Robust disturbance rejection methodology for unstable non-minimum phase systems via disturbance observer
Related Experiment Video
Updated: Jan 2, 2026

Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
1Marine Navigation Research Institute, College of Automation, Harbin Engineering University, Harbin 150001, PR China.

Abstract:
In this work, we propose a disturbance rejection methodology to deal with control problem of unstable non-minimum phase (NMP) systems. Firstly, we propose a two degrees-of-freedom control structure, which consists of an outer loop feedback controller and an inner loop disturbance observer (DOB). Specifically, the controller is designed for desired control performance, whereas the robust DOB is applied to deal with external disturbances and internal uncertainties. By analyzing the robust internal stability, several design requirements on both controller and DOB are presented for the control system. The H2 theory is adopted for controller design. Then, we propose a systematic DOB optimization method for unstable NMP systems. The proposed method synthesizes the relative order, robust internal stability and mixed sensitivity optimization together to formulate the cost function. The standard H∞ method is introduced to acquire the optimal solution that guarantying the design requirements. Simulations show that the proposed method can deal with the control system design for the unstable NMP systems, and it also has better performance comparing with the traditional method.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 07:19
A Modified Lean and Release Technique to Emphasize Response Inhibition and Action Selection in Reactive Balance
Published on: March 19, 2020
Related Concept Videos
 01:18
Second Order systems II
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:28
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:23
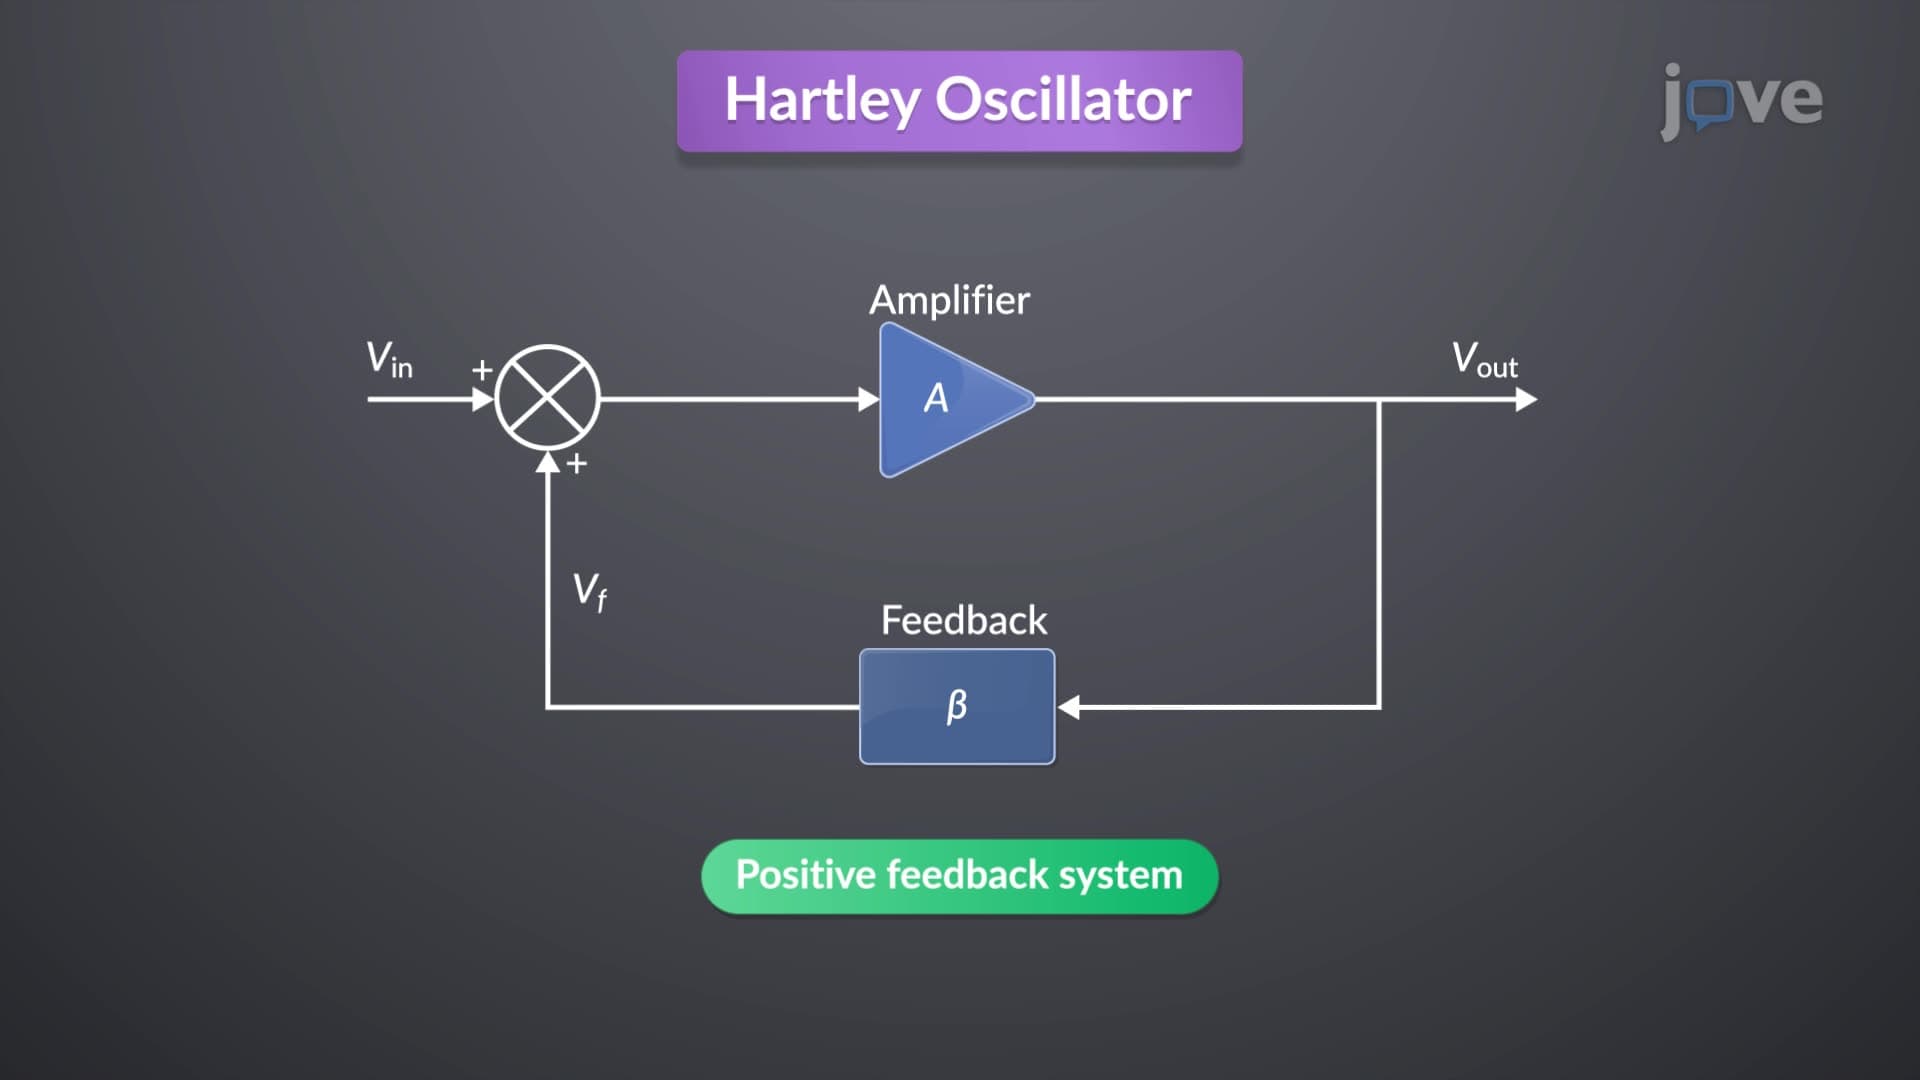
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...
 01:19
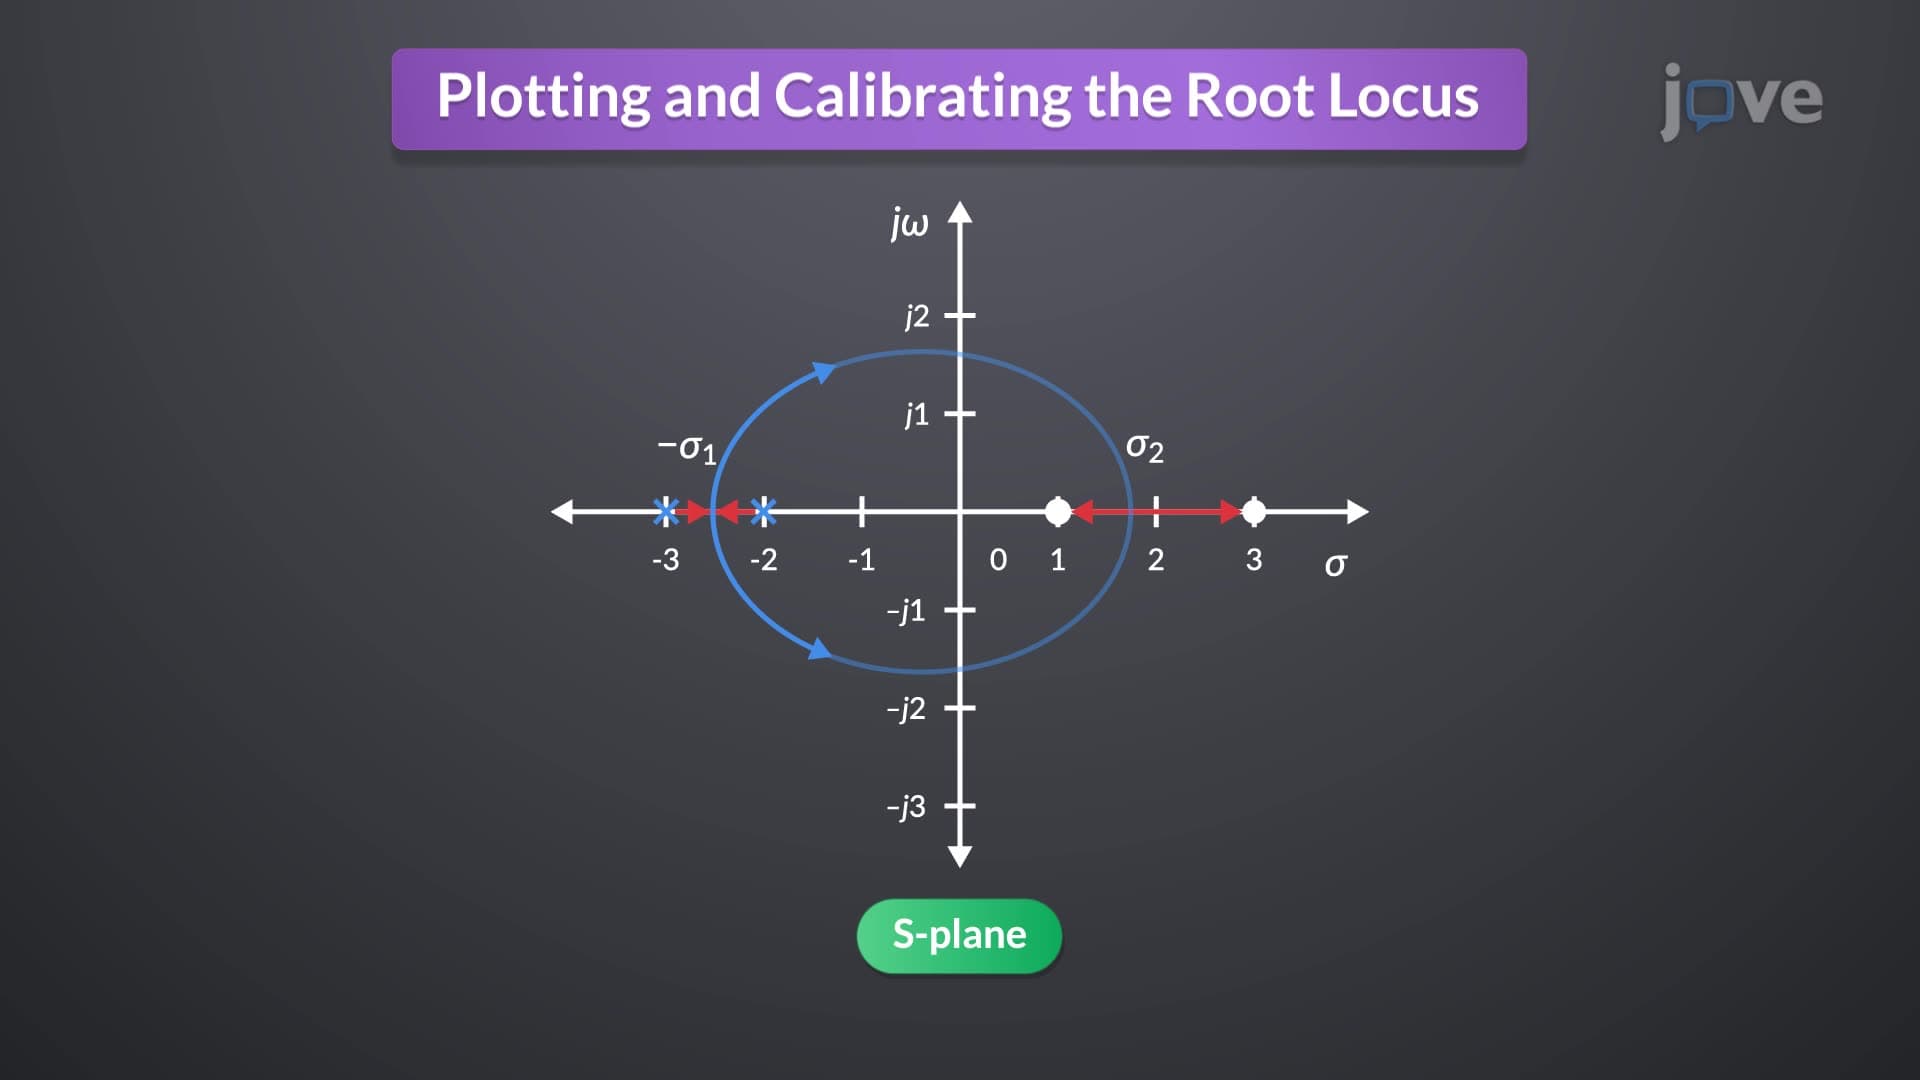
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...