Related Experiment Video
Updated: Jan 2, 2026
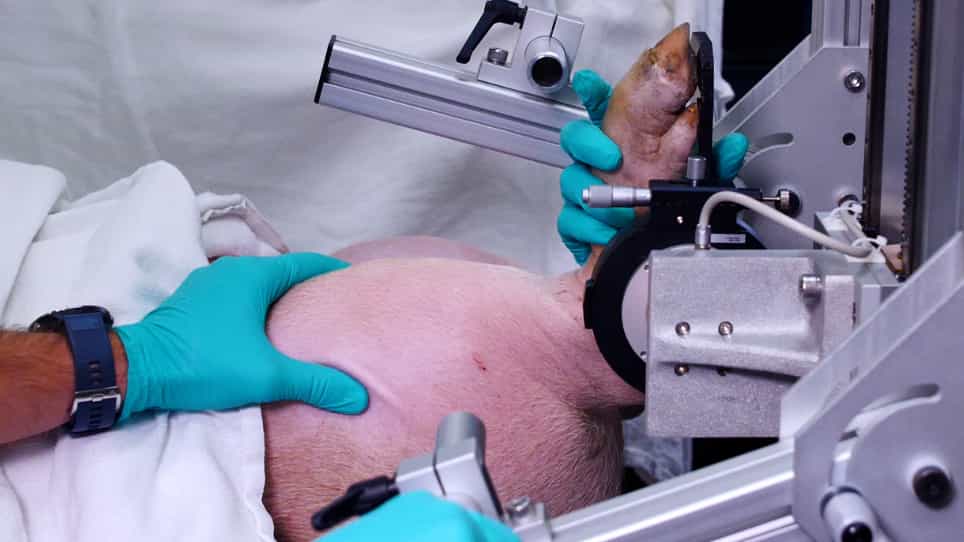

In Vivo Measurement of Hindlimb Dorsiflexor Isometric Torque from Pig
Published on: September 3, 2021
Direct Validation of Model-Predicted Muscle Forces in the Cat Hindlimb During Locomotion
Derya Karabulut1, Suzan Cansel Dogru1, Yi-Chung Lin2
1Department of Mechanical Engineering, Faculty of Engineering, Istanbul University-Cerrahpasa, Avcilar, Istanbul 34320, Turkey.

Abstract:
Various methods are available for simulating the movement patterns of musculoskeletal systems and determining individual muscle forces, but the results obtained from these methods have not been rigorously validated against experiment. The aim of this study was to compare model predictions of muscle force derived for a cat hindlimb during locomotion against direct measurements of muscle force obtained in vivo. The cat hindlimb was represented as a 5-segment, 13-degrees-of-freedom (DOF), articulated linkage actuated by 25 Hill-type muscle-tendon units (MTUs). Individual muscle forces were determined by combining gait data with two widely used computational methods-static optimization and computed muscle control (CMC)-available in opensim, an open-source musculoskeletal modeling and simulation environment. The forces developed by the soleus, medial gastrocnemius (MG), and tibialis anterior muscles during free locomotion were measured using buckle transducers attached to the tendons. Muscle electromyographic activity and MTU length changes were also measured and compared against the corresponding data predicted by the model. Model-predicted muscle forces, activation levels, and MTU length changes were consistent with the corresponding quantities obtained from experiment. The calculated values of muscle force obtained from static optimization agreed more closely with experiment than those derived from CMC.