Related Experiment Video
Updated: Jan 2, 2026


Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
Central pattern generator-based coupling control method for synchronously controlling the two-degrees-of-freedom
Qiang Fu1, Tianhong Luo1, Chunpeng Pan1
1Department of Robot Engineering, Chongqing University of Arts and Sciences, Chongqing, China.

Abstract:
Synchronous control is a fundamental and significant problem for controlling a multi-joint robot. In this article, by applying two coupled Rayleigh oscillators as the referred central pattern generator models for the two joints of a two-degrees-of-freedom robot, the central pattern generator-based coupling control method is proposed for controlling the two-degrees-of-freedom robot's joints. On these bases, the co-simulation model of the two-degrees-of-freedom robot with the proposed central pattern generator-based coupling control method is established via ADAMS and MATLAB/Simulink, and the performance of the central pattern generator-based coupling control method on synchronizing two motions of two-degrees-of-freedom robot's joints is numerically simulated. Furthermore, the experimental setup of a two-degrees-of-freedom robot is established based on the real-time simulations system via the proposed central pattern generator-based coupling control method. And experiments are carried out on the established setup. Simulations and experimental results show that the phase of the controlled two-degrees-of-freedom robot's joints is mutual locked to other, and their motion pattern can be adjusted through the coupling parameter in the central pattern generator-based coupling control method. In conclusion, the proposed central pattern generator-based coupling control method can control the two-degrees-of-freedom robot's joints to produce the coordinated motions and adjust the rhythmic pattern of the two-degrees-of-freedom robot.


Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:19
PID Controller
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:30
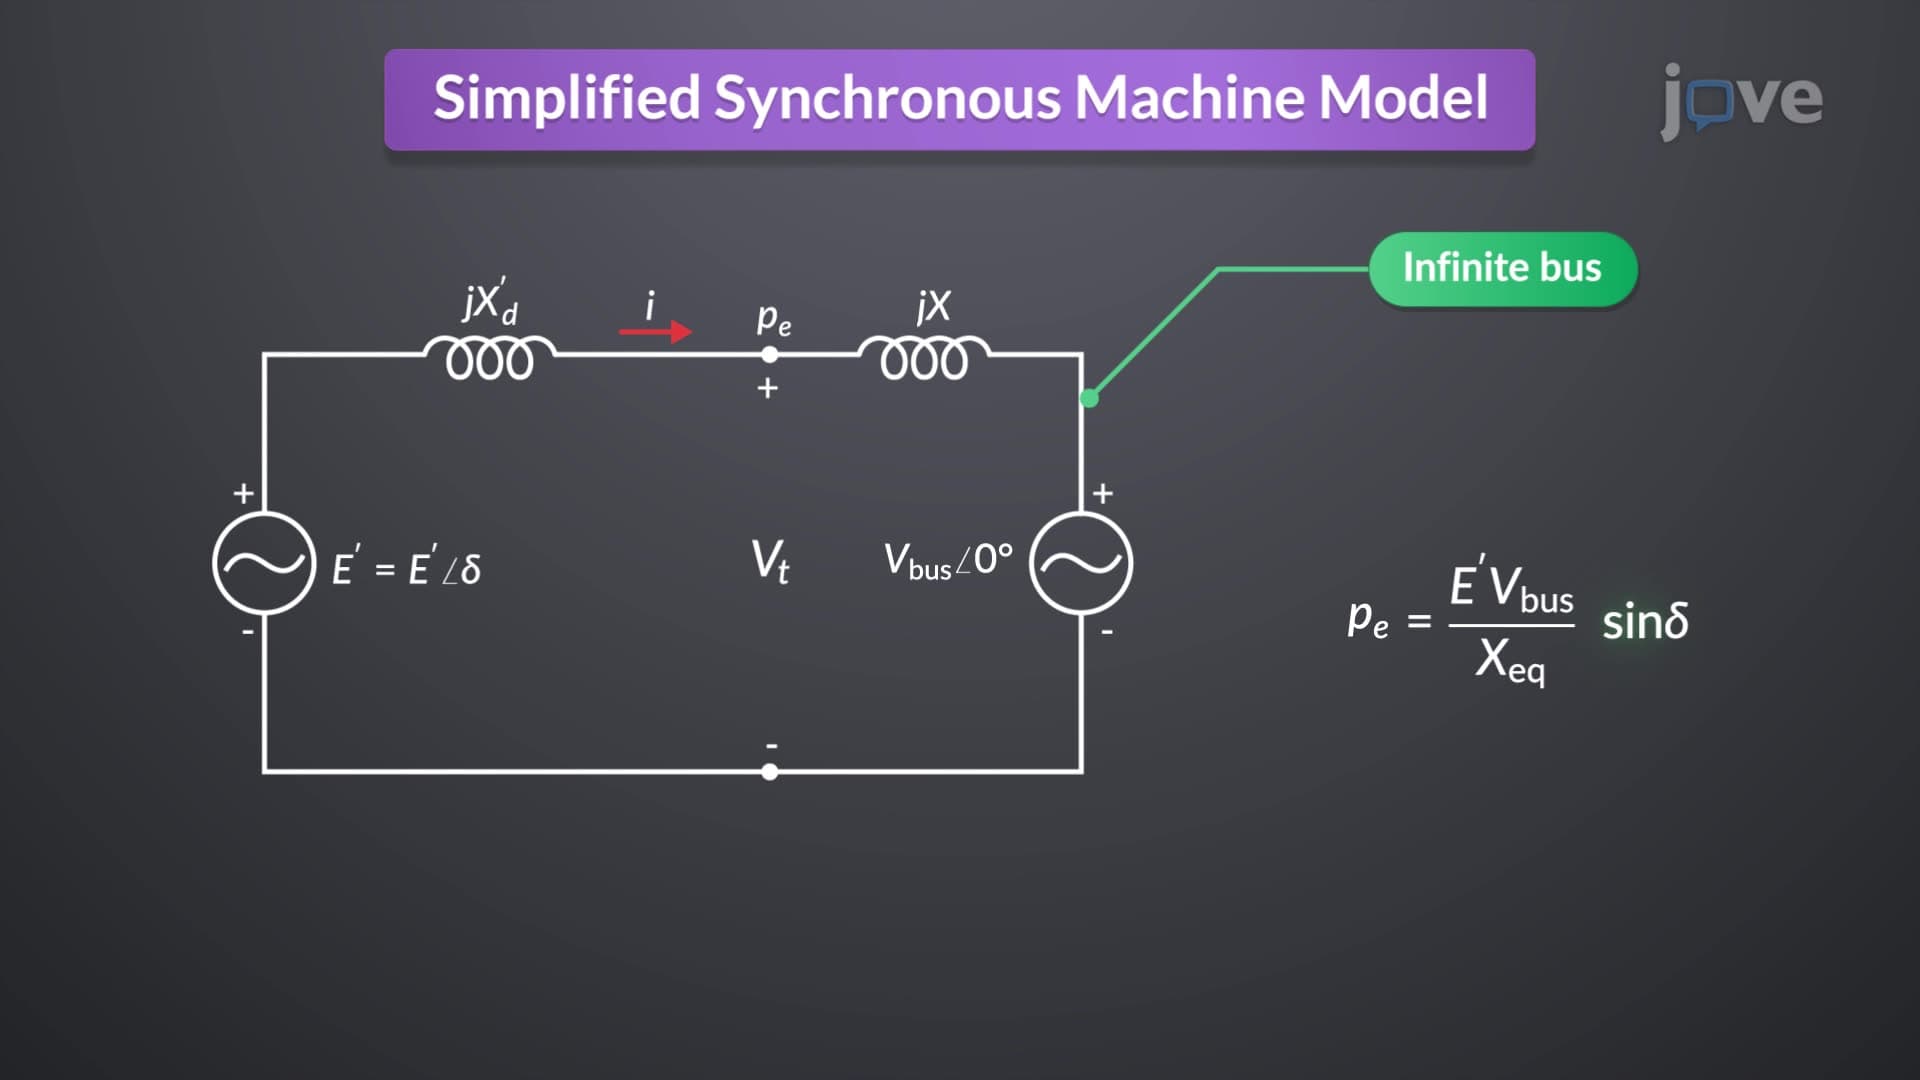
Simplified Synchronous Machine Model
In this model, each generator is connected to a...