Optimized LOAM Using Ground Plane Constraints and SegMatch-Based Loop Detection
Related Experiment Video
Updated: Jan 2, 2026
Automatic Laser-based Geometry Capture for Finite Element Analysis of Weld Beads
Published on: July 25, 2025
Xiao Liu1,2, Lei Zhang2, Shengran Qin2,3
1Faculty of Robot Science and Engineering, Northeastern University, Shenyang 110016, China.

Abstract:
Reducing the cumulative error in the process of simultaneous localization and mapping (SLAM) has always been a hot issue. In this paper, in order to improve the localization and mapping accuracy of ground vehicles, we proposed a novel optimized lidar odometry and mapping method using ground plane constraints and SegMatch-based loop detection. We only used the lidar point cloud to estimate the pose between consecutive frames, without any other sensors, such as Global Positioning System (GPS) and Inertial Measurement Unit (IMU). Firstly, the ground plane constraints were used to reduce matching errors. Then, based on more accurate lidar odometry obtained from lidar odometry and mapping (LOAM), SegMatch completed segmentation matching and loop detection to optimize the global pose. The neighborhood search was also used to accomplish the loop detection task in case of failure. Finally, the proposed method was evaluated and compared with the existing 3D lidar SLAM methods. Experiment results showed that the proposed method could realize low drift localization and dense 3D point cloud map construction.
More Related Videos
 09:45
Large-area Scanning Probe Nanolithography Facilitated by Automated Alignment and Its Application to Substrate Fabrication for Cell Culture Studies
Published on: June 12, 2018
 11:53
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Related Concept Videos
 01:19
Design Example: Maintaining Level of an Embankment
 01:14
Design Example: Managing Concrete Workability
 01:16
Segregation in Fresh Concrete
 01:12
Taping Over Different Ground Profiles
 01:21
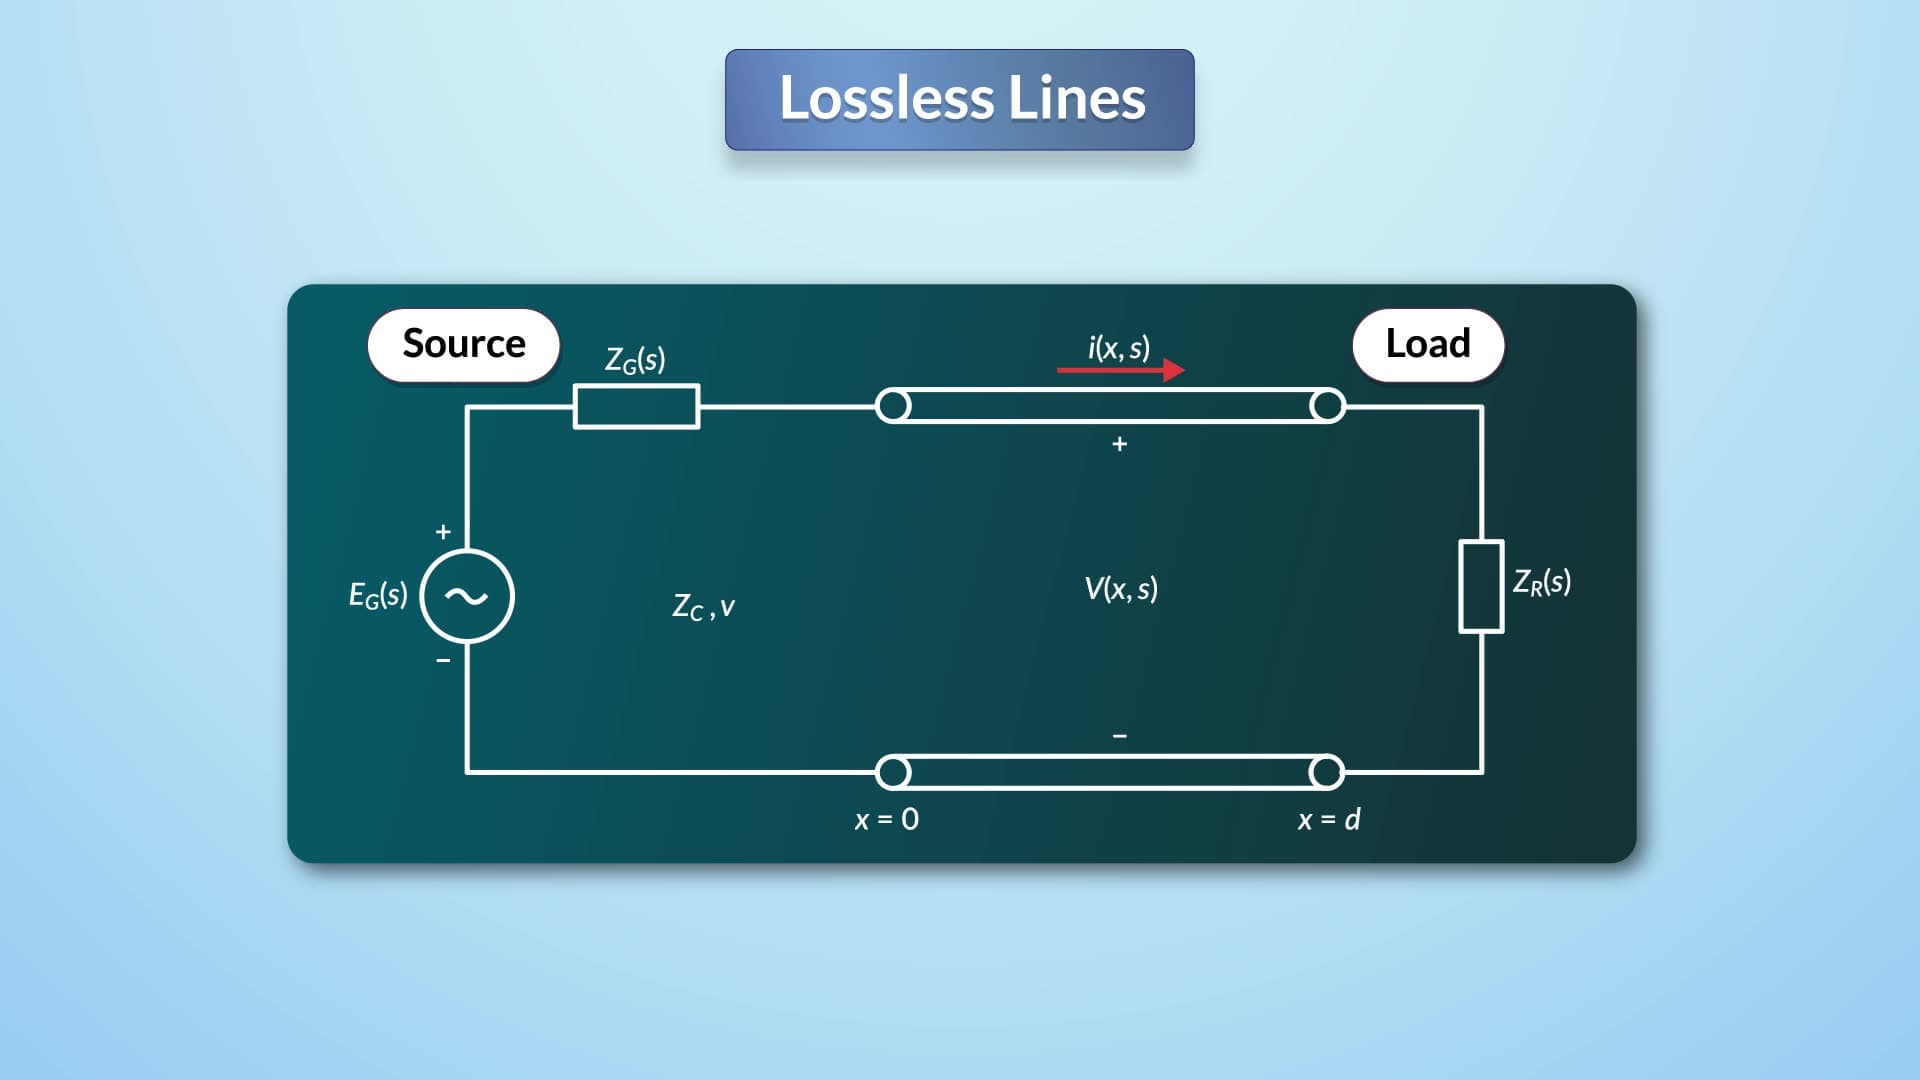
Boundary Conditions: Lossless Lines
At the receiving end, the boundary condition states that the voltage equals the product of the receiving-end impedance and current. This relationship is expressed as a function of the incident and...
 01:26
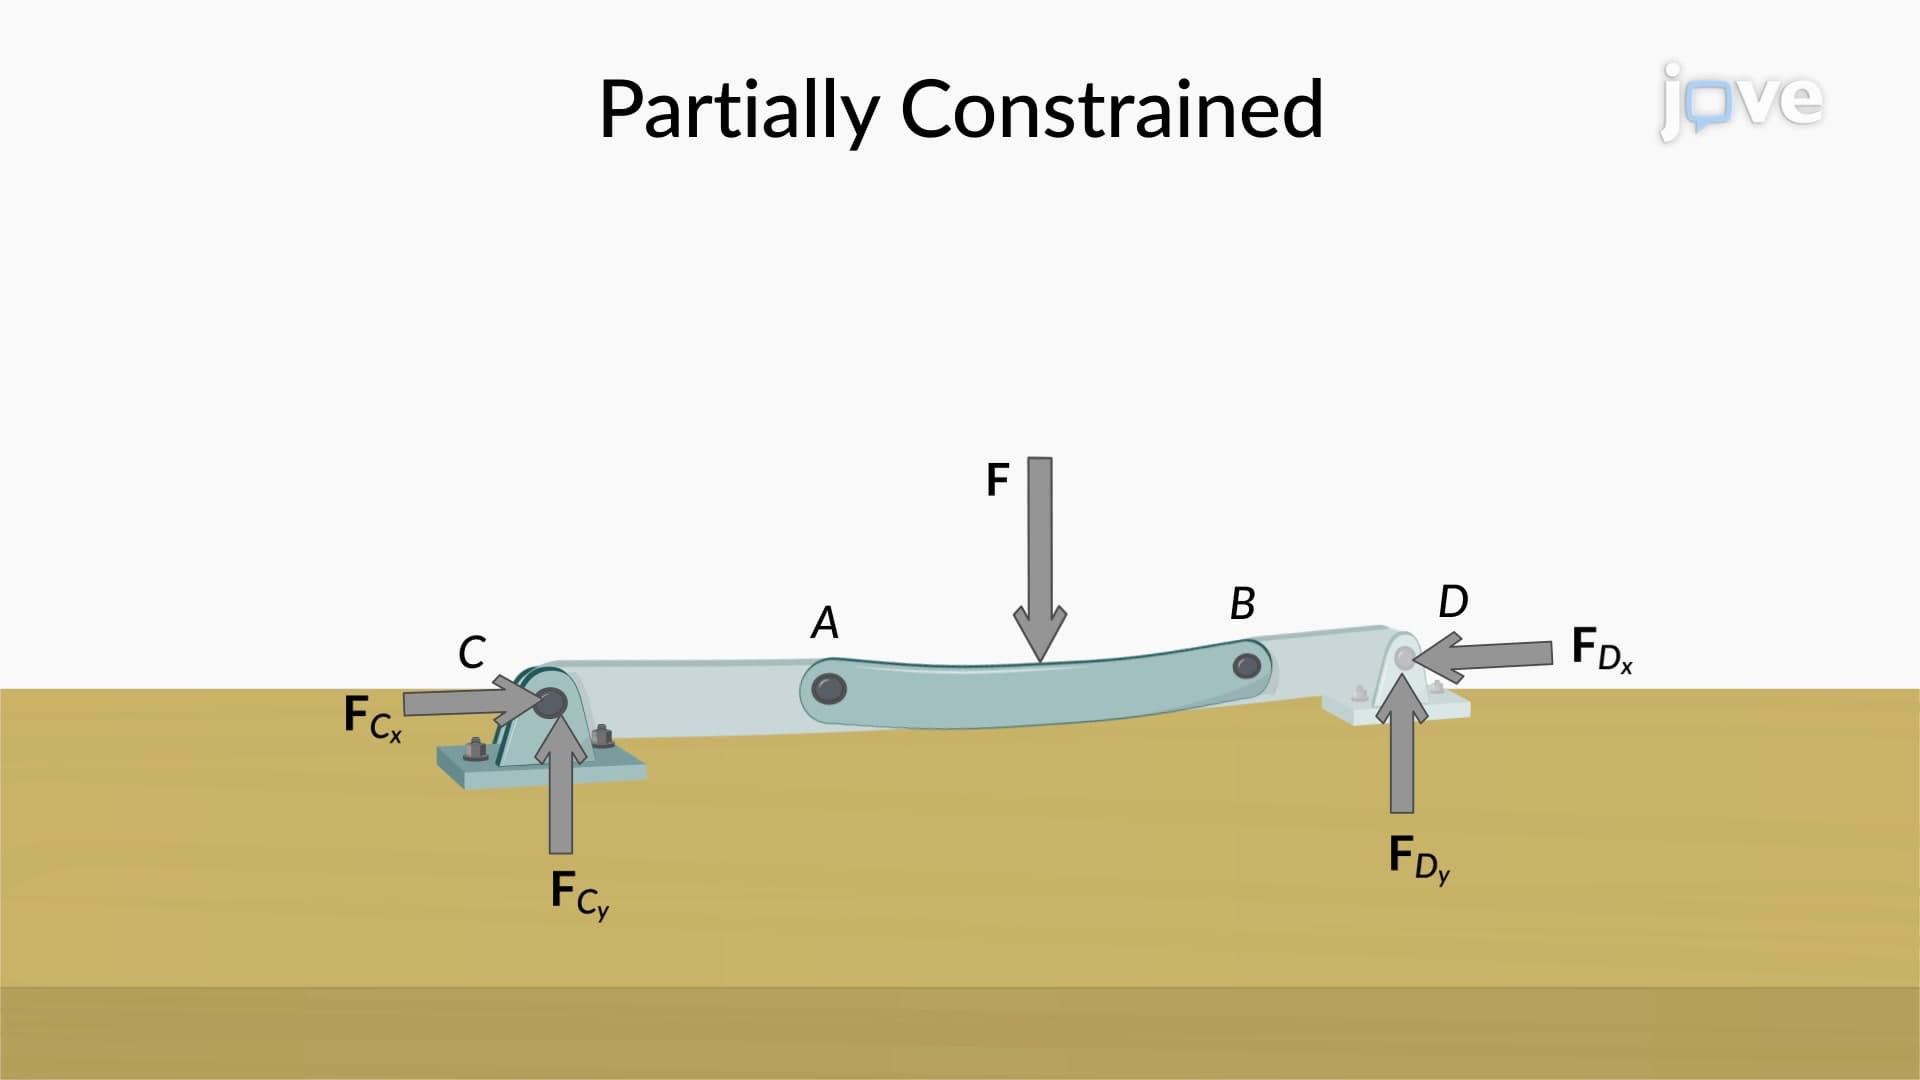
Constraints and Statical Determinacy