Multi-Target Localization and Tracking Using TDOA and AOA Measurements Based on Gibbs-GLMB Filtering
Related Experiment Video
Updated: Jan 2, 2026

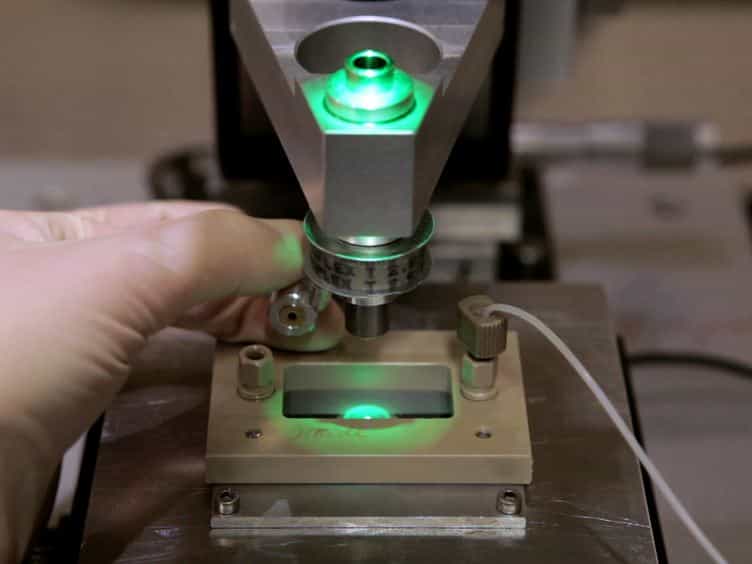
A Protocol for Real-time 3D Single Particle Tracking
Published on: January 3, 2018
Zhengwang Tian1, Weifeng Liu1, Xinfeng Ru1
1Xiasha Higher Education Zone, Hangzhou 310018, Zhejiang, China.

Abstract:
This paper deals with mobile multi-target detection and tracking. In the traditional method, there are uncertainties such as misdetection and false alarm in the measurement data, and it will be inevitable having to deal with the data association. To solve the target trajectory and state estimation problem under a cluttered environment, this paper proposes a non-concurrent multi-target acoustic localization tracking method based on the Gibbs-generalized labelled multi-Bernoulli (Gibbs-GLMB) filter and considers an acoustic array of a fixed arrangement for the tracking of targets by joint time difference of arrival (TDOA) and angle of arrival (AOA) measurements. Firstly, the TDOAs are calculated by using the generalized cross-correlation algorithm (GCC) and the AOAs are derived from the received signal directions. Secondly, we assume the independence of the targets and fuse the measurements which are used to track the multiple targets via the Gibbs-GLMB filter. Finally, the effectiveness of the method is verified by Monte Carlo simulation experiments.

Related Concept Videos
 01:18
Distance Measurements by Taping
 01:30
Types of Global Positioning System Surveys
 01:28
Field Application of Global Positioning System
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:26
Errors in Global Positioning System
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...