Related Experiment Video
Updated: Jan 1, 2026
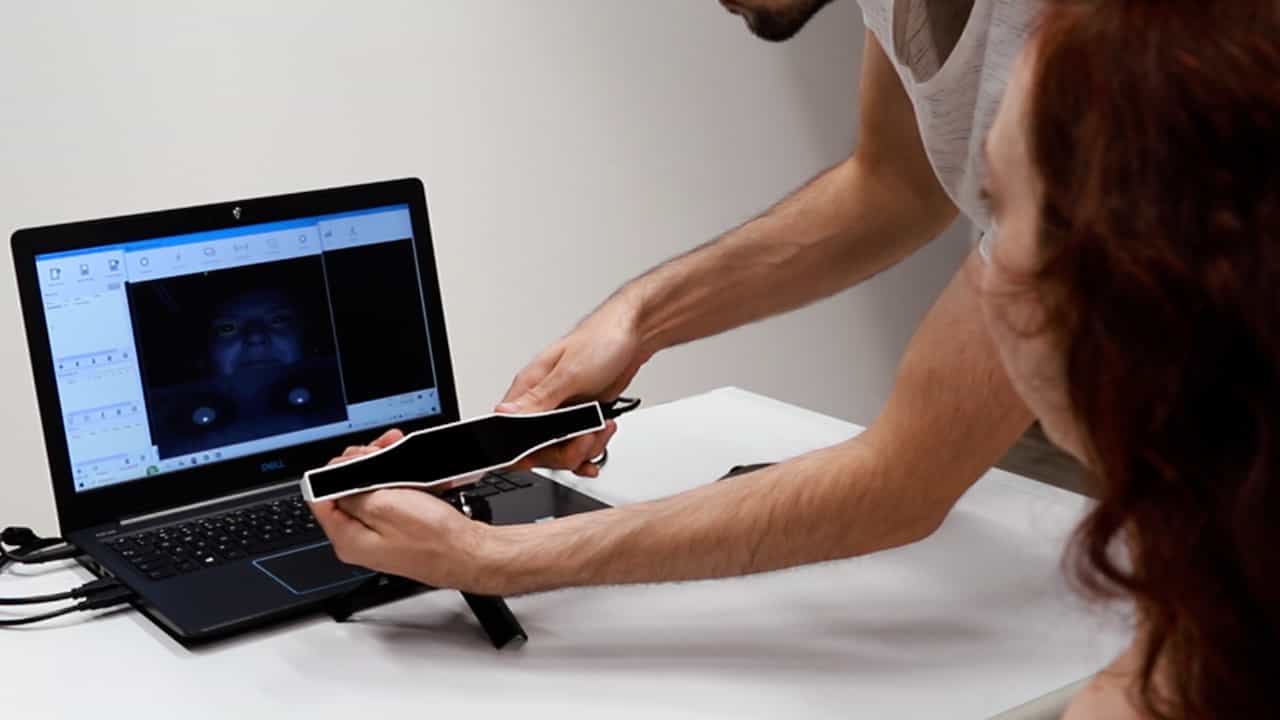

Author Spotlight: Insights into the Analysis of Human Interaction with 3D Virtual Objects
Published on: October 18, 2024
Evaluating Local Geometric Feature Representations for 3D Rigid Data Matching

Abstract:
Local geometric descriptors act as an essential component for 3D rigid data matching. A rotational invariant local geometric descriptor usually consists of two components: local reference frame (LRF) and feature representation. However, existing evaluation efforts have mainly been paid on the LRF or the overall descriptor and the quantitative comparison of feature representations remains unexplored. This paper fills the gap by comprehensively evaluating nine state-of-the-art local geometric feature representations. In particular, our evaluation assesses feature representations based on ground-truth LRFs such that the ranking of tested methods is more convincing as compared with existing studies. The experiments are deployed on six standard datasets with various application scenarios (shape retrieval, point cloud registration, and object recognition) and data modalities (LiDAR, Kinect, and Space Time) as well as perturbations including Gaussian noise, shot noise, data decimation, clutter, occlusion, and limited overlap. The evaluated terms cover the major concerns for a feature representation, e.g., distinctiveness, robustness, compactness, and efficiency. The outcomes present interesting findings that may shed new light on this community and provide complementary perspectives to existing evaluations on the topic of local geometric feature description. A summary of evaluated methods regarding their peculiarities is finally presented to guide real-world applications and new descriptor crafting.
More Related Videos
 10:23
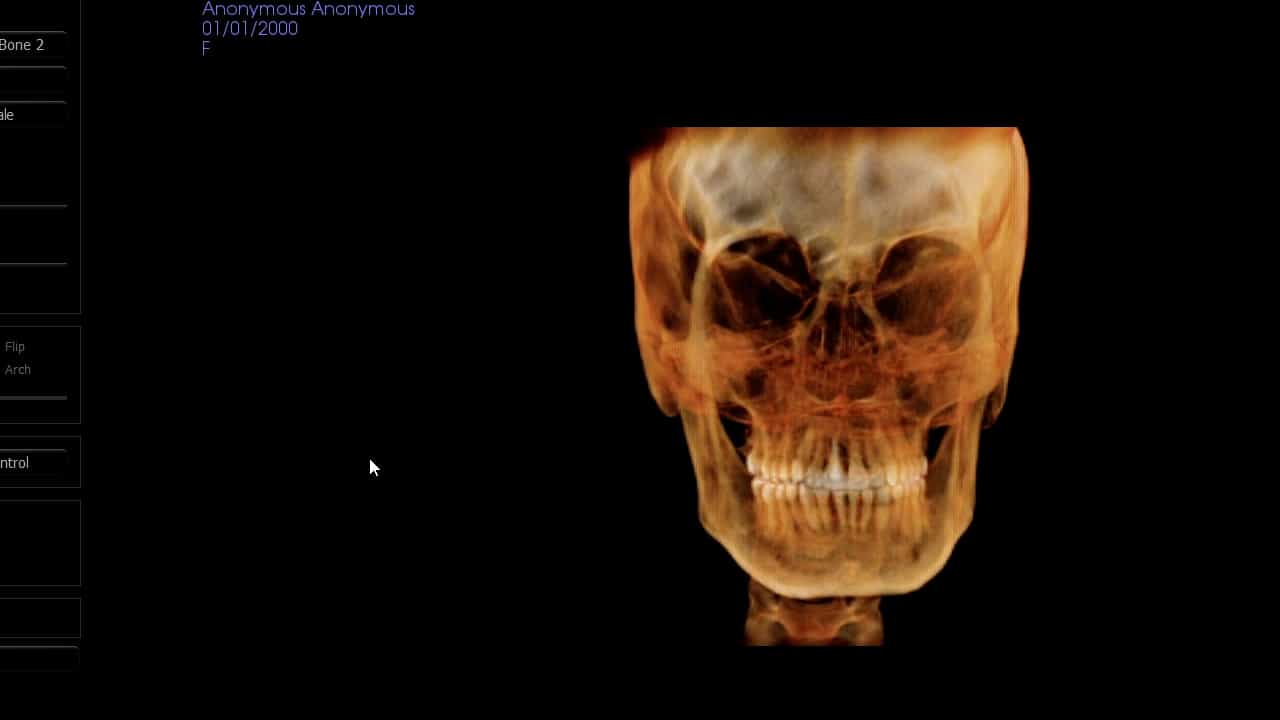
Author Spotlight: Three-Dimensional Cephalometric Landmark Annotation Demonstration on Human Cone Beam Computed Tomography Scans
Published on: September 8, 2023
 07:46
Author Spotlight: Revolutionizing Remote Surgery with Augmented Reality and Robotics for Enhanced Precision and Accessibility
Published on: August 9, 2024
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:29
Three-Dimensional Analysis of Strain