First-order derivative matrix of a ray: a simple and flexible alternative computation method
Related Experiment Video
Updated: Jan 1, 2026

Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013

Abstract:
The present group previously proposed a method for determining the first-order derivative matrix (i.e., the Jacobian matrix) of a skew ray by taking all the independent variables of the optical system as the system variable vector, X¯sys. However, many trigonometric function calls, divisions, multiplications and additions were required to determine the ray Jacobian matrix with respect to X¯sys. Accordingly, in the present study, the angular variables in the system variable vector, X¯sys, are replaced with their respective cosine and sine trigonometric functions. The boundary variable vector, X¯i, is similarly redefined such that it includes no angular variables. The proposed method has three main advantages over that previously reported: 1) it is valid for any pose matrix, irrespective of the order in which the rotation and translation motions of a boundary are assigned; 2) it involves only polynomial differentiation, and is thus easily implemented in computer code; and 3) the computation speed of ∂X¯i/∂X¯i ∂X¯sys ∂X¯sys is improved by a factor of approximately ten times.
Related Concept Videos
 01:22
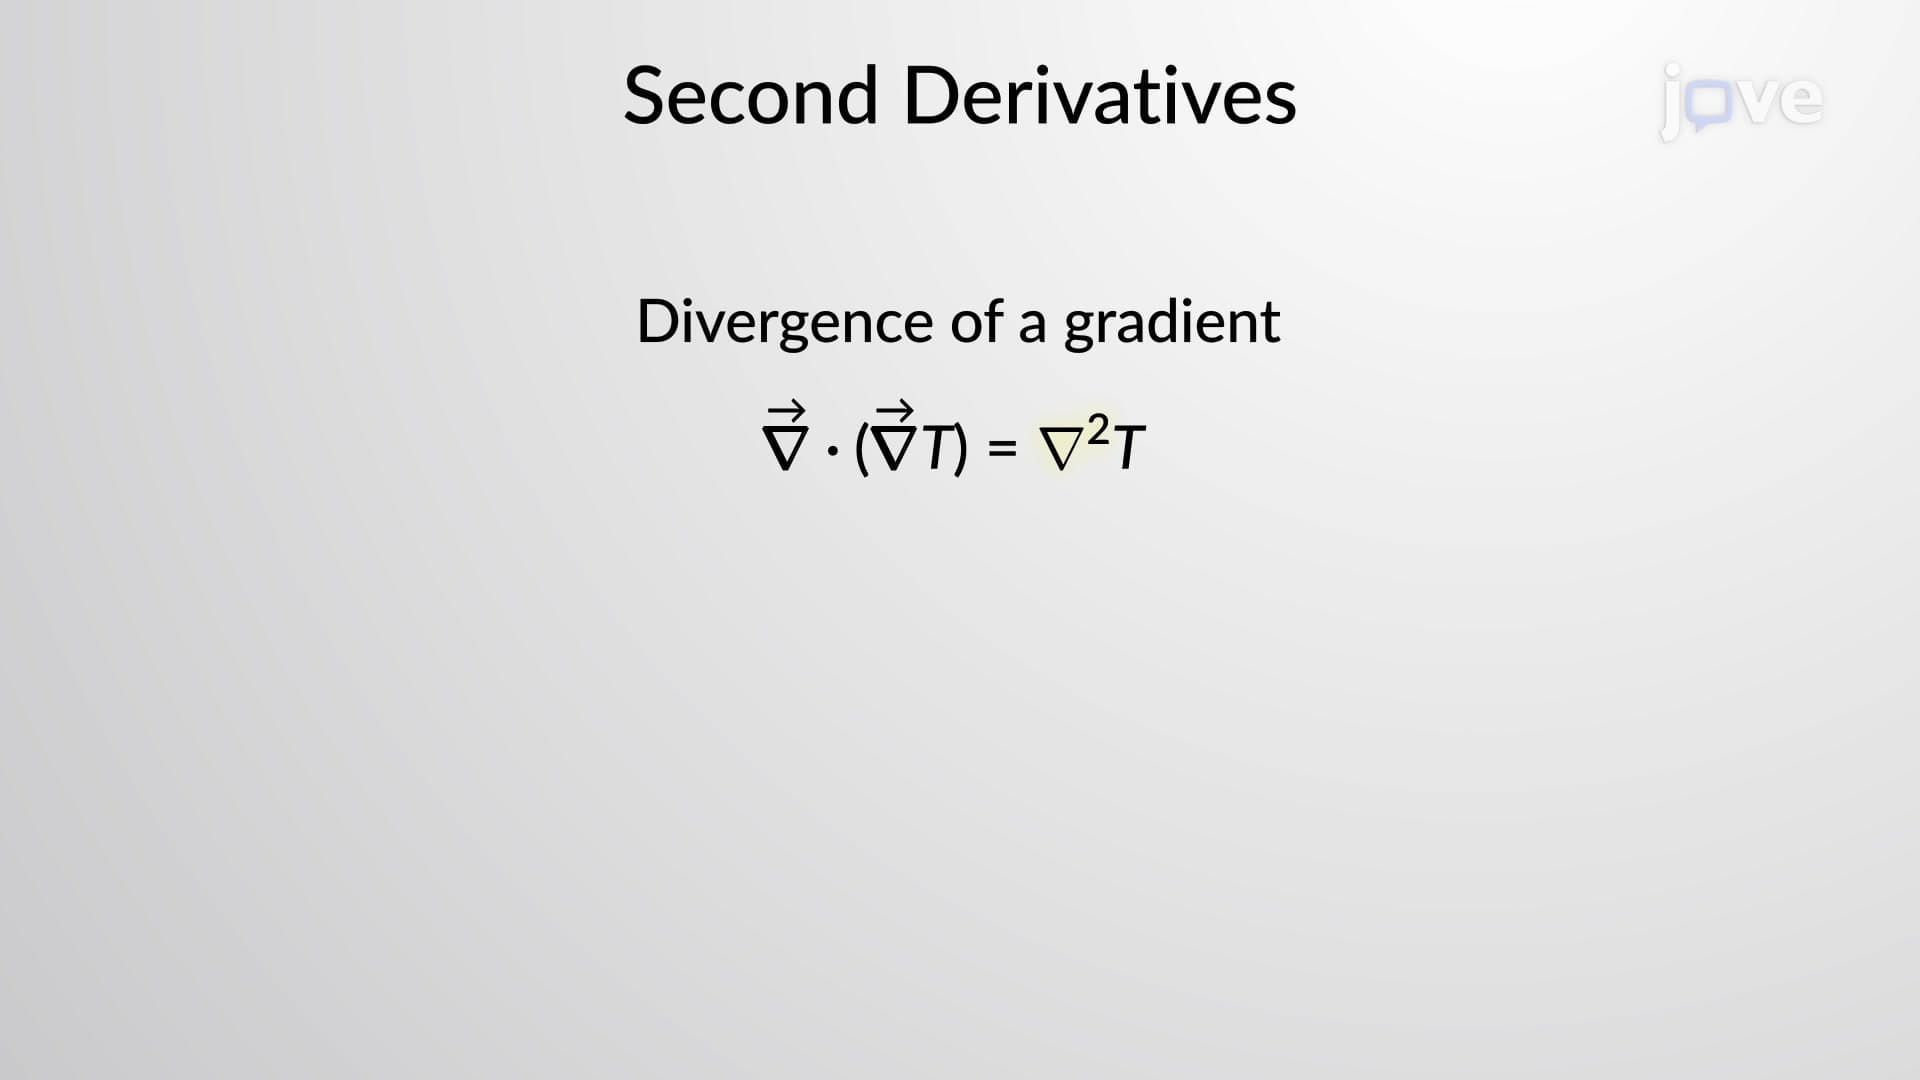
Second Derivatives and Laplace Operator
Consider a scalar function. The curl of its...
 01:16
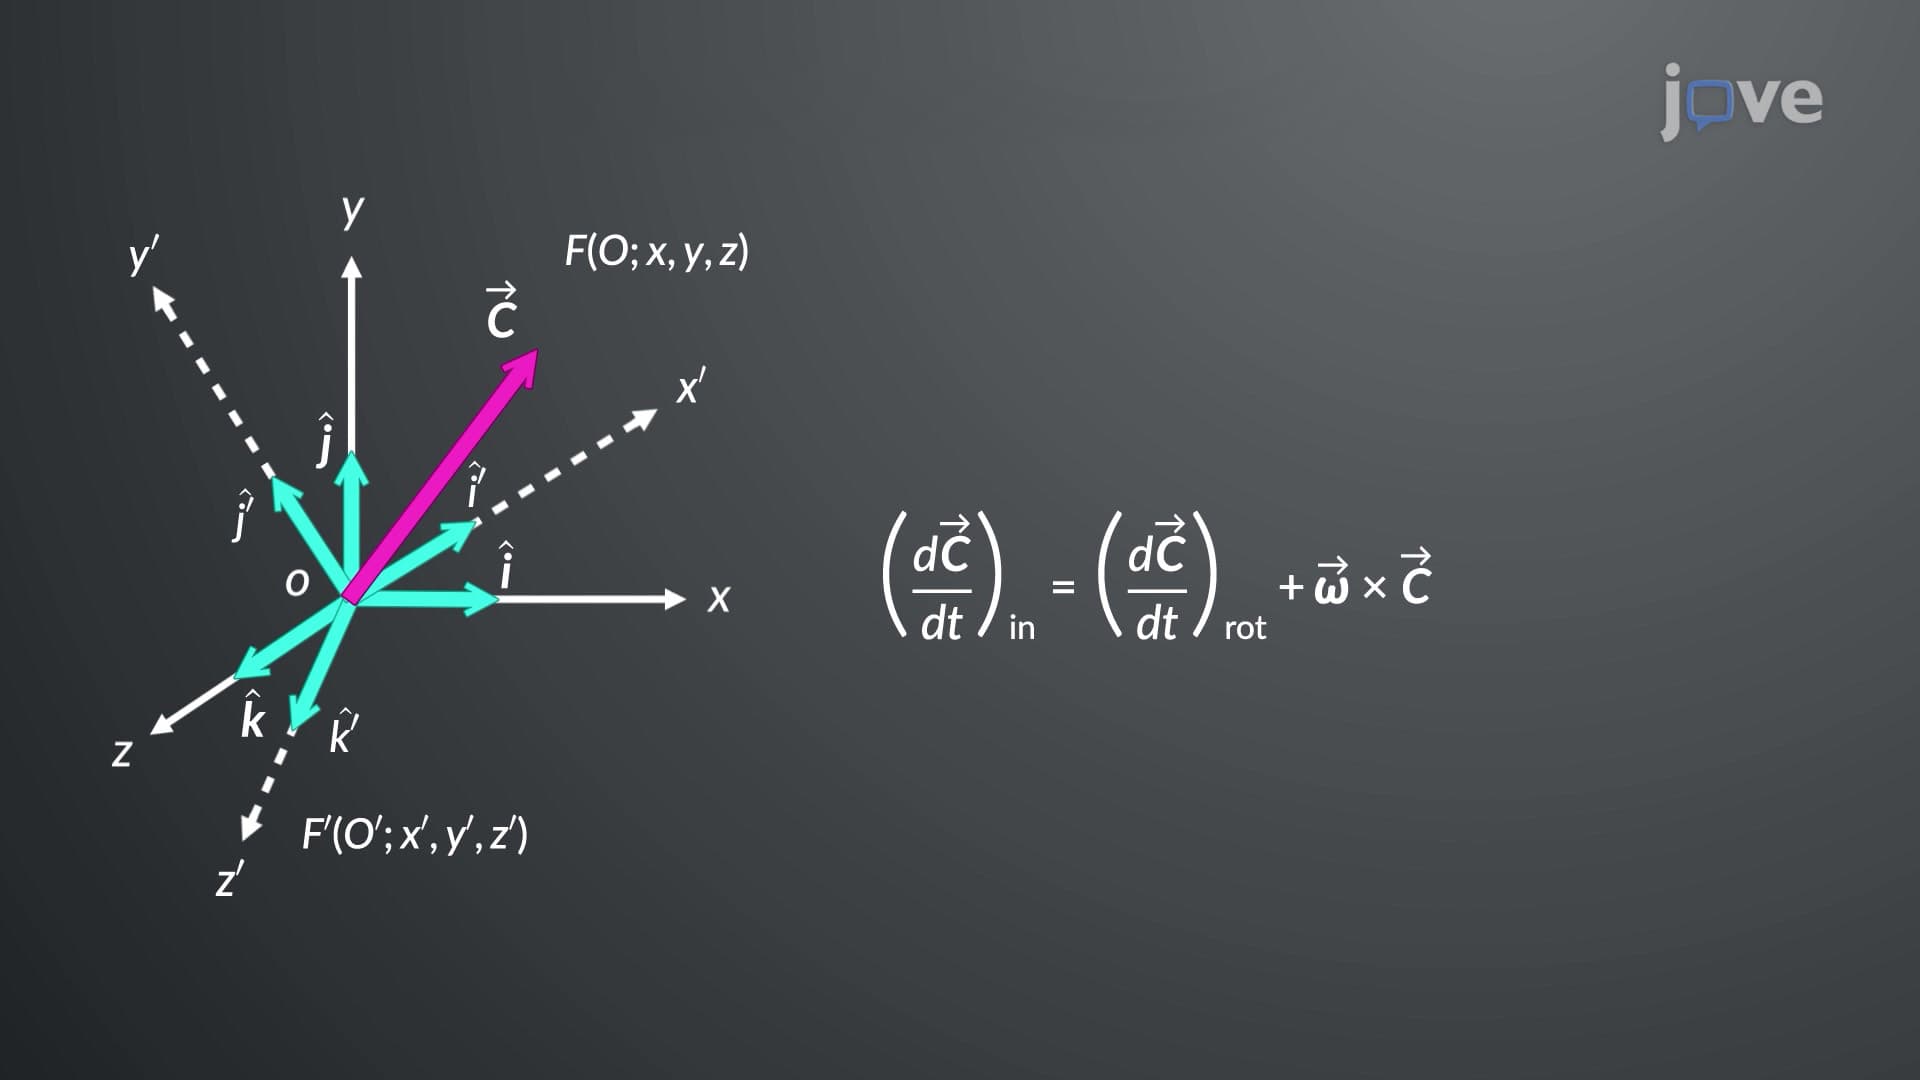
Vector Transformation in Rotating Coordinate Systems
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:10
Vector Algebra: Graphical Method
We use the laws of geometry to construct resultant vectors, followed by trigonometry to find vector magnitudes and directions. For a geometric construction of the sum of two vectors in a plane, we follow the parallelogram rule. Suppose two vectors are at arbitrary positions. Translate either one of...
 01:18
Castigliano's Theorem