Related Experiment Video
Updated: Dec 31, 2025
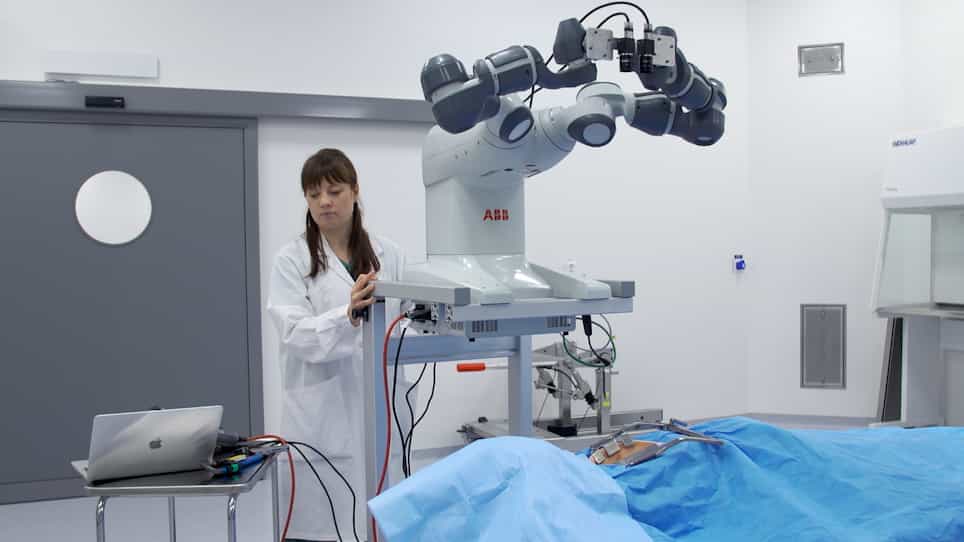
Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021
Cycle-SfM: Joint self-supervised learning of depth and camera motion from monocular image sequences
Qiyu Sun1, Yang Tang1, Chaoqiang Zhao1
1The Key Laboratory of Advanced Control and Optimization for Chemical Processes, Ministry of Education, East China University of Science and Technology, Shanghai 200237, China.

Abstract:
Understanding 3D scene geometry is a fundamental research topic in computer vision, including various subproblems, such as depth prediction, visual odometry, optical flow, etc. With the advent of artificial intelligence methods like deep learning, many approaches have emerged to deal with such problems in an end-to-end manner. These pipelines take the 3D understanding task as a nonlinear optimization problem, with the purpose of minimizing the cost function of the whole framework. Here, we present a self-supervised framework for jointly learning the monocular depth and camera's ego-motion from unlabeled, unstructured, and monocular video sequences. We propose a forward-backward consistency constraint on view reconstruction to capture temporal relations across adjacent frames, whose purpose is to explore and make full use of the bidirectional projection information. A simple and practicable improvement on the design of cost function is proposed to enhance the estimated accuracy. Due to the fact that our improvement is a lightweight and general module, it can be integrated into any self-supervised architectures seamlessly, and more accurate results can be obtained. The evaluation on the KITTI dataset demonstrates that our approach is highly efficient and performs better than the existing works in pose estimation, while the results in depth estimation perform comparably with the existing ones.
Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:12
Observational Learning
 01:18
Uniform Depth Channel Flow: Problem Solving