Related Experiment Video
Updated: Dec 31, 2025


Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
Coupling analysis of a 5-degree-of-freedom hybrid manipulator based on a global index
Yanqin Zhao1, Jiangping Mei1, Wentie Niu1
1Key Laboratory of the Ministry of Education on Mechanism Theory and Equipment Design, Tianjin University, Tianjin, China.

Abstract:
Parallel kinematic machines have been applied in aerospace and automotive manufacturing due to their potentials in high speed and high accuracy. However, there exists coupling in parallel kinematic machines, which makes dynamic analysis, rigidity enhancement, and control very complicated. In this article, coupling characteristics of a 5-degree-of-freedom (5-dof) hybrid manipulator are analyzed based on a local index and a global index. First, velocity analysis as well as acceleration analysis of the robot is conducted to provide essential information for dynamic modeling. Then the dynamic model is built based on the principle of virtual work. Whereas the mass matrix is off-diagonal, a local coupling index as well as a global index is defined, based on which coupling characteristics of the robot are analyzed. Results show that distributions of coupling indices are symmetric due to its structural features. And dimensional parameters, structural parameters, as well as mass parameters have a large influence on the system's coupling characteristics. Research conducted in the article is of great help in optimal design and control. Meanwhile, the method proposed in the article can be applied to other types of parallel kinematic machines or hybrid manipulators.


Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Moment of a Couple: Problem Solving
The moment of a couple is found by multiplying the magnitude of one of the forces by the perpendicular distance between the line of action of the two forces. This creates a twisting force, which can be used to rotate an object. The moment of a couple is used to solve problems...
 01:10
Relative Motion Analysis - Acceleration
 01:23
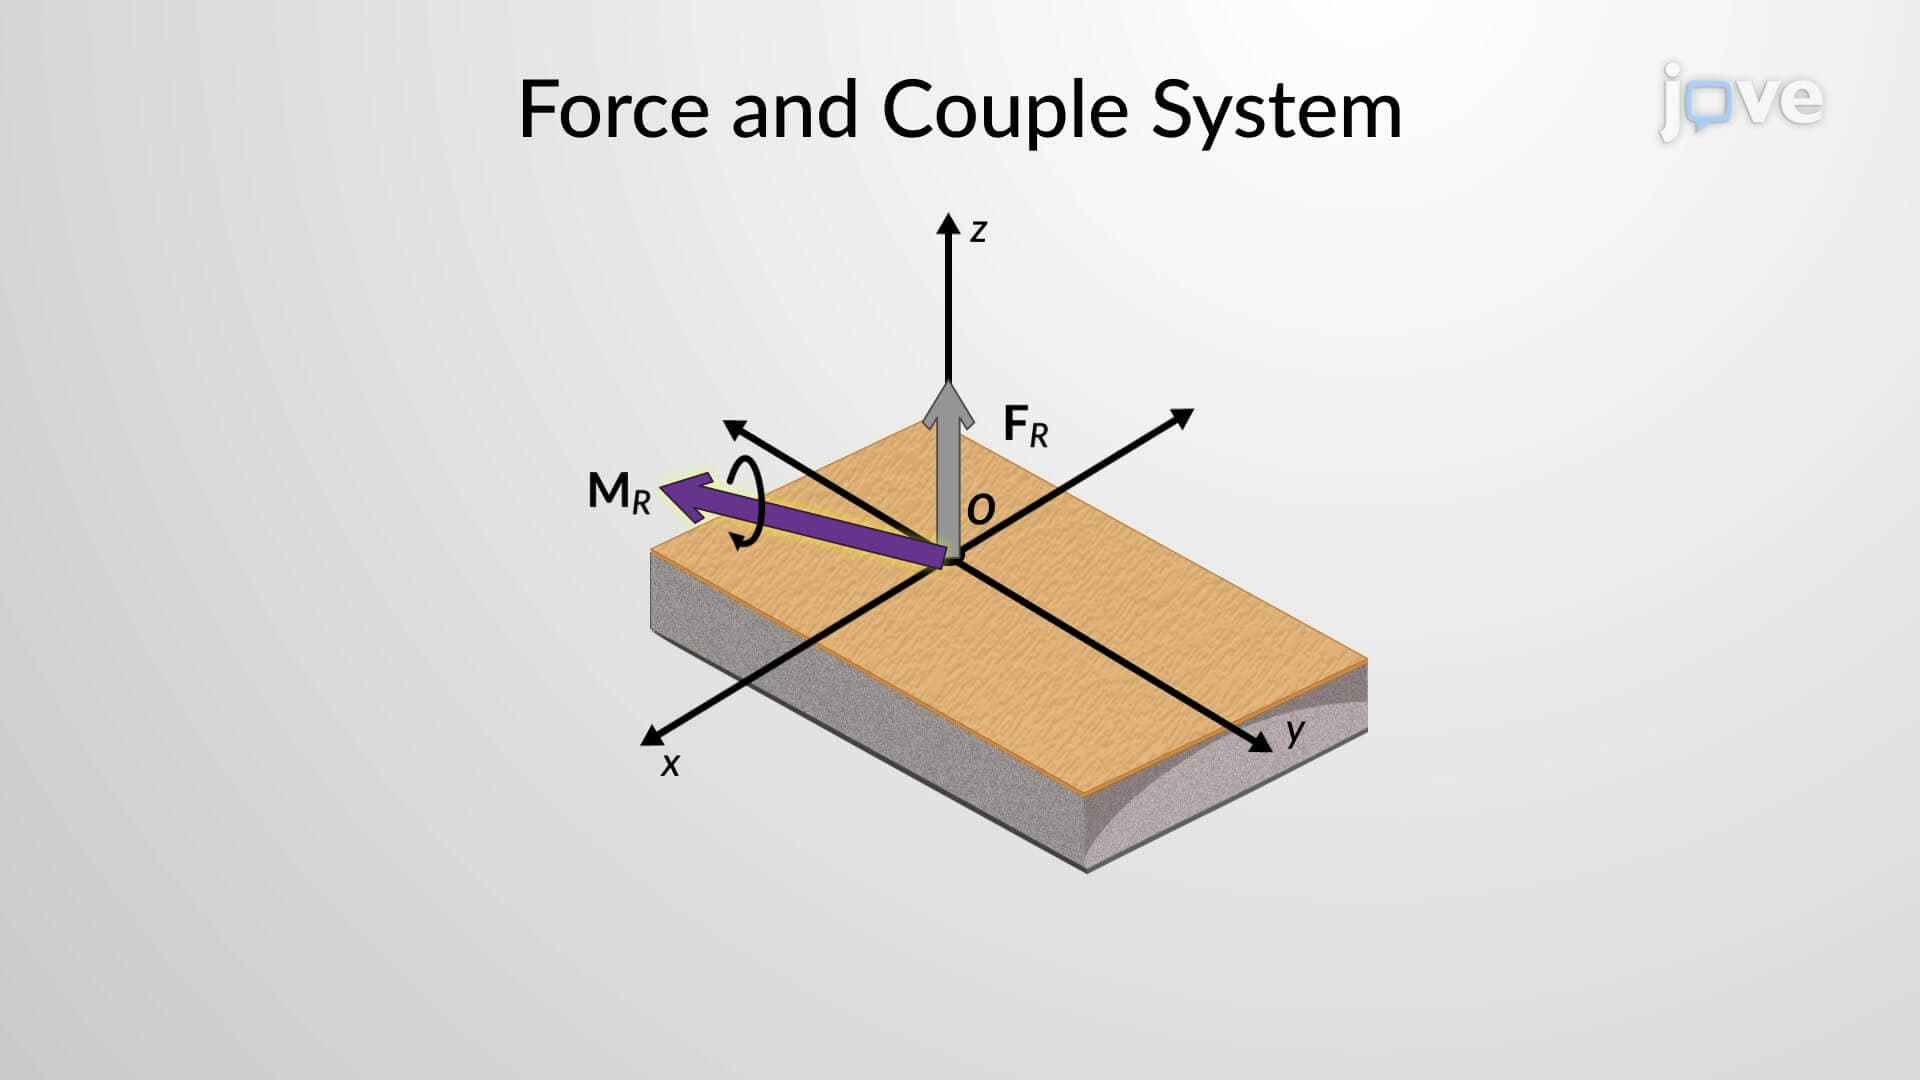
Simplification of a Force and Couple System: II
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:18
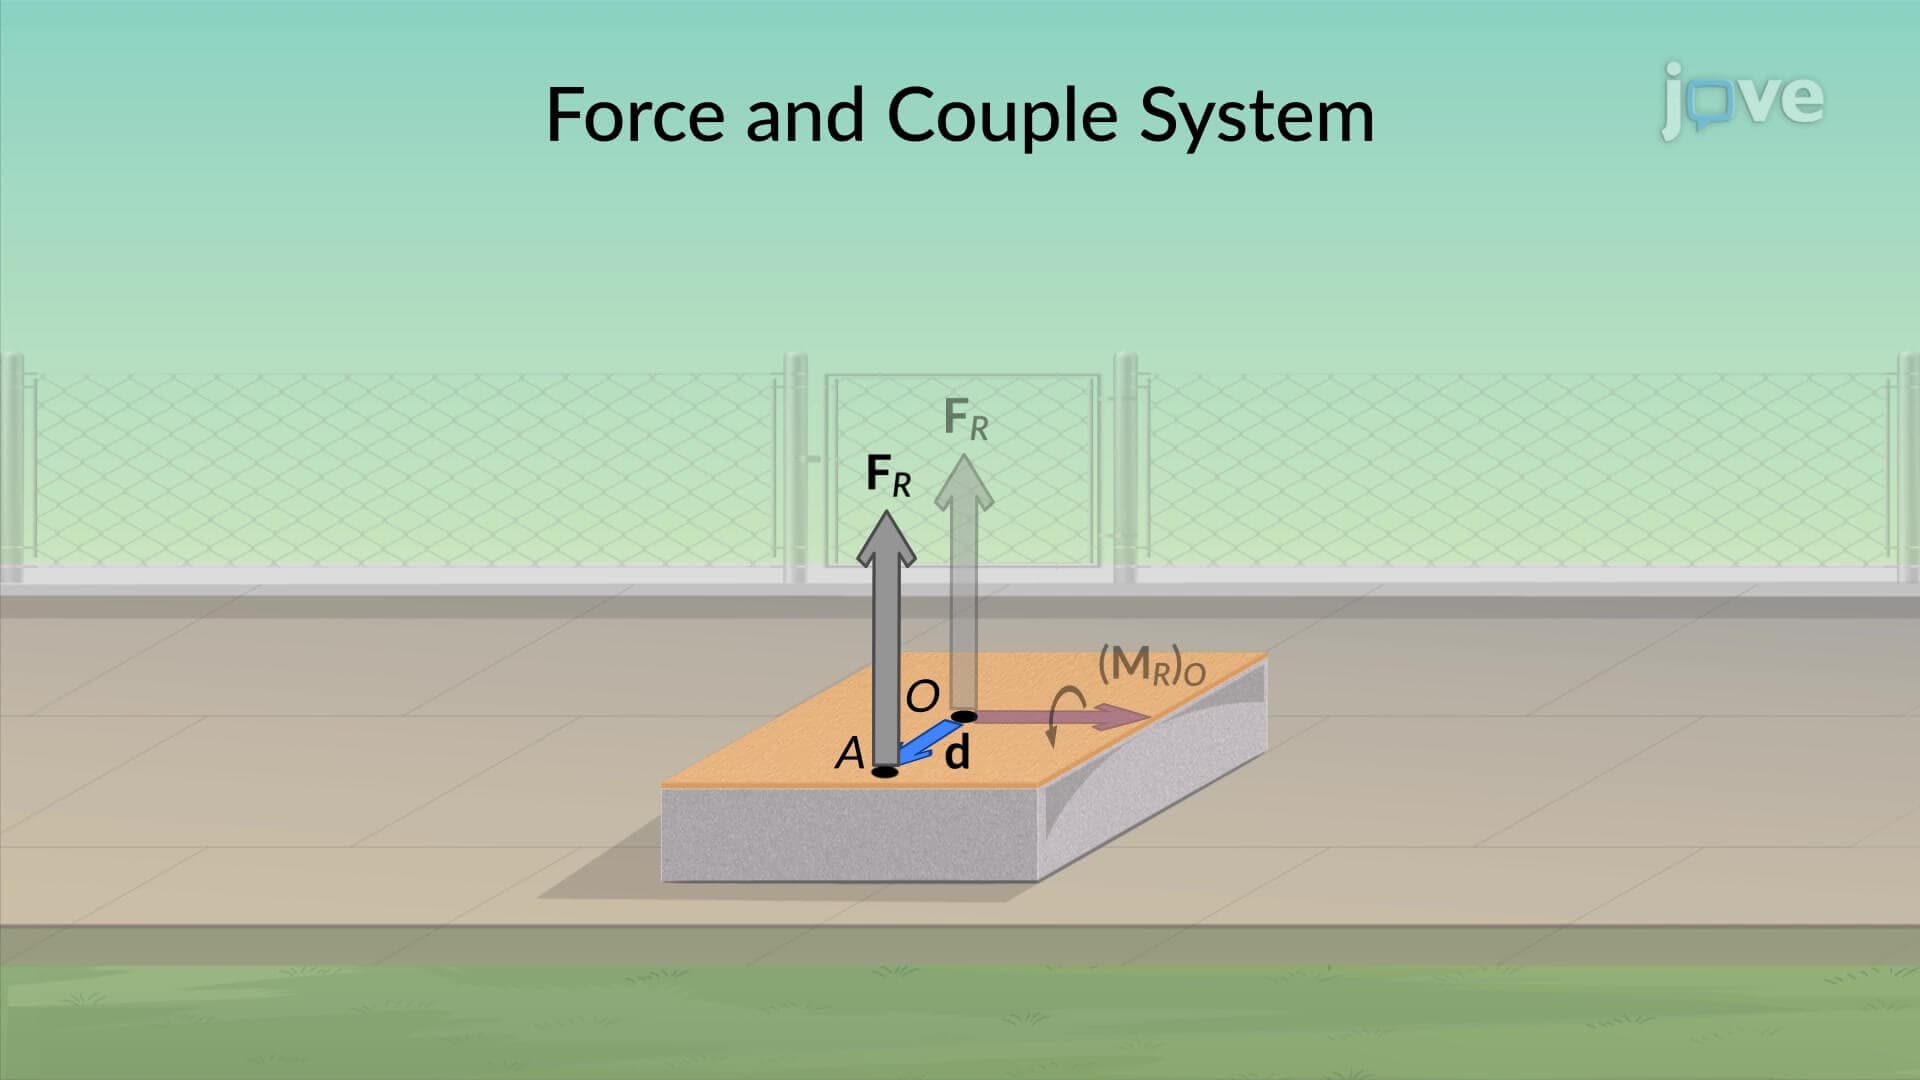
Simplification of a Force and Couple System I