Related Experiment Video
Updated: Dec 31, 2025

Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Performance Evaluation of a Robot-Mounted Interferometer for an Industrial Environment
1Electrical and Manufacturing Engineering, Intelligent Automation Centre, Wolfson School of Mechanical, Loughborough University, Loughborough LE11 3TU, UK.

Abstract:
High value manufacturing requires production-integrated, fast, multi-sensor and multi-scale inspection. To meet this need, the robotic deployment of sensors within the factory environment is becoming increasingly popular. For microscale measurement applications, robot-mountable versions of high-resolution instruments, that are traditionally deployed in a laboratory environment, are now becoming available. However, standard methodologies for the evaluation of these instruments, particularly when mounted to a robot, have yet to be fully defined, and therefore, there is limited independent evaluation data to describe the potential performance of these systems. In this paper, a detailed evaluation approach is presented for light-weight robot mountable scanning interferometric sensors. Traditional evaluation approaches are considered and extended to account for robotic sensor deployment within industrial environments. The applicability and value of proposed evaluation is demonstrated through the comprehensive characterization of a Heliotis H6 interferometric sensors. The results indicate the performance of the sensor, in comparison to a traditional laboratory-based system, and demonstrate the limits of the sensor capability. Based-on the evaluation an effective strategy for robotic deployment of the sensor is demonstrated.
More Related Videos
 08:40
Isokinetic Robotic Device to Improve Test-Retest and Inter-Rater Reliability for Stretch Reflex Measurements in Stroke Patients with Spasticity
Published on: June 12, 2019
 11:53
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Related Concept Videos
 01:30
Electronic Distance Measuring Instruments
 01:14
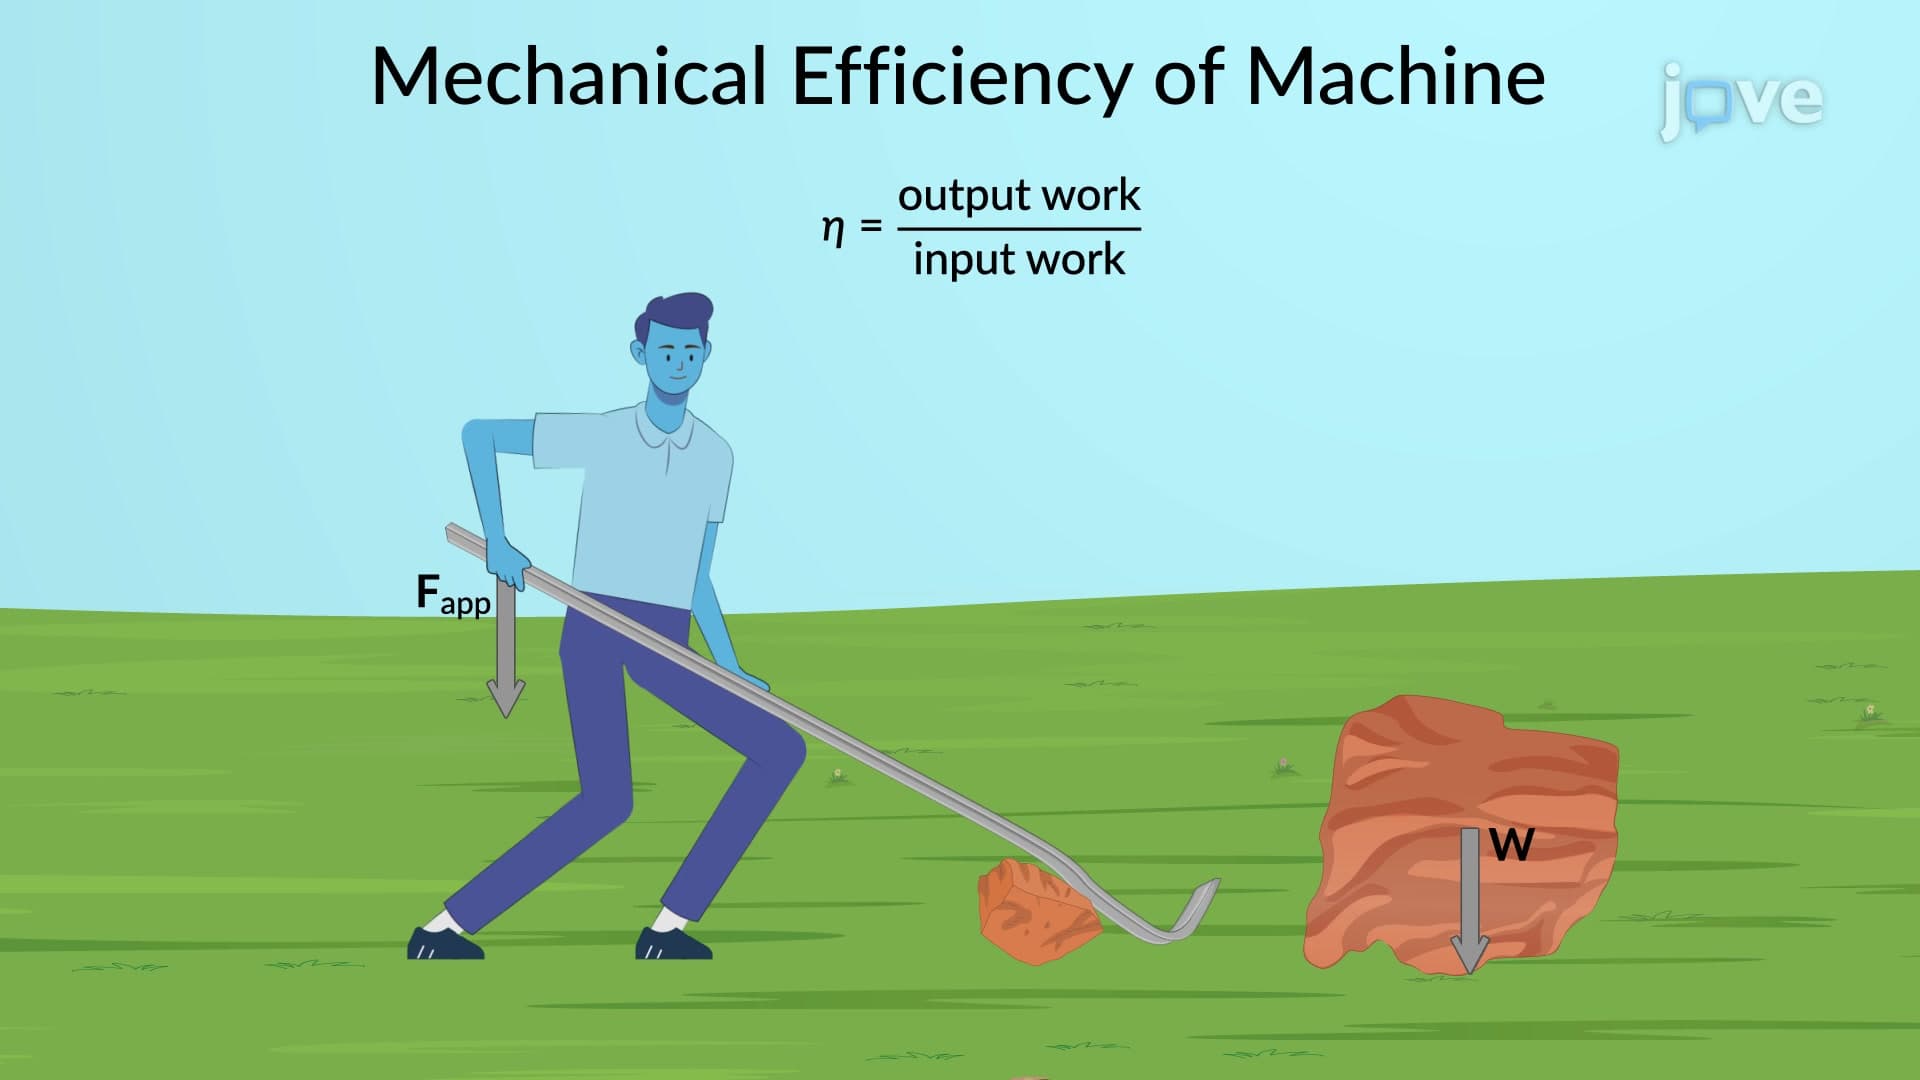
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...