Related Experiment Video
Updated: Dec 31, 2025
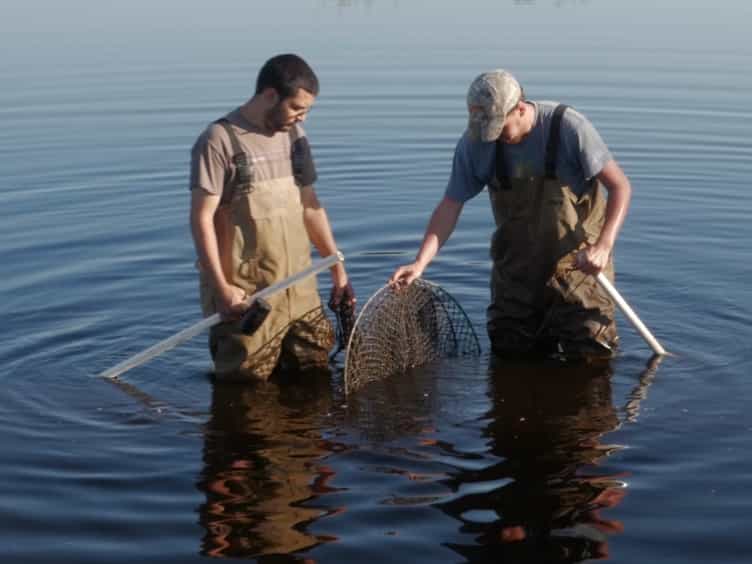

Using Pharmacological Manipulation and High-precision Radio Telemetry to Study the Spatial Cognition in Free-ranging Animals
Published on: November 6, 2016
Learning from animals: How to Navigate Complex Terrains
Henghui Zhu1, Hao Liu2, Armin Ataei1
1Center for Information and Systems Engineering, Boston University, Boston, Massachusetts, United States of America.

Abstract:
We develop a method to learn a bio-inspired motion control policy using data collected from hawkmoths navigating in a virtual forest. A Markov Decision Process (MDP) framework is introduced to model the dynamics of moths and sparse logistic regression is used to learn control policy parameters from the data. The results show that moths do not favor detailed obstacle location information in navigation, but rely heavily on optical flow. Using the policy learned from the moth data as a starting point, we propose an actor-critic learning algorithm to refine policy parameters and obtain a policy that can be used by an autonomous aerial vehicle operating in a cluttered environment. Compared with the moths' policy, the policy we obtain integrates both obstacle location and optical flow. We compare the performance of these two policies in terms of their ability to navigate in artificial forest areas. While the optimized policy can adjust its parameters to outperform the moth's policy in each different terrain, the moth's policy exhibits a high level of robustness across terrains.
More Related Videos
Related Concept Videos
 01:12
Observational Learning
 01:17
Rolling Resistance: Problem Solving
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...