Related Experiment Video
Updated: Dec 30, 2025


Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
An Implicit Function-Based Adaptive Control Scheme for Noncanonical-Form Discrete-Time Neural-Network Systems

Abstract:
This article proposes a new implicit function-based adaptive control scheme for the discrete-time neural-network systems in a general noncanonical form. Feedback linearization for such systems leads to the output dynamics nonlinear dependence on the system states, the control input, and uncertain parameters, which leads to the nonlinear parametrization problem, the implicit relative degree problem, and the difficulty to specify an analytical adaptive controller. To address these problems, we first develop a new adaptive parameter estimation strategy to deal with all uncertain parameters, especially, those of nonlinearly parameterized forms, in the output dynamics. Then, we construct a key implicit function equation using available signals and parameter estimates. By solving the equation, a unique adaptive control law is derived to ensure asymptotic output tracking and closed-loop stability. Alternatively, we design an iterative solution-based adaptive control law which is easy to implement and ensure output tracking and closed-loop stability. The simulation study is given to demonstrate the design procedure and verify the effectiveness of the proposed adaptive control scheme.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Related Concept Videos
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
PI Controller: Design
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:21
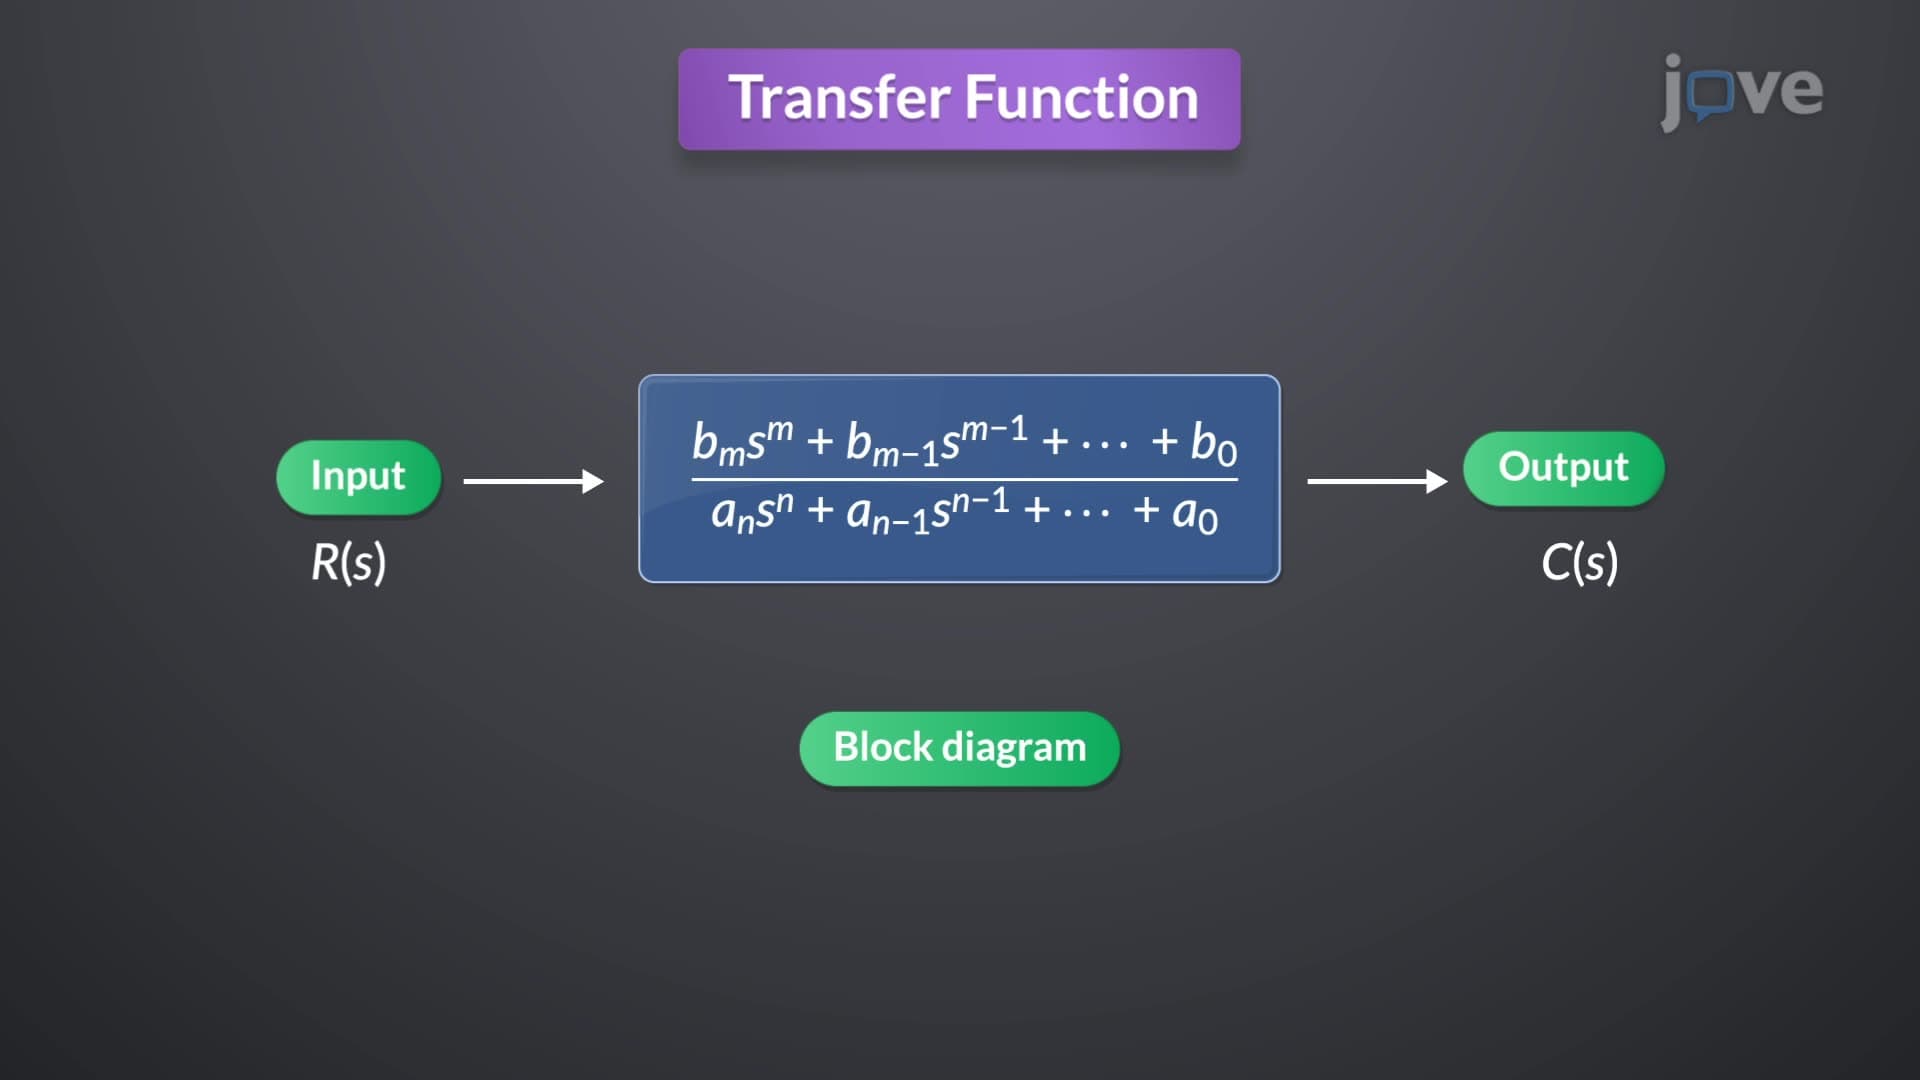
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:21
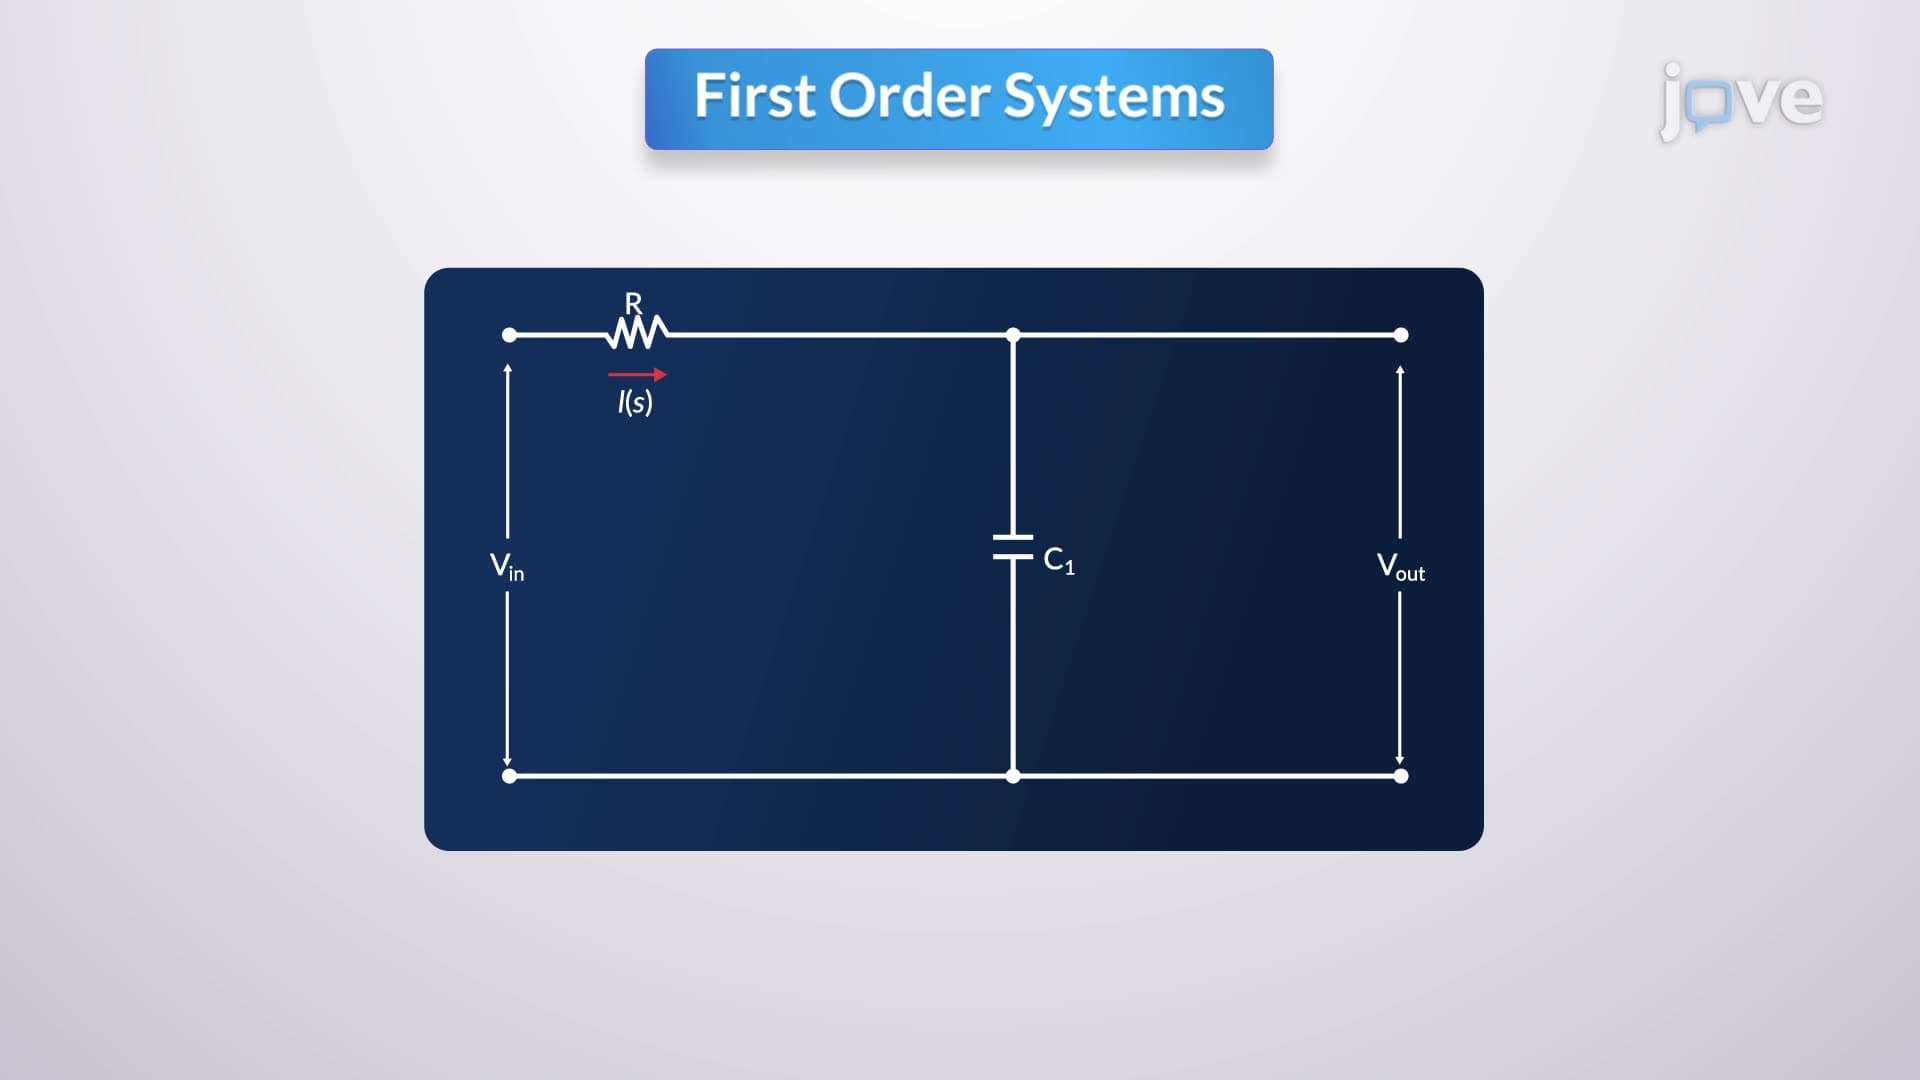
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...