Related Experiment Video
Updated: Dec 30, 2025


Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
Development of Cybernic Robot Arm to realize Support Action cooperated with Hemiplegic Person's Arm

Abstract:
Hemiplegics have difficulty conducting various daily tasks because they must perform such tasks using only their unaffected arm. If a robot arm that can replace their missing upper-limb function is made available, it will greatly contribute to an improvement in their lives. To realize such a robot arm, cooperative actions of the robot arm and the unaffected arm are important. The purpose of this research is to develop a "cybernic robot arm" that can provide work support through cooperation with the unaffected arm for realization of upper-limb tasks in the daily life of hemiplegics. The developed system can detect the external force applied to a gripped object using a tactile force sensor embedded in the robot fingers. The system estimates the motion of the unaffected arm and the user's intention regarding its operation based on the external force, and provides a support action in cooperation with the unaffected arm based on the estimated information. In addition, to confirm the applicability of the developed system, we developed a support function for opening tasks that are difficult for hemiplegics to carry out on their own, and conducted an experiment confirming the applicability of the system. The results confirm that the proposed system provides proper support by cooperating with the user's arm, allowing an opening task to be performed. The developed system will support various upper-limb tasks that are difficult for hemiplegics.
More Related Videos
 03:55
Author Spotlight: Enhancing Grasping Abilities for Hemiplegic Patients with Flexible Robotic Limbs
Published on: October 27, 2023
 05:28
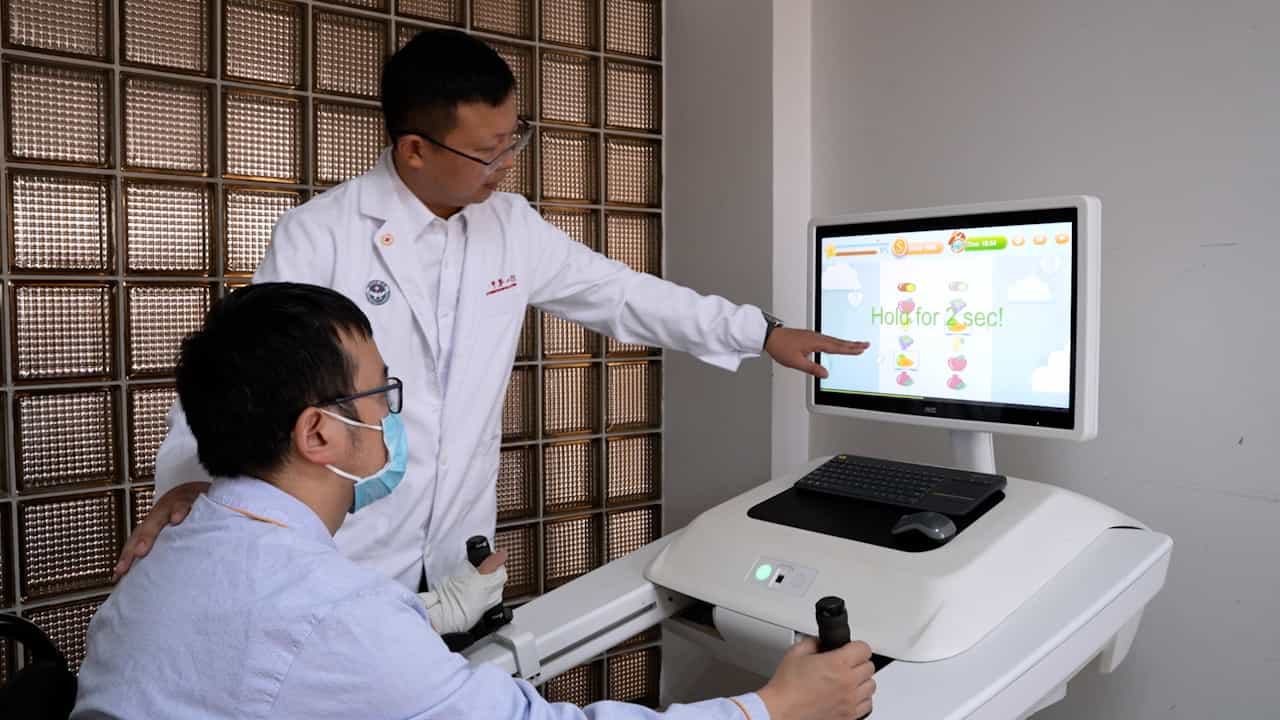
Author Spotlight: Enhancing Upper Limb Rehabilitation in Stroke Patients Through Advanced Robotic and Neuromodulation Technologies
Published on: October 11, 2024