

Integral terminal sliding mode control unified with UDE for output constrained tracking of mismatched uncertain
Deepika Deepika1, Sandeep Kaur1, Shiv Narayan1
1Department of Electrical Engineering, Punjab Engineering College, Chandigarh, India.

Abstract:
This paper presents a novel integral terminal sliding mode control (ITSMC) algorithm compounded with Barrier Lyapunov's Function (BLF) for high precision output tracking objective of uncertain N-dimensional strict feedback class of non-linear systems subjected to non-infringement of system output constraint. Besides, the proposed algorithm also employs uncertainty and disturbance estimator (UDE) technique for abating the existence of unknown mismatched and matched uncertainties. Most of the preliminary SMC schemes encompass the UDE technique to cope with unknown matched uncertainties only. However, the presented method embodies the dynamic surface control (DSC) architecture to get rid of the matching architectural constraint in UDE approach as well as 'complexity explosion' concern in backstepping approach. Additionally, the introduced method also applies the notion of symmetric BLF to enforce strict bounds on output tracking deviation from its reference value. To emphasize on the strengths of devised methodology, two examples are simulated by comparing the derived outcomes with already existing techniques in literature.
More Related Videos
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Transfer Function in Control Systems
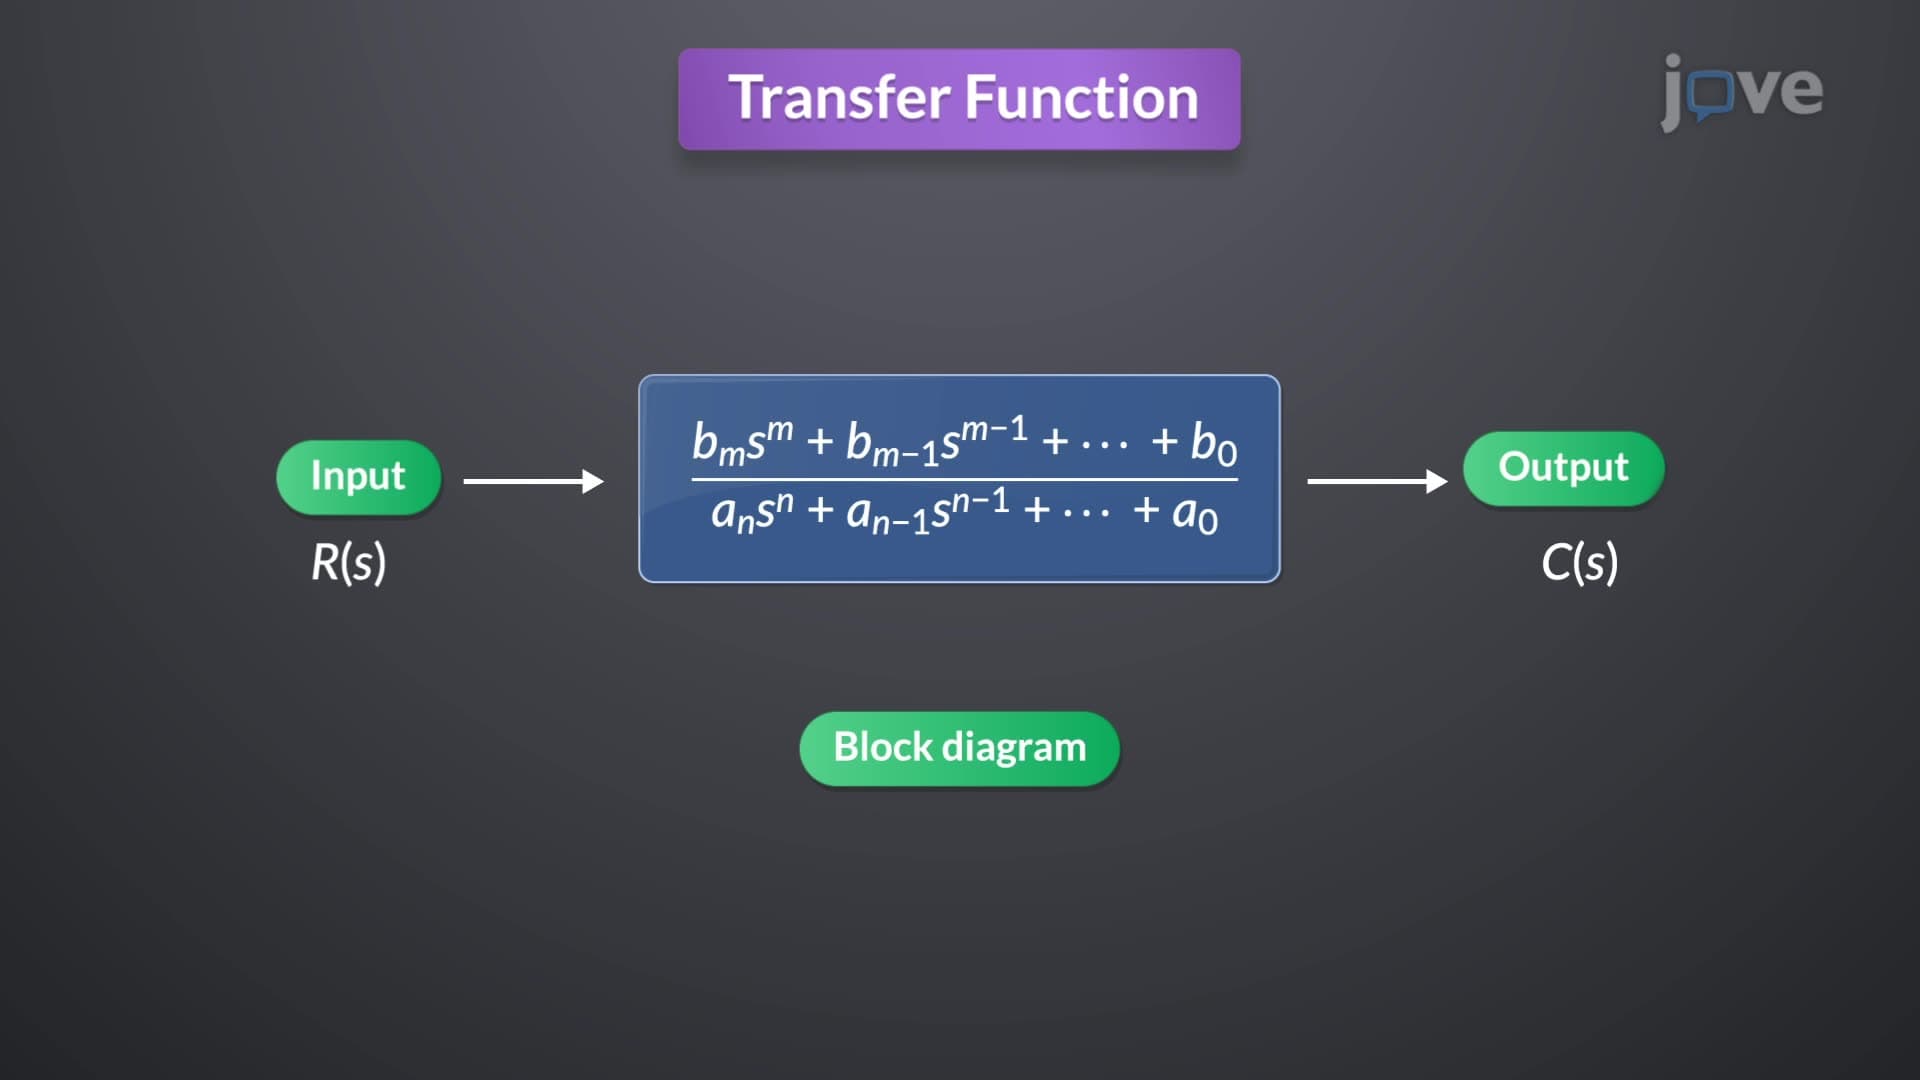
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:10
Control Systems
At the heart...