Related Experiment Video
Updated: Dec 30, 2025


Studying the Neural Basis of Adaptive Locomotor Behavior in Insects
Published on: April 13, 2011
Anticipatory Control of Momentum for Bipedal Walking on Uneven Terrain
Osman Darici1,2, Hakan Temeltas3, Arthur D Kuo4,5
1Faculty of Kinesiology, University of Calgary, Calgary, Alberta, Canada. osman.darici1@ucalgary.ca.

Abstract:
Humans and other walking bipeds often encounter and compensate for uneven terrain. They might, for example, regulate the body's momentum when stepping on stones to cross a stream. We examined what to do and how far to look, as a simple optimal control problem, where forward momentum is controlled to compensate for a step change in terrain height, and steady gait regained with no loss of time relative to nominal walking. We modeled planar, human-like walking with pendulum-like legs, and found the most economical control to be quite stereotypical. It starts by gaining momentum several footfalls ahead of an upward step, in anticipation of the momentum lost atop that step, and then ends with another speed-up to regain momentum thereafter. A similar pattern can be scaled to a variety of conditions, including both upward or downward steps, yet allow for considerably reduced overall energy and peak power demands, compared to compensation without anticipation. We define a "persistence time" metric from the transient decay response after a disturbance, to describe how momentum is retained between steps, and how far ahead a disturbance should be planned for. Anticipatory control of momentum can help to economically negotiate uneven terrain.


Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:13
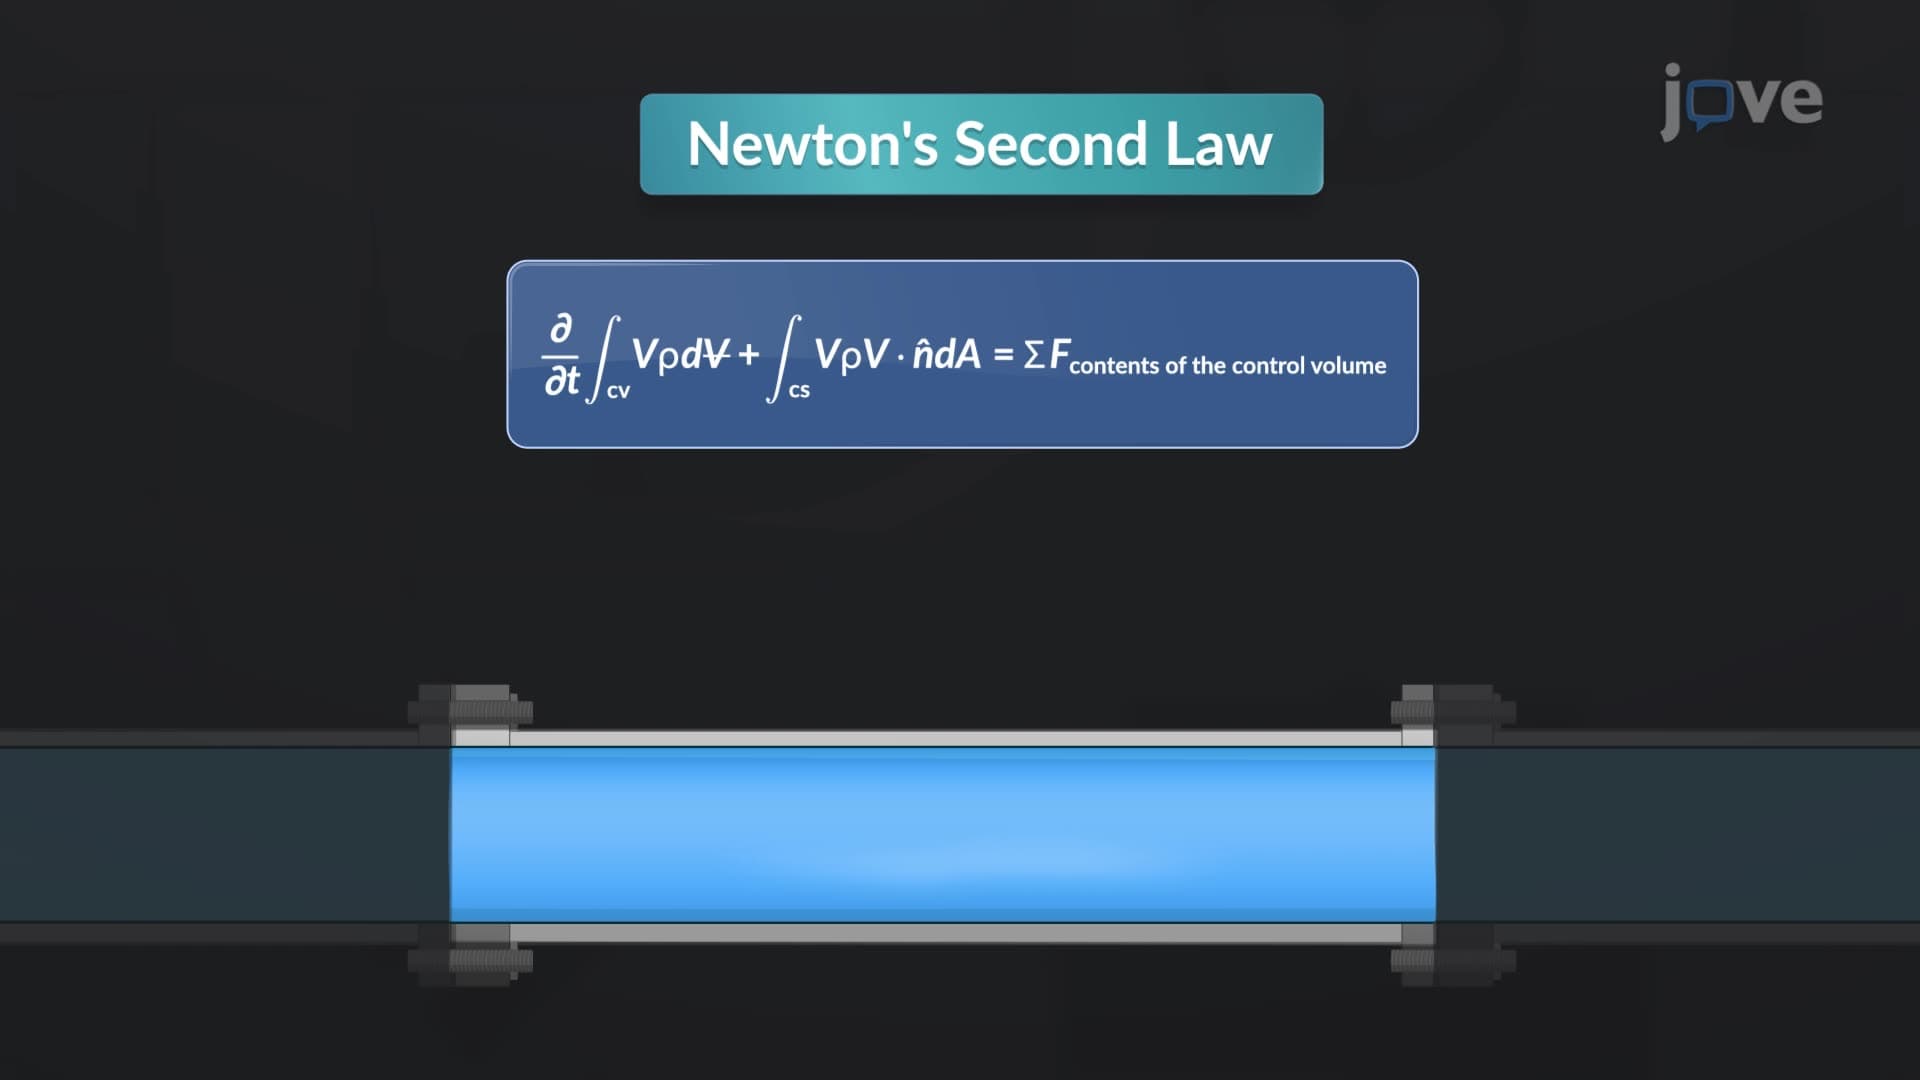
Linear Momentum in Control Volume
 01:28
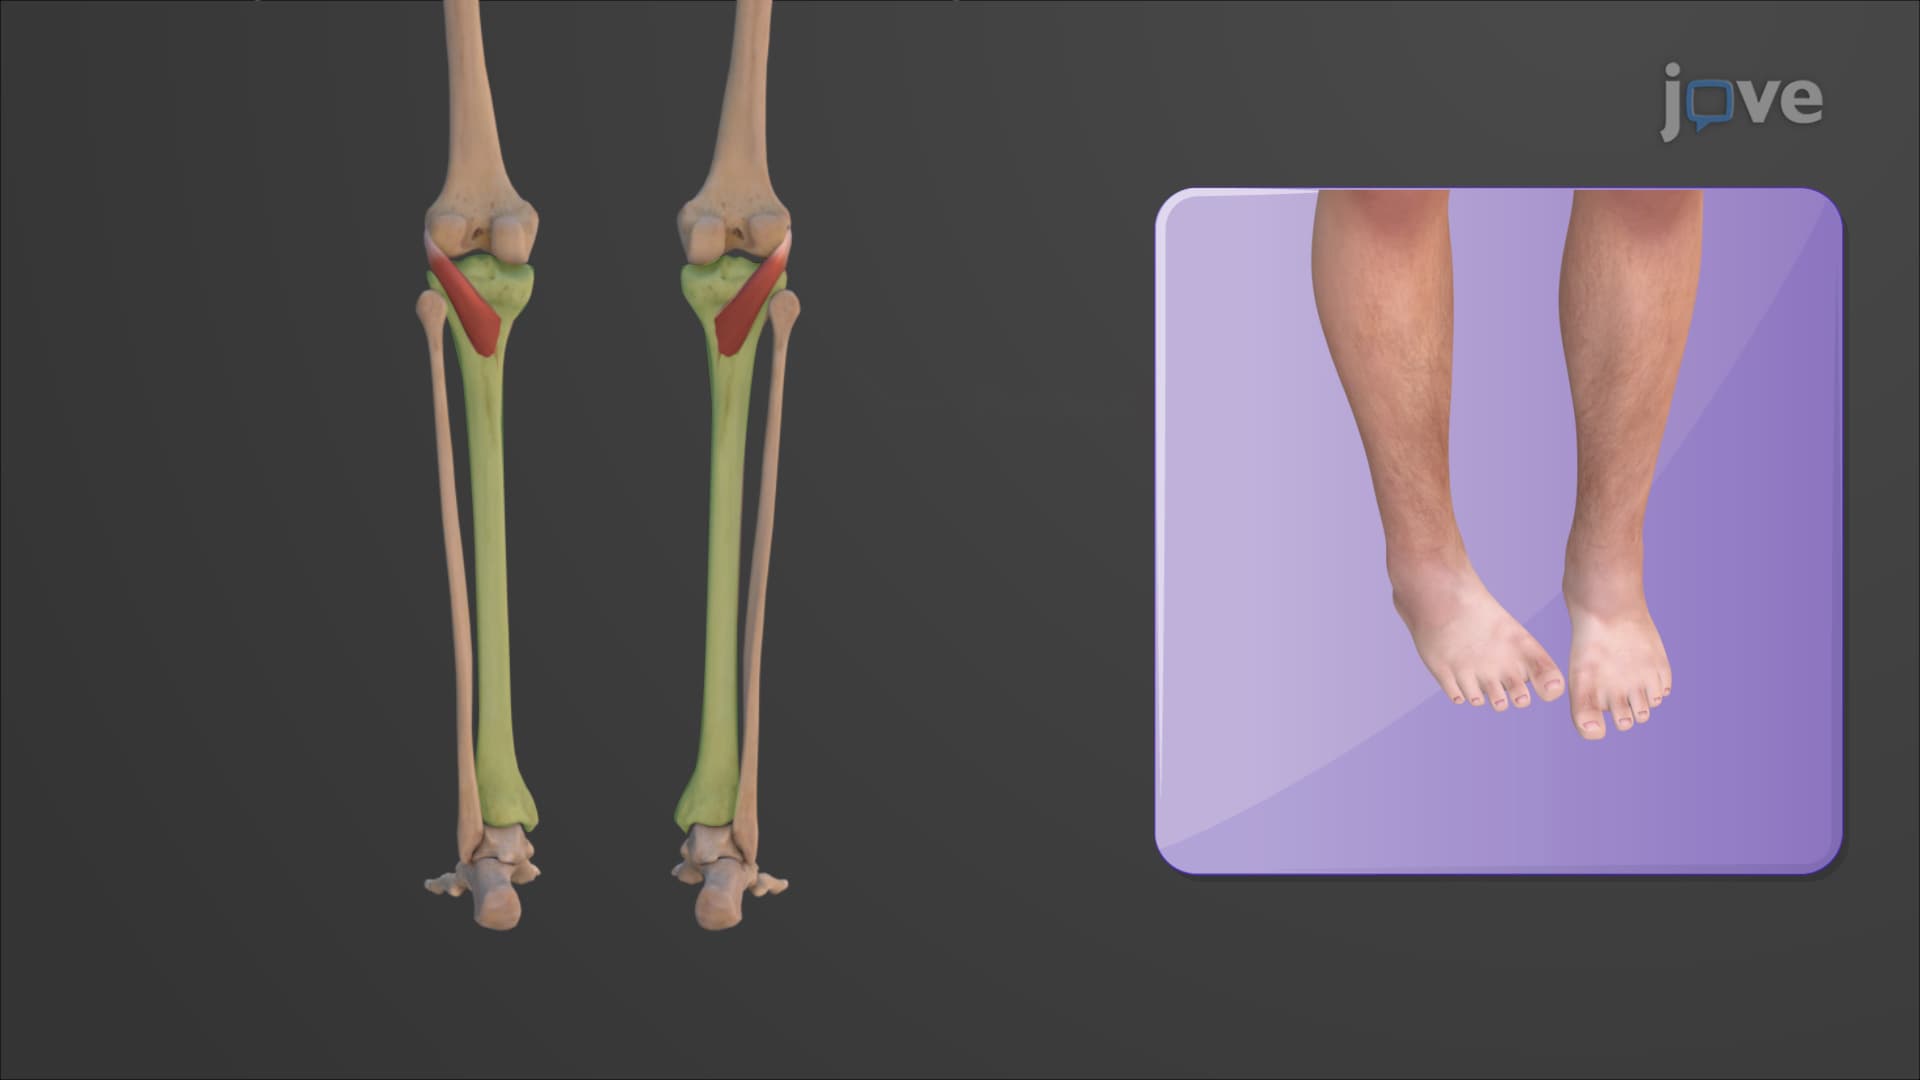
Muscles of the Leg that Move the Foot and Toes
Anterior Compartment
The anterior compartment includes muscles that contribute to the dorsiflexion of the foot. This compartment houses the tibialis anterior, extensor hallucis longus, and extensor digitorum longus muscles....