A Non-Linear Differentiable CNN-Rendering Module for 3D Data Enhancement
Related Experiment Video
Updated: Dec 30, 2025

Author Spotlight: Enhancement of Salient Object Detection for Smart Grid Applications
Published on: December 15, 2023

Abstract:
In this article we introduce a differentiable rendering module which allows neural networks to efficiently process 3D data. The module is composed of continuous piecewise differentiable functions defined as a sensor array of cells embedded in 3D space. Our module is learnable and can be easily integrated into neural networks allowing to optimize data rendering towards specific learning tasks using gradient based methods in an end-to-end fashion. Essentially, the module's sensor cells are allowed to transform independently and locally focus and sense different parts of the 3D data. Thus, through their optimization process, cells learn to focus on important parts of the data, bypassing occlusions, clutter, and noise. Since sensor cells originally lie on a grid, this equals to a highly non-linear rendering of the scene into a 2D image. Our module performs especially well in presence of clutter and occlusions as well as dealing with non-linear deformations to improve classification accuracy through proper rendering of the data. In our experiments, we apply our module in various learning tasks and demonstrate that using our rendering module we accomplish efficient classification, localization, and segmentation tasks on 2D/3D cluttered and non-cluttered data.
Related Concept Videos
 01:18
Reducing Line Loss
With a step-up transformer at the source, the voltage is increased, thereby reducing the current in the transmission lines since power loss in...
 01:24
Convolution: Math, Graphics, and Discrete Signals
To simplify the convolution integral, it is assumed that both the input signal and impulse response are zero for negative time values. The graphical convolution process...
 01:20
Deconvolution
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:27
Curvilinear Motion: Normal and Tangential Components
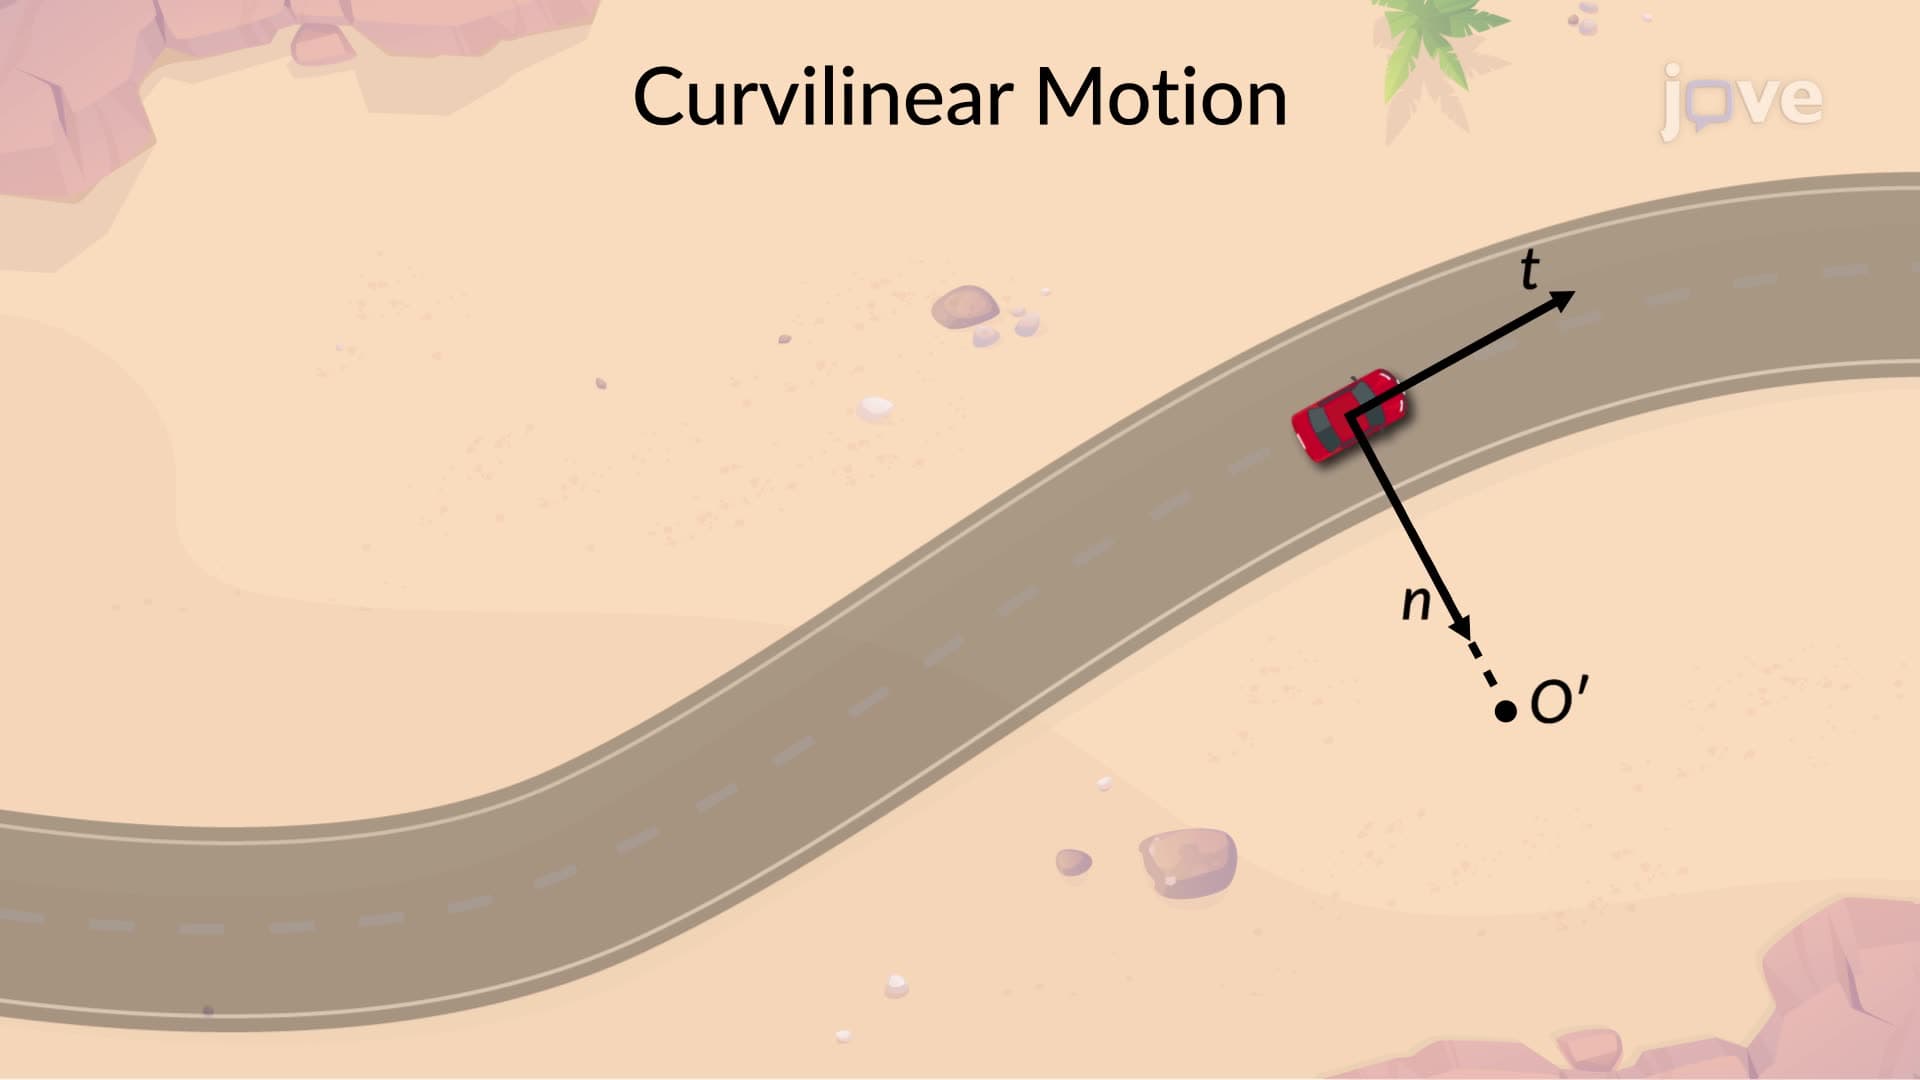
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 02:06
Newman Projections
The organic molecules rotate across the single bonds leading to numerous temporary three-dimensional structures of varying energy known as...