Related Experiment Video
Updated: Dec 29, 2025
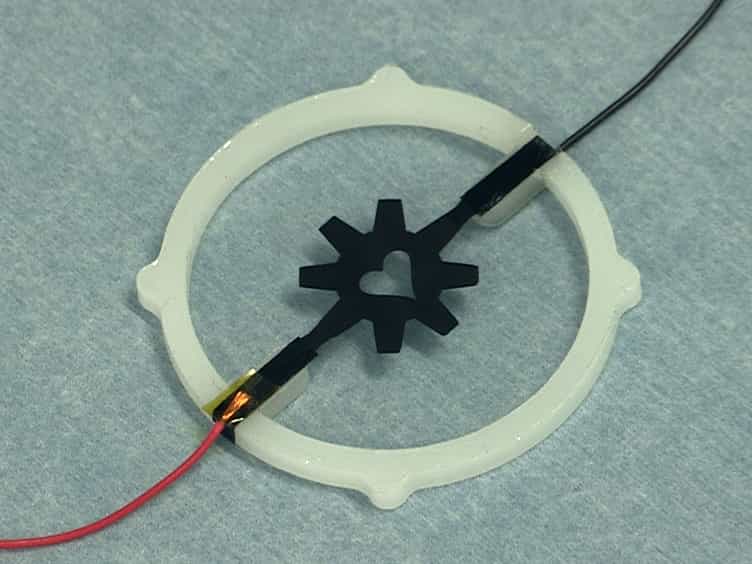
Fabrication Process of Silicone-based Dielectric Elastomer Actuators
Published on: February 1, 2016
A Super-Lightweight and Soft Manipulator Driven by Dielectric Elastomers
Zhiguang Xing1, Junming Zhang1, David McCoul2
1Department of Mechanical Engineering, Harbin Institute of Technology, Weihai, China.

Abstract:
Some applications are very sensitive to the weight of the robot, such as space manipulation or any untethered mobile manipulation. In this article, we designed a five-module unilaterally bending serial manipulator with length of 32 cm and a weight of only 18 g. The manipulator is driven by dielectric elastomer actuators (DEAs). Each module consists of a spatially closed tubular structure, which has the capability of large deformation while simultaneously maintaining torsional rigidity. The design is based on the buckling of columns. To achieve global deformation continuously, each module was controlled independently by a multichannel high-voltage power supply. As a demo, the manipulator was able to enter and exit a narrow L-shaped pipe. Experiments demonstrate that the manipulator driven by spatial DEAs can be super lightweight and can realize large continuous deformation.


