Related Experiment Video
Updated: Dec 29, 2025
Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
Cooperative Dynamic Manipulation of Unknown Flexible Objects: Joint Energy Injection Based on Simple Pendulum
Philine Donner1,2, Franz Christange3, Jing Lu1
11Department of Electrical and Computer Engineering, Chair of Automatic Control Engineering (LSR), Technical University of Munich, Munich, Germany.

Abstract:
Cooperative dynamic manipulation enlarges the manipulation repertoire of human-robot teams. By means of synchronized swinging motion, a human and a robot can continuously inject energy into a bulky and flexible object in order to place it onto an elevated location and outside the partners' workspace. Here, we design leader and follower controllers based on the fundamental dynamics of simple pendulums and show that these controllers can regulate the swing energy contained in unknown objects. We consider a complex pendulum-like object controlled via acceleration, and an "arm-flexible object-arm" system controlled via shoulder torque. The derived fundamental dynamics of the desired closed-loop simple pendulum behavior are similar for both systems. We limit the information available to the robotic agent about the state of the object and the partner's intention to the forces measured at its interaction point. In contrast to a leader, a follower does not know the desired energy level and imitates the leader's energy flow to actively contribute to the task. Experiments with a robotic manipulator and real objects show the efficacy of our approach for human-robot dynamic cooperative object manipulation.


Related Concept Videos
 01:13
Kinetic Energy for a Rigid Body
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
Rigid Body Equilibrium Problems - I
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
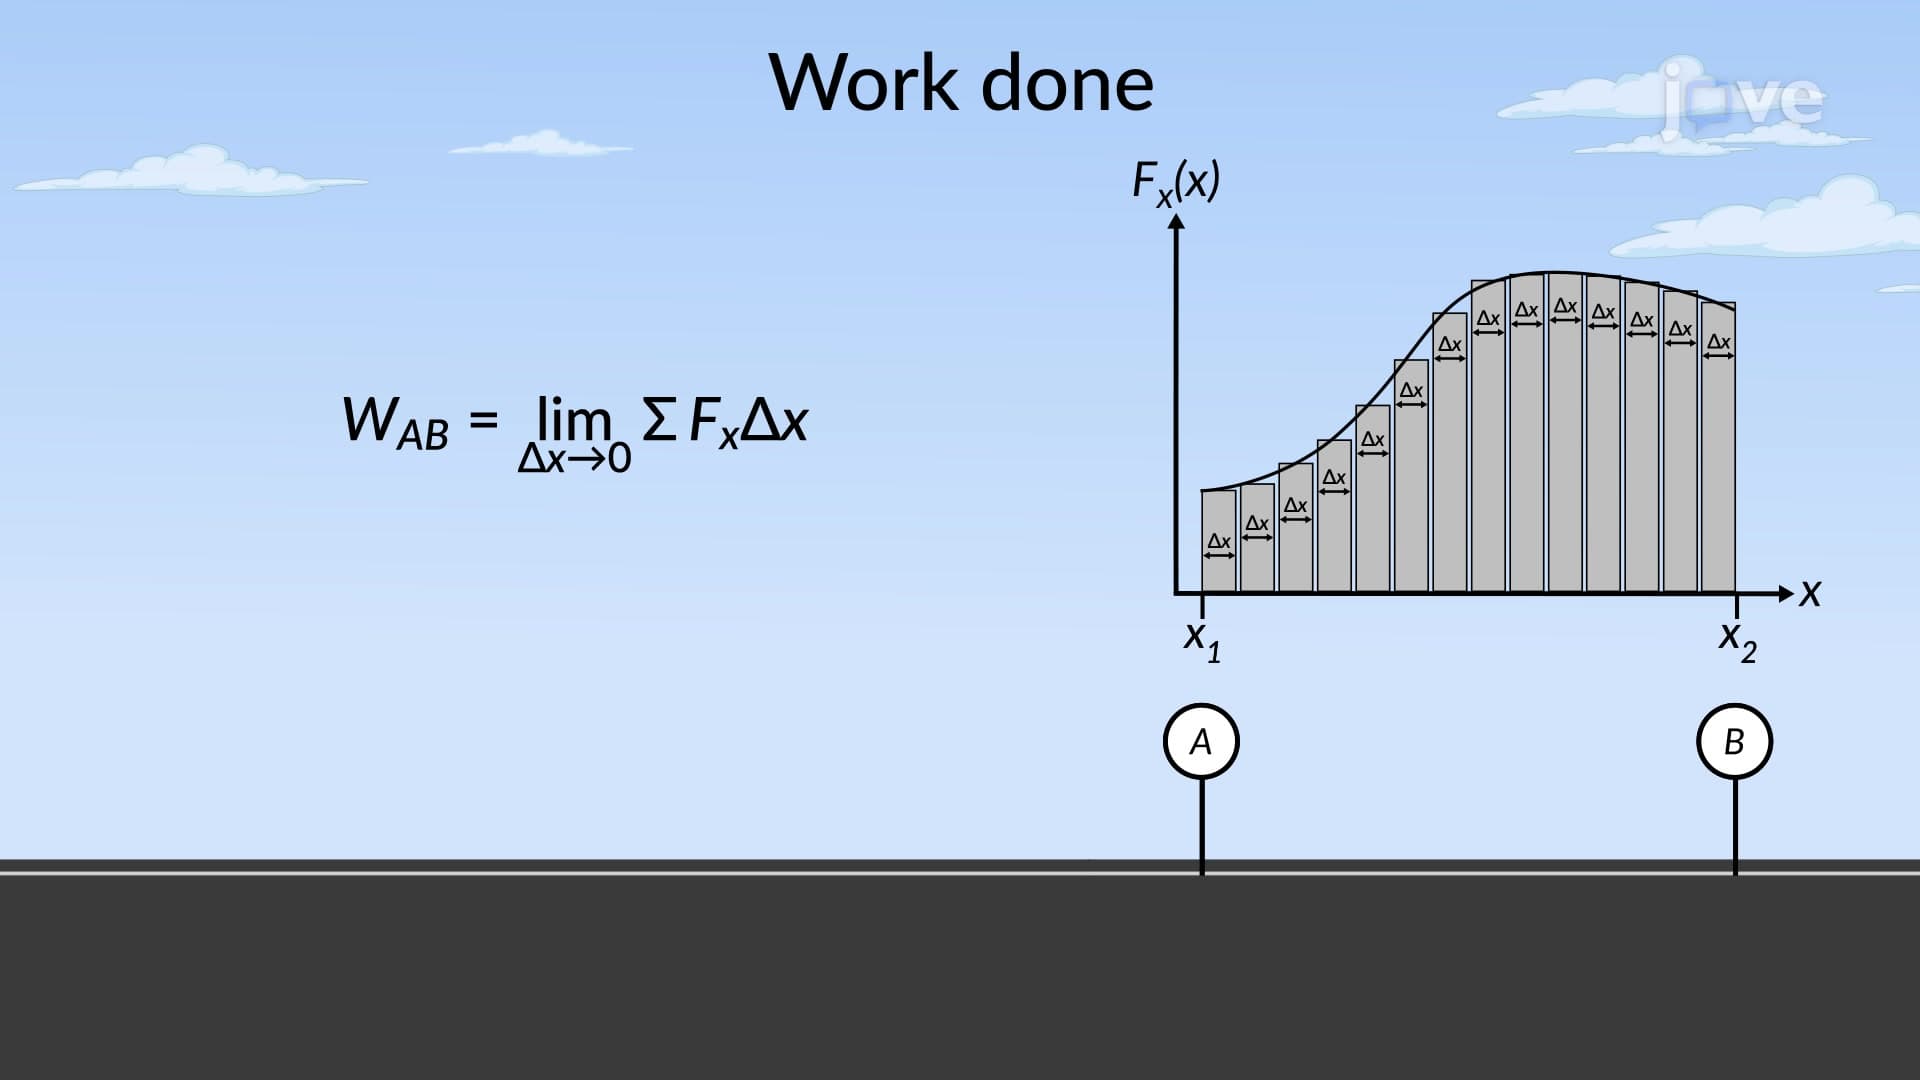 01:10
Work and Energy for Variable Forces
 01:15
Kinematic Equations: Problem Solving