Related Experiment Video
Updated: Dec 29, 2025
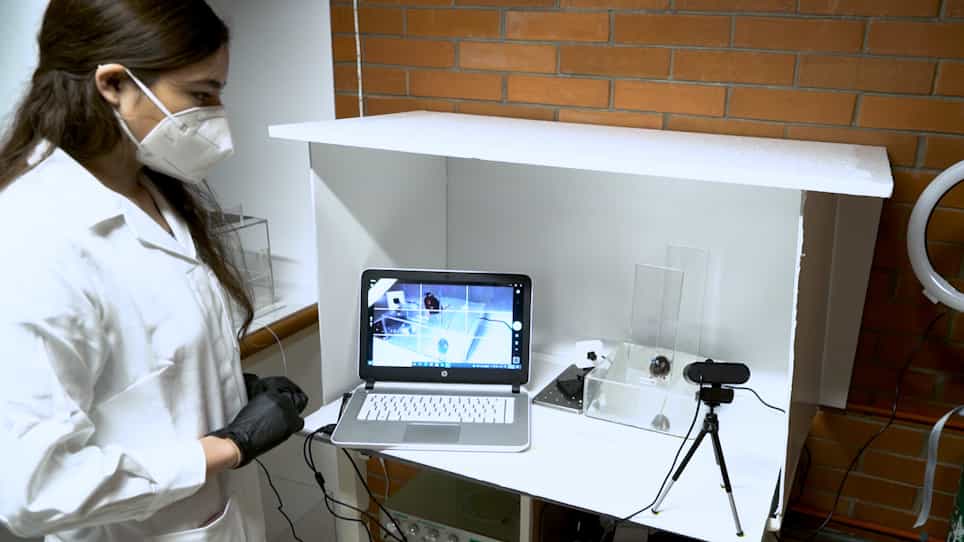

In Vivo Wireless Optogenetic Control of Skilled Motor Behavior
Published on: November 22, 2021
How does the CNS control arm reaching movements? Introducing a hierarchical nonlinear predictive control organization
Sedigheh Dehghani1, Fariba Bahrami1
1CIPCE, Human Motor Control and Computational Neuroscience Laboratory, School of ECE, College of Engineering, University of Tehran, Tehran, Iran.

Abstract:
In this study, we introduce a hierarchical and modular computational model to explain how the CNS (Central Nervous System) controls arm reaching movement (ARM) in the frontal plane and under different conditions. The proposed hierarchical organization was established at three levels: 1) motor planning, 2) command production, and 3) motor execution. Since in this work we are not discussing motion learning, no learning procedure was considered in the model. Previous models mainly assume that the motor planning level produces the desired trajectories of the joints and feeds it to the next level to be tracked. In the proposed model, the motion control is described based on a regulatory control policy, that is, the output of the motor planning level is a step function defining the initial and final desired position of the hand. For the command production level, a nonlinear predictive model was developed to explain how the time-invariant muscle synergies (MSs) are recruited. We used the same computational model to explain the arm reaching motion for a combined ARM task. The combined ARM is defined as two successive ARM such that it starts from point A and reaches to point C via point B. To develop the model, kinematic and kinetic data from six subjects were recorded and analyzed during ARM task performance. The subjects used a robotic manipulator while moving their hand in the frontal plane. The EMG data of 15 muscles were also recorded. The MSs used in the model were extracted from the recorded EMG data. The proposed model explains two aspects of the motor control system by a novel computational approach: 1) the CNS reduces the dimension of the control space using the notion of MSs and thereby, avoids immense computational loads; 2) at the level of motor planning, the CNS generates the desired position of the hand at the starting, via and the final points, and this amounts to a regulatory and non-tracking structure.


Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
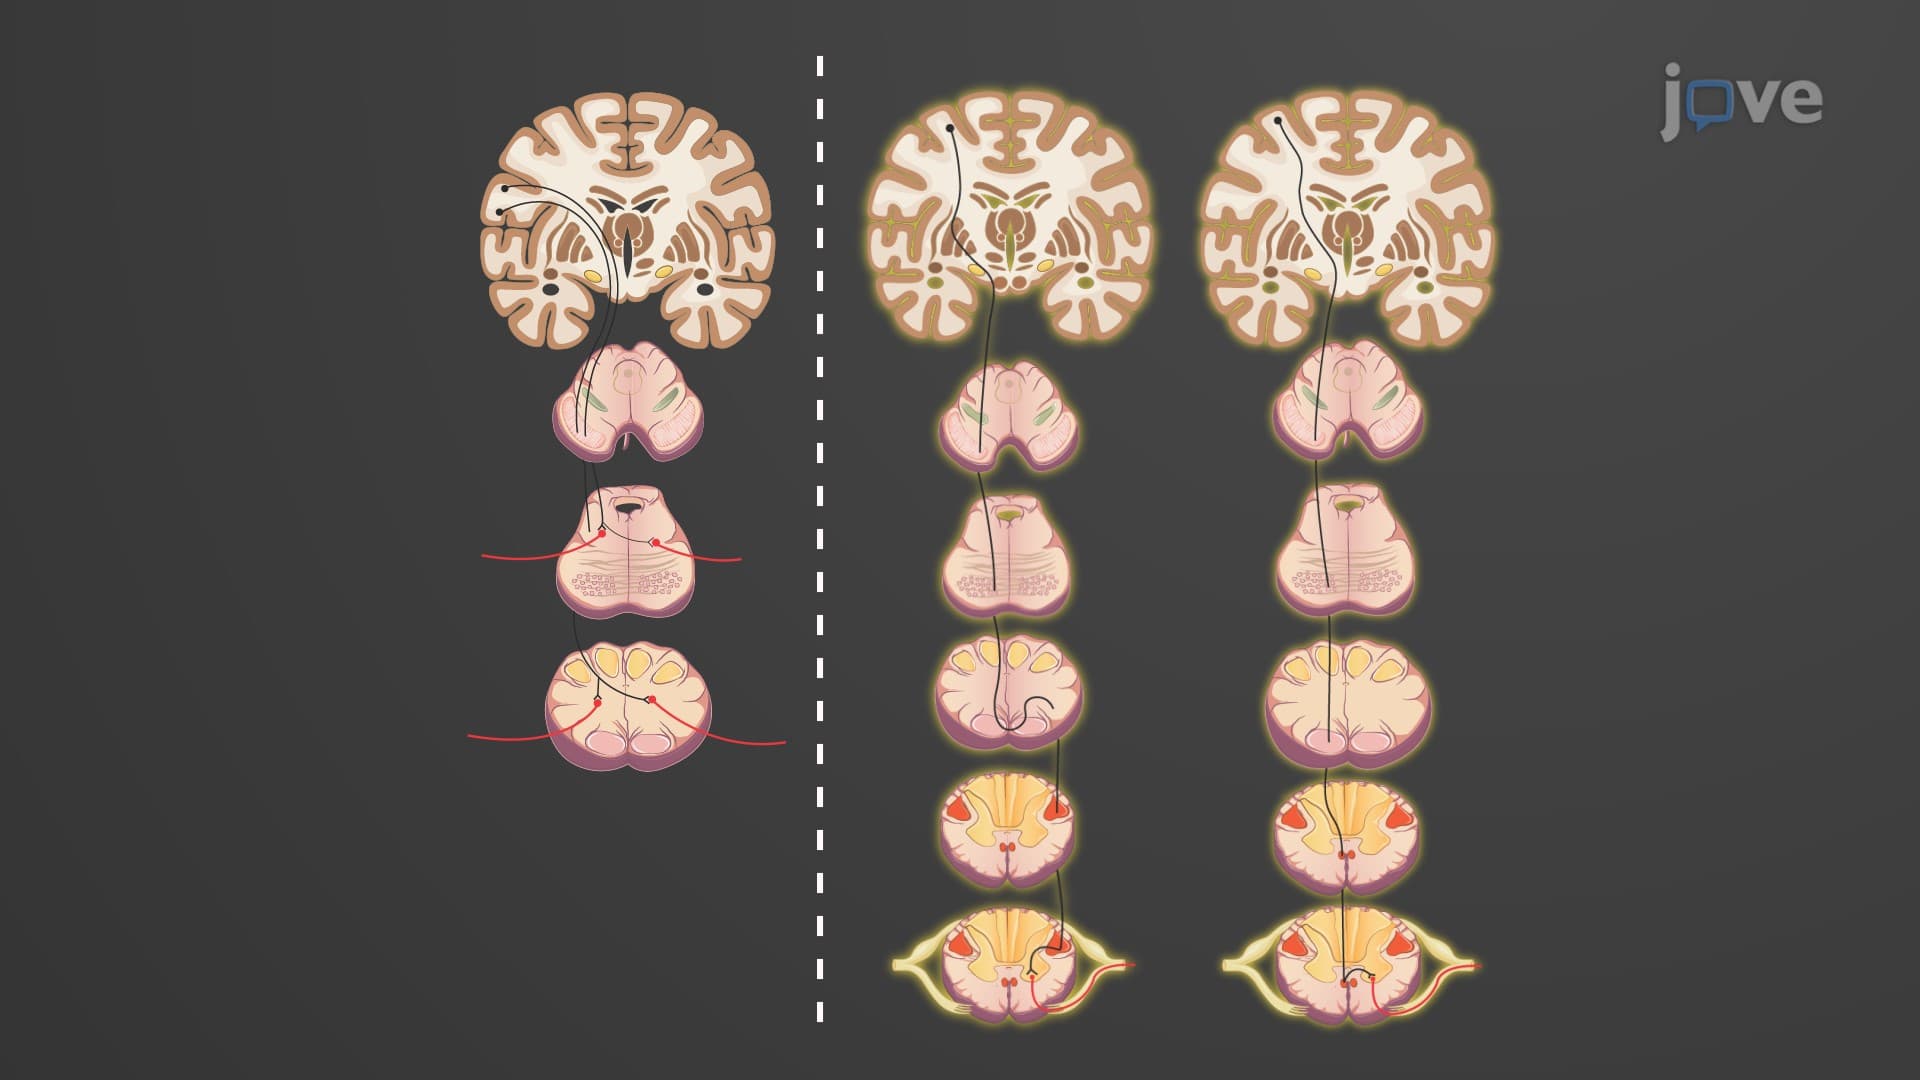 01:11
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...
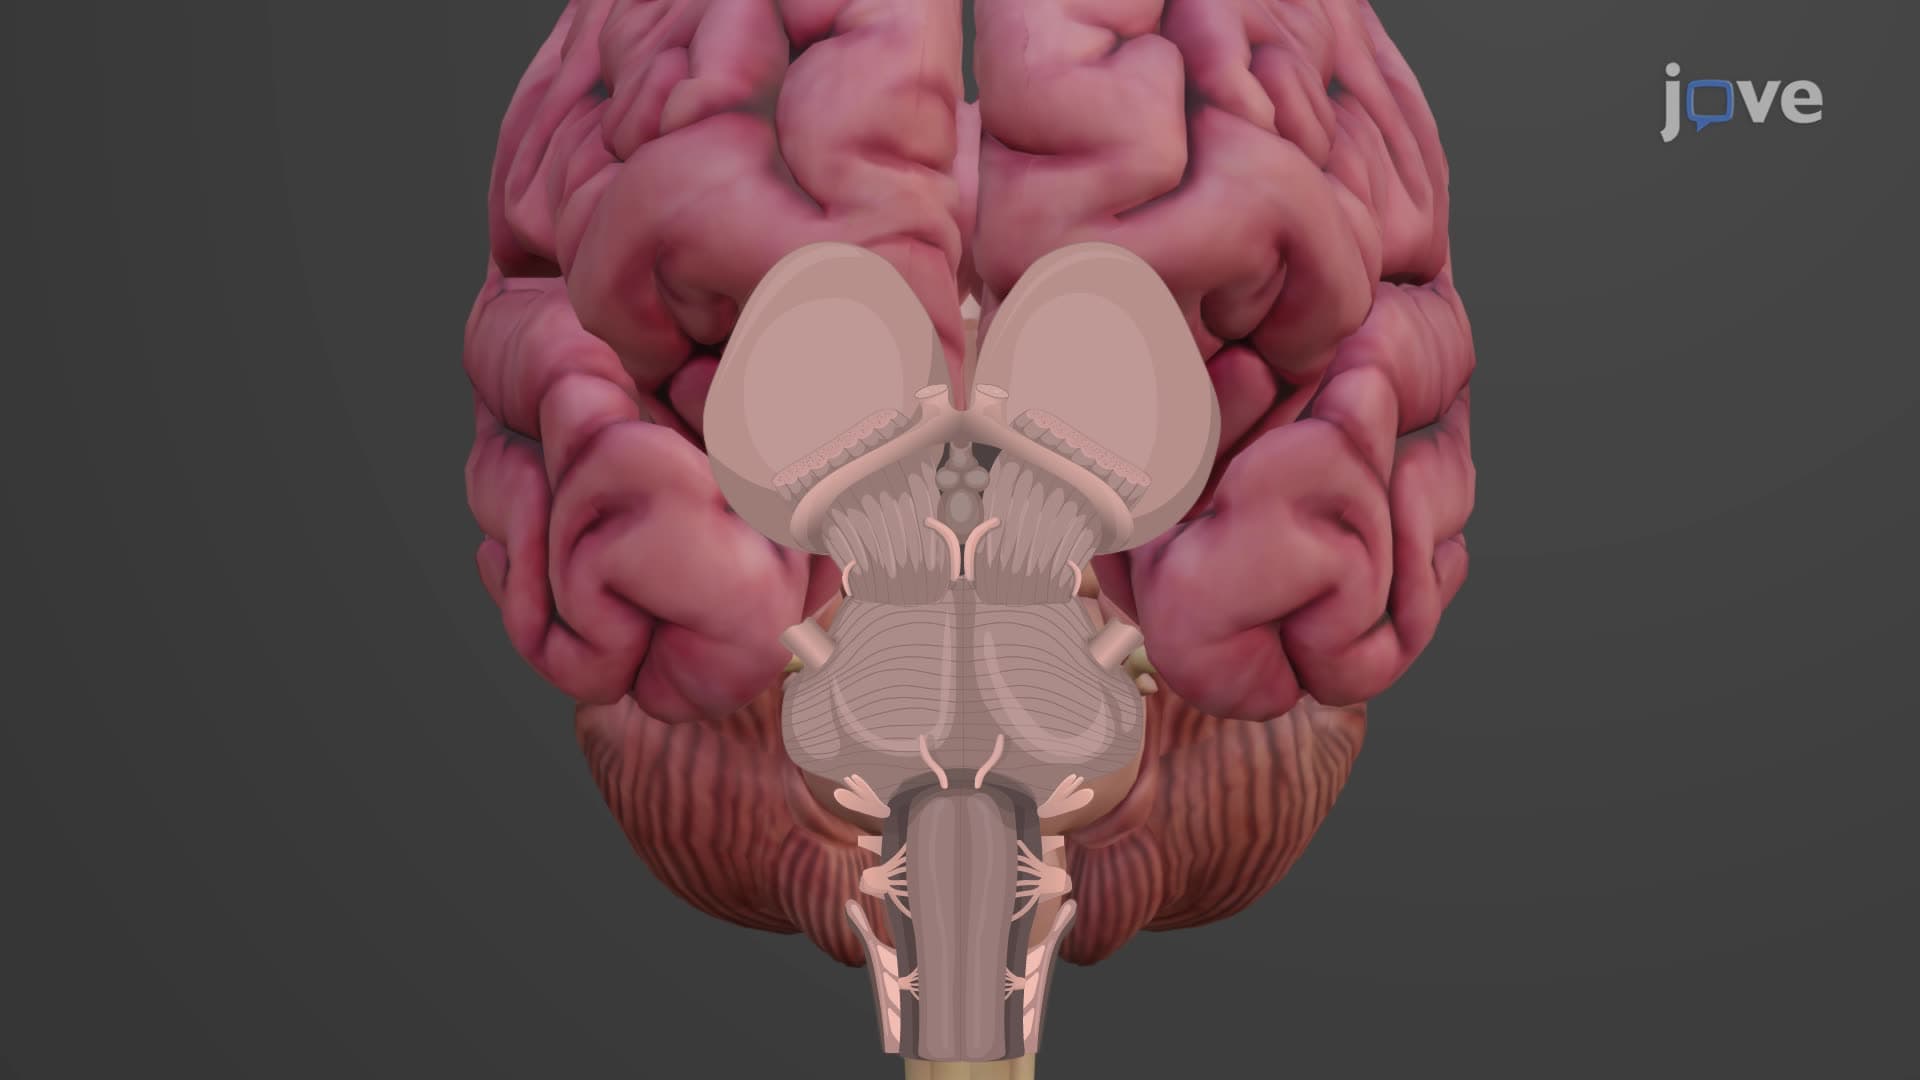 01:19
Brainstem
The Midbrain
The midbrain is located beneath the diencephalon and connects the cerebrum with the lower parts of the brain. The cerebral peduncles are prominent midbrain structures that house the...
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:13
Motor Units
Motor units come in different sizes, with smaller units...