Related Experiment Video
Updated: Dec 28, 2025


Author Spotlight: Enhancement of Salient Object Detection for Smart Grid Applications
Published on: December 15, 2023
A New Edge Patch with Rotation Invariance for Object Detection and Pose Estimation
Xunwei Tong1, Ruifeng Li1, Lianzheng Ge1
1State Key Laboratory of Robotics and System, Harbin Institute of Technology, Harbin 150001, China.

Abstract:
Local patch-based methods of object detection and pose estimation are promising. However, to the best of the authors' knowledge, traditional red-green-blue and depth (RGB-D) patches contain scene interference (foreground occlusion and background clutter) and have little rotation invariance. To solve these problems, a new edge patch is proposed and experimented with in this study. The edge patch is a local sampling RGB-D patch centered at the edge pixel of the depth image. According to the normal direction of the depth edge, the edge patch is sampled along a canonical orientation, making it rotation invariant. Through a process of depth detection, scene interference is eliminated from the edge patch, which improves the robustness. The framework of the edge patch-based method is described, and the method was evaluated on three public datasets. Compared with existing methods, the proposed method achieved a higher average F1-score (0.956) on the Tejani dataset and a better average detection rate (62%) on the Occlusion dataset, even in situations of serious scene interference. These results showed that the proposed method has higher detection accuracy and stronger robustness.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:11
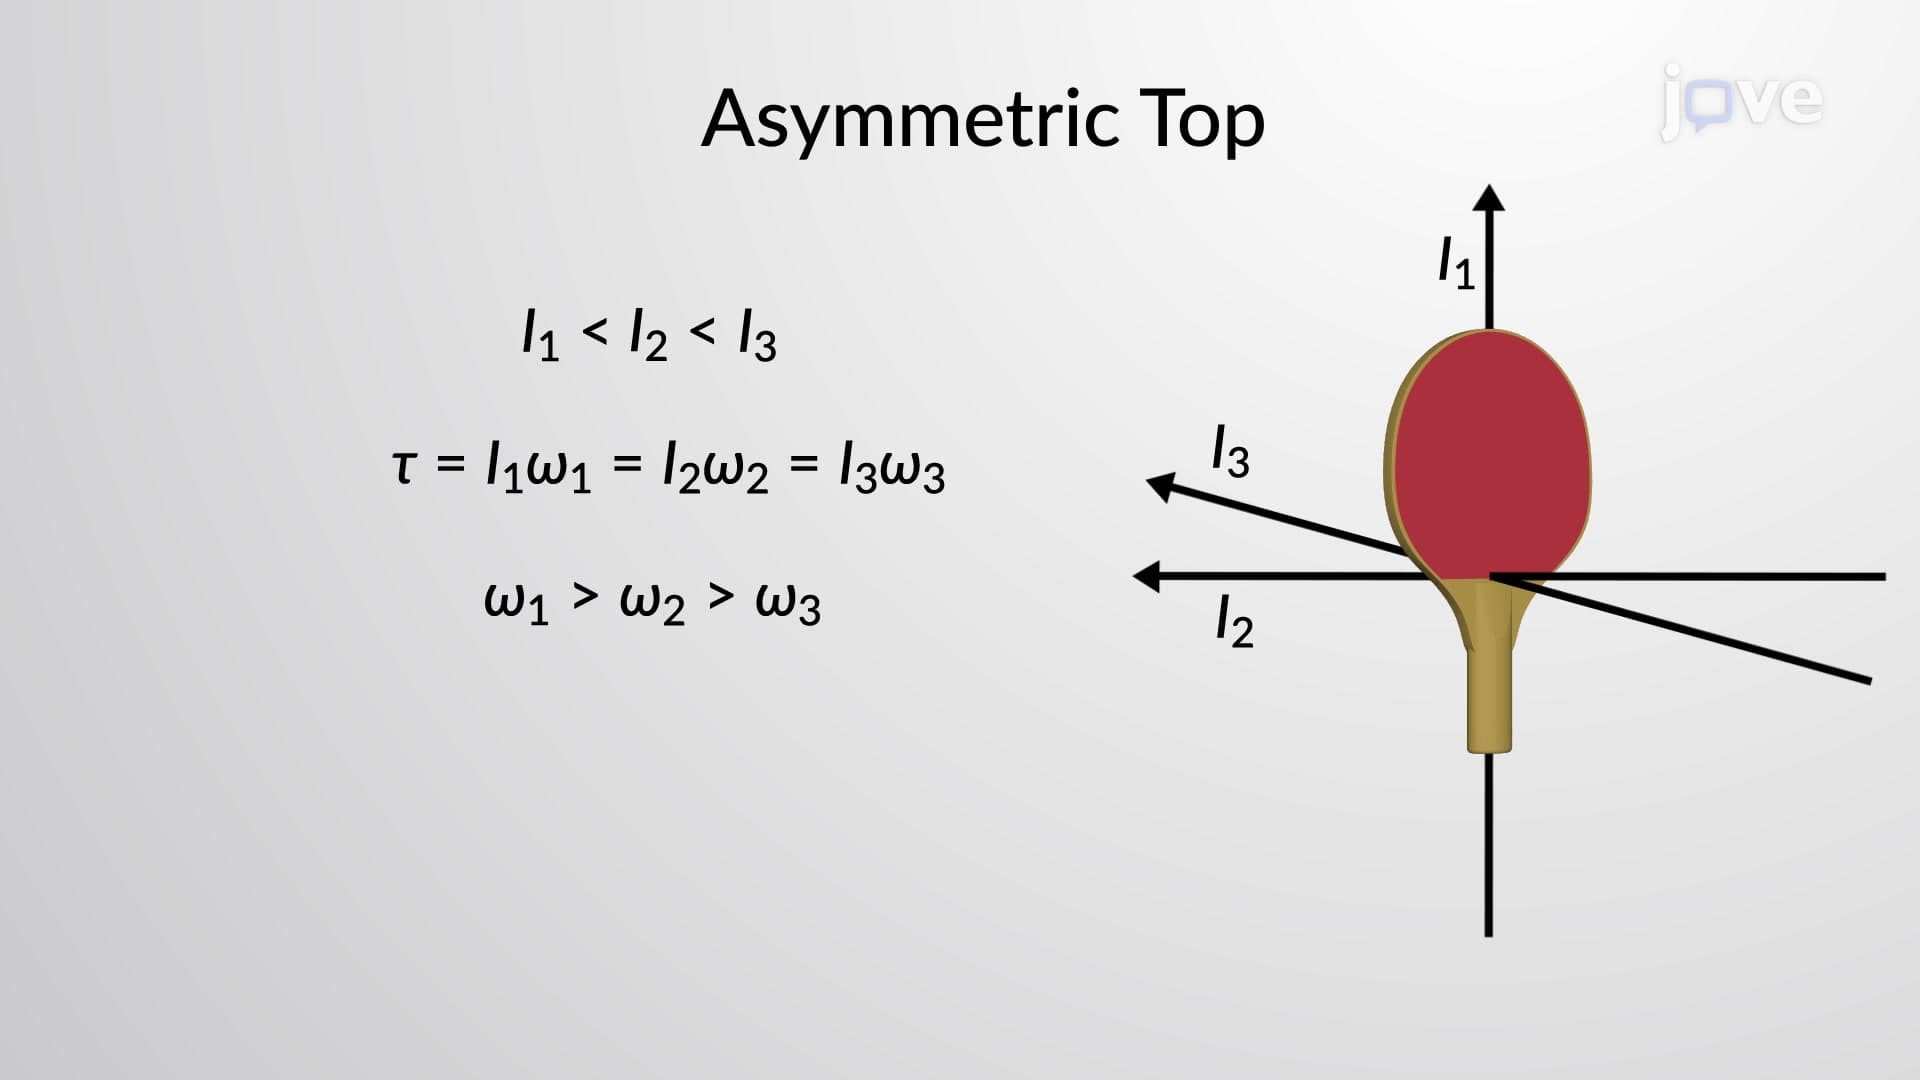
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:16
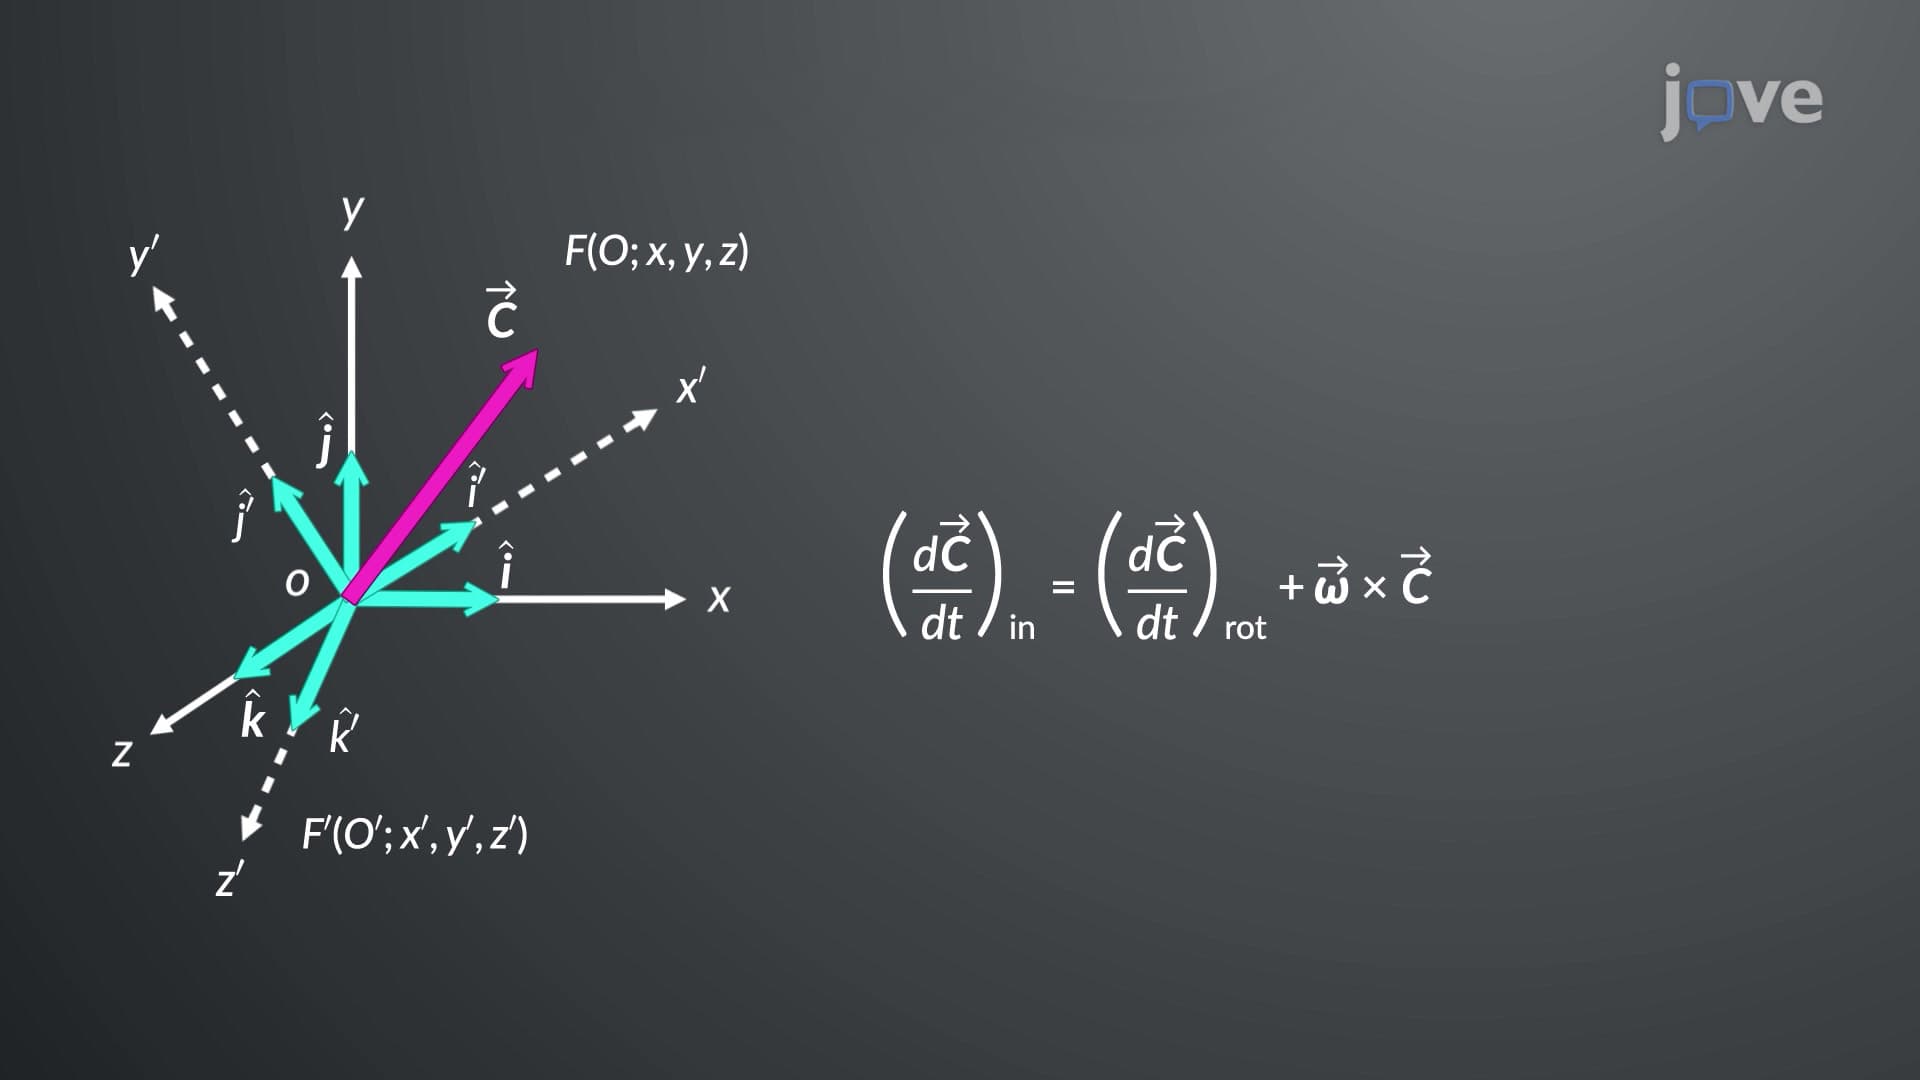
Vector Transformation in Rotating Coordinate Systems
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:16
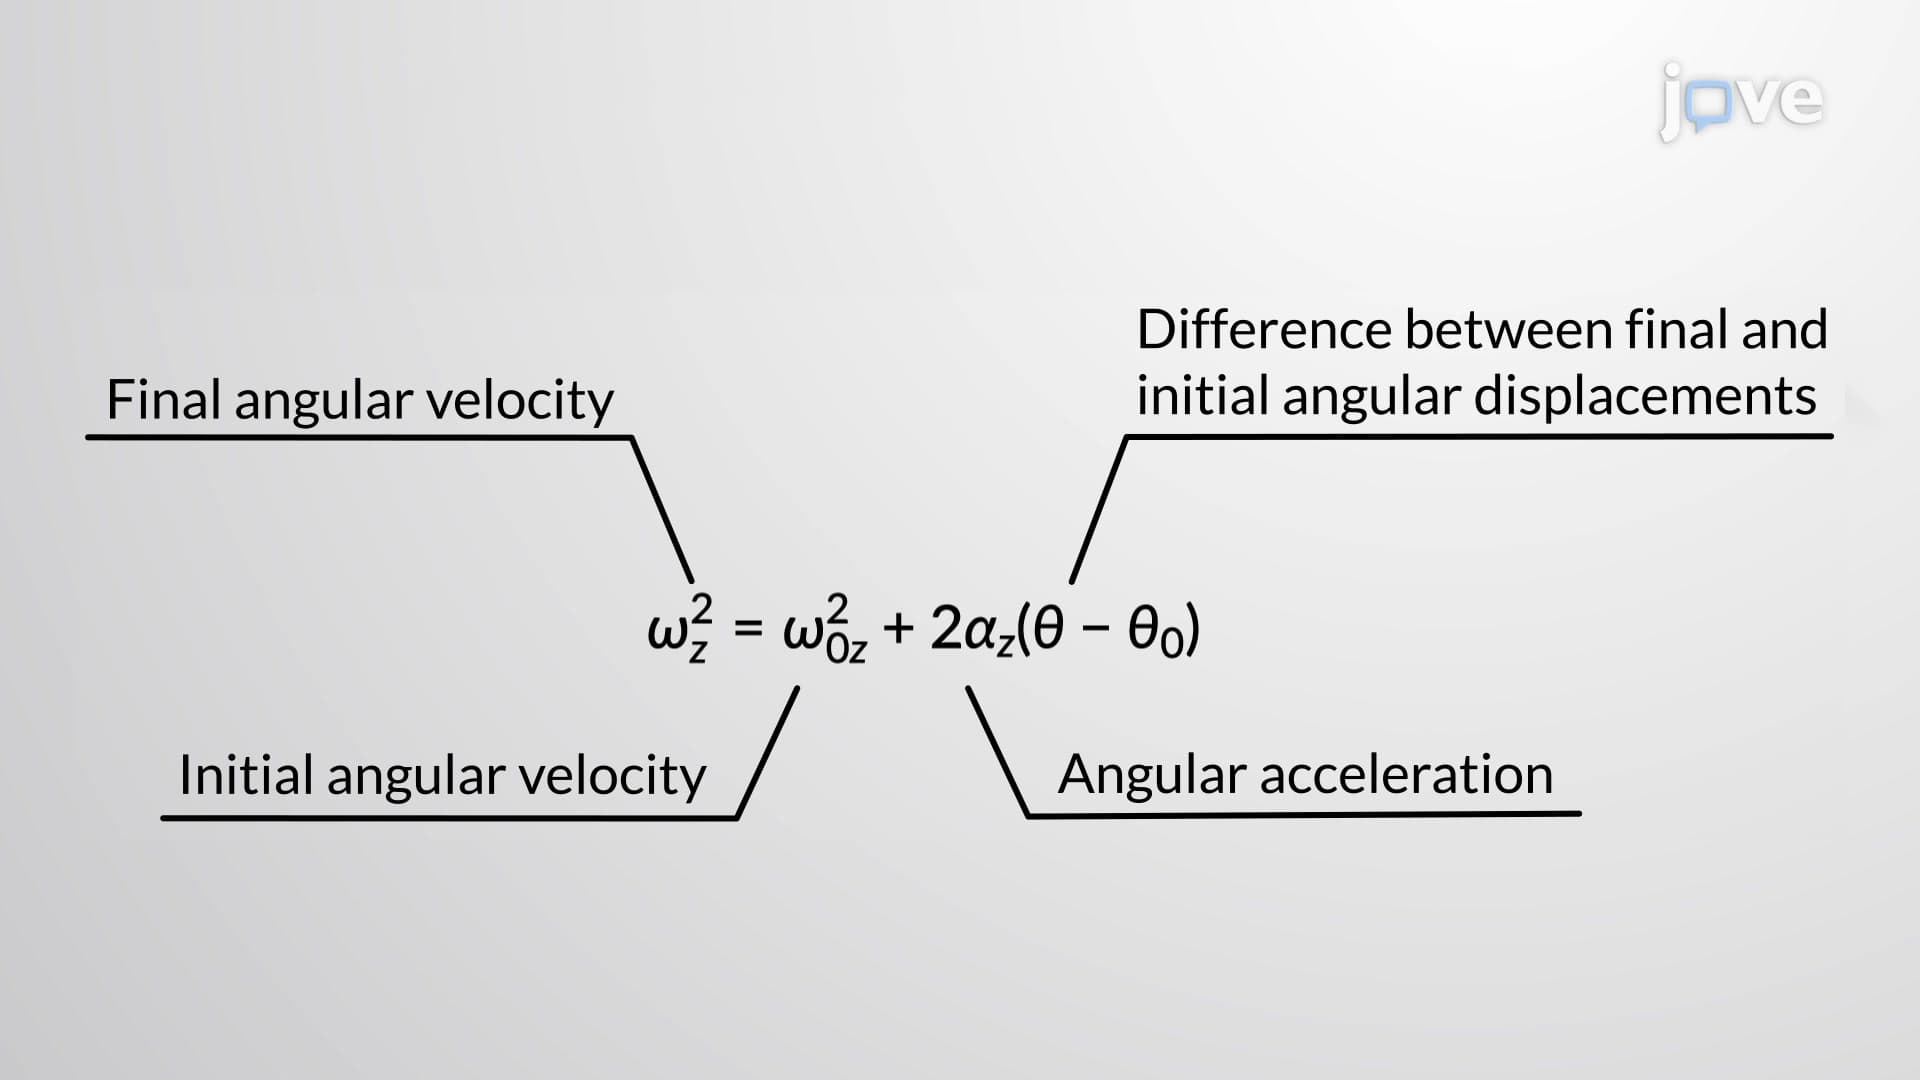
Rotation with Constant Angular Acceleration - II
The first...