Related Experiment Video
Updated: Dec 28, 2025
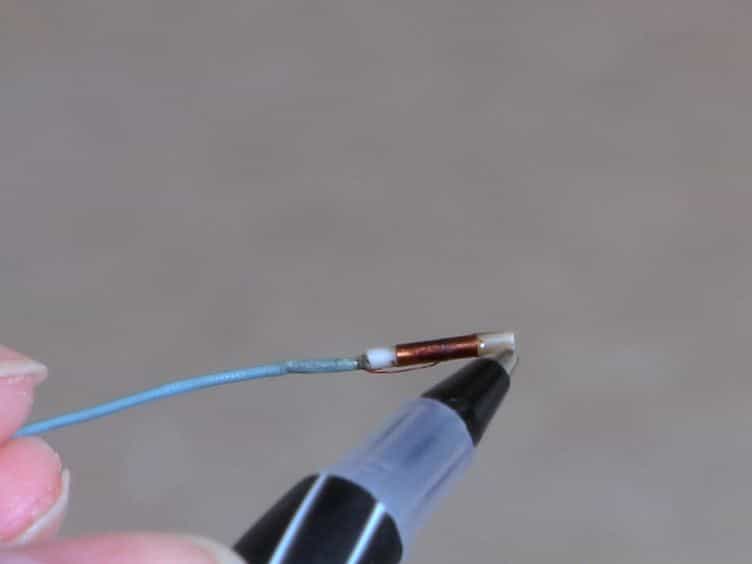

Magnetically-Assisted Remote Controlled Microcatheter Tip Deflection under Magnetic Resonance Imaging
Published on: April 4, 2013
Magnetic Needle Steering in Soft Phantom Tissue
Mahdi Ilami1, Reza James Ahmed1, Alex Petras1
1Arizona State University, School for Engineering of Matter Transport and Energy (SEMTE), Tempe, 85287, USA.

Abstract:
Needle steering is a technology for guiding needles around sensitive internal obstacles in minimally invasive surgery. Traditional techniques apply rotation at the base of a needle with an asymmetric tip, enabling steering through the redirection of radial forces. Magnetic steering of catheters and continuum manipulators is another technology that allows steering of a shaft in the body. Both of these techniques rely on mechanical or manual shaft advancement methods. Needle steering has not achieved widespread clinical use due to several limitations: 1- buckling and compression effects in the shaft and needle rotation cause excessive tissue damage; 2- torsion effects on the shaft and needle deflection at tissue boundaries lead to difficulty in control; and 3- restricted radius of curvature results in limited workspace. Magnetically steered catheters and continuum manipulators also suffer from limited curvature and the possibility of buckling. This paper proposes a novel needle steering method empowered by electromagnetic actuation that overcomes all of the aforementioned limitations, making it a promising option for further study toward healthcare applications.