
Trunk pitch oscillations for energy trade-offs in bipedal running birds and robots
Özge Drama1, Alexander Badri-Spröwitz
1Dynamic Locomotion Group, Max Planck Institute of Intelligent Systems, Stuttgart, Germany.

Abstract:
Bipedal animals have diverse morphologies and advanced locomotion abilities. Terrestrial birds, in particular, display agile, efficient, and robust running motion, in which they exploit the interplay between the body segment masses and moment of inertias. On the other hand, most legged robots are not able to generate such versatile and energy-efficient motion and often disregard trunk movements as a means to enhance their locomotion capabilities. Recent research investigated how trunk motions affect the gait characteristics of humans, but there is a lack of analysis across different bipedal morphologies. To address this issue, we analyze avian running based on a spring-loaded inverted pendulum model with a pronograde (horizontal) trunk. We use a virtual point based control scheme and modify the alignment of the ground reaction forces to assess how our control strategy influences the trunk pitch oscillations and energetics of the locomotion. We derive three potential key strategies to leverage trunk pitch motions that minimize either the energy fluctuations of the center of mass or the work performed by the hip and leg. We suggest how these strategies could be used in legged robotics.
Related Concept Videos
 01:14
Energy Diagrams - I
Take the example of a skater on a parabolic ramp. The potential energy at different points along the ramp will be proportional to the height of the ramp, which varies quadratically with the horizontal position on the ramp. As the skater moves down the ramp from the highest position,...
 01:10
Bones of the Lower Limb: Tibia and Fibula
 01:09
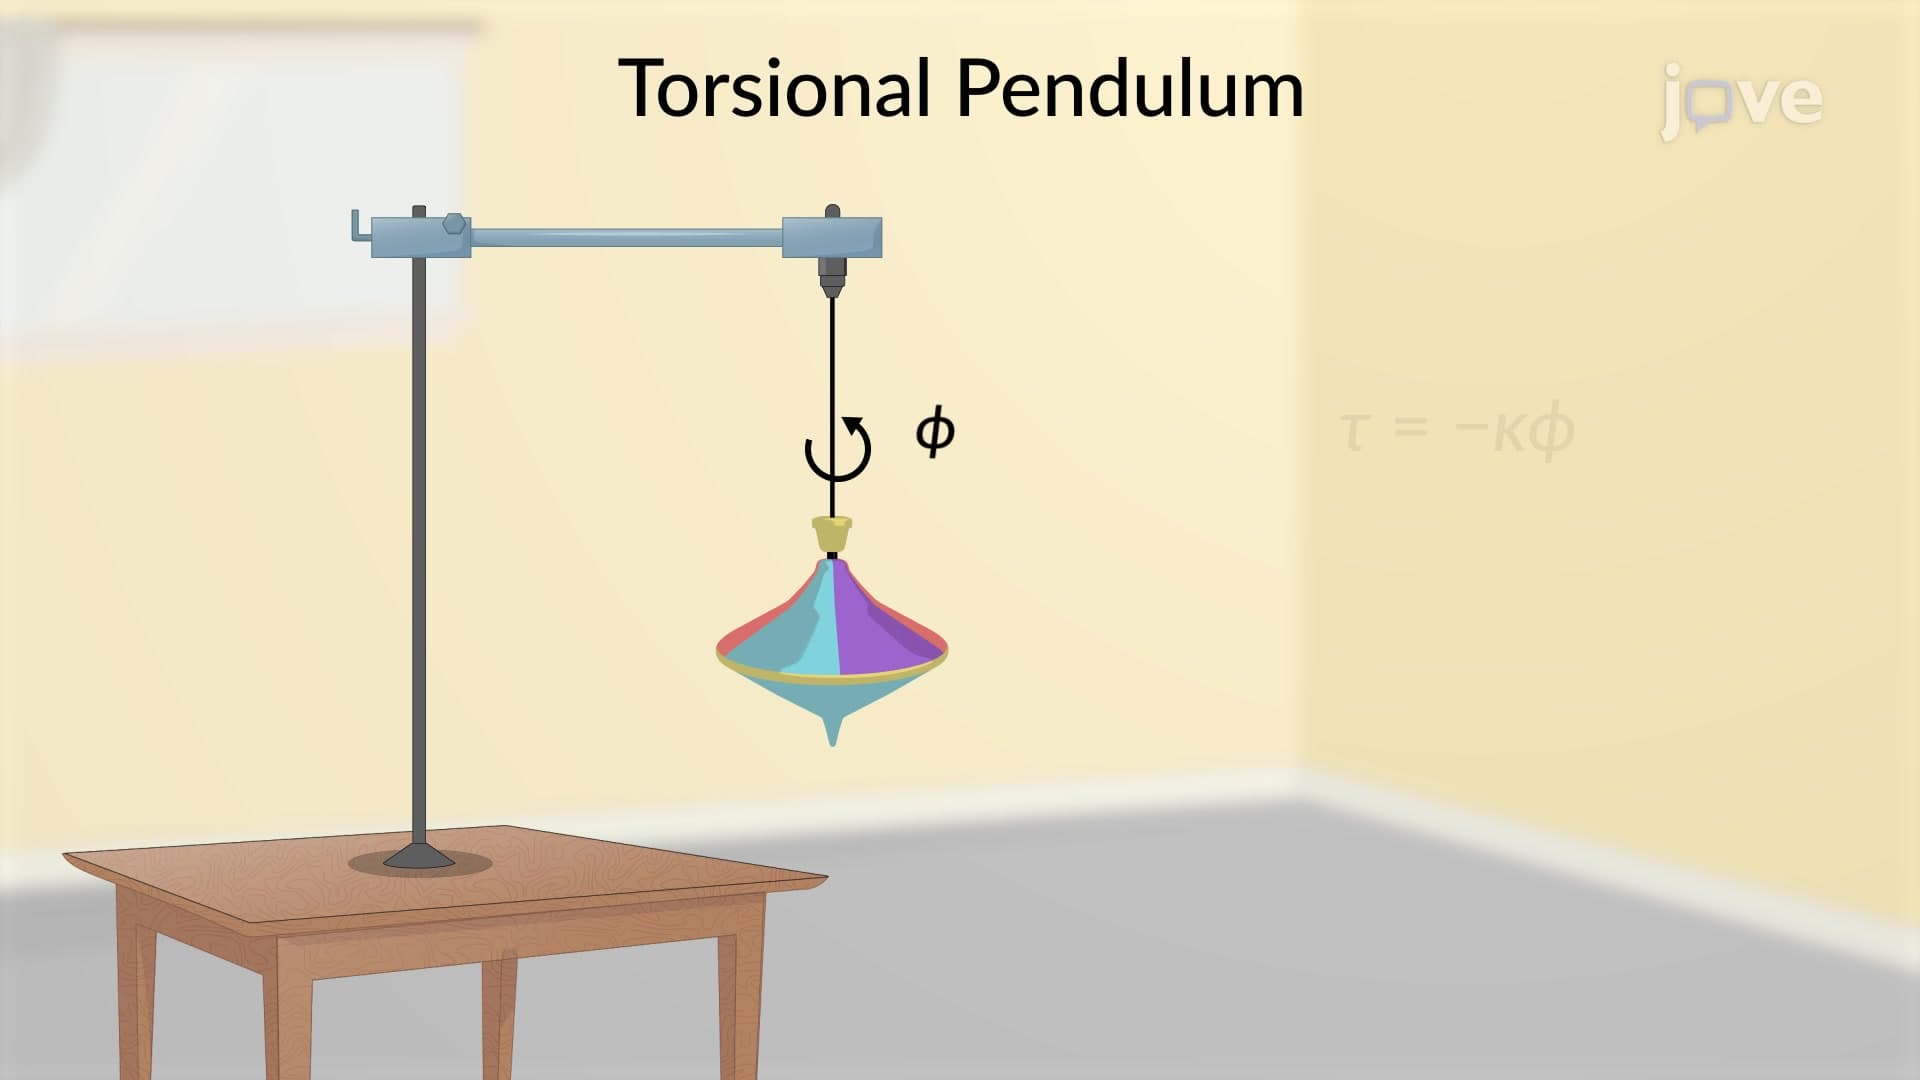
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...