Related Experiment Video
Updated: Dec 28, 2025
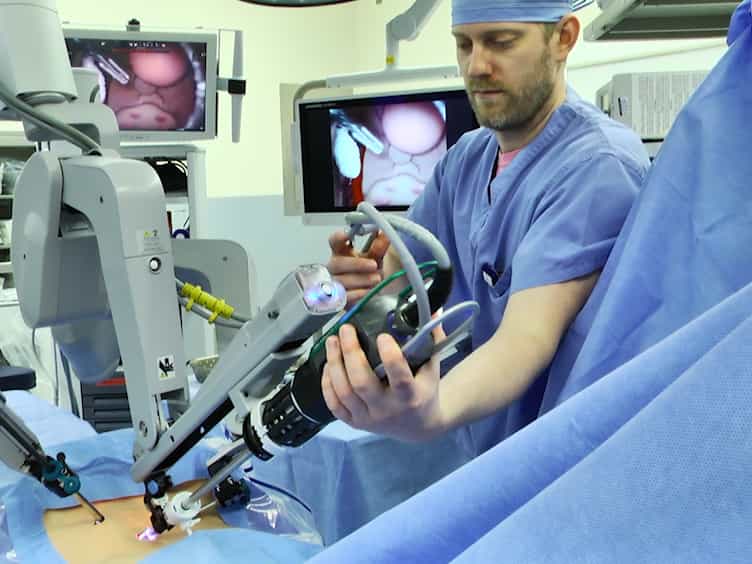

Emergency Undocking in Robotic Surgery: A Simulation Curriculum
Published on: May 20, 2018
From Da Vinci Si to Da Vinci Xi: realistic times in draping and docking the robot
Emma M van der Schans1,2, Marijn A J Hiep3, Esther C J Consten4,5
1Department of Surgery, Meander Medical Center, Maatweg 3, Amersfoort, The Netherlands. em.vander.schans@meandermc.nl.

Abstract:
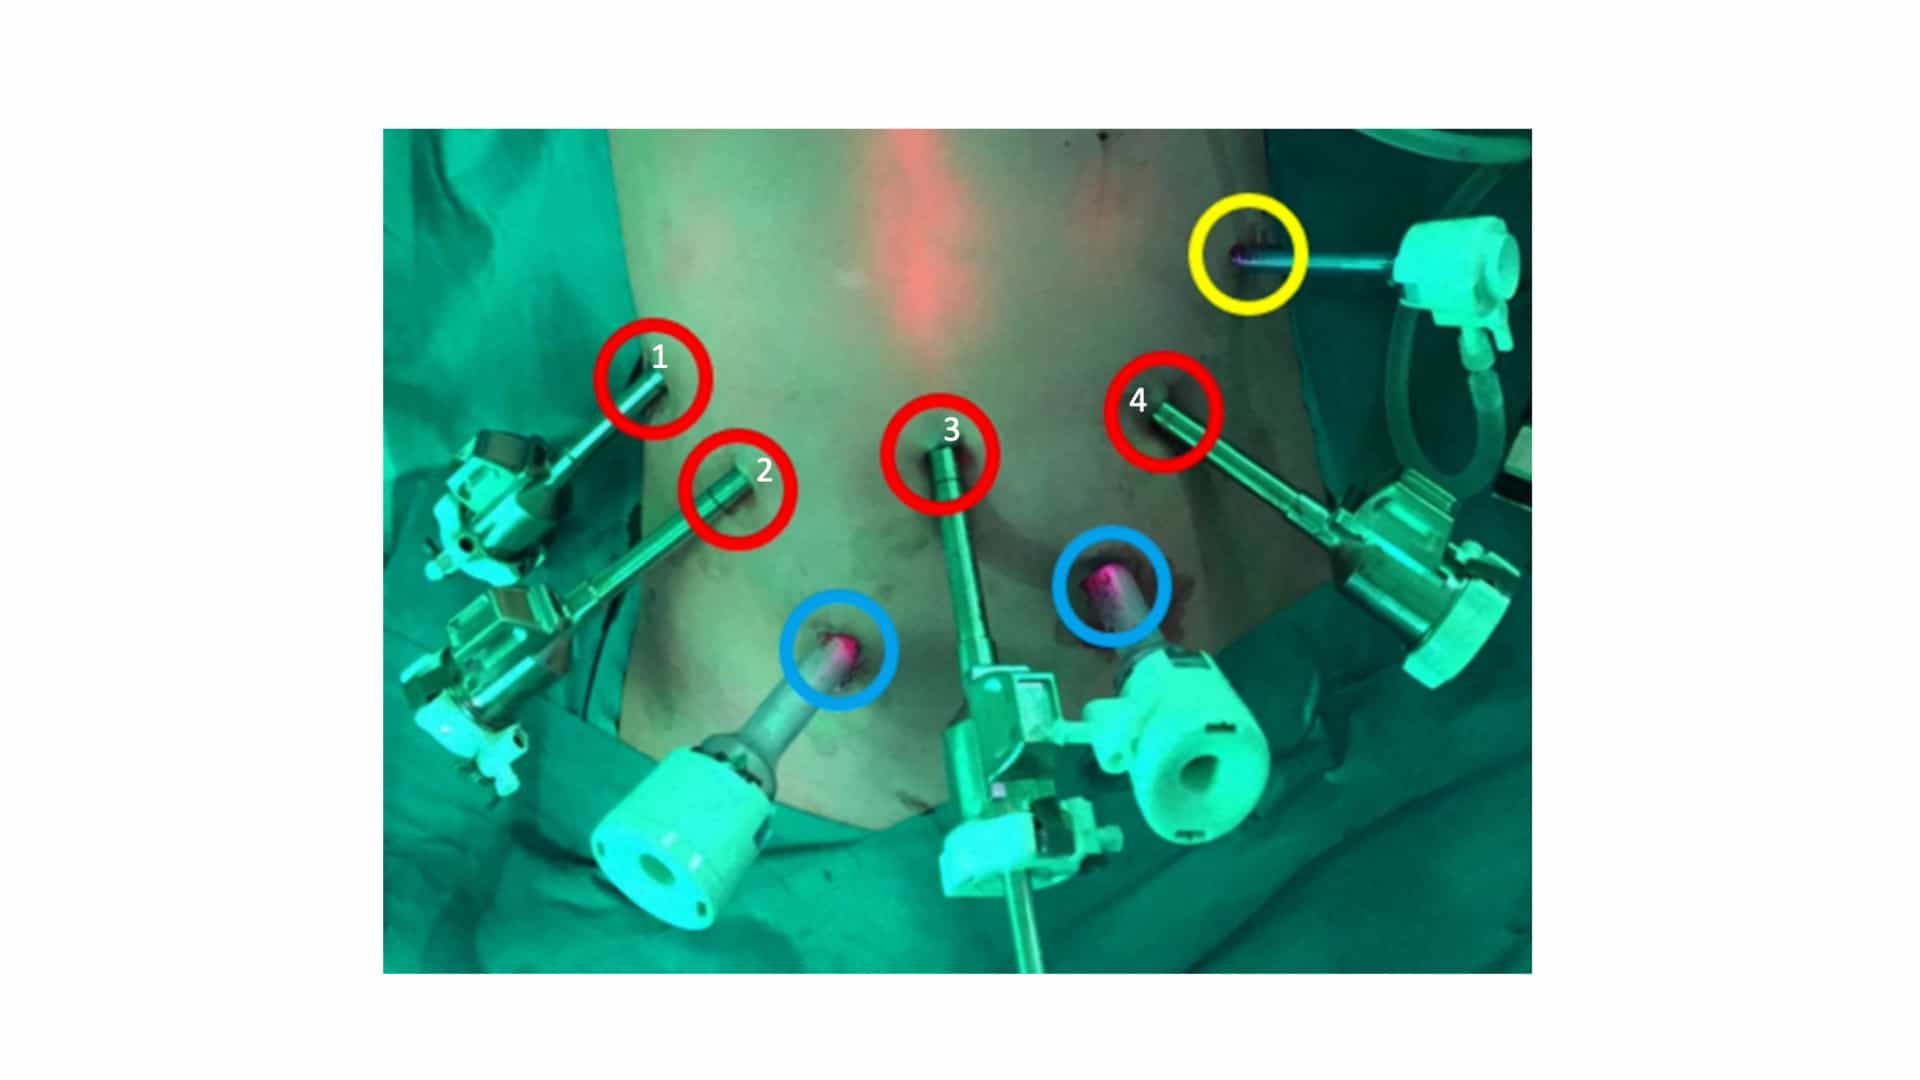
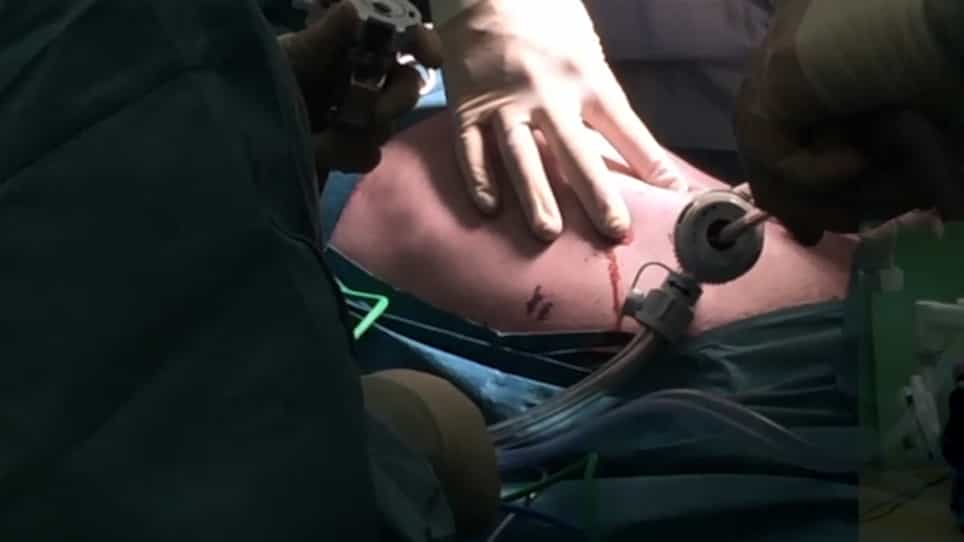
Robot-assisted surgery is assumed to be time consuming partially due to extra time needed in preparing the robot. The objective of this study was to give realistic times in Da Vinci Xi draping and docking and to analyse the learning curve in the transition from the Si to the Xi in an experienced team. This prospective study was held in a hospital with a high volume of robot-assisted surgery in general surgery, urology and gynaecology. Times from the moment patients entered the operating room until the surgeon took place behind console were precisely recorded during the first 6 weeks after the implementation of the Xi. In total, 65 procedures were performed and documented. The learning curve for the process of draping and docking the robot was reached after 21 and 18 cases, respectively. Mean times after completion of the learning curve were 5 min for draping and 7 min for docking and were statistically different from mean times before completion of the learning curve (p values < 0.01). In dedicated teams netto extra time needed for preparing the Xi can even be reduced to just the time needed for docking. Thus, setting up the robot should have limited impact on overall time spent in the operation room.
Related Concept Videos
 01:14
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:22
Mechanical Systems
 01:12
Modeling and Similitude