Related Experiment Video
Updated: Dec 28, 2025

Fabrication of Soft Pneumatic Network Actuators with Oblique Chambers
Published on: August 17, 2018
Geometric Confined Pneumatic Soft-Rigid Hybrid Actuators
Jinhua Zhang1, Tao Wang1, Jin Wang2
1Department of Mechanical Engineering, Institute of Design Science and Basic Components, Xi'an Jiaotong University, Xi'an, China.

Abstract:
In this work, we propose a new kind of soft-rigid hybrid actuator composed mainly of soft chambers and rigid frames. Compared with the well-known fiber-reinforced soft actuators, the hybrid actuators are able to ensure the design of noncircular cross-sectional shapes. It is demonstrated that rigid frames are capable of providing geometric constraints, reducing the ineffective deformation, and improving the energy utilization for the hybrid actuators with noncircular cross-sections. The essential characteristics of rigid constraints and flexible constraints are obtained by simulation and experiments on specimens with three different cross-sectional shapes. Furthermore, a spring-fluid film model is introduced to characterize the behavior of a representative hybrid linear actuator and a bending actuator with a rectangular cross-section, and it is also proved by the corresponding experiments. The change of the cross-sectional shape of fiber-reinforced soft actuators under pressurization is also explained theoretically as a contrast. Then, two application examples, namely, a robotic gripper and a caudal fin formed from linear actuators, are designed and demonstrated, showing the advantages and potential applications of the proposed geometric confined hybrid actuators. The proposed soft-rigid hybrid actuators combine the properties of soft and rigid materials, expand the design scope of the compliant actuators, and provide new solutions for robotics, especially for soft robots with specific requirements for their shapes or profiles.

Related Concept Videos
 01:03
Application of Pascal's Law
Hydraulic systems are used to operate automotive brakes, hydraulic jacks, and numerous other mechanical systems. We can derive a relationship between the forces in a simple hydraulic system...
 01:22
Mechanical Systems
 01:27
Three Force Member
For example, consider a dumpster connected to a pin support at point A and a pin attached to a hydraulic cylinder at point B.
 01:20
Plastic Deformation in Circular Shafts
 01:24
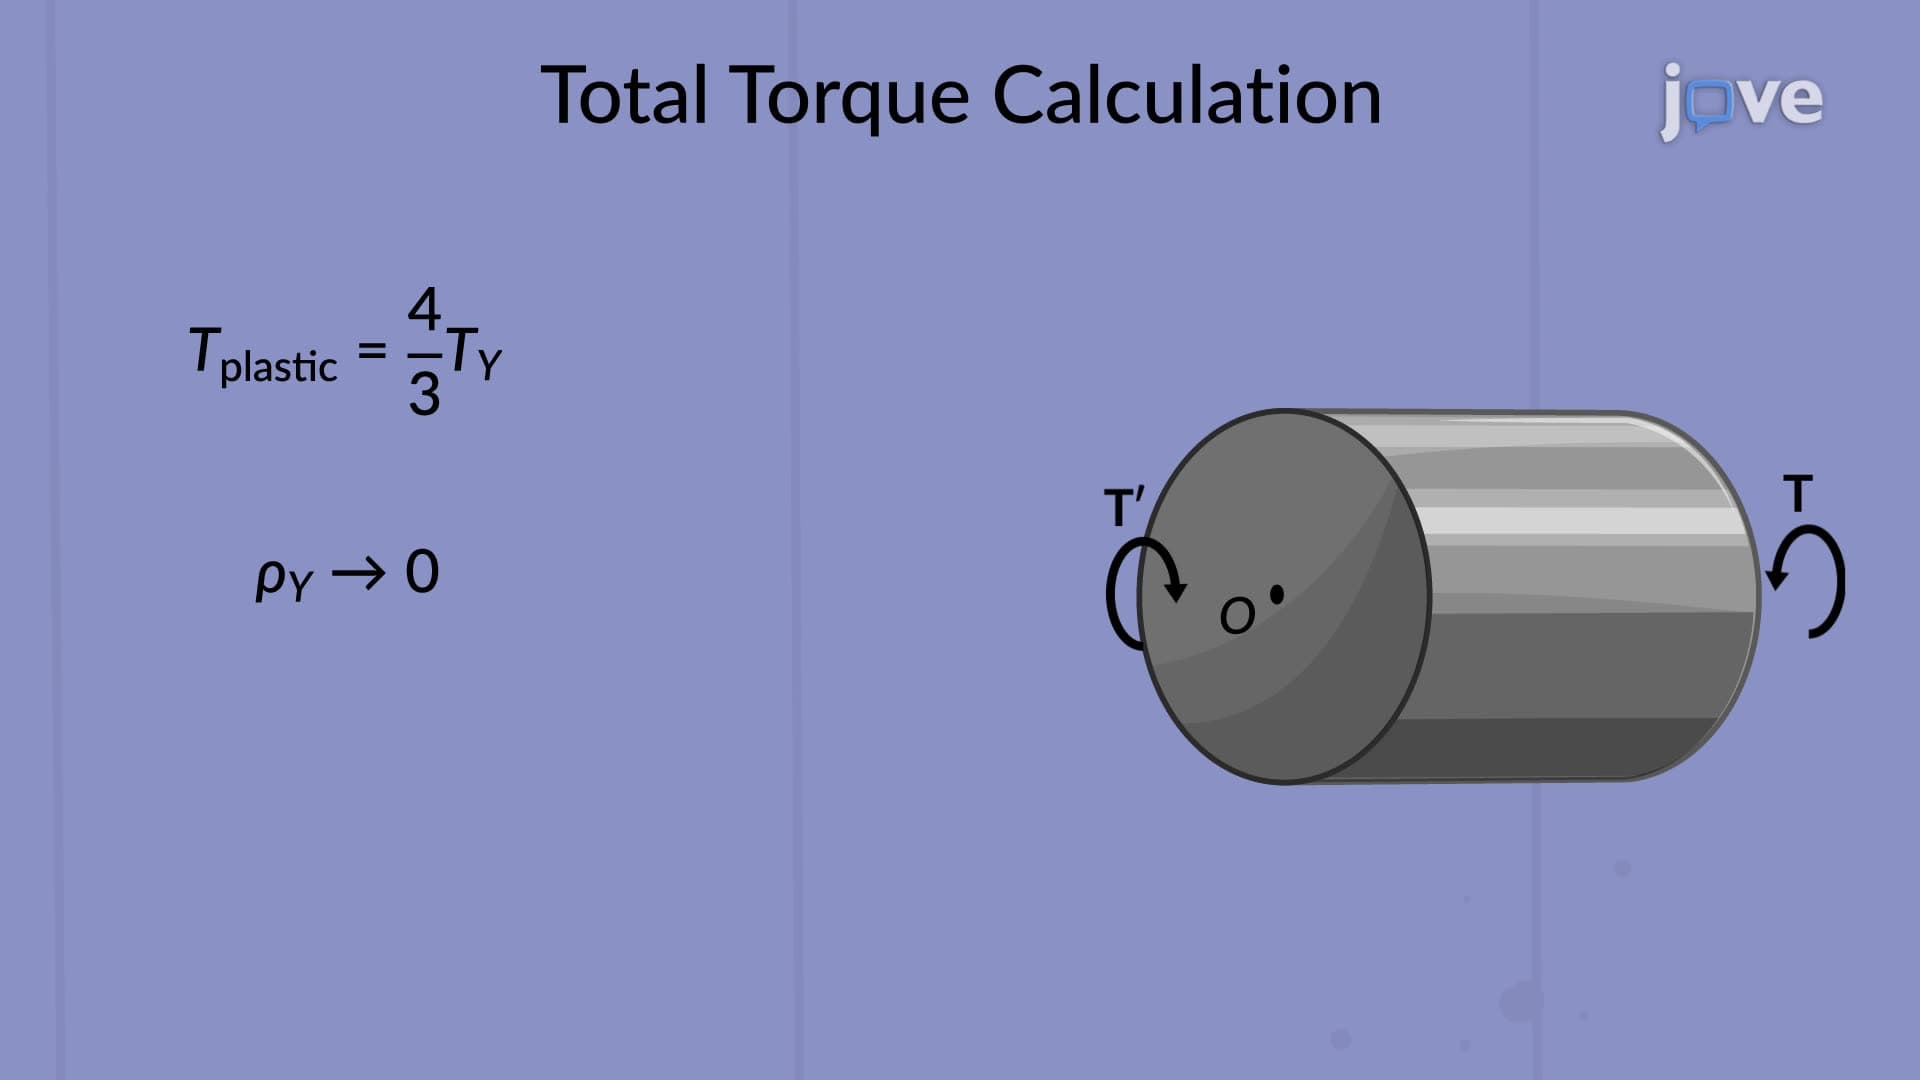
Circular Shafts - Elastoplastic Materials
As torque on the...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...