Related Experiment Video
Updated: Dec 27, 2025
Design and Characterization Methodology for Efficient Wide Range Tunable MEMS Filters
Published on: February 4, 2018
The Characteristics and Locking Process of Nonlinear MEMS Gyroscopes
Yan Su1,2, Pengfei Xu1,2, Guowei Han1
1Engineering Research Center for Semiconductor Integrated Technology, Institute of Semiconductors, Chinese Academy of Sciences, Beijing 100083, China.

Abstract:
With the miniaturization of micro-electro-mechanical system (MEMS) gyroscopes, it is necessary to study their nonlinearity. The phase-frequency characteristics, which affect the start-up time, are crucial for guaranteeing the gyroscopes' applicability. Nevertheless, although the amplitude-frequency (A-f) effect, one of the most obvious problems in nonlinearity, has been well studied, the phase response of nonlinear gyroscopes is rarely mentioned. In this work, an elaborate study on the characteristics and locking process of nonlinear MEMS gyroscopes is reported. We solved the dynamic equation using the harmonic balance method and simulated the phase-locked loop (PLL) actuation process with an iterative calculation method. It was shown that there existed an apparent overhanging and multi-valued phenomenon in both the amplitude-frequency and phase-frequency curves of nonlinear gyroscopes. Meanwhile, it was ascertained by our simulations that the locking time of PLL was retarded by the nonlinearity under certain conditions. Moreover, experiments demonstrating the effect of nonlinearity were aggravated by the high quality factor of the drive mode due to the instability of the vibration amplitude. A nonlinear PLL (NPLL) containing an integrator was designed to accelerate the locking process. The results show that the start-up time was reduced by an order of magnitude when the appropriate integral coefficient was used.
More Related Videos
 14:18
Automation of Mode Locking in a Nonlinear Polarization Rotation Fiber Laser through Output Polarization Measurements
Published on: February 28, 2016
 11:44
Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
Related Concept Videos
 01:02
Gyroscope
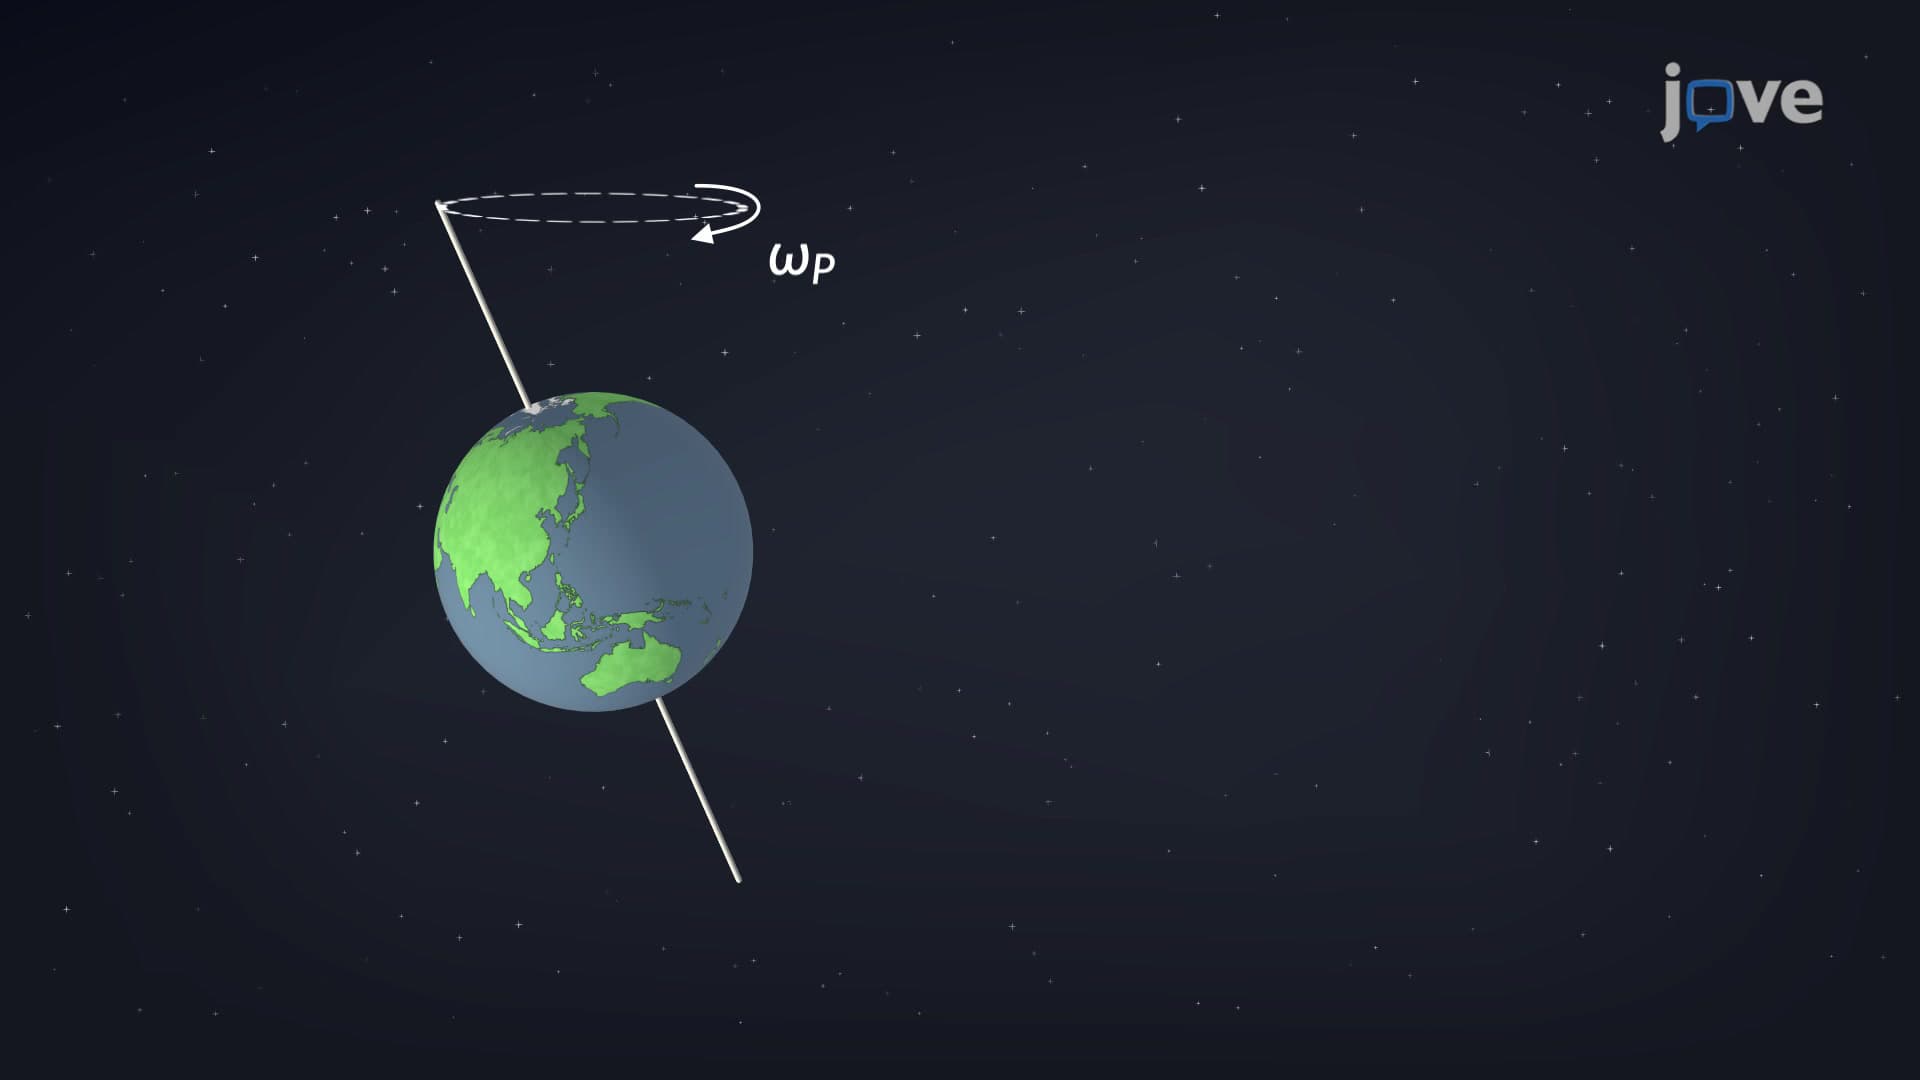 01:24
Gyroscope: Precession
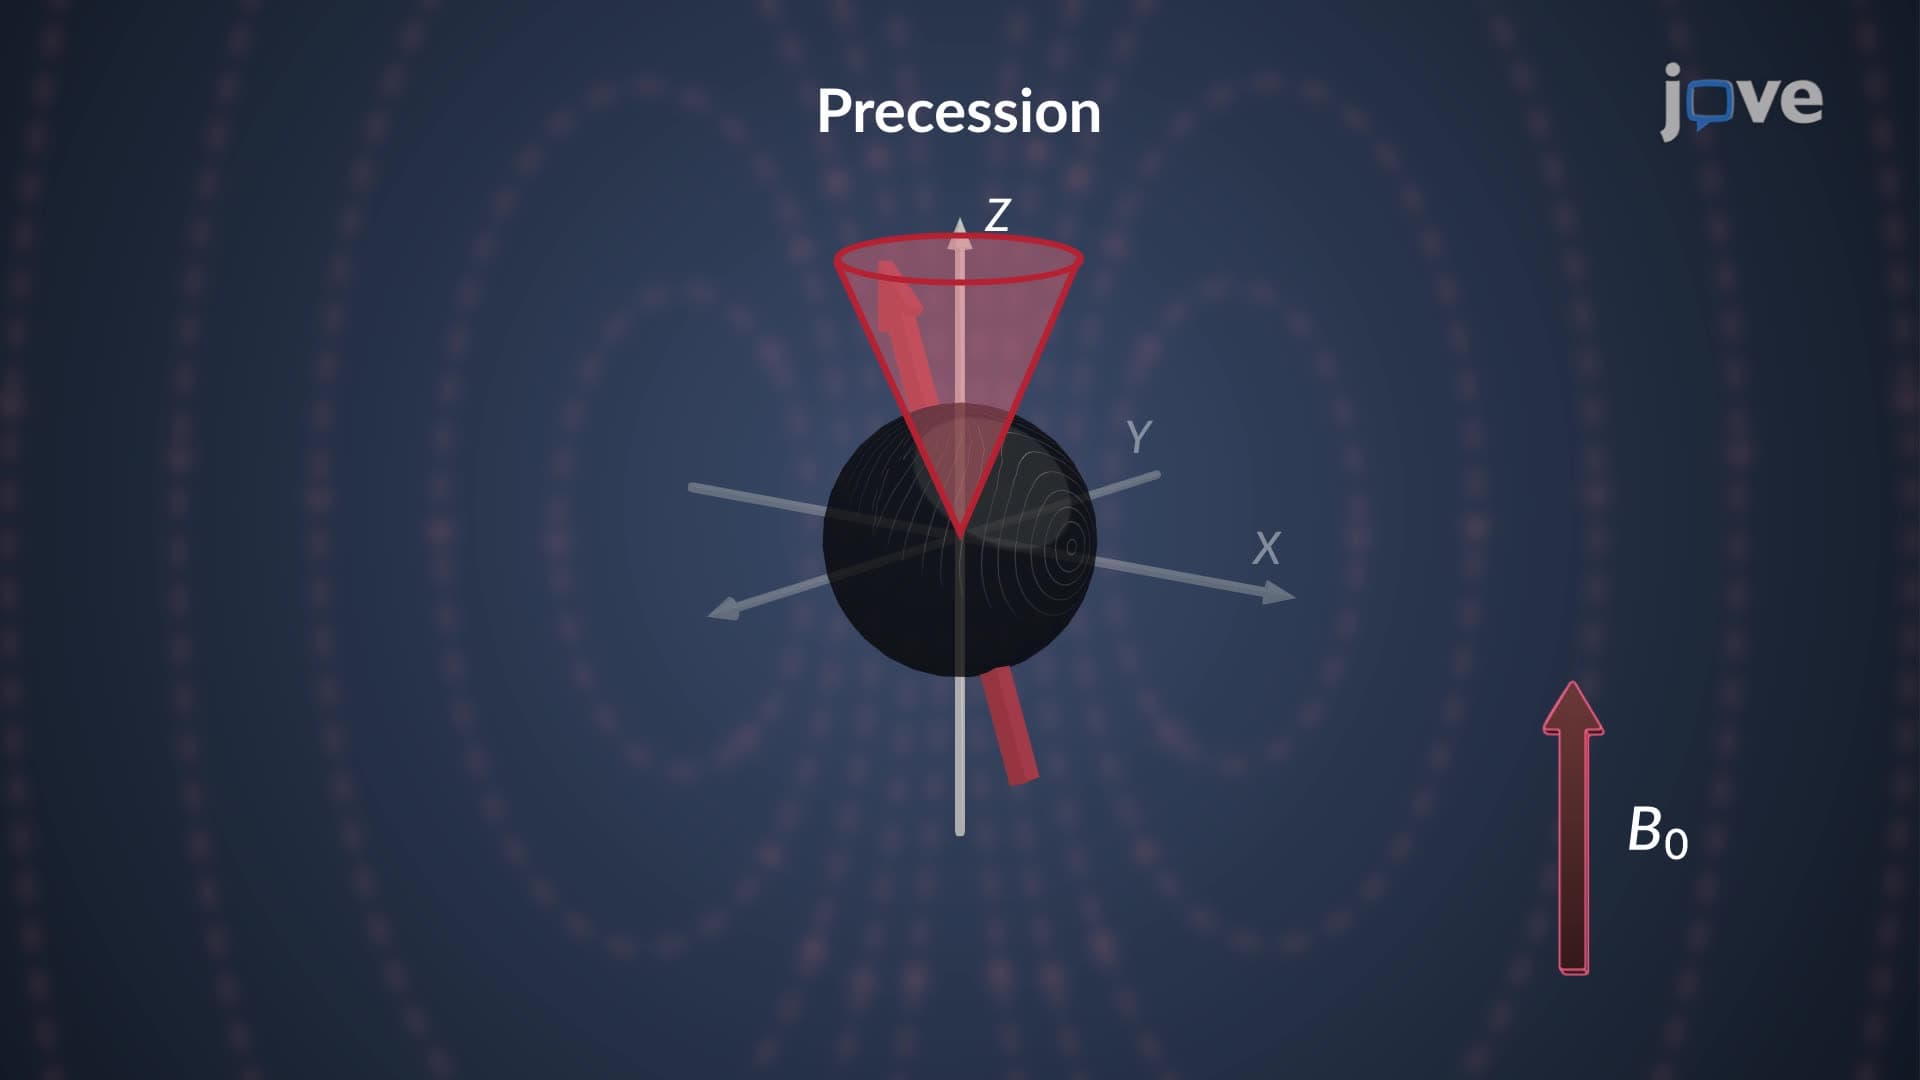 01:11
Atomic Nuclei: Larmor Precession Frequency
 01:14
NMR Spectrometers: Resolution and Error Correction
 01:16
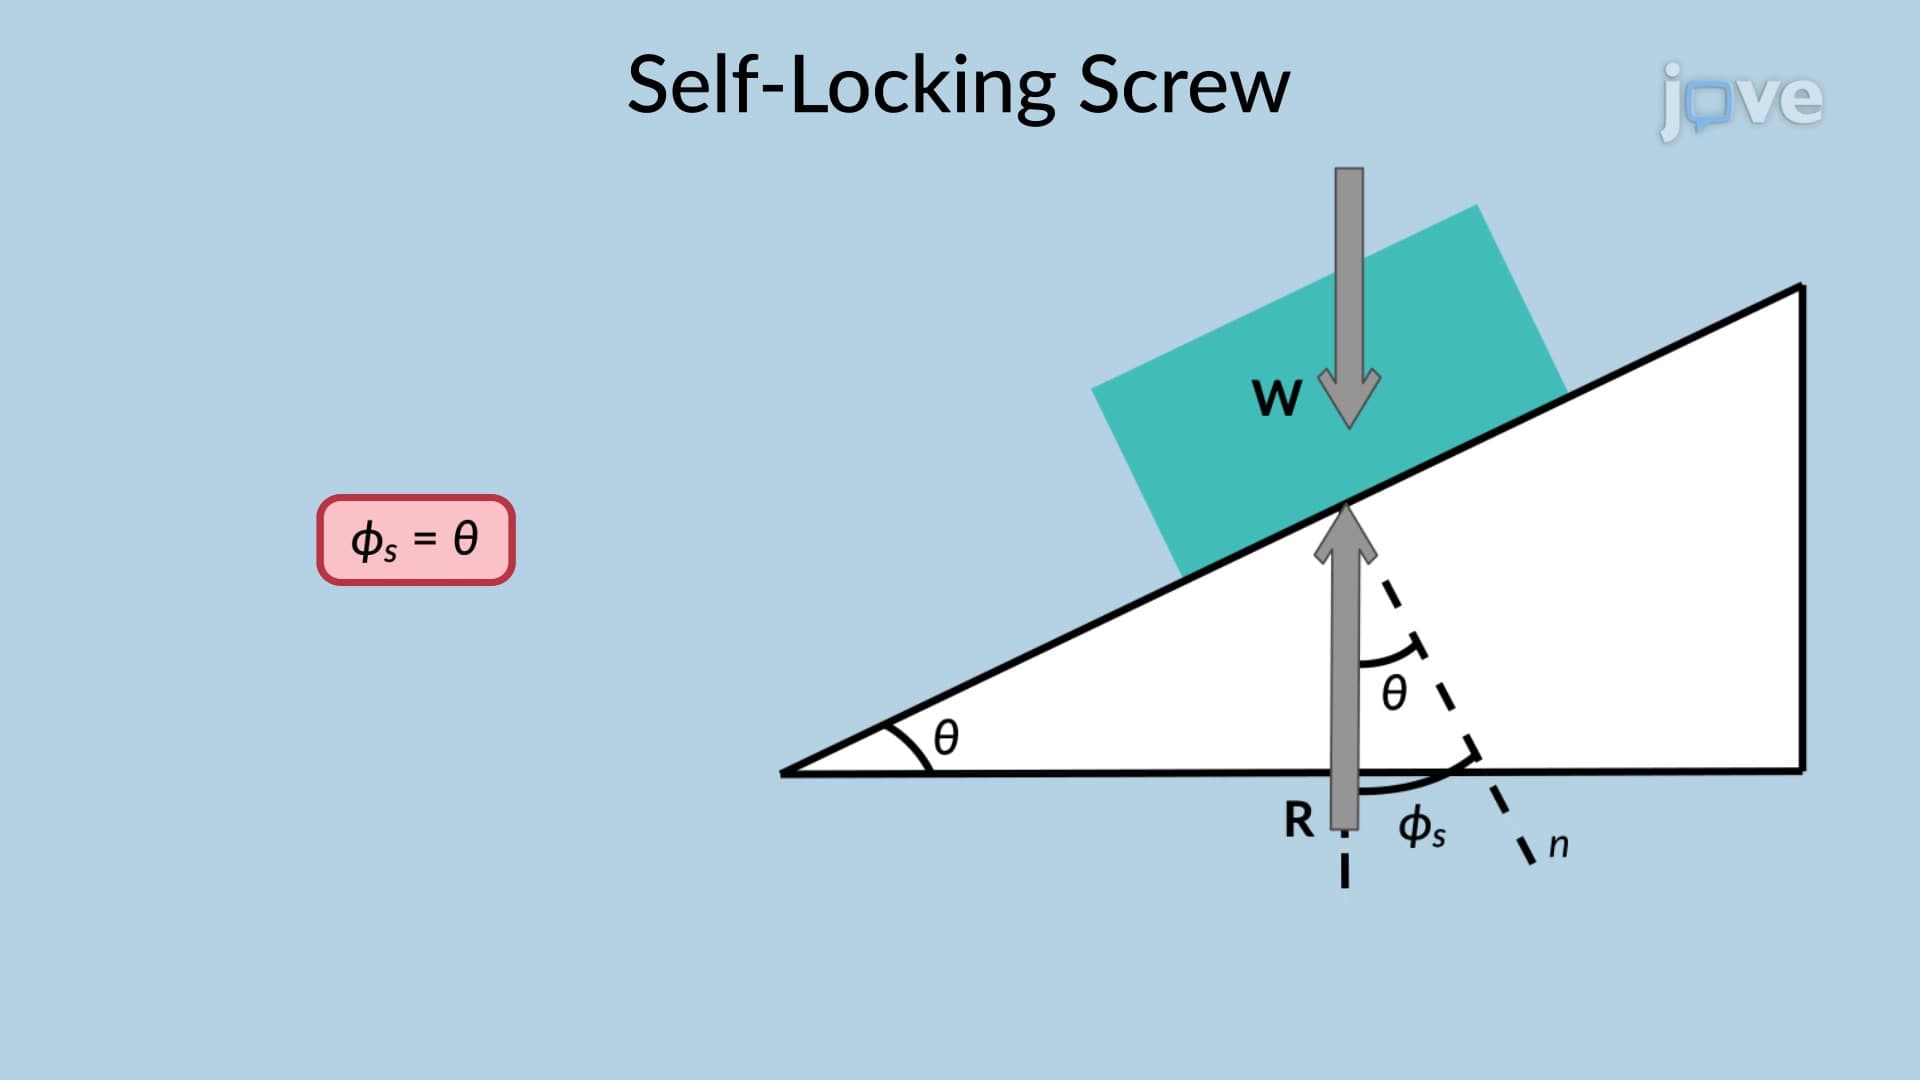
Self-Locking Screw
A square-threaded screw jack carrying a load is considered self-locking if the screw retains its position even after the moment applied to it is removed.
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...