Modeling and state-space identification of deformable mirrors
Related Experiment Video
Updated: Dec 27, 2025
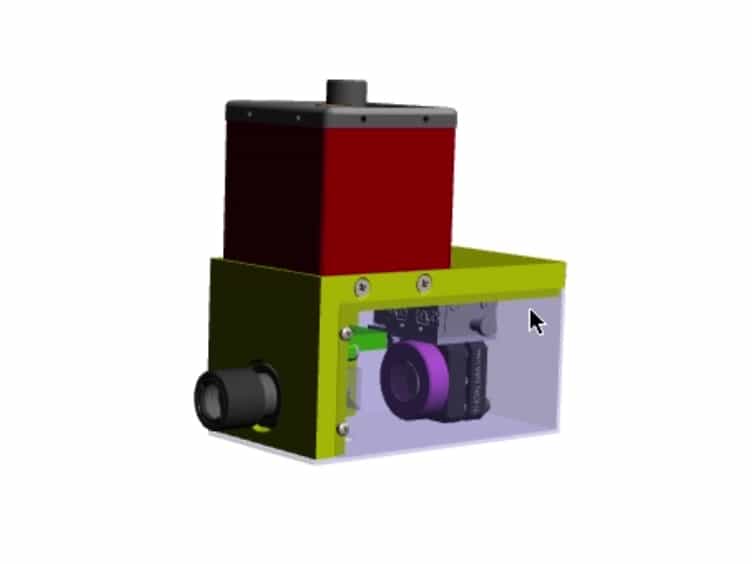
Compact Lens-less Digital Holographic Microscope for MEMS Inspection and Characterization
Published on: July 5, 2016

Abstract:
To develop high-performance controllers for adaptive optics (AO) systems, it is essential to first derive sufficiently accurate state-space models of deformable mirrors (DMs). However, it is often challenging to develop realistic large-scale finite element (FE) state-space models that take into account the system damping, actuator dynamics, boundary conditions, and multi-physics phenomena affecting the system dynamics. Furthermore, it is challenging to establish a modeling framework capable of the automated and quick derivation of state-space models for different actuator configurations and system geometries. On the other hand, for accurate model-based control and system monitoring, it is often necessary to estimate state-space models from the experimental data. However, this is a challenging problem since the DM dynamics is inherently infinite-dimensional and it is characterized by a large number of eigenmodes and eigenfrequencies. In this paper, we provide modeling and estimation frameworks that address these challenges. We develop an FE state-space model of a faceplate DM that incorporates damping and actuator dynamics. We investigate the frequency and time domain responses for different model parameters. The state-space modeling process is completely automated using the LiveLink for MATLAB toolbox that is incorporated into the COMSOL Multiphysics software package. The developed state-space model is used to generate the estimation data. This data, together with a subspace identification algorithm, is used to estimate reduced-order DM models. We address the model-order selection and model validation problems. The results of this paper provide essential modeling and estimation tools to broad AO and mechatronics scientific communities. The developed Python, MATLAB, and COMSOL Multiphysics codes are available online.
More Related Videos


Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:23
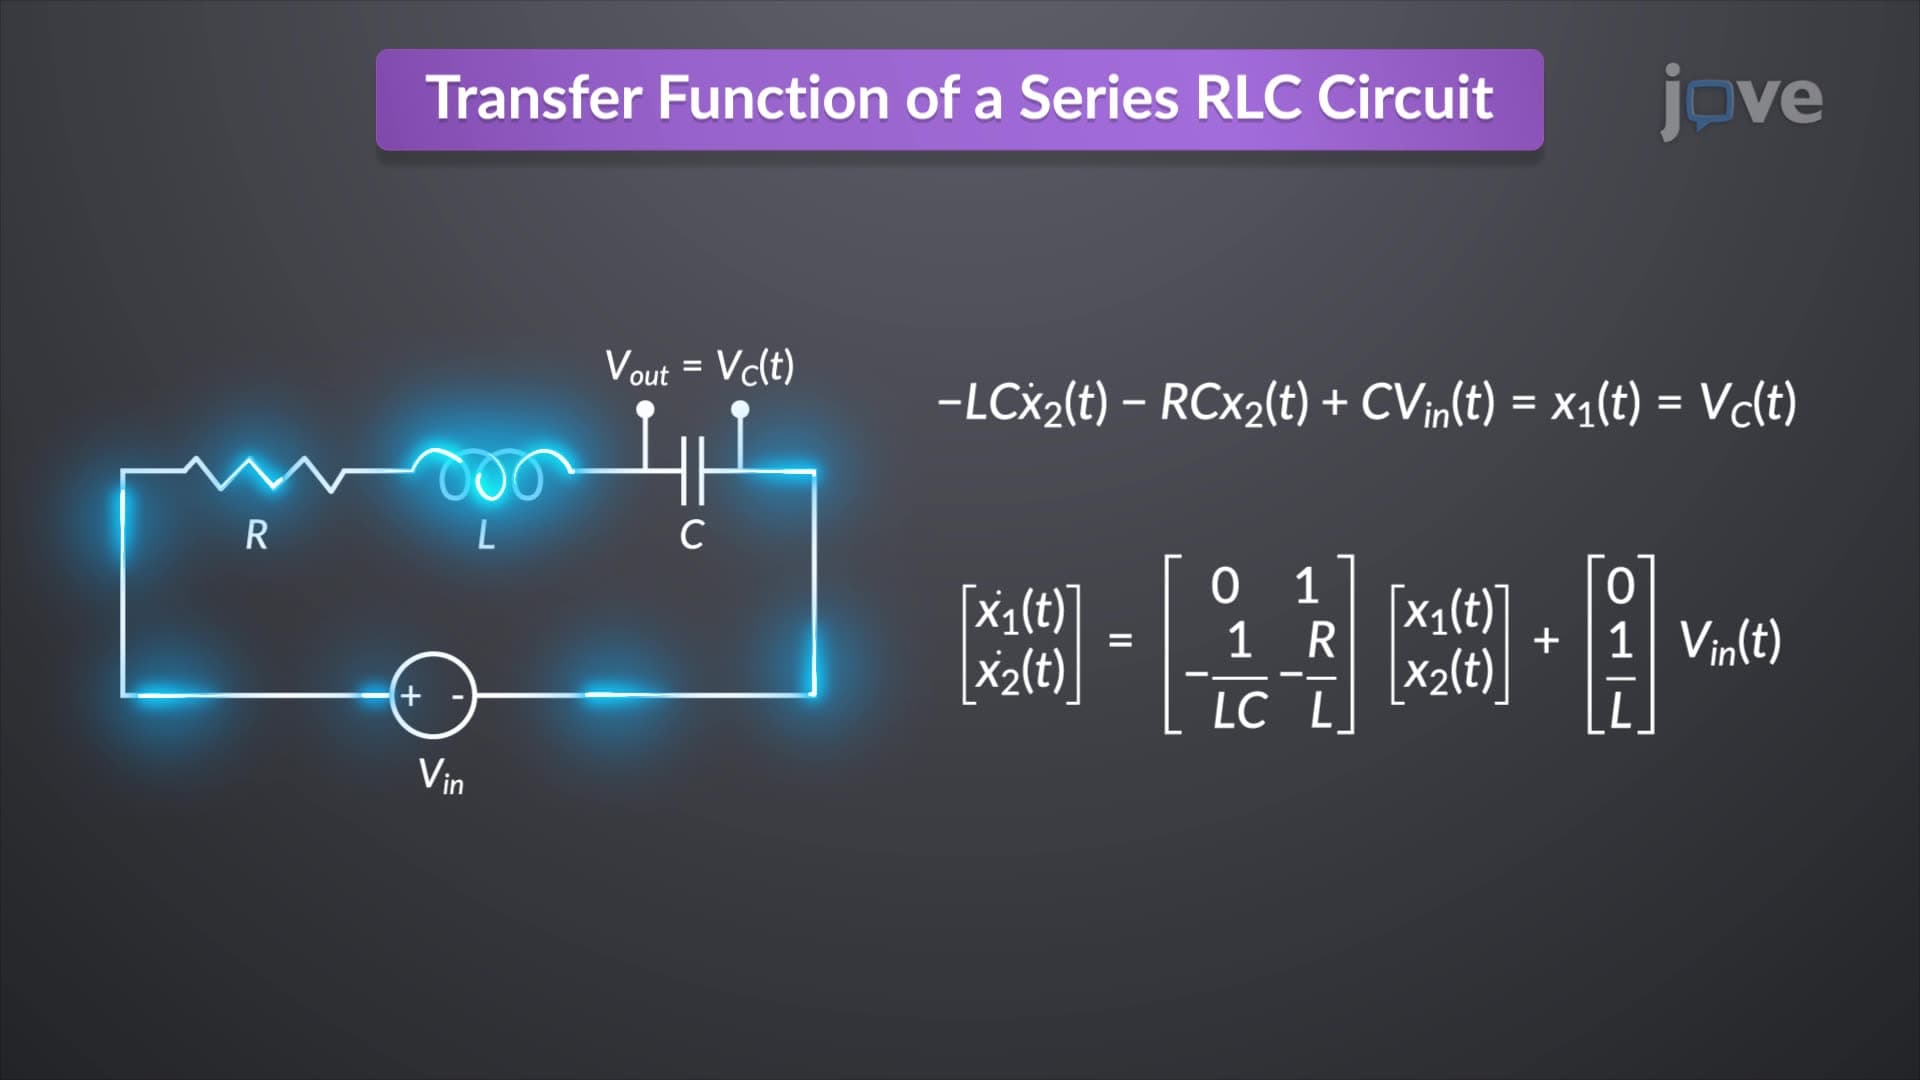
Transfer Function to State Space
In an RLC...
 01:21
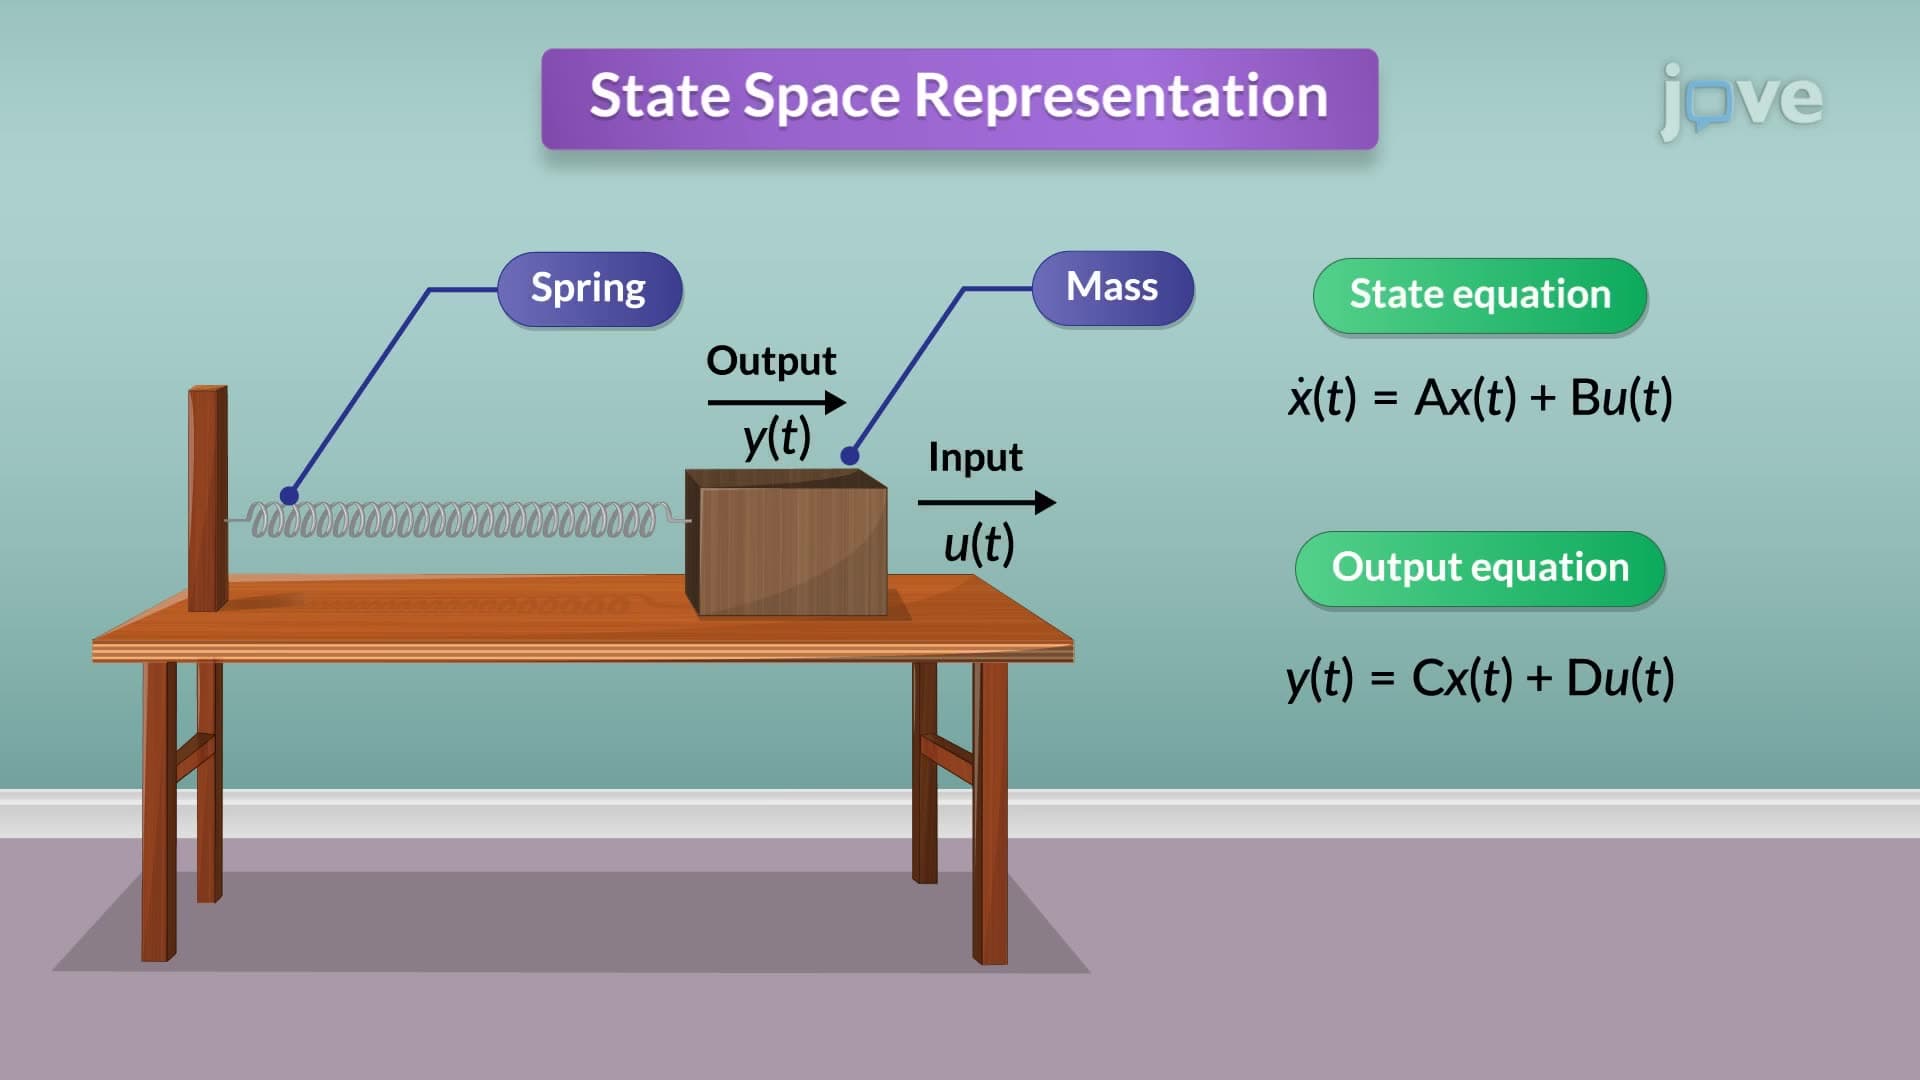
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:11
Deformation of Member under Multiple Loadings
In the case of a member with a variable cross-section, the strain is not constant but depends on the position. The deformation of an...
 01:12
Temperature Dependent Deformation