Related Experiment Video
Updated: Dec 25, 2025


Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Anisotropic electroactive elastomer for highly maneuverable soft robotics
Youhua Xiao1, Jie Mao, Yejie Shan
1The State Key Laboratory of Chemical Engineering, College of Chemical and Biological Engineering, Zhejiang University, 310027, China. yingwu.luo@zju.edu.cn.

Abstract:
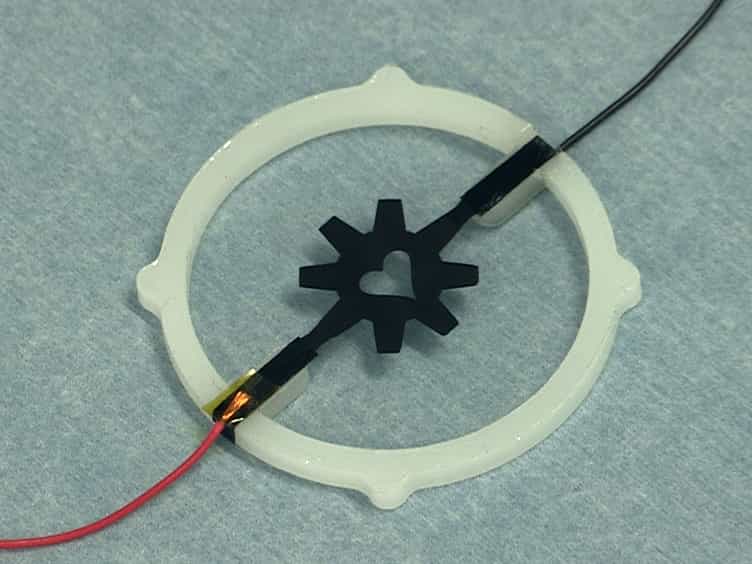
Dielectric elastomers (DEs) are promising electroactive artificial muscles for use in soft machines. However, achieving anisotropy and sub-kV actuation voltage remains a great challenge for DE actuators. Herein, we report a facile method to fabricate ultrathin anisotropic DE films of an amorphous triblock copolymer poly(styrene-b-butyl acrylate-b-styrene) (SBAS) for soft actuators. The modulus of anisotropic SBAS in one direction can be modulated from 0.3 MPa to 10.5 MPa, and the modulus in the orthogonal direction remains the same as that of the pristine film (0.3 MPa). The anisotropy endows soft DE actuators with the directional-preferred response to an applied electric field and programmable multiple actuation morphs. These anisotropic SBAS films allowed us to fabricate compact soft robotics with high maneuverability, including soft grippers for object manipulation and crawling robots with reversible moving ability under an actuation voltage around 800 V.