Onset and limiting amplitude of yaw instability of a submerged three-tethered buoy
Related Experiment Video
Updated: Dec 24, 2025
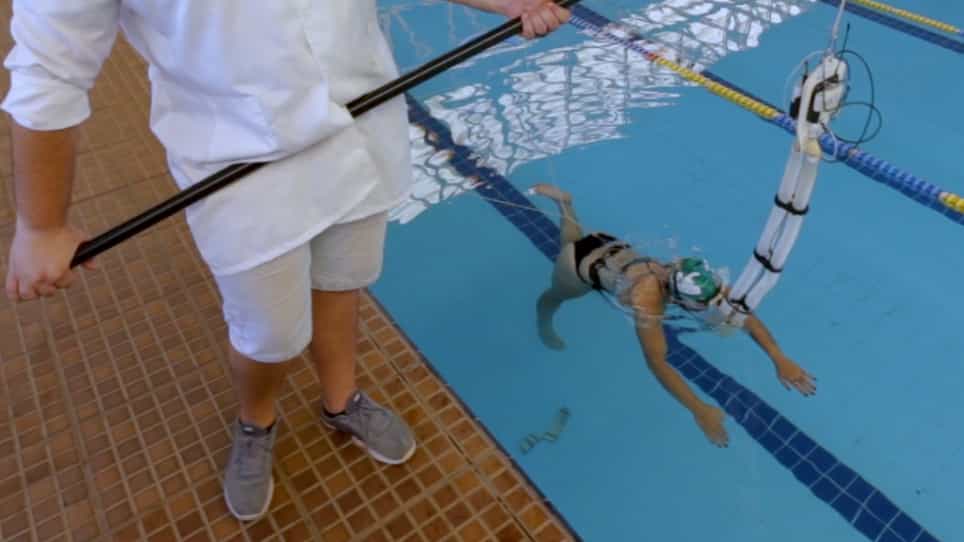
A Rapidly Incremented Tethered-Swimming Maximal Protocol for Cardiorespiratory Assessment of Swimmers
Published on: January 28, 2020
J Orszaghova1,2, H Wolgamot1,2, S Draper1,2
1Faculty of Engineering and Mathematical Sciences, University of Western Australia, WA 6009, Australia.

Abstract:
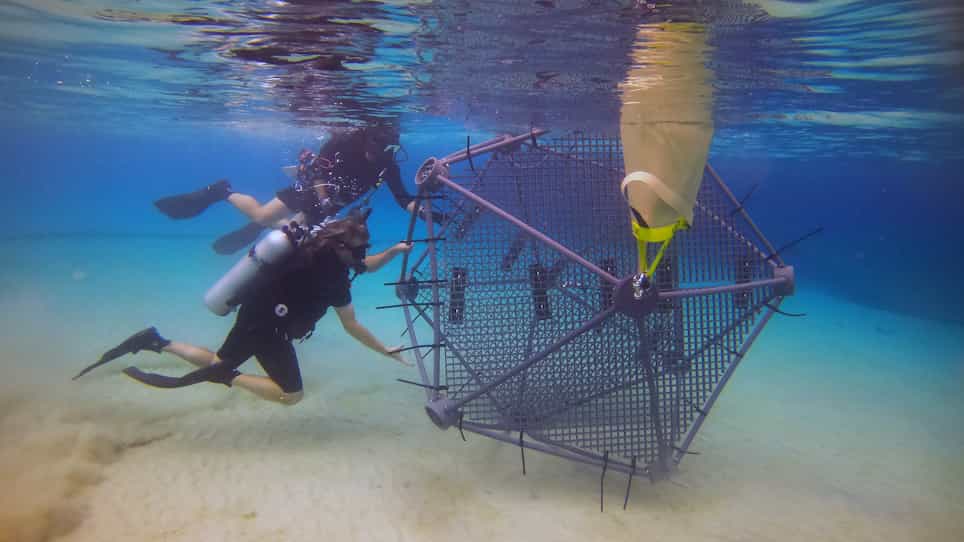
In this paper the dynamics of a submerged axi-symmetric wave energy converter are studied, through mathematical models and wave basin experiments. The device is disk-shaped and taut-moored via three inclined tethers which also act as a power take-off. We focus on parasitic yaw motion, which is excited parametrically due to coupling with heave. Assuming linear hydrodynamics throughout, but considering both linear and nonlinear tether geometry, governing equations are derived in 6 degrees of freedom (DOF). From the linearized equations, all motions, apart from yaw, are shown to be contributing to the overall power absorption. At higher orders, the yaw governing equation can be recast into a classical Mathieu equation (linear in yaw), or a nonlinear Mathieu equation with cubic damping and stiffness terms. The well-known stability diagram for the classical Mathieu equation allows prediction of onset/occurrence of yaw instability. From the nonlinear Mathieu equation, we develop an approximate analytical solution for the amplitude of the unstable motions. Comparison with regular wave experiments confirms the utility of both models for making relevant predictions. Additionally, irregular wave tests are analysed whereby yaw instability is successfully correlated to the amount of parametric excitation and linear damping. This study demonstrates the importance of considering all modes of motion in design, not just the power-producing ones. Our simplified 1 DOF yaw model provides fundamental understanding of the presence and severity of the instability. The methodology could be applied to other wave-activated devices.
Related Concept Videos
 01:11
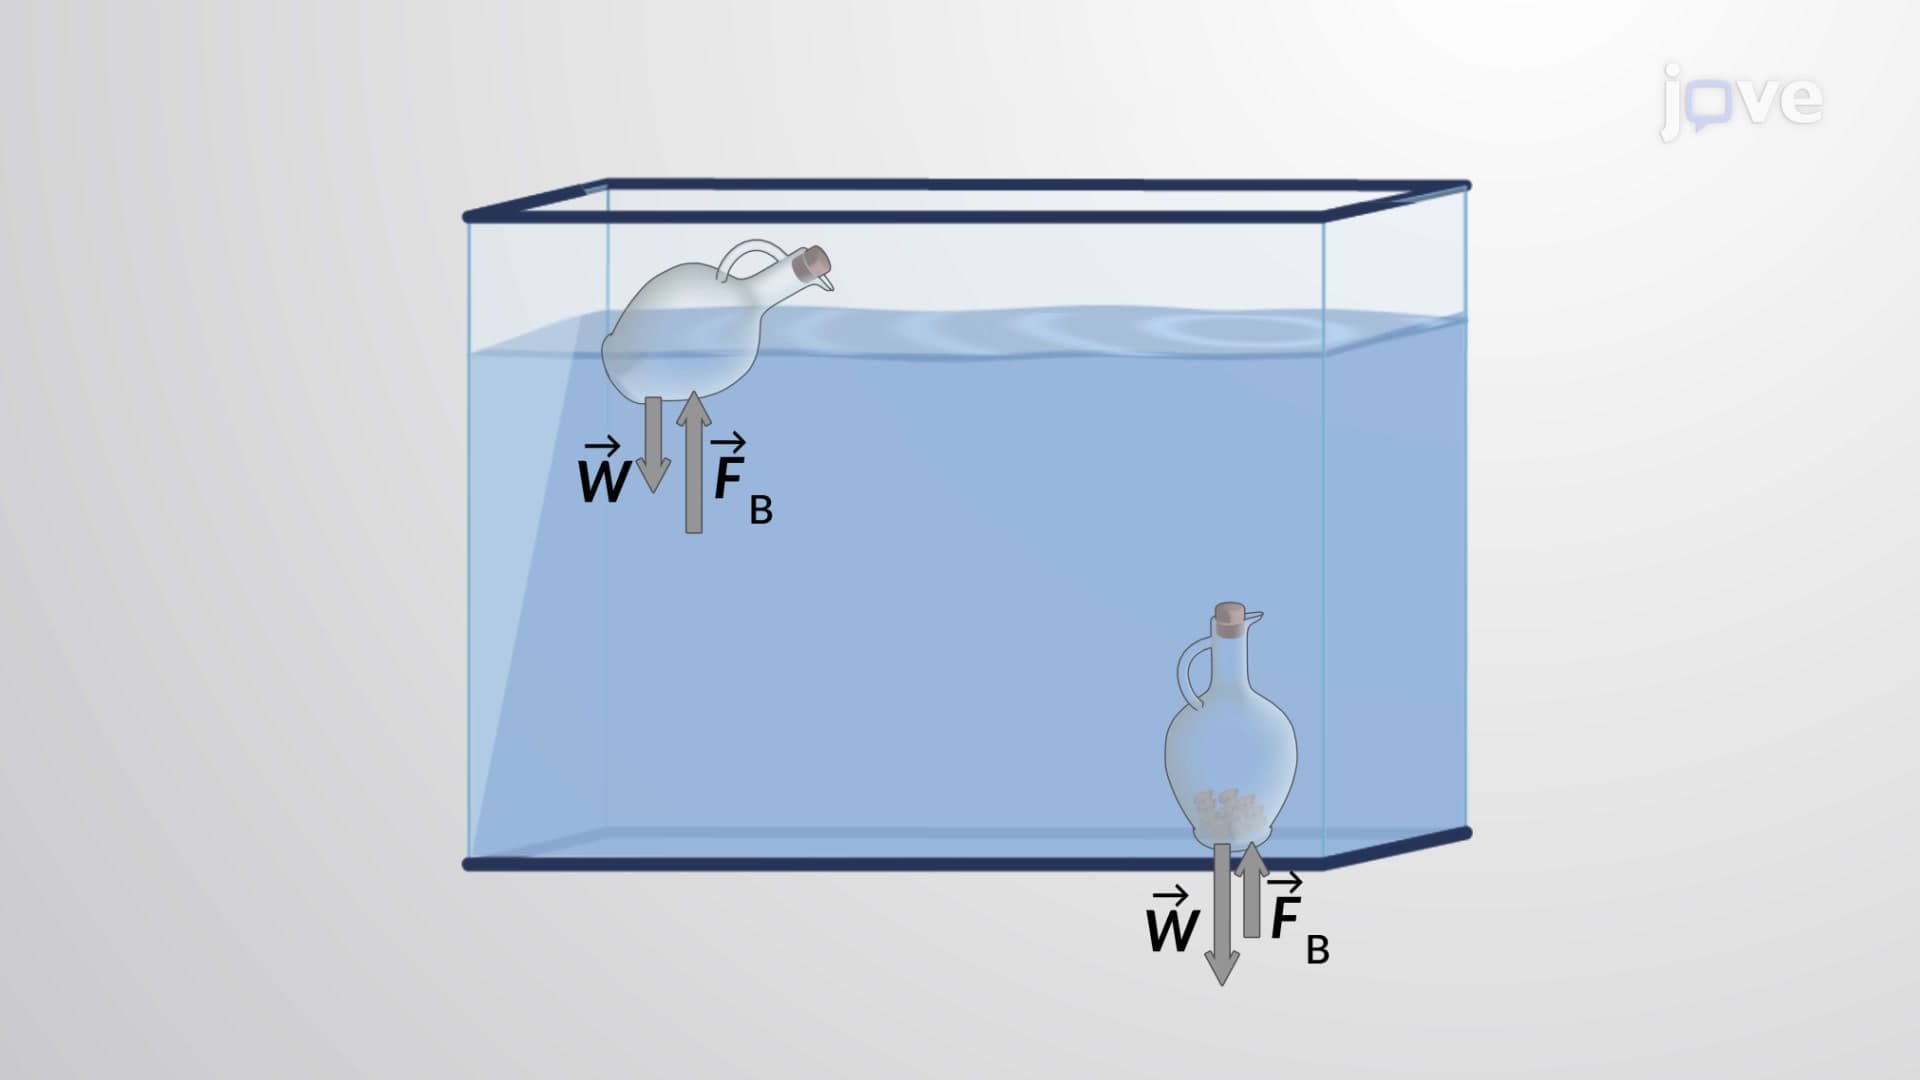
Buoyancy and Stability for Submerged and Floating Bodies
 01:12
Buoyancy
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:07
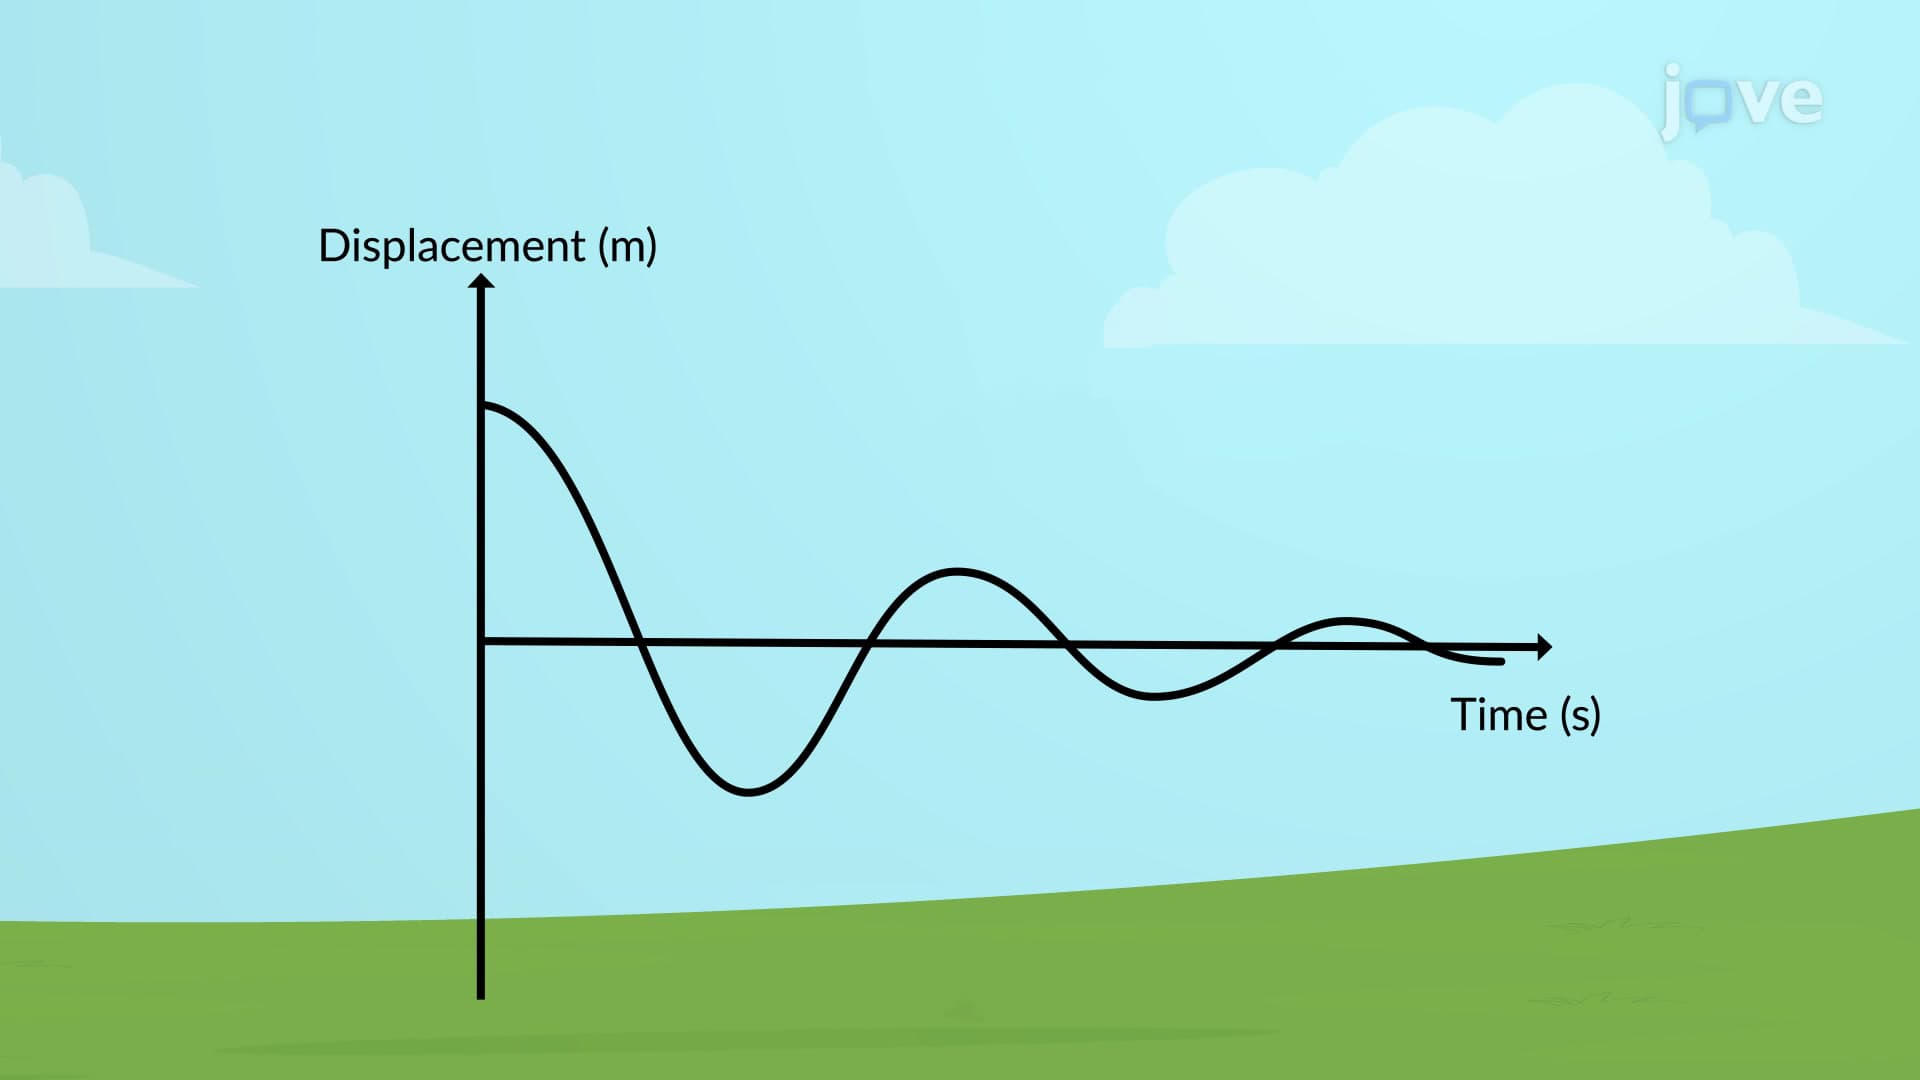
Damped Oscillations
Although friction and other non-conservative...
 01:20
Types of Damping
 01:09
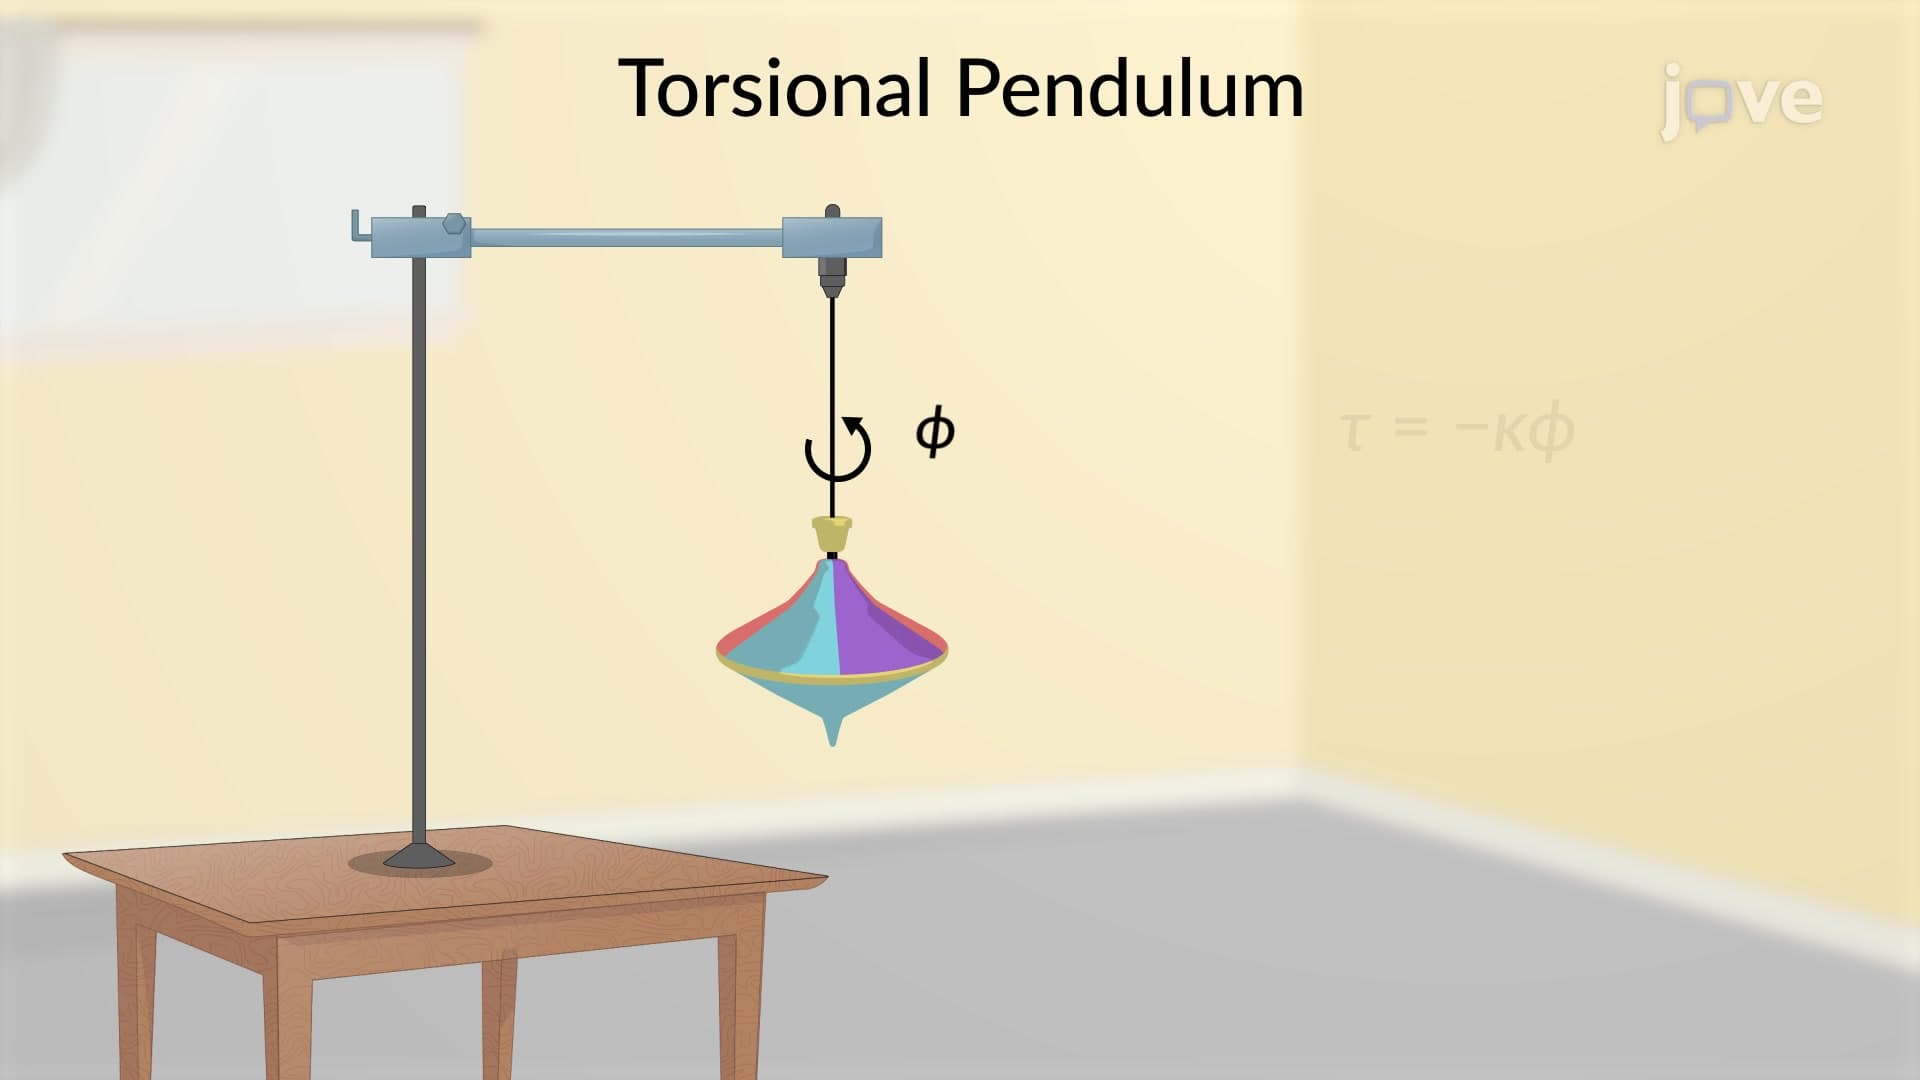
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...