Related Experiment Video
Updated: Dec 24, 2025
Hand Controlled Manipulation of Single Molecules via a Scanning Probe Microscope with a 3D Virtual Reality Interface
Published on: October 2, 2016
Robotic Trajectories and Morphology Manipulation of Single Particle and Granular Materials by a Vibration Tweezer
Zewei Hou1, Zhitao Zhou1, Peng Liu1
1State Key Lab for Turbulence and Complex Systems, College of Engineering, Peking University, Beijing, China.

Abstract:
Robotic self-assembly of deformable materials holds potential for the automatic construction of complex robots. Current manipulation for deformable manipulation mainly focuses on a soft robot. It still remains a great challenge for morphology manipulation of a swarm of particles. Chladni patterns have raised great interest in the field of self-assembly for different materials. The formation of Chladni patterns is driven by the vibration process that involves the particles moving from disorder to order. Particles bounce randomly on the plate, and gradually accumulate along nodal lines, whereas the instantaneous random effect is inevitable, meaning that the trajectories of particles are uncertain. Here, the vibration tweezer is proposed by programmable two-frequency driving Chladni patterns. Different materials can be precisely and flexibly trapped to the vibration node. The vibration tweezer is further programmed for arbitrary positions by solving the vibration inverse problem. Then, different controllable trajectories "PKU" manipulation of particle can be achieved through switching the tweezer positions. Most importantly, the vibration tweezer exhibits the morphology of granular materials assemblages with collection, motion, and rotation. This work paves the way for the control of complex self-assembly, thereby enabling programmable manipulation of granular materials and micro robots.
More Related Videos
 11:28
3D Orbital Tracking in a Modified Two-photon Microscope: An Application to the Tracking of Intracellular Vesicles
Published on: October 1, 2014
 09:00
Visualization of Failure and the Associated Grain-Scale Mechanical Behavior of Granular Soils under Shear using Synchrotron X-Ray Micro-Tomography
Published on: September 29, 2019
Related Concept Videos
 01:08
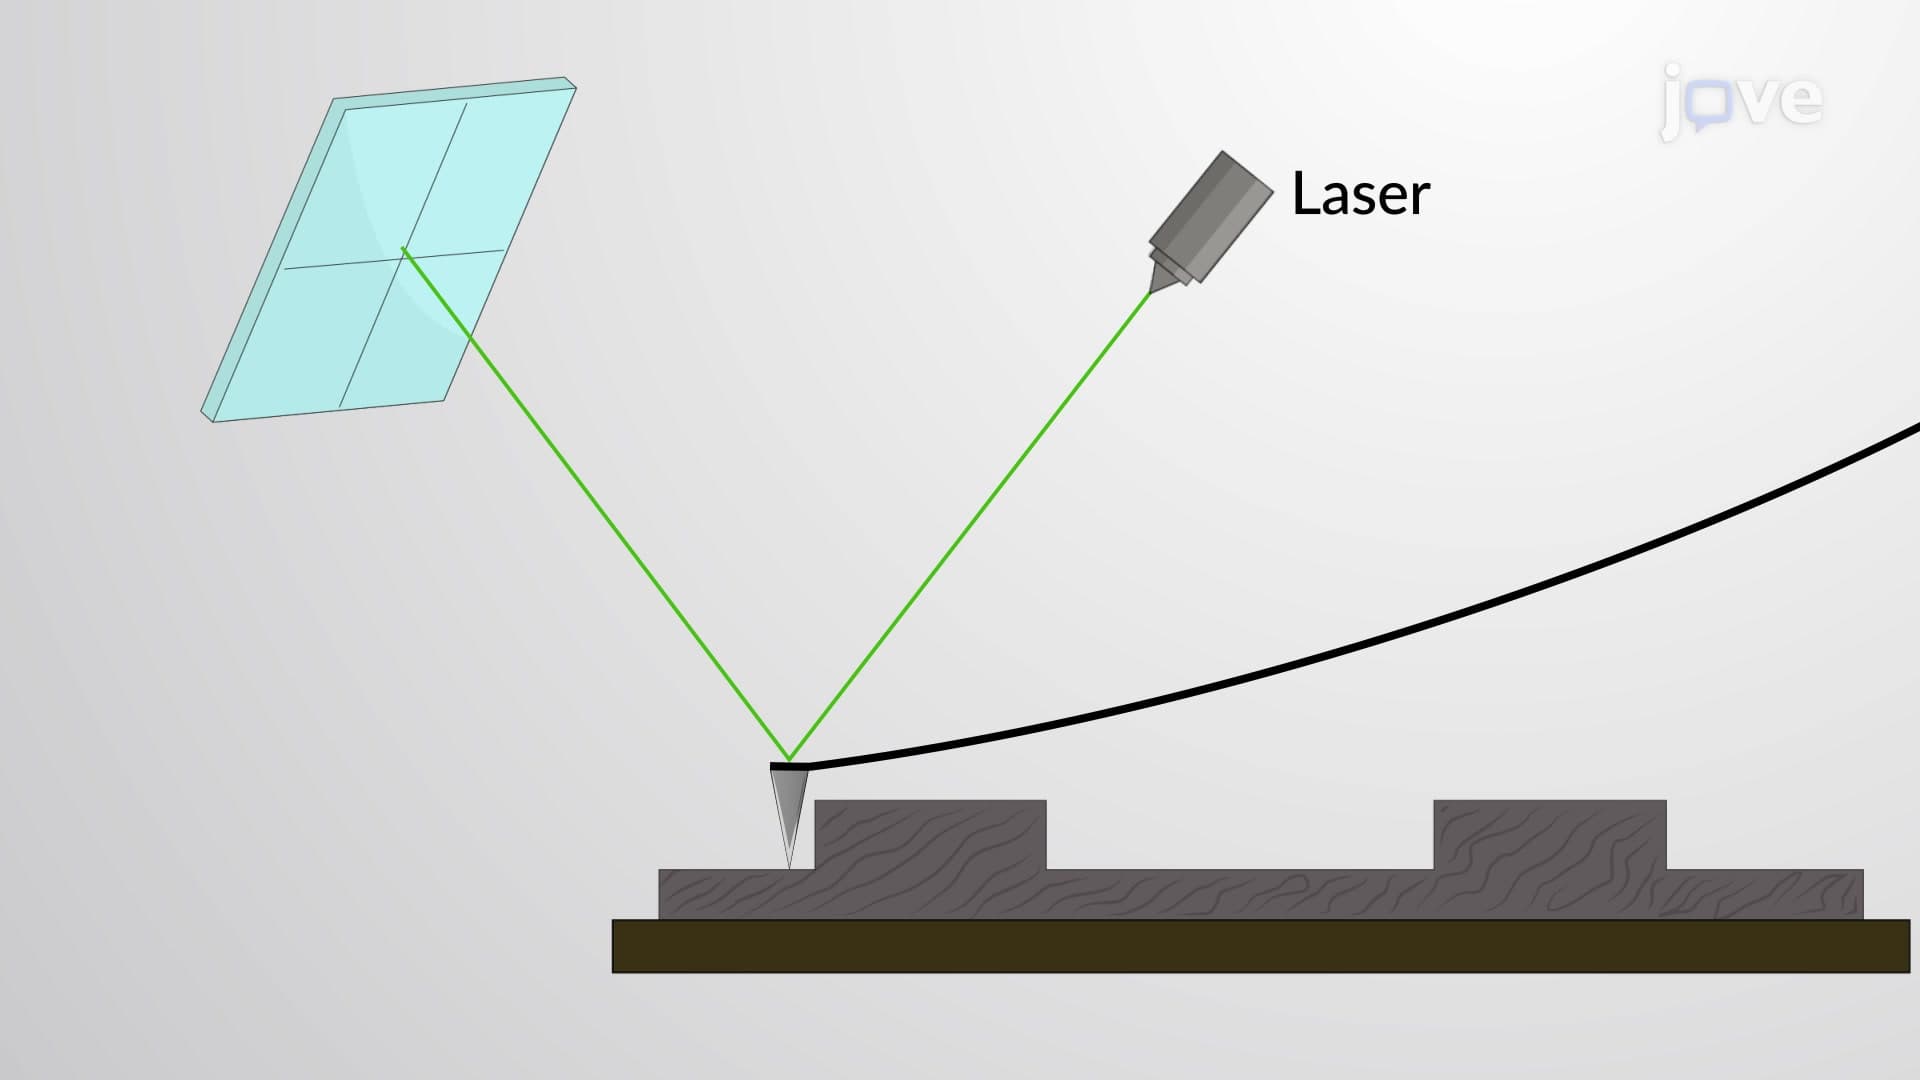
Atomic Force Microscopy
The AFM Probe
The probe is regarded as the heart of any AFM setup and comprises the...
 01:07
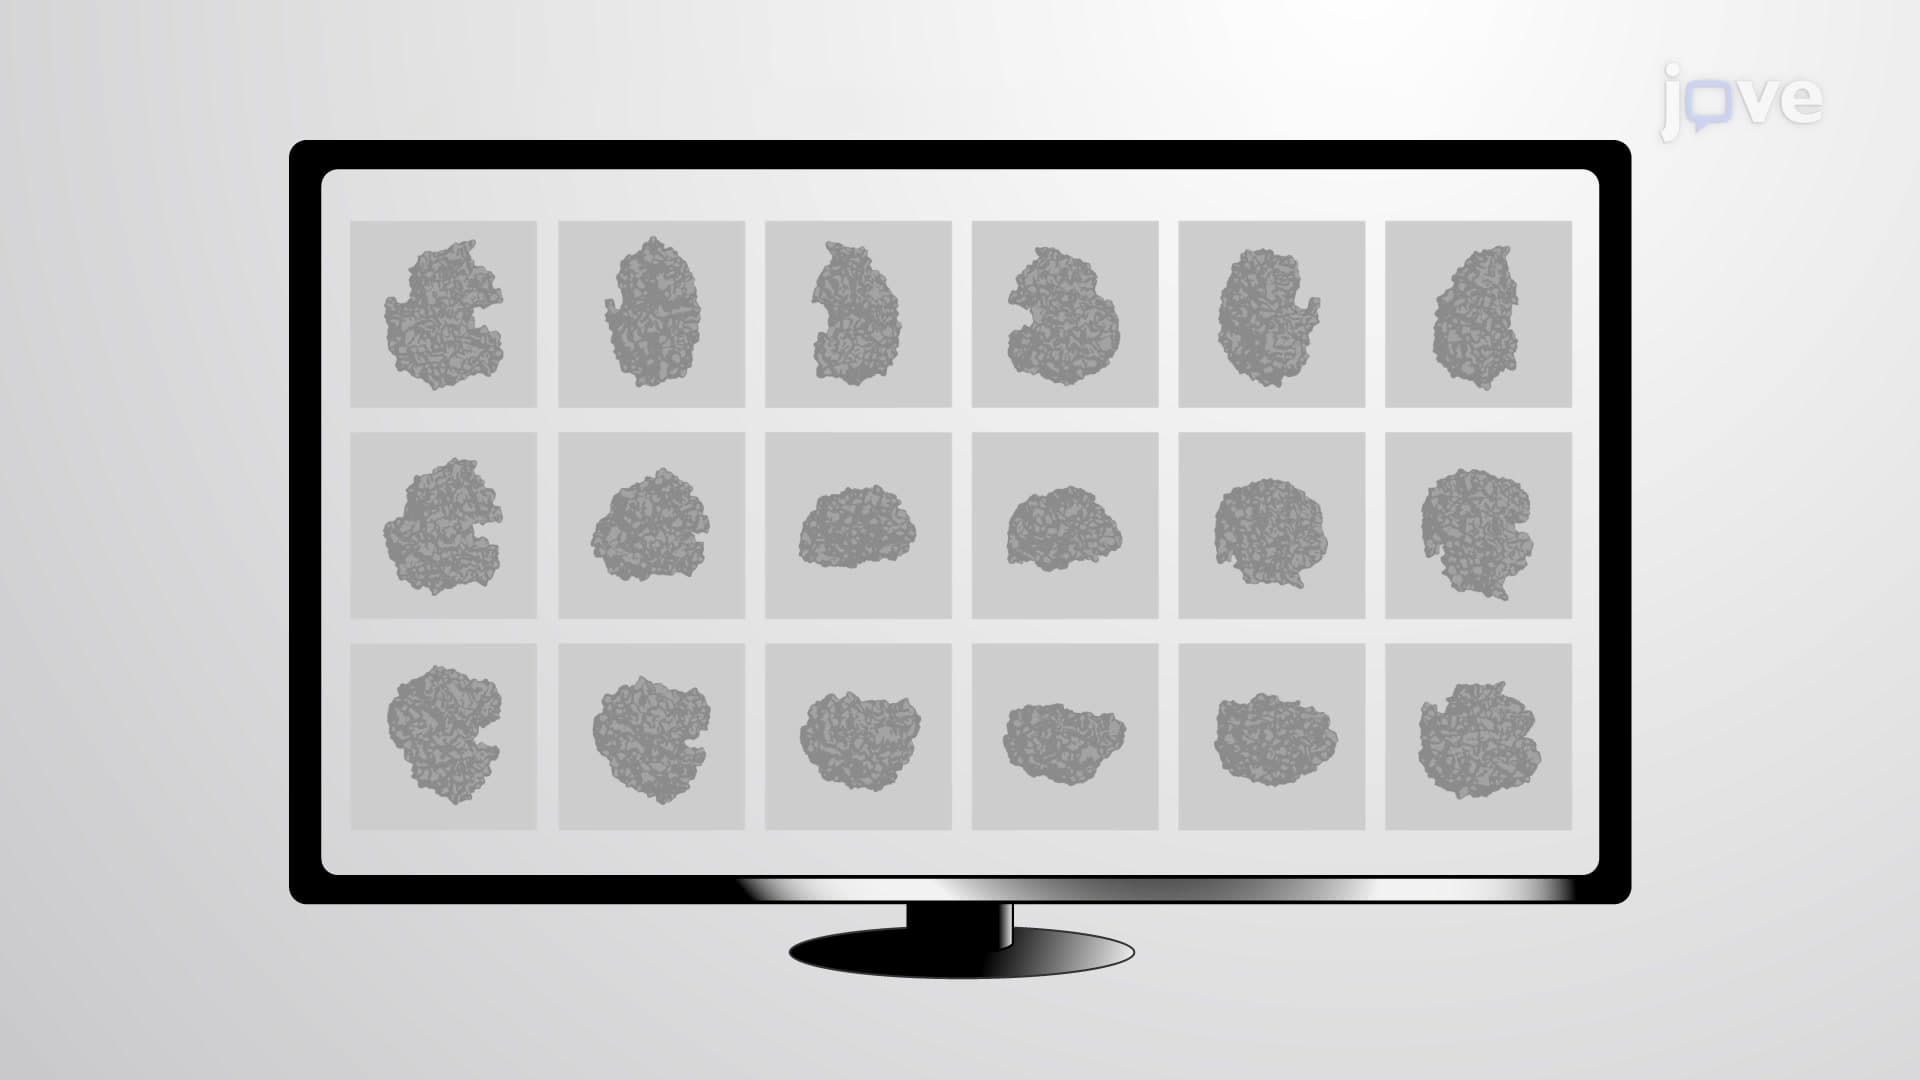
Electron Microscope Tomography and Single-particle Reconstruction
Electron Tomography
Electron tomography can be performed either in TEM or STEM (scanning transmission...