Related Experiment Video
Updated: Dec 24, 2025

Optimizing Minimally Invasive Spine Surgery: A Fully 3D CT O-Arm Navigated Workflow in MIS TLIF
Published on: October 17, 2025
Navigated Spinal Robotics in Minimally Invasive Spine Surgery, With Preoperative and Intraoperative Workflows:
Martin H Pham1, Joseph A Osorio1, Ronald A Lehman2
1Department of Neurosurgery, University of California San Diego School of Medicine, San Diego, California.

Abstract:
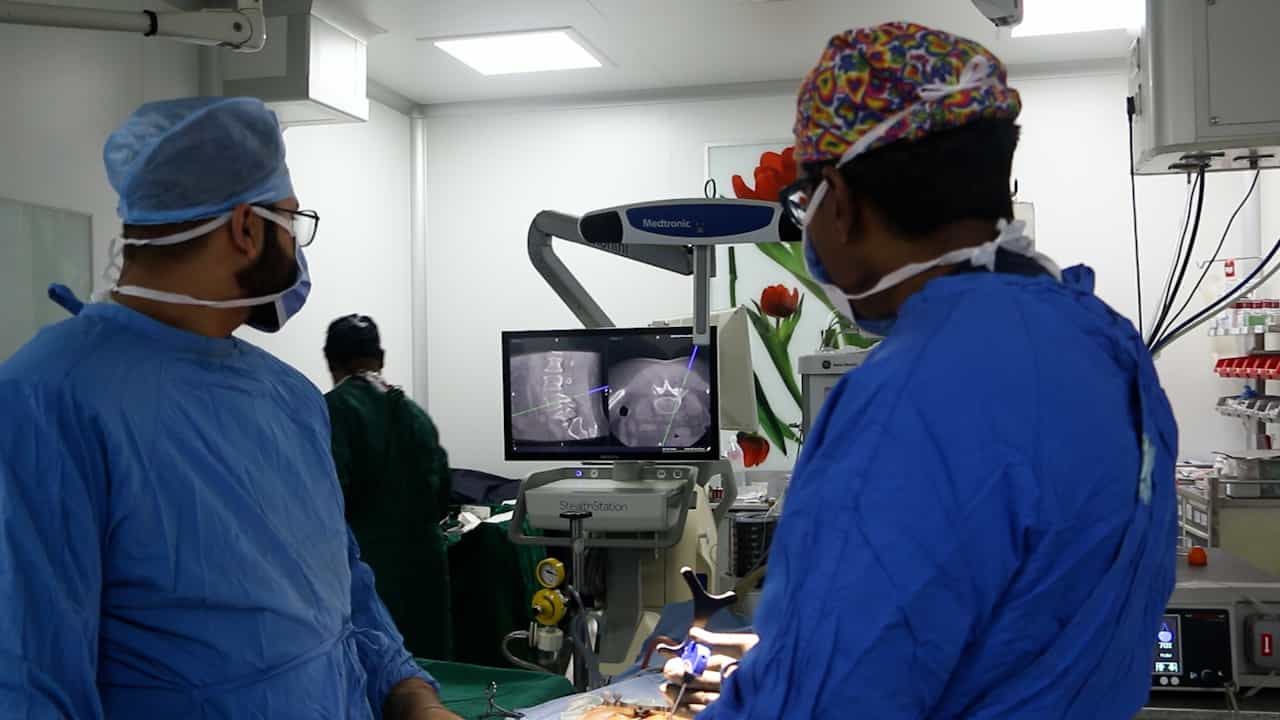
The use of robotic guidance for spinal instrumentation has become promising for its ability to offer the advantages of precision, accuracy, and reproducibility. However, the utilization and adoption of robotic platforms for spine surgery remain limited, especially in comparison to other surgical fields. We present here a case of a 52-yr-old man with a grade 1 L4-5 degenerative spondylolisthesis causing severe claudication and radiculopathy who subsequently underwent a minimally invasive L4-5 transforaminal lumbar interbody fusion with navigated spinal robotic assistance (Mazor X Stealth Edition, Mazor Robotics Ltd, Caesarea, Israel). This platform allows for planning and registration via (1) a preoperative thin-cut computed tomography (CT) scan, or (2) an intraoperative CT "scan-and-plan" method. We show here the preoperative CT method that we use in the majority of our patients. To our knowledge, this is the first video demonstrating the preoperative software and intraoperative surgical registration and instrument workflow of navigated spinal robotic guidance using the Mazor X Stealth Edition for the insertion of pedicle screws in a minimally invasive spine surgery procedure. There is no identifying information in this video. Patient consent was obtained for the surgical procedure and for publishing of the material included in the video.