Related Experiment Video
Updated: Dec 23, 2025


Studying the Neural Basis of Adaptive Locomotor Behavior in Insects
Published on: April 13, 2011
A System for Simple Robotic Walking Assistance With Linear Impulses at the Center of Mass

Abstract:
Walking can be simplified as an inverted pendulum motion where both legs generate linear impulses to redirect the center of mass (COM) into every step. In this work, we describe a system to assist walking in a simpler way than exoskeletons by providing linear impulses directly at the COM instead of providing torques at the joints. We developed a novel waist end-effector and high-level controller for an existing cable-robot. The controller allows for the application of cyclic horizontal force profiles with desired magnitudes, timings, and durations based on detection of the step timing. By selecting a lightweight rubber series elastic element with optimal stiffness and carefully tuning the gains of the closed-loop proportional-integral-derivative (PID) controller in a number of single-subject experiments, we were able to reduce the within-step root mean square error between desired and actual forces up to 1.21% of body weight. This level of error is similar or lower compared to the performance of other robotic tethers designed to provide variable or constant forces at the COM. The system can produce force profiles with peaks of up to 15 ± 2% of body weight within a root mean square error (RMSE) of 2.5% body weight. This system could be used to assist patient populations that require levels of assistance that are greater than current exoskeletons and in a way that does not make the user rely on vertical support.


Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:14
Equation of Motion: Center of Mass
Internal forces between any pair of particles manifest as collinear pairs of equal magnitude but opposite directions,...
 01:23
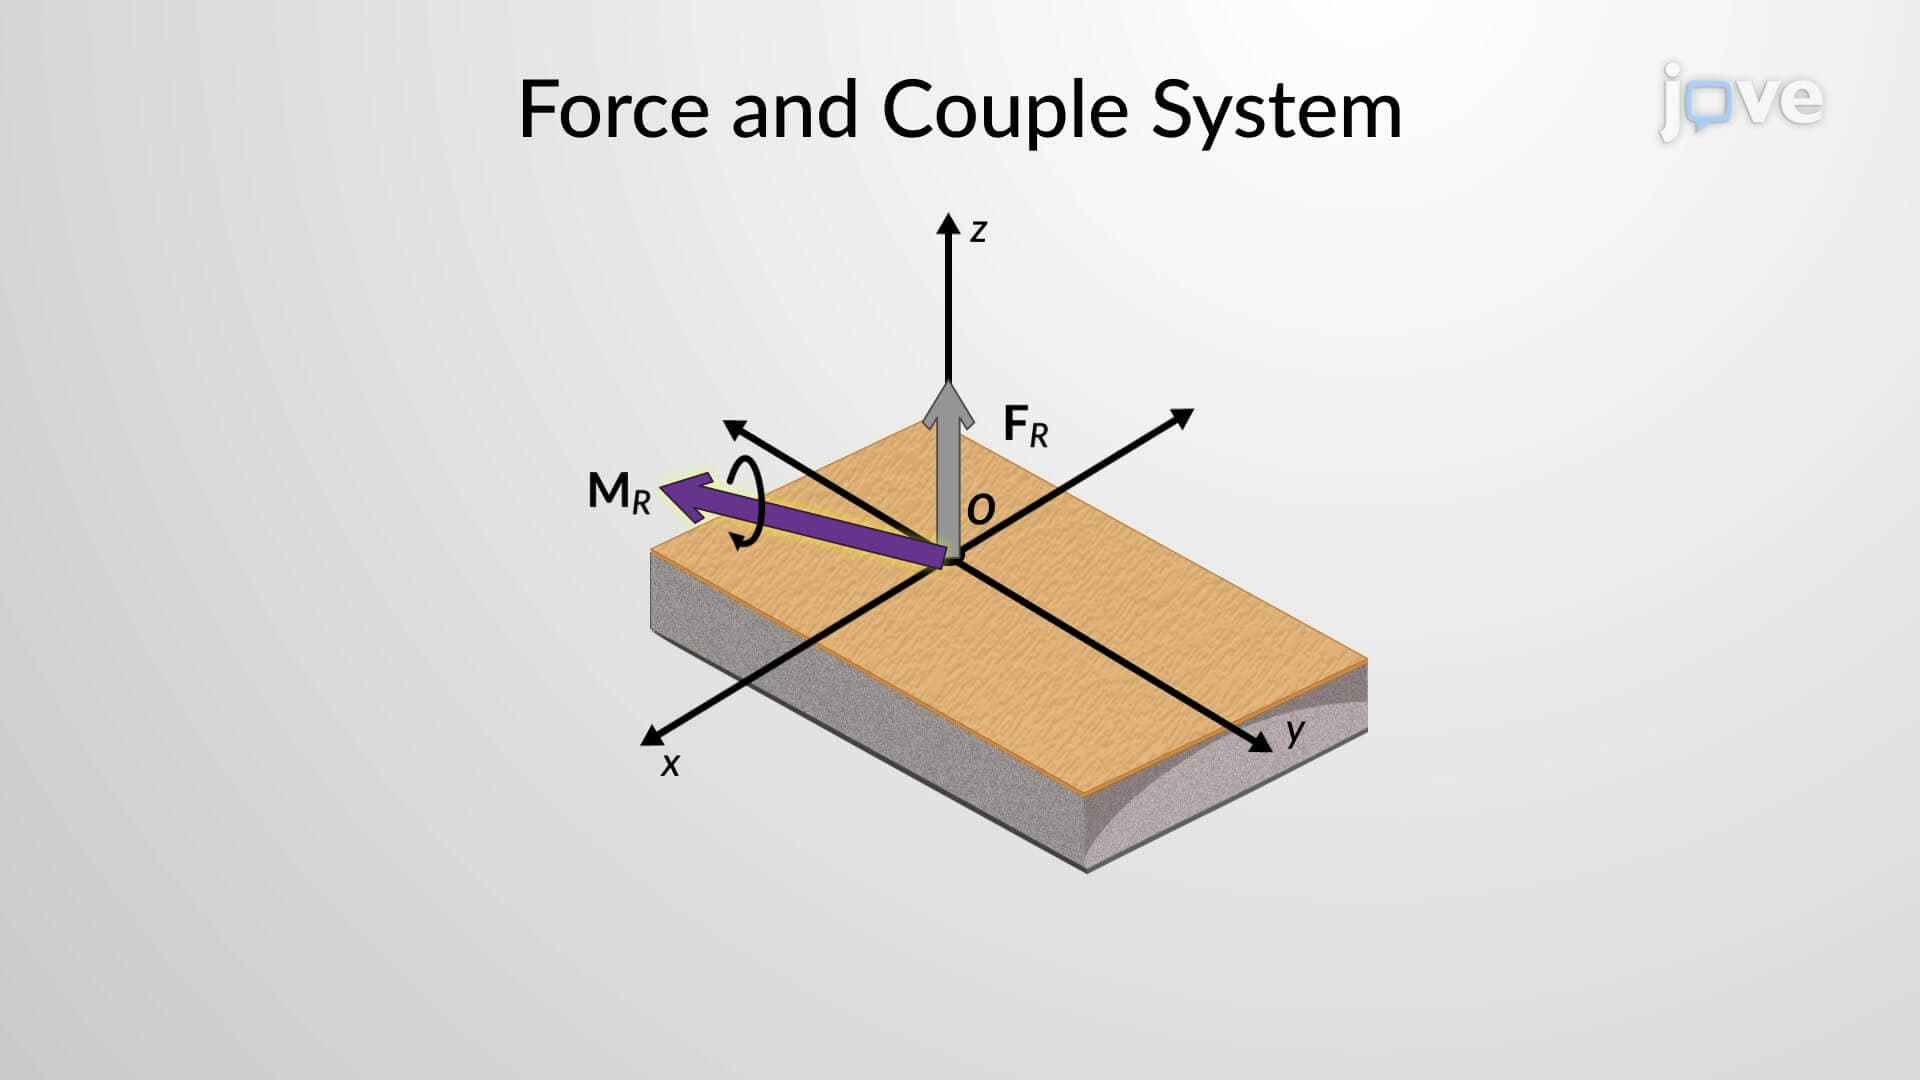
Simplification of a Force and Couple System: II
 01:26
Rotational Motion about a Fixed Axis
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:03
Center of Mass: Introduction