Related Experiment Video
Updated: Aug 7, 2026

Simultaneous Recording of Electroretinography and Visual Evoked Potentials in Anesthetized Rats
Published on: July 1, 2016
Parameters of exponentially damped sinusoids in noise and their application to the analysis of visual evoked
1Department of Scientific Instrumentation, Zhejing University, Hang Zhou, People's Republic of China.

Abstract:
The backward prediction and singular value (SV) truncation methods for estimating multiple exponentially damped real sinusoids in noise have been studied. The basic theory and algorithm are outlined, and the effect on the error of computational parameters, such as the sampling window, the sampling rate, the order of the prediction-error filter (PEF) and the truncated point of SV, were studied using simulated data. If the computational parameters are carefully chosen, the estimate of frequency and damping factor of a damped sinusoid is quite accurate (within a certain range of signal to noise (S/N) ratio). We use this method to estimate the parameters of visual evoked potentials (VEP) and then reconstructed them from estimated parameters according to the resonant model. The error between original VEP and the reconstructed waveform is within 5%. This method can be used in the analysis and recognition of various systems.
Related Concept Videos
 01:20
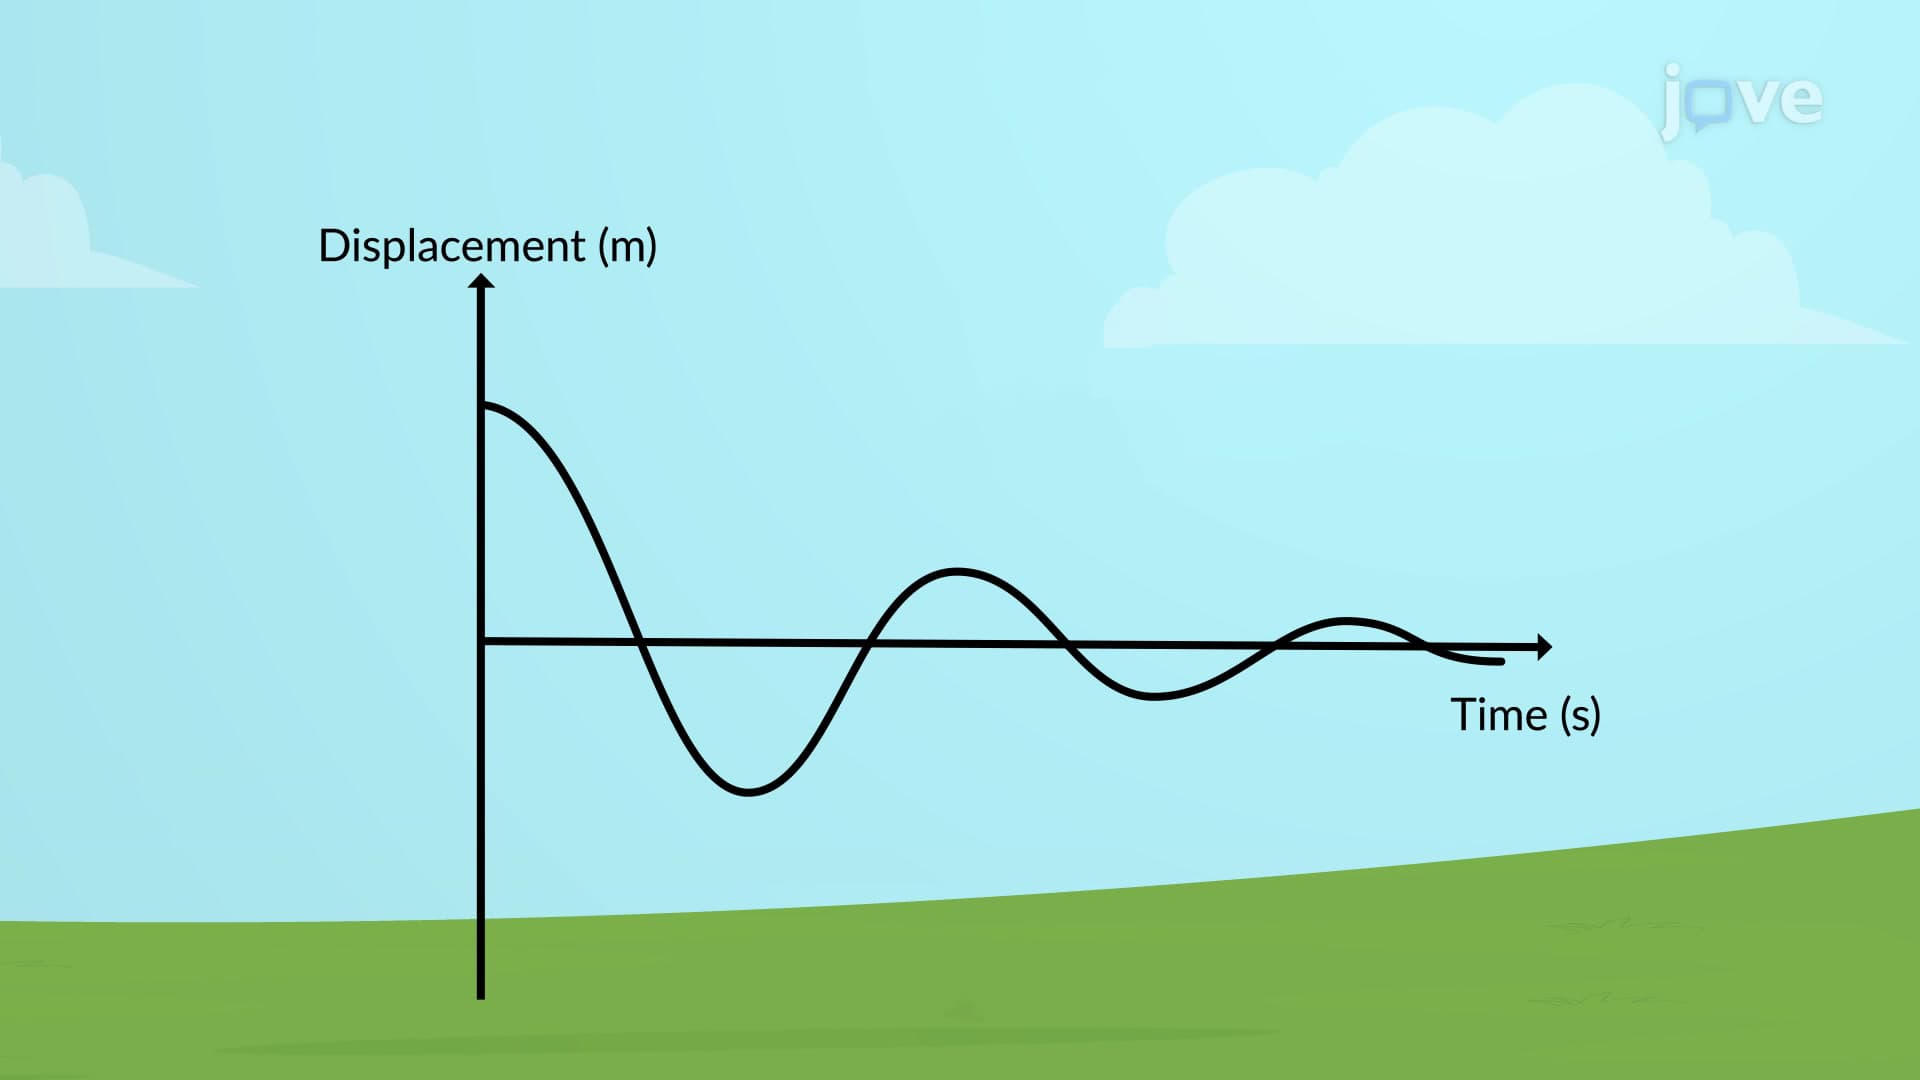
Types of Damping
 01:11
Types of Responses of Series RLC Circuits
 01:20
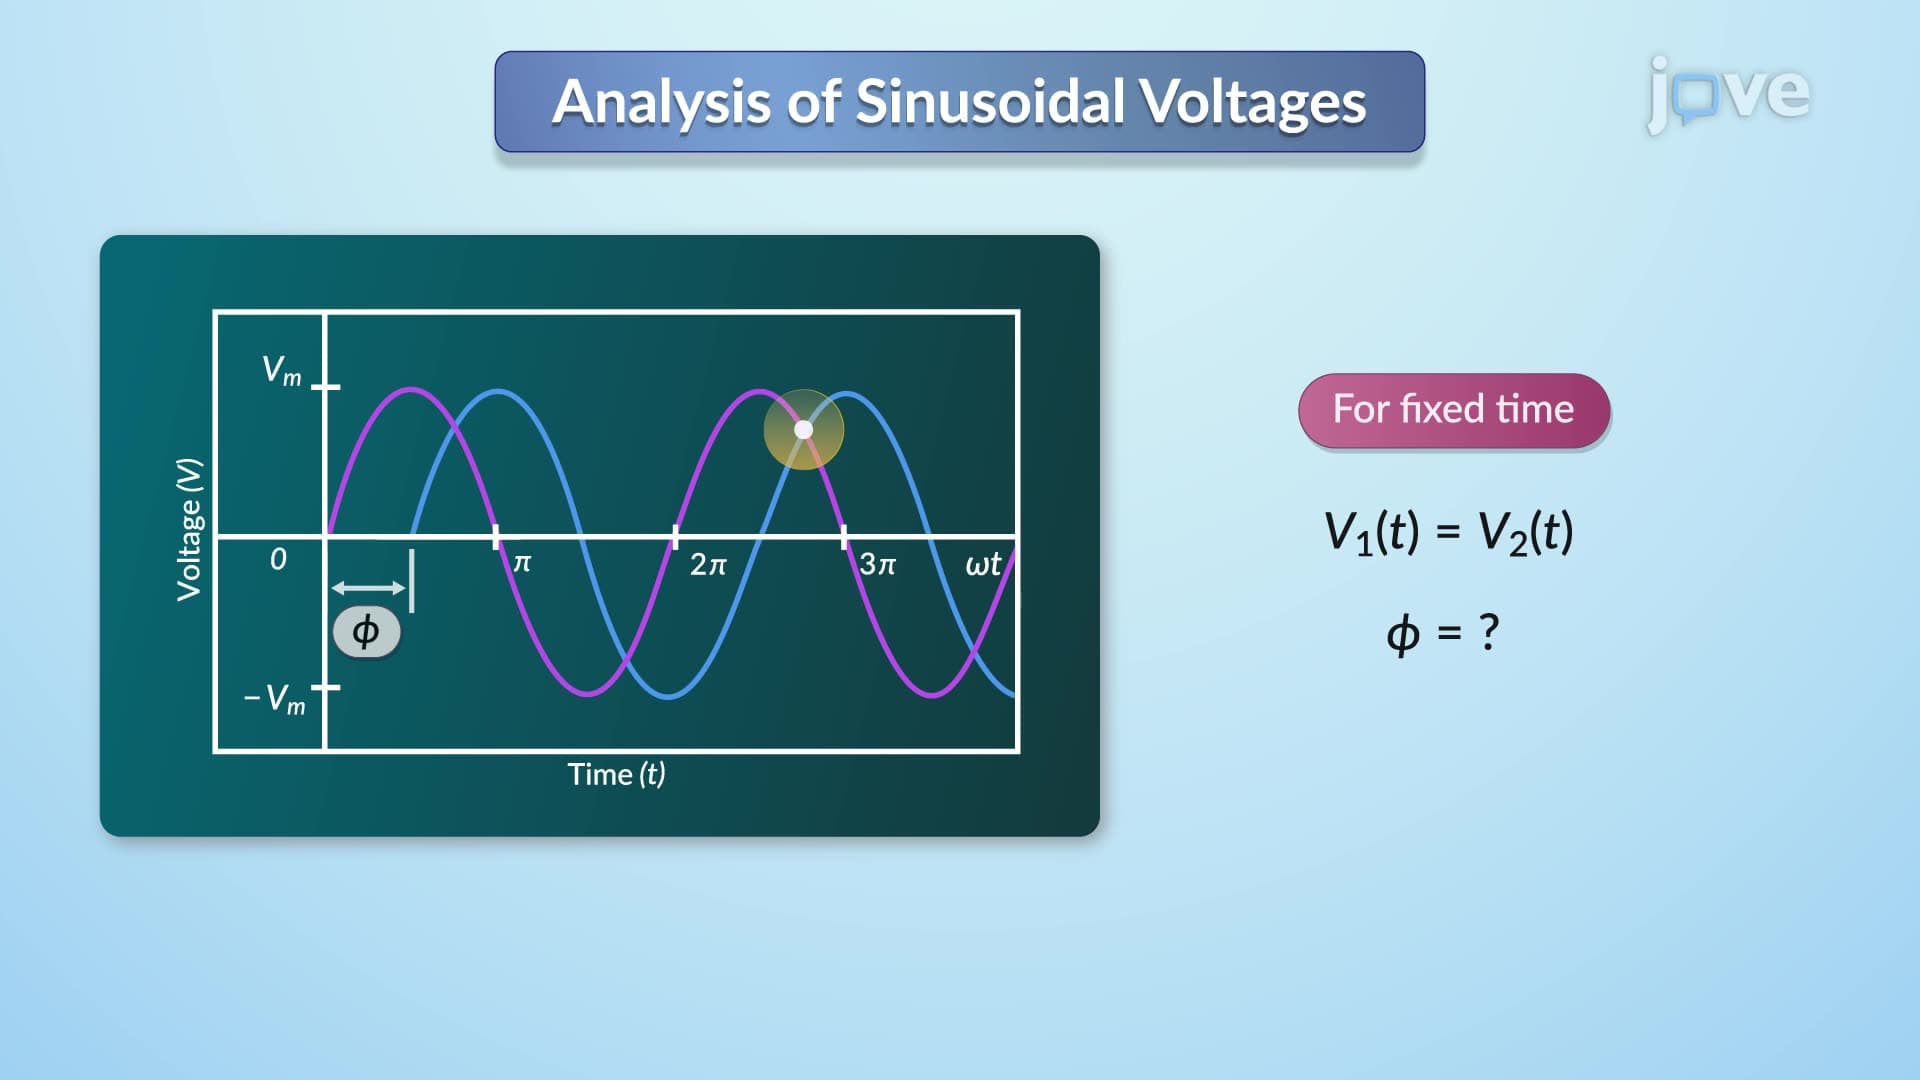
Graphical and Analytic Representation of Sinusoids
The first step is measuring the peak-to-peak value, which is twice the amplitude of the sinusoid. This provides information about the maximum voltage swing of the waveform.
Secondly, the period and angular frequency are determined. The period is the time taken for one complete cycle of the waveform, while...
 01:18
Exponential and Sinusoidal Signals
 01:16
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:18
Second Order systems II
If ζ...