Non-weighted L2 gain and asynchronous H∞ control for continuous-time switched T-S fuzzy systems
Related Experiment Video
Updated: Dec 21, 2025

An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
Can Liu1, Yang Li1, Qunxian Zheng2
1School of Information and Communication Engineering, University of Electronic Science and Technology of China, Chengdu 611731, Sichuan, PR China.

Abstract:
This article considers the non-weighted L2 gain and asynchronous H∞ control issues for continuous-time switched nonlinear systems. Firstly, Takagi-Sugeno (T-S) fuzzy models are employed to describe the nonlinear subsystems. By taking full advantage of the asynchronous features, a novel time-varying fuzzy Lyapunov function (TVFLF) and the corresponding controllers are all constructed separately in synchronous and asynchronous intervals. Based on the TVFLF approach, sufficient conditions of asynchronous H∞ controller are established. Finally, two simulation examples are discussed to certify the effectiveness of the proposed results.
More Related Videos
 08:35
Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Transfer Function in Control Systems
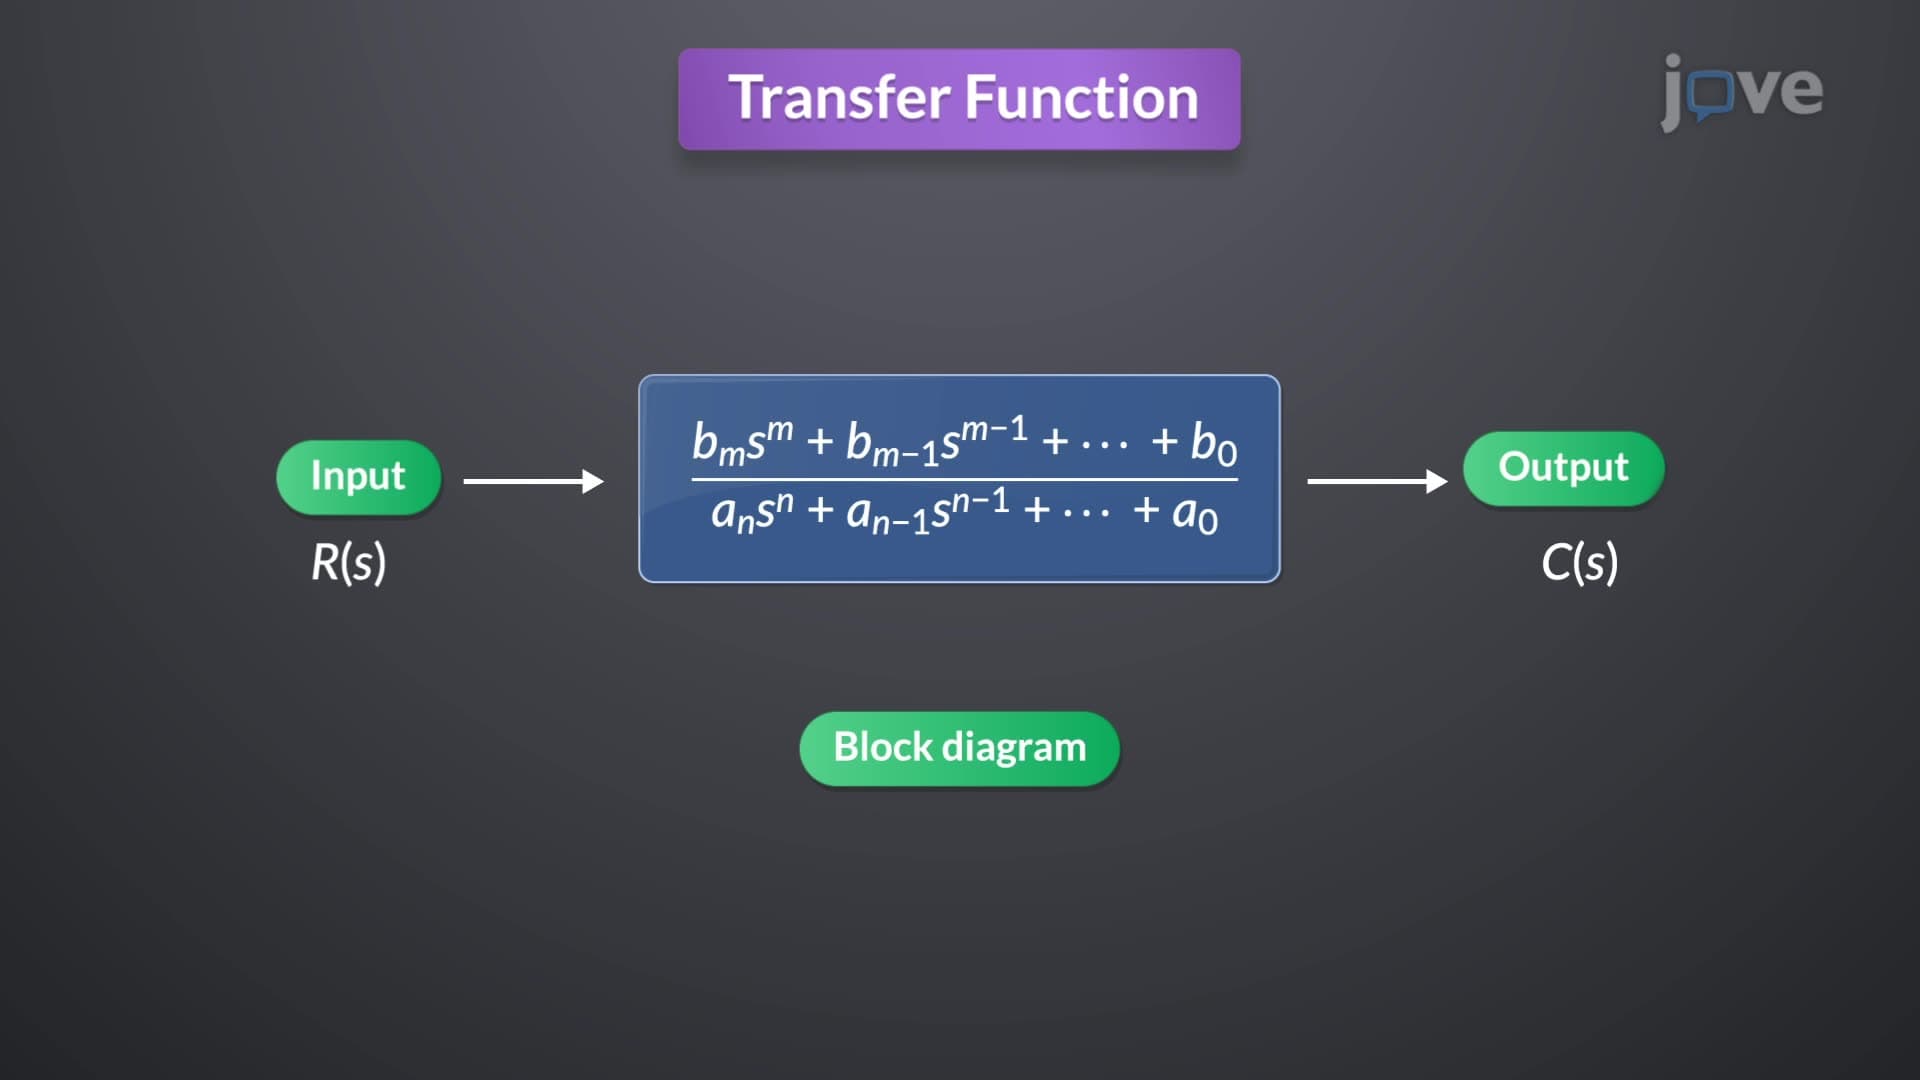
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:23
Root Loci for Positive-Feedback Systems
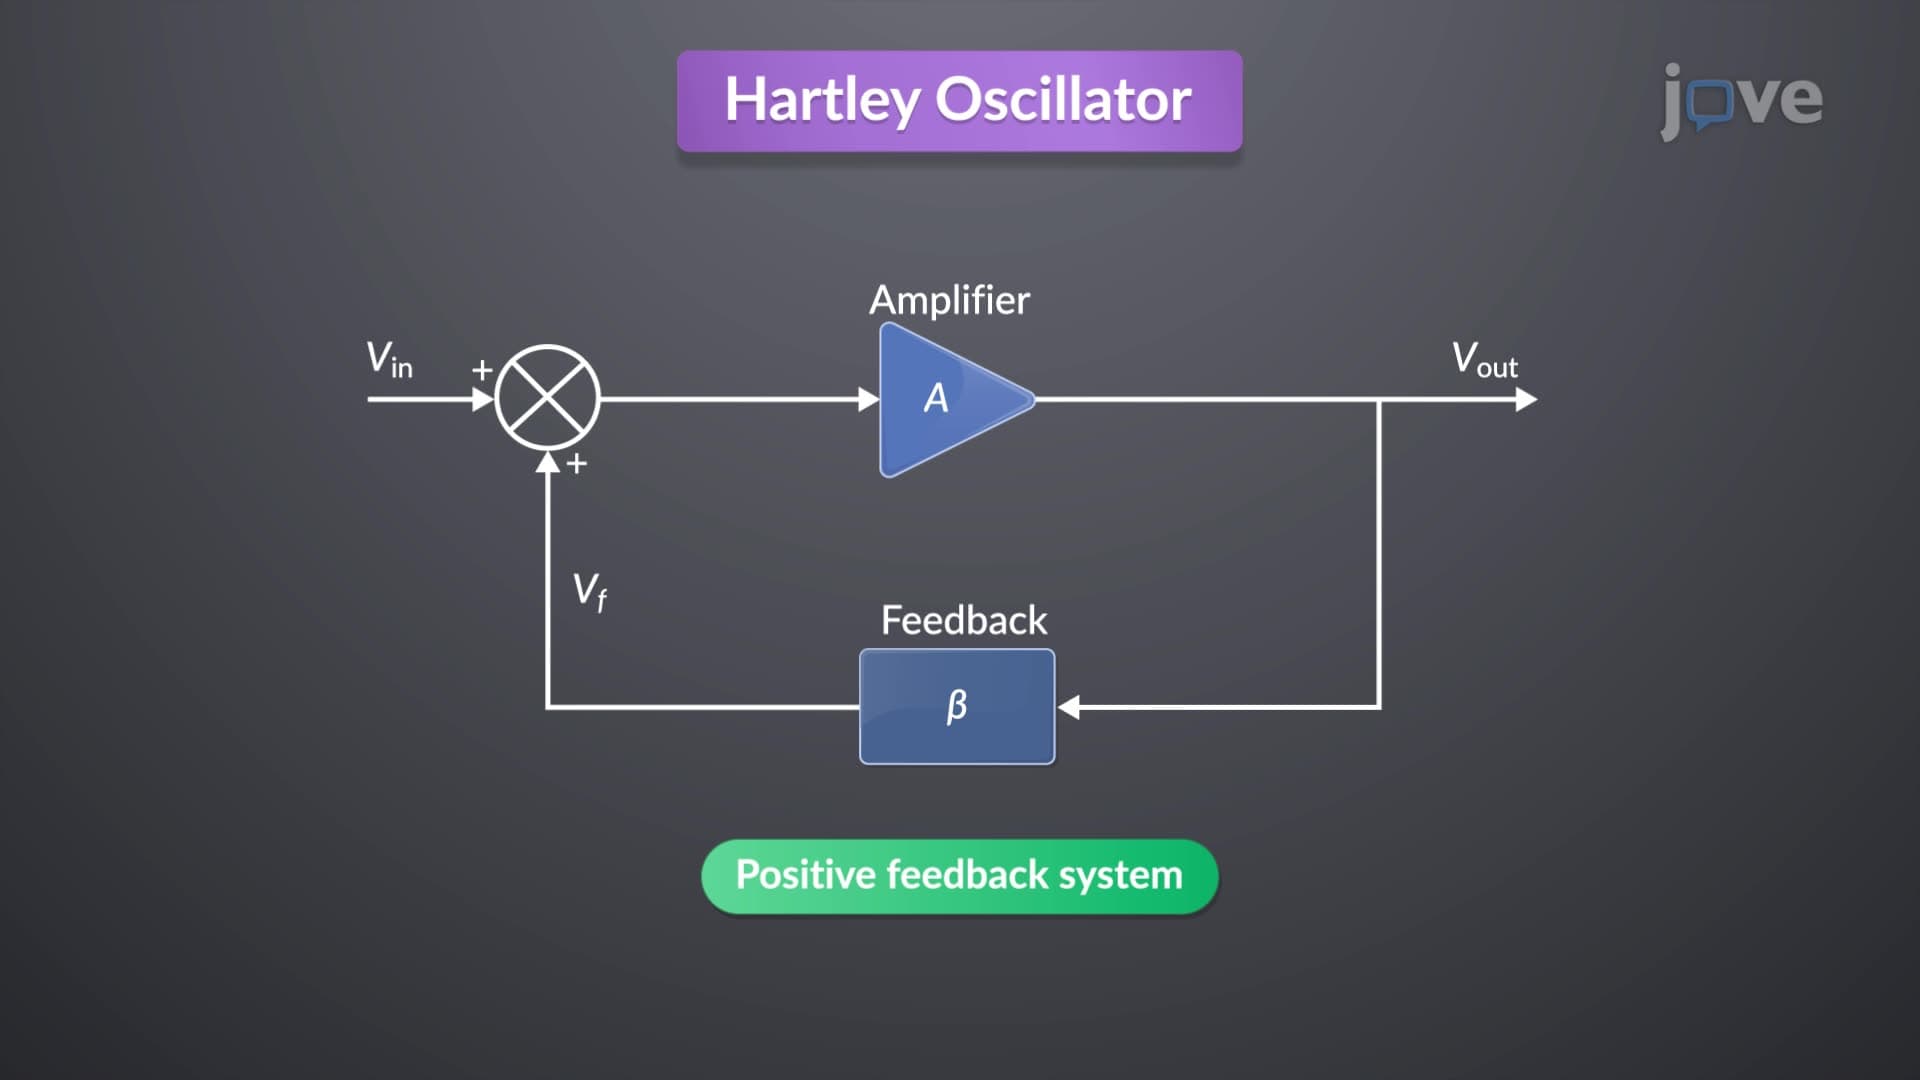
The construction rules for the root locus in positive feedback systems are similar to those in...