Related Experiment Video
Updated: Dec 20, 2025
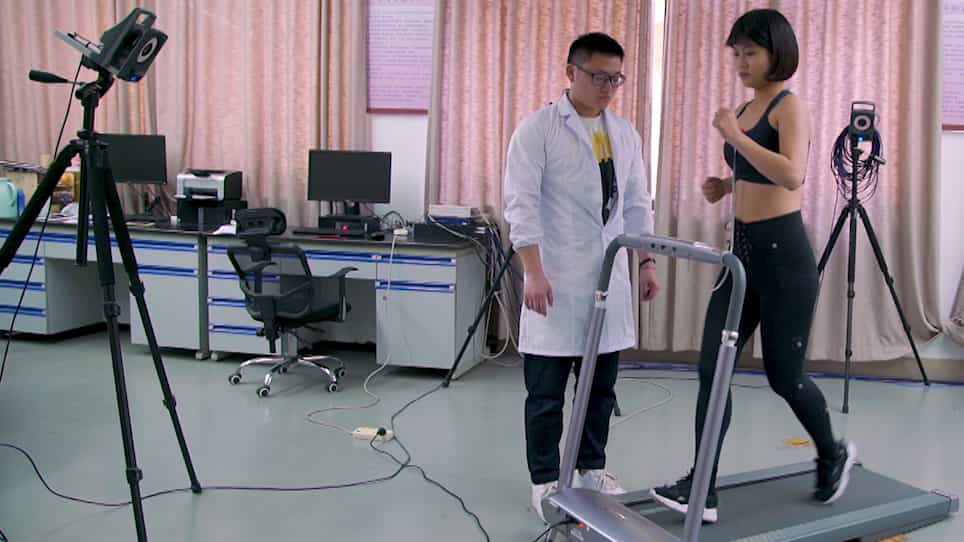

Comparative Analysis of Lower Limb Kinematics between the Initial and Terminal Phase of 5km Treadmill Running
Published on: July 17, 2020
Biomechanics of graded running: Part II-Joint kinematics and kinetics
Arash Khassetarash1, Gianluca Vernillo1,2, Aaron Martinez1
1Human Performance Laboratory, Faculty of Kinesiology, University of Calgary, Calgary, AB, Canada.

Abstract:
Compared to level running (LR), different strategies might be implemented by runners to cope with specific challenges of graded running at different speeds. The changes in joint kinetics and kinematics associated with graded running have been investigated, but their interactions with speed are unknown. Nineteen participants ran on an instrumented treadmill at five grades (0°, ±5° and ± 10°) and three speeds (2.50, 3.33 and 4.17 m/s), while 3D motion and forces were recorded. Three speed × five-grade repeated-measures ANOVA was used to analyze kinetic and kinematic variables. A speed × grade interaction was observed for hip range of motion (ROM). Downhill running (DR) at fastest speed did not reduce ROM at the hip, compared to LR. Compared to LR, it was observed that the hip joint was responsible for a greater contribution of energy generation while running at the fastest speed at +10°. Speed × grade interactions were also observed for the energy absorption, peak moment, and peak power at the knee. Contrary to LR, running faster during UR did not require higher peak power at the knee. Finally, DR at the fastest speed did not increase peak negative power at the knee compared to LR. This study demonstrates that ankle, knee, and hip joint kinetics depend on speed and grade of running, while the effect of grade on joint kinematics was not substantially modulated by speed.
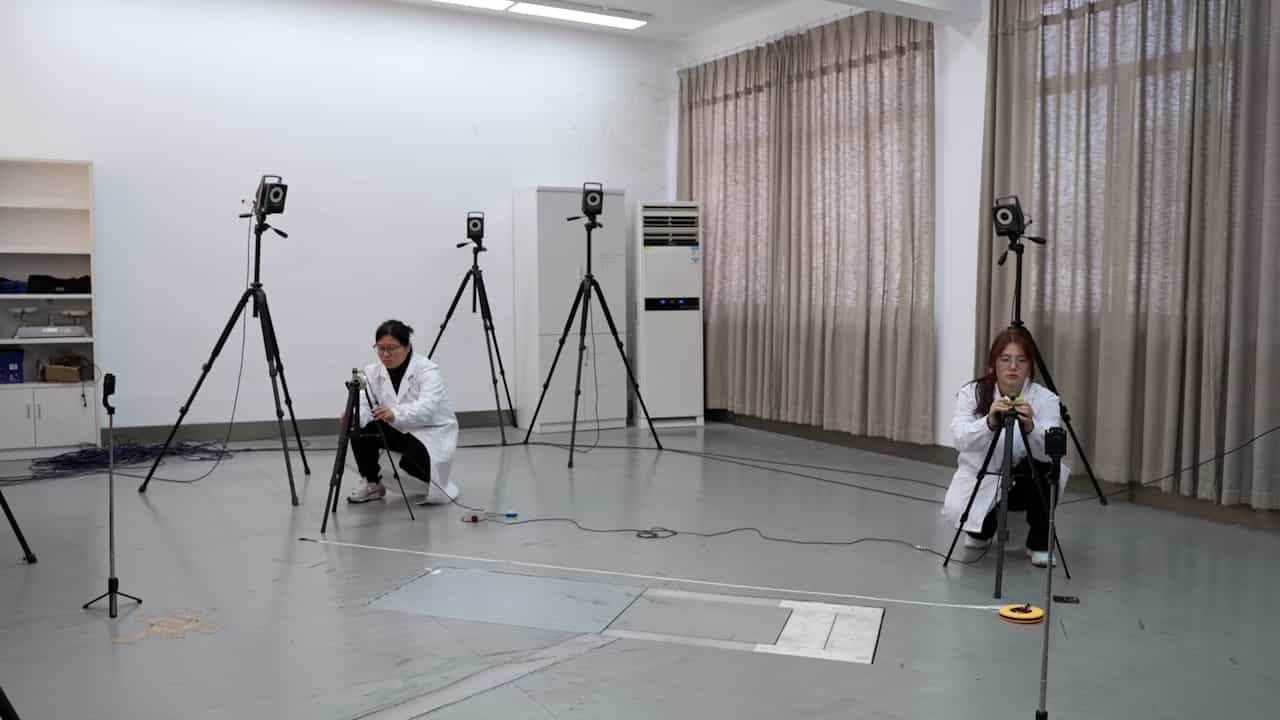

Related Concept Videos
 00:58
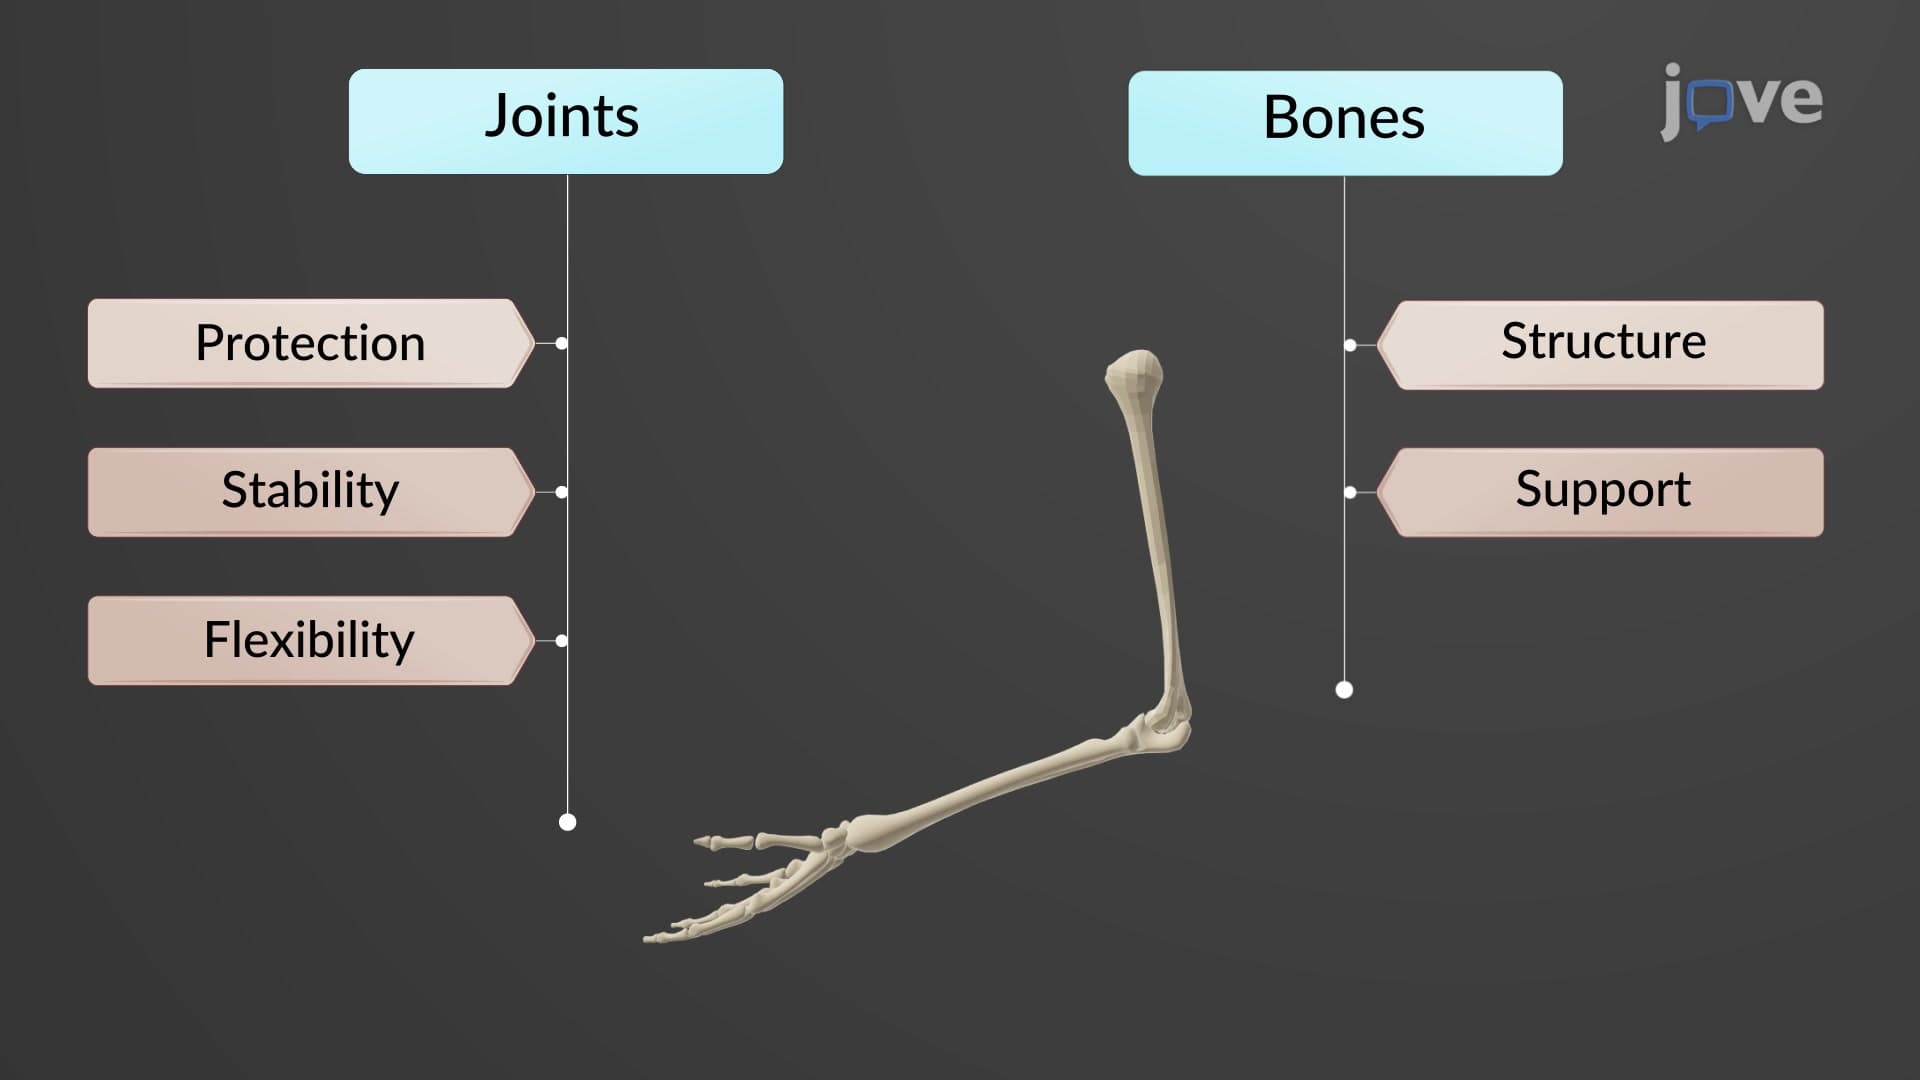
Introduction to Joints
 01:16
Bones of the Lower Limb: Femur and Patella
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
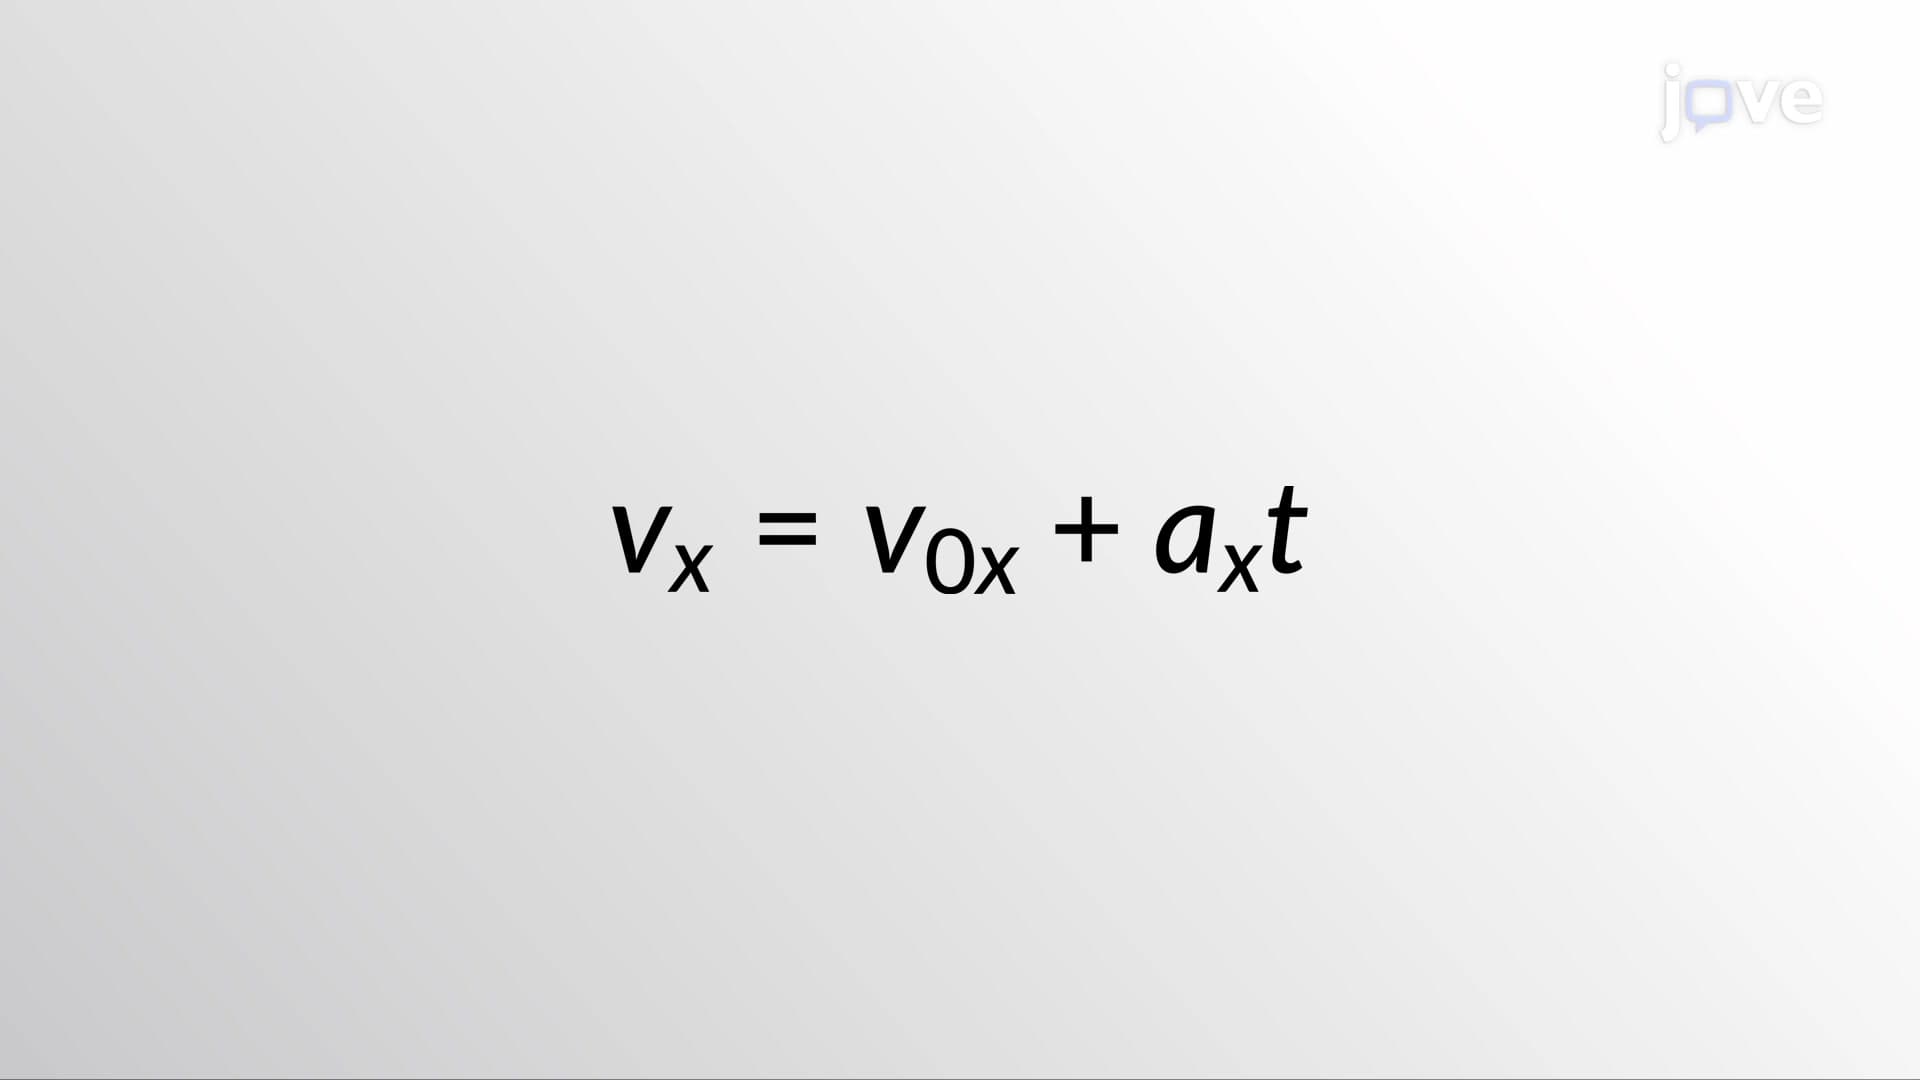 01:26
Kinematic Equations - I
 01:18
Kinematic Equations - III
Using the kinematic equations,...