Related Experiment Video
Updated: Dec 18, 2025

Author Spotlight: Enhancement of Salient Object Detection for Smart Grid Applications
Published on: December 15, 2023
Sparse Regularization-Based Approach for Point Cloud Denoising and Sharp Features Enhancement
Esmeide Leal1, German Sanchez-Torres2, John W Branch3
1Faculty of Engineering, Universidad Autónoma del Caribe, Barranquilla 080001, Colombia.

Abstract:
Denoising the point cloud is fundamental for reconstructing high quality surfaces with details in order to eliminate noise and outliers in the 3D scanning process. The challenges for a denoising algorithm are noise reduction and sharp features preservation. In this paper, we present a new model to reconstruct and smooth point clouds that combine L1-median filtering with sparse L1 regularization for both denoising the normal vectors and updating the position of the points to preserve sharp features in the point cloud. The L1-median filter is robust to outliers and noise compared to the mean. The L1 norm is a way to measure the sparsity of a solution, and applying an L1 optimization to the point cloud can measure the sparsity of sharp features, producing clean point set surfaces with sharp features. We optimize the L1 minimization problem by using the proximal gradient descent algorithm. Experimental results show that our approach is comparable to the state-of-the-art methods, as it filters out 3D models with a high level of noise, but keeps their geometric features.
Related Concept Videos
 01:18
Reducing Line Loss
With a step-up transformer at the source, the voltage is increased, thereby reducing the current in the transmission lines since power loss in...
 01:20
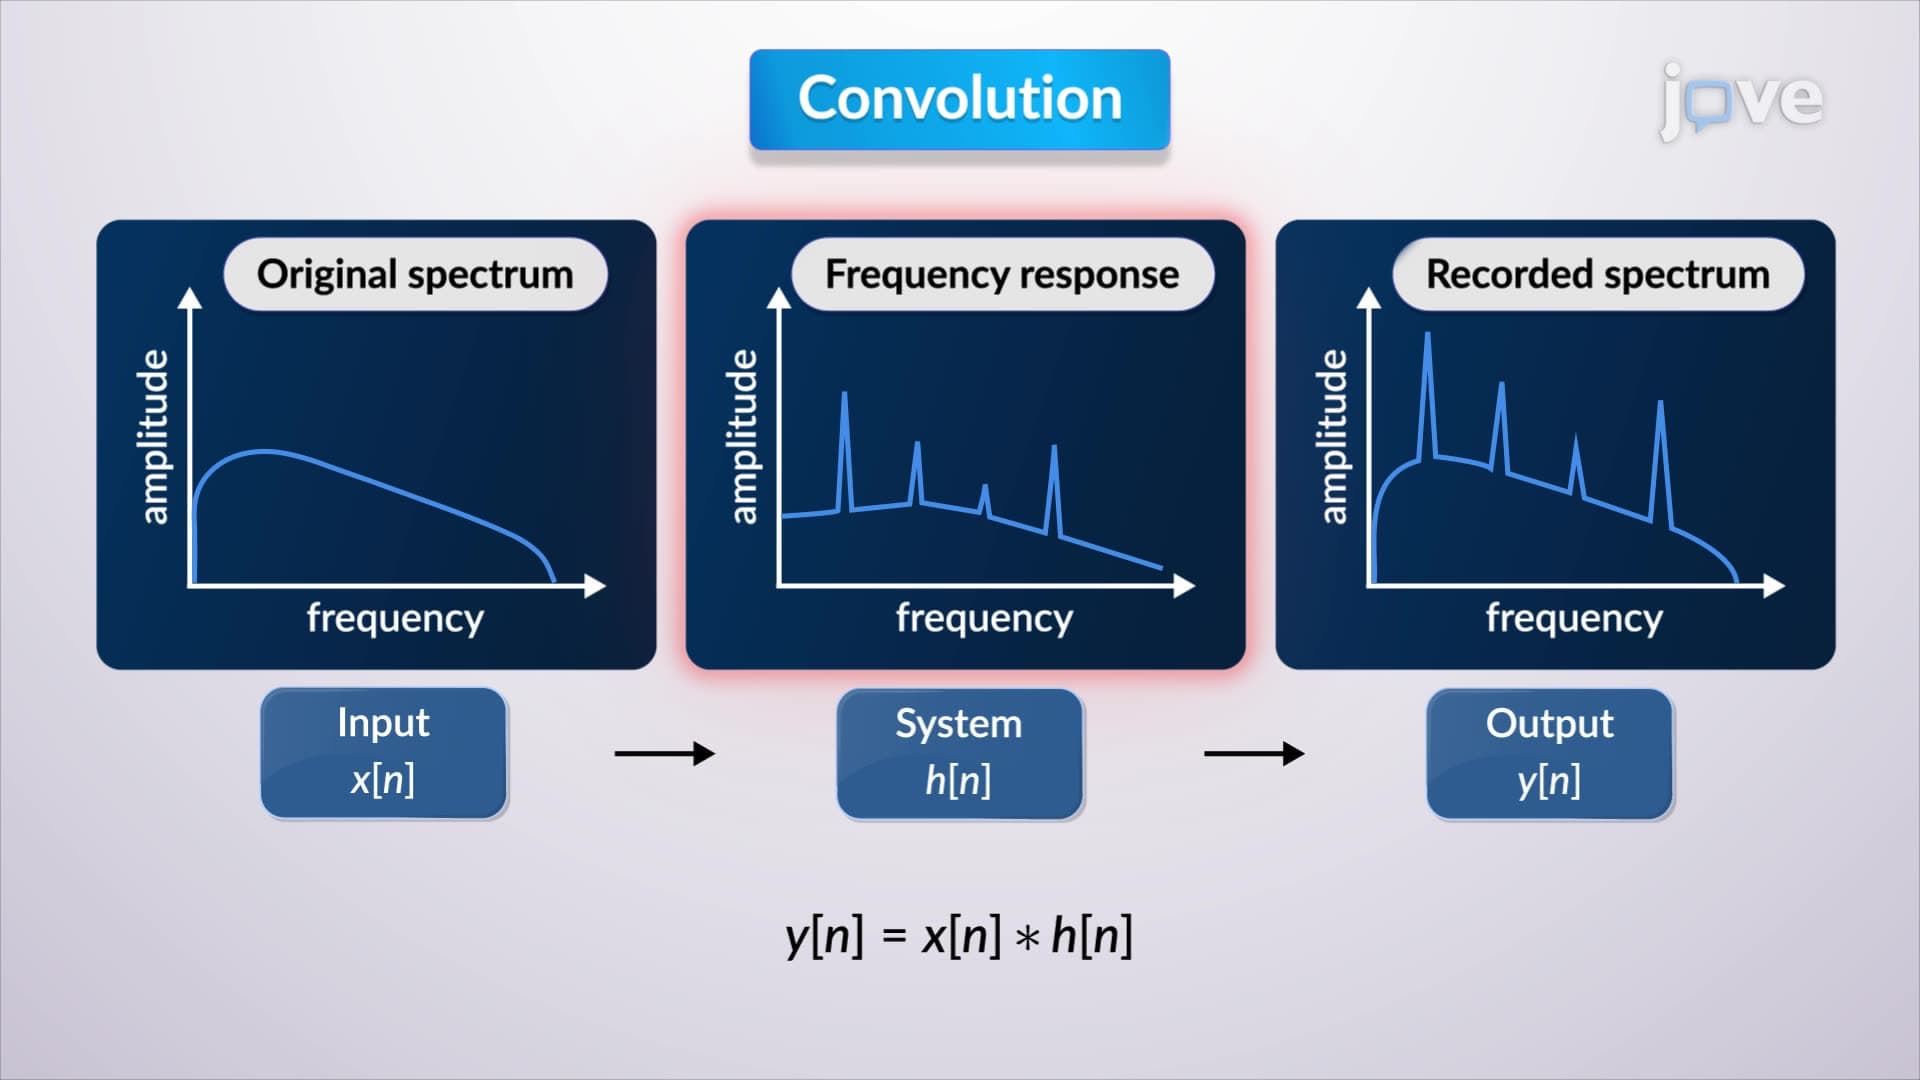
Deconvolution
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:11
Residuals and Least-Squares Property
If the observed data point lies above the line, the residual is positive, and the line underestimates the actual data value for y. If the observed data point lies below the line, the residual is negative, and the line overestimates the actual data value for y.
The process of fitting the best-fit...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:20
Downsampling
The Fourier transform of the decimated sequence reveals a combination of scaled and shifted versions of the original spectrum. This...
 01:20
Calibration Curves: Linear Least Squares
For data that follow a straight line, the standard method for fitting is the linear...