Related Experiment Video
Updated: Dec 18, 2025


Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
Multiple-Target Homotopic Quasi-Complete Path Planning Method for Mobile Robot Using a Piecewise Linear Approach
Gerardo Diaz-Arango1, Hector Vazquez-Leal2,3, Luis Hernandez-Martinez4
1Engineering School, University of Xalapa, Km. 2 Carretera Xalapa-Veracruz, Xalapa, Veracruz 91190, Mexico.

Abstract:
The ability to plan a multiple-target path that goes through places considered important is desirable for autonomous mobile robots that perform tasks in industrial environments. This characteristic is necessary for inspection robots that monitor the critical conditions of sectors in thermal, nuclear, and hydropower plants. This ability is also useful for applications such as service at home, victim rescue, museum guidance, land mine detection, and so forth. Multiple-target collision-free path planning is a topic that has not been very studied because of the complexity that it implies. Usually, this issue is left in second place because, commonly, it is solved by segmentation using the point-to-point strategy. Nevertheless, this approach exhibits a poor performance, in terms of path length, due to unnecessary turnings and redundant segments present in the found path. In this paper, a multiple-target method based on homotopy continuation capable to calculate a collision-free path in a single execution for complex environments is presented. This method exhibits a better performance, both in speed and efficiency, and robustness compared to the original Homotopic Path Planning Method (HPPM). Among the new schemes that improve their performance are the Double Spherical Tracking (DST), the dummy obstacle scheme, and a systematic criterion to a selection of repulsion parameter. The case studies show its effectiveness to find a solution path for office-like environments in just a few milliseconds, even if they have narrow corridors and hundreds of obstacles. Additionally, a comparison between the proposed method and sampling-based planning algorithms (SBP) with the best performance is presented. Furthermore, the results of case studies show that the proposed method exhibits a better performance than SBP algorithms for execution time, memory, and in some cases path length metrics. Finally, to validate the feasibility of the paths calculated by the proposed planner; two simulations using the pure-pursuit controlled and differential drive robot model contained in the Robotics System Toolbox of MATLAB are presented.
More Related Videos

Related Concept Videos
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:28
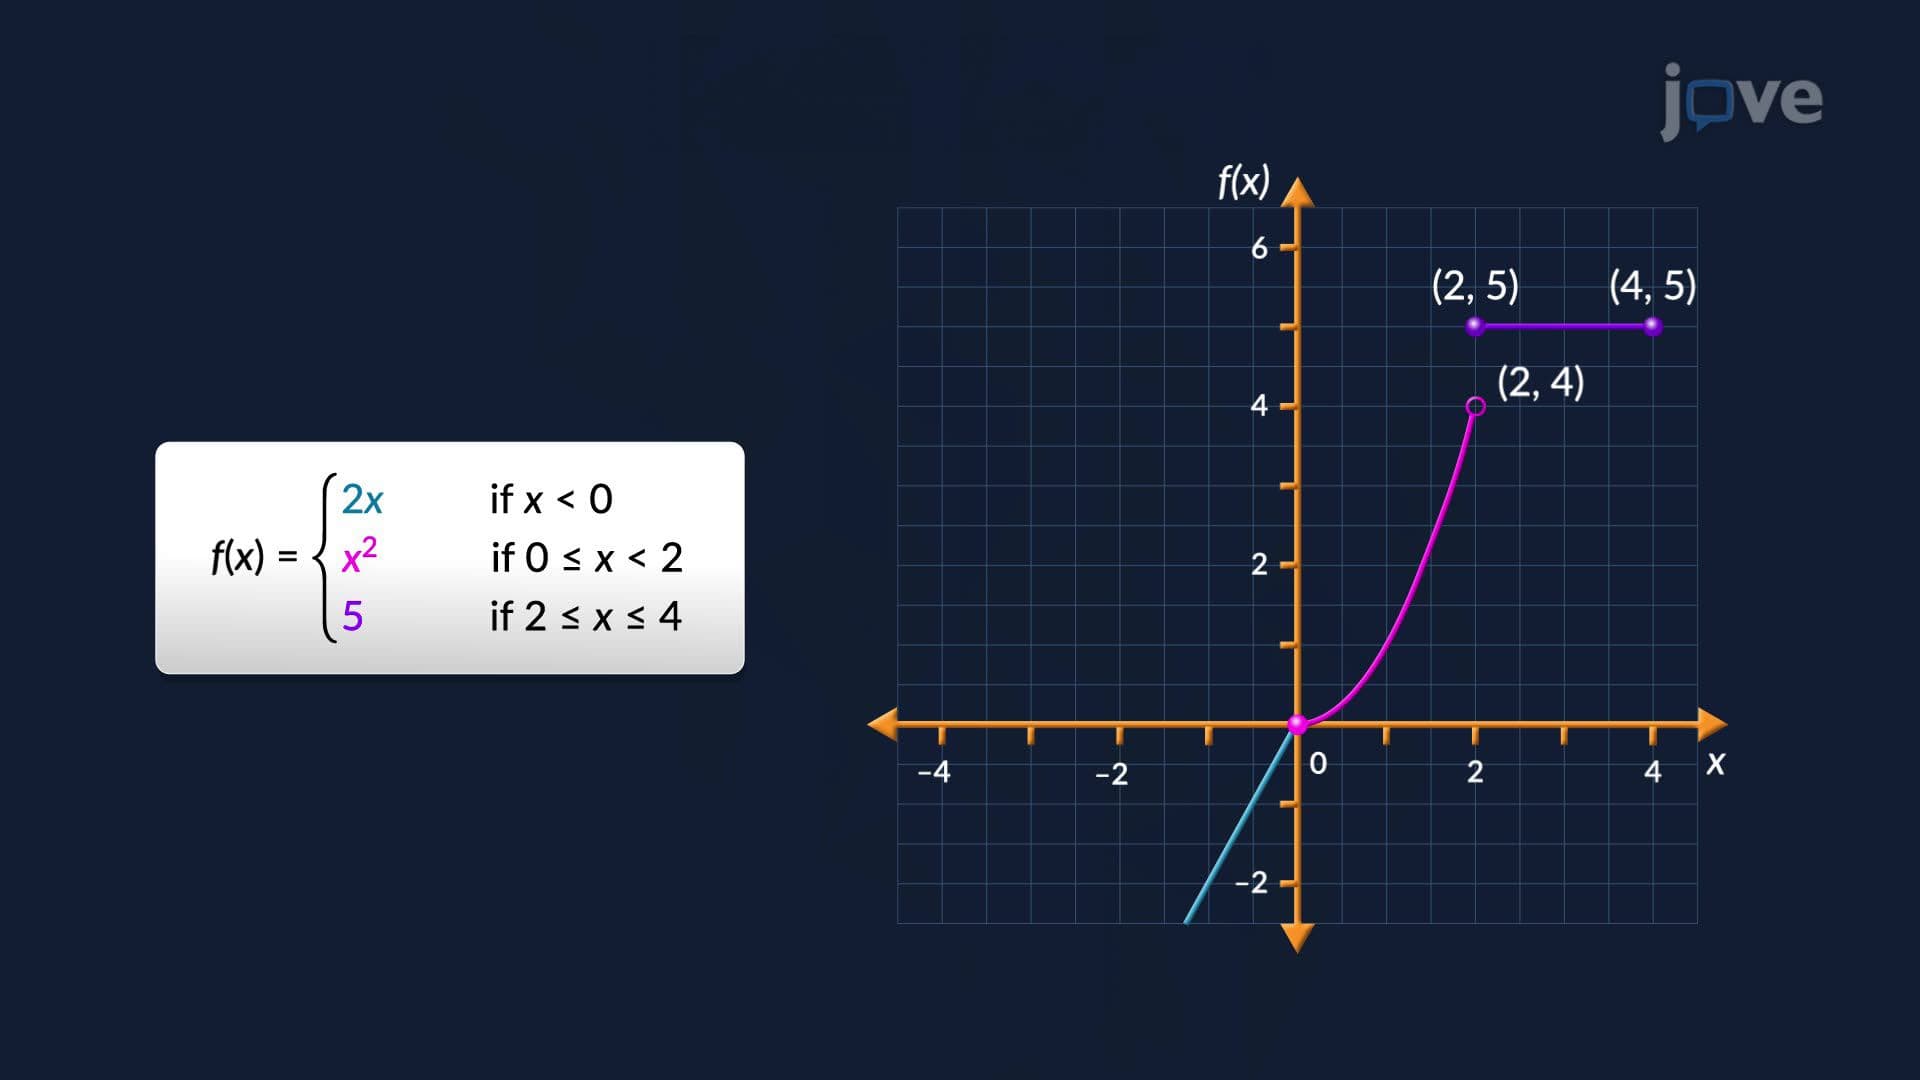
Piecewise-Defined Functions
 01:11
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...
 01:15
Kinematic Equations: Problem Solving