Novel results on finite-time stabilization of state-based switched chaotic inertial neural networks with distributed delays
Related Experiment Video
Updated: Dec 18, 2025
Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
Changqing Long1, Guodong Zhang1, Zhigang Zeng2
1School of Mathematics and statistics, South-Central University For Nationalities, Wuhan 430074, China.

Abstract:
The p-norm finite-time stabilization (FTS) issue of a class of state-based switched inertial chaotic neural networks (SBSCINNs) with distributed time-varying delays is investigated. By using a suitable variable transformation, such second-order SBSCINNs are turned into the first-order differential equations. Then some novel criteria are obtained to stabilize SBSCINNs in a finite time based on the theory of finite-time control and non-smooth analysis together with designing two proper delay-dependent feedback controllers. Besides, the settling time of FTS is also estimated and discussed. Finally, the validity and practicability of the deduced theoretical results are verified by examples and applications.
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:27
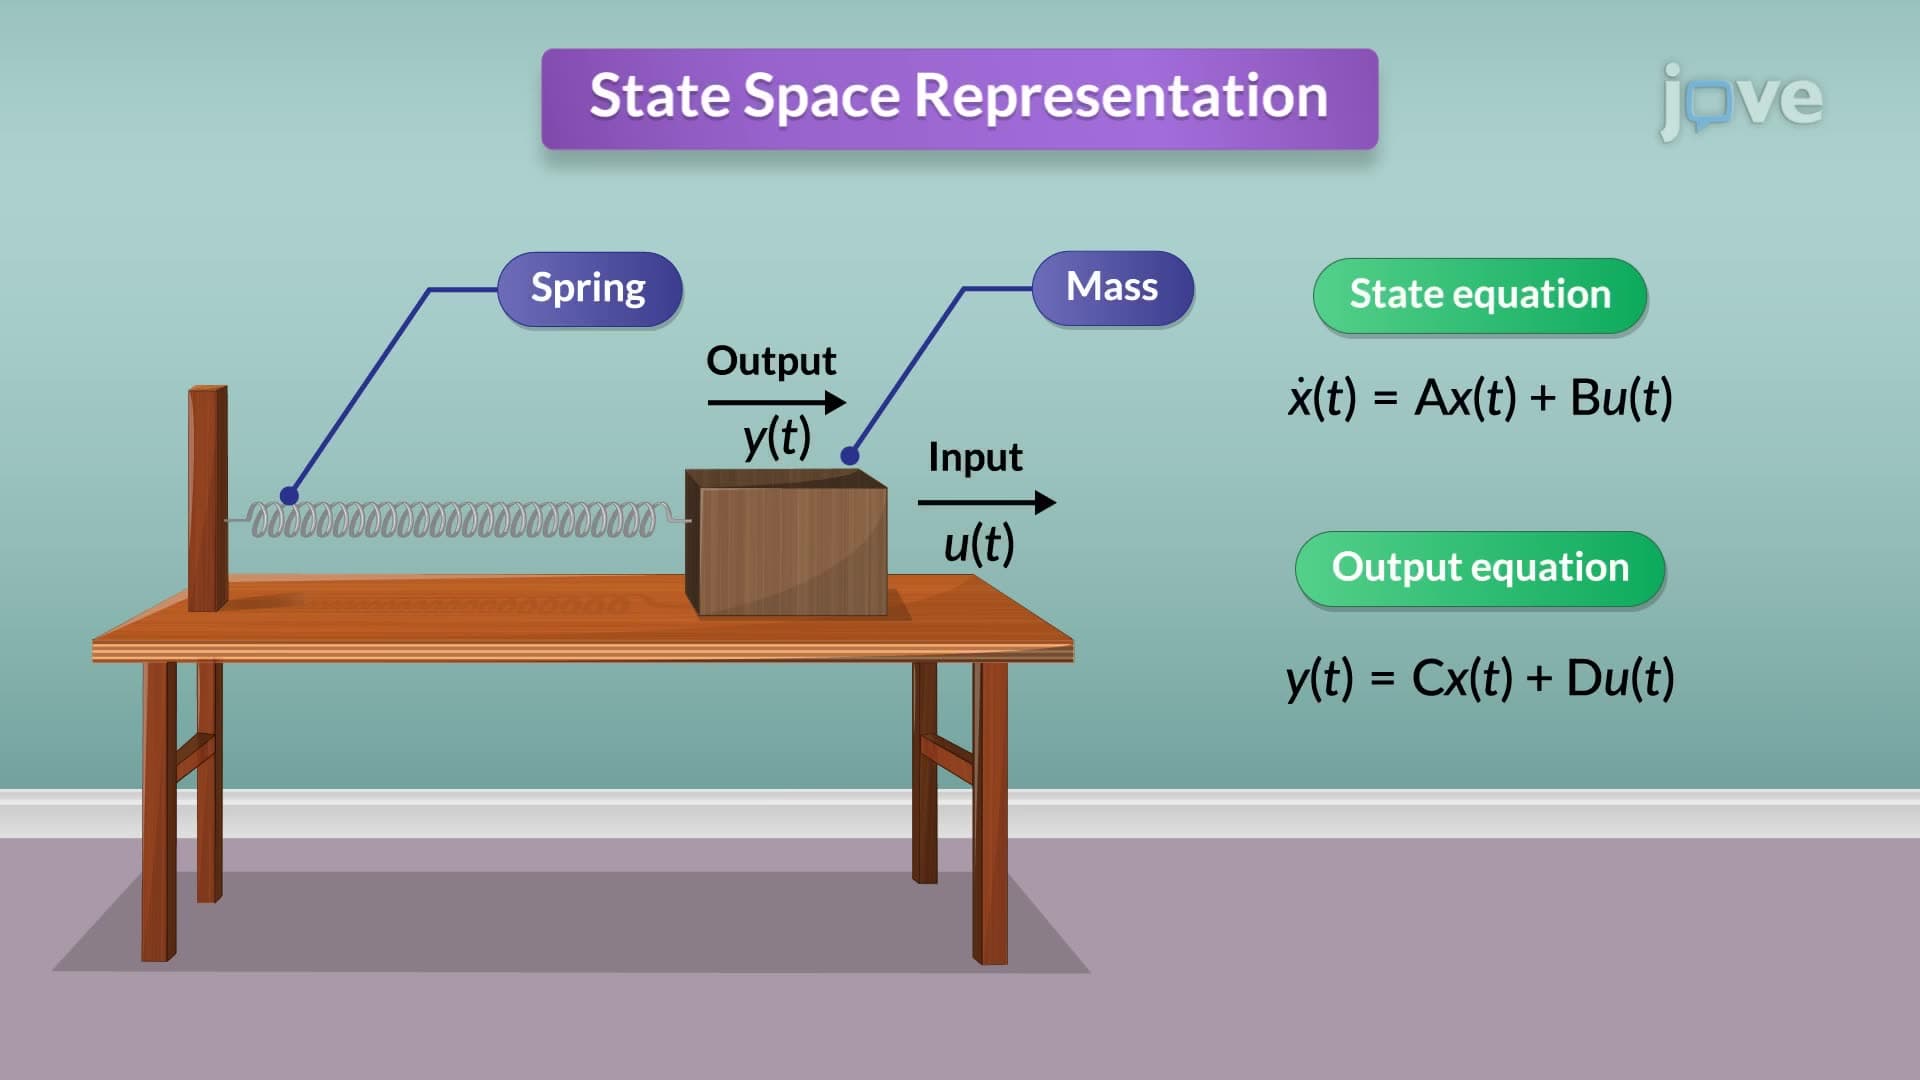
State Space Representation
Consider an RLC circuit, a...
 01:28
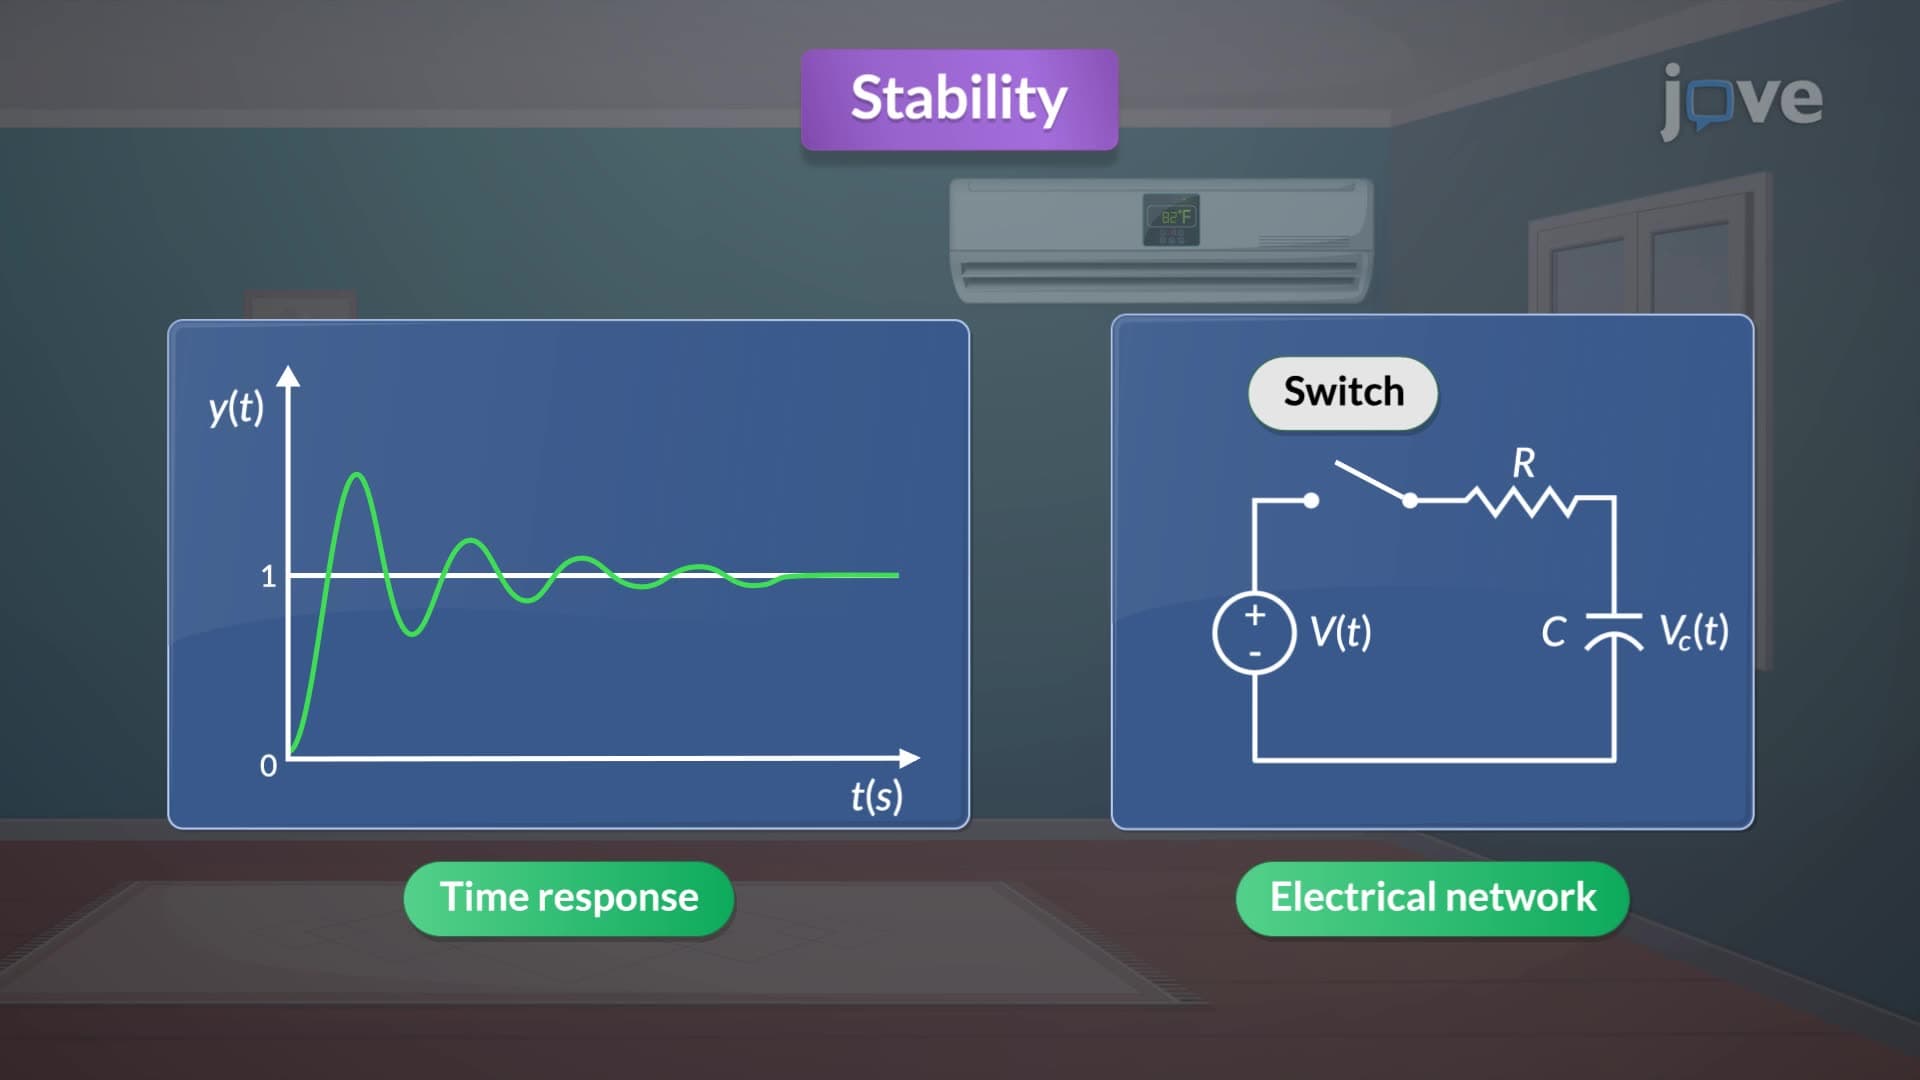
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:21
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as: