[Rationale of kinematic alignment]
Related Experiment Video
Updated: Dec 17, 2025
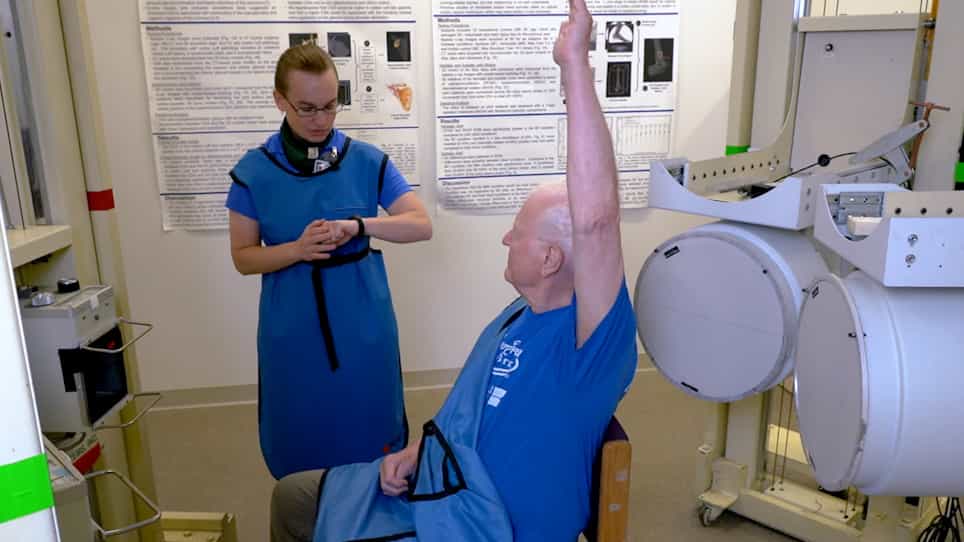
Measuring 3D In-vivo Shoulder Kinematics using Biplanar Videoradiography
Published on: March 12, 2021
1Orthopädische Klinik der Medizinischen Hochschule Hannover im DIAKOVERE Annastift, Anna-von Borries Str. 1-6, 30625, Hannover, Deutschland. henning.windhagen@diakovere.de.

Background:
Kinematic alignment is a philosophy for individual knee prosthesis implantation in a three-dimensional view. The key of the concept is to understand the femoral flexion-extension axis as the centre of a cylinder within the posterior condyles. This axis defines the knee in three dimensions over the entire range of motion. The tibia follows the femur, is balanced on the knee in extension and flexion, and shows individual laxities in flexion and deep flexion.
Impacts:
As a consequence, limbs will be reconstructed along their constitutional leg axis, which in most patients is different to a straight hip-knee-ankle centre axis. The method aims at perfectly reconstructing the natural joint lines, which in many patients leads to the natural oblique joint lines. This results in considerable advantages, as the natural stability of the knee is restored, and native patella kinematics are maintained. From a static view, polyethylene and the implant-bone interface may be vulnerable to mechanical overloading due to altered adductor moments. However, a growing body of evidence shows that naturally oriented knee joints show a more balanced loading pattern. Moreover, dynamic gait patterns actually show the mechanism of even reduced knee adductor moments, explaining the clinical results of up to 10 years follow up.
Related Concept Videos
 01:30
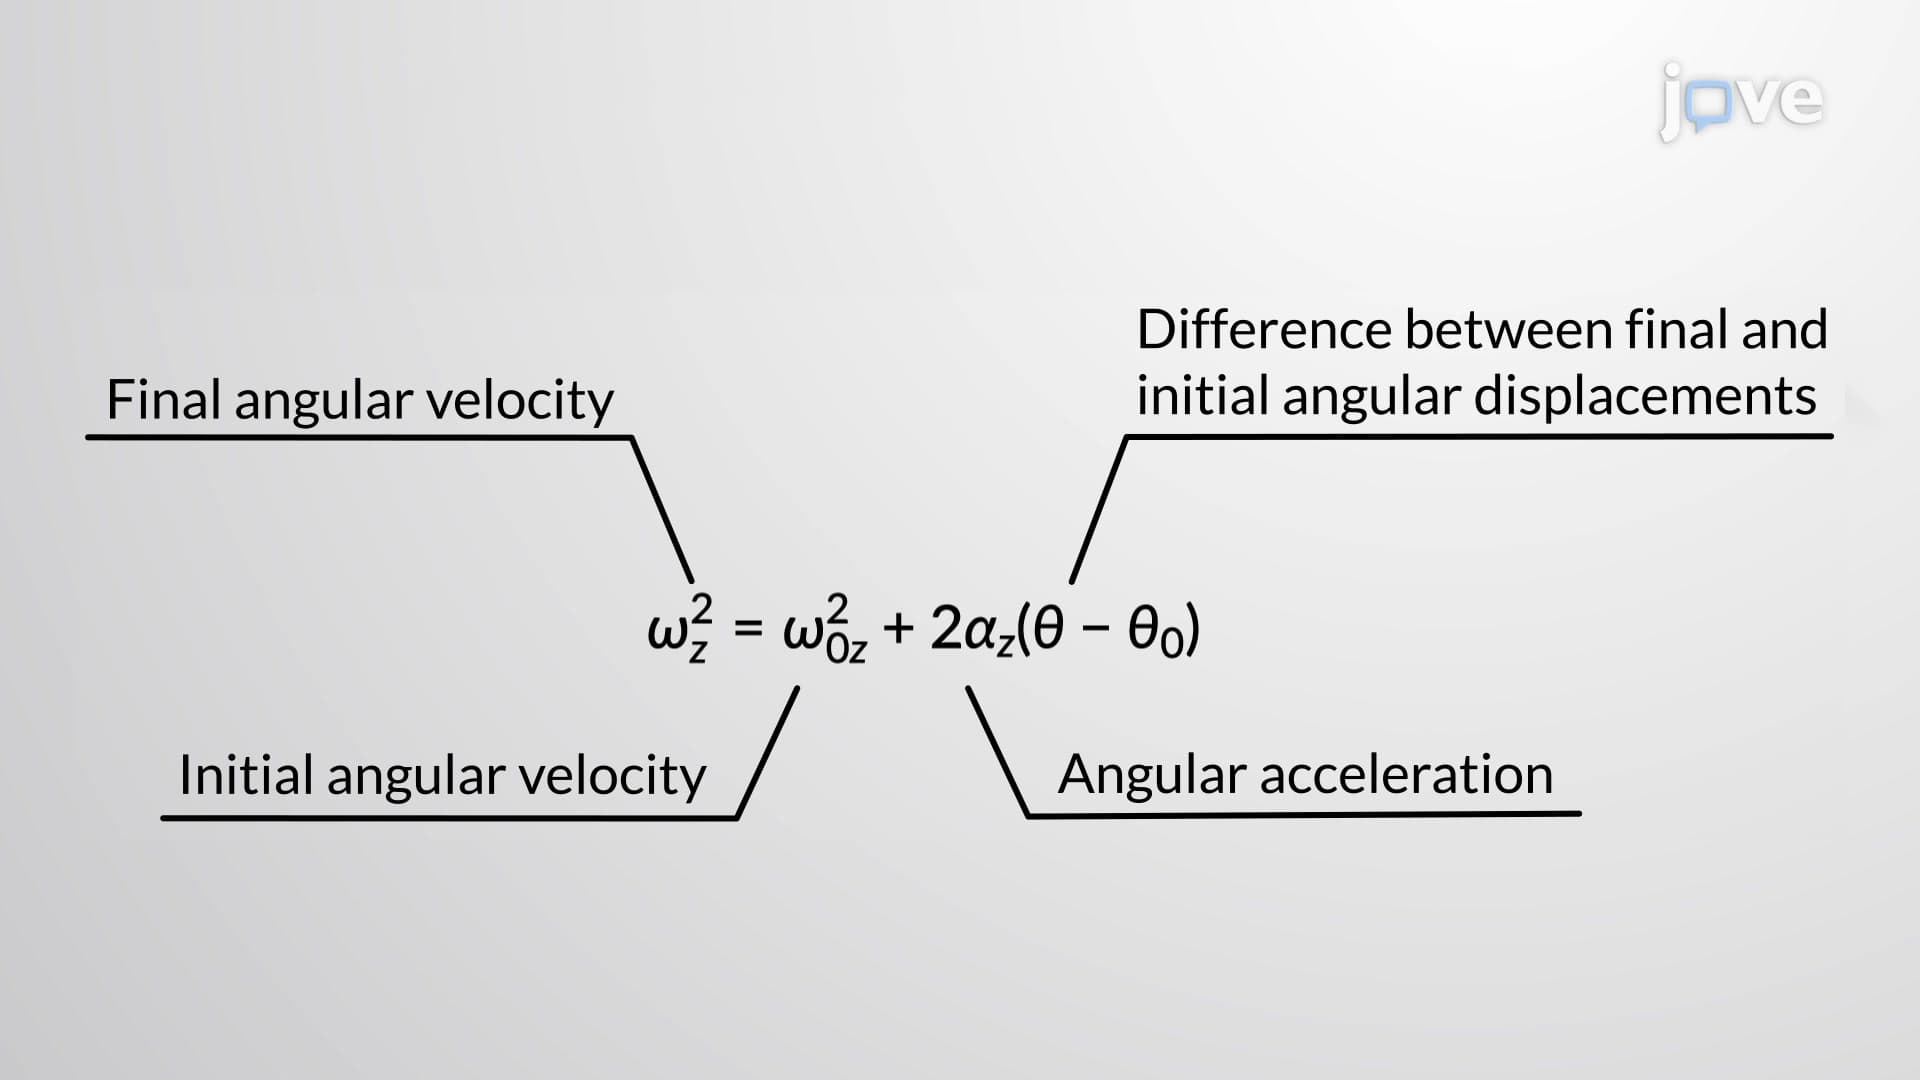
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:16
Rotation with Constant Angular Acceleration - II
The first...
 01:15
Kinematic Equations: Problem Solving
 01:10
Relative Motion Analysis - Acceleration
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:14
Stability of structures