An Inertial Proximal-Gradient Penalization Scheme for Constrained Convex Optimization Problems

Radu Ioan Boţ1, Ernö Robert Csetnek1, Nimit Nimana2

  • 1Faculty of Mathematics, University of Vienna, Oskar-Morgenstern-Platz 1, 1090 Vienna, Austria.

Vietnam Journal of Mathematics
|July 28, 2020
PubMed

Related Concept Videos

Application of Nonlinear Inequalities01:29

Application of Nonlinear Inequalities

A nonlinear inequality describes a comparison involving an expression that curves or behaves more complexly than a straight line. These inequalities often appear in forms that include squares, products, or variables in the denominator.To solve such an inequality, one starts by rewriting it so that zero appears on one side. For example, the inequality:  can be factored as: This form makes it easier to identify the values that cause the expression to equal zero. In this case, the...
134
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving01:29

Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving

Mechanistic models play a crucial role in algorithms for numerical problem-solving, particularly in nonlinear mixed effects modeling (NMEM). These models aim to minimize specific objective functions by evaluating various parameter estimates, leading to the development of systematic algorithms. In some cases, linearization techniques approximate the model using linear equations.
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
210
Principle of Linear Impulse and Momentum for a Single Particle: Problem Solving01:23

Principle of Linear Impulse and Momentum for a Single Particle: Problem Solving

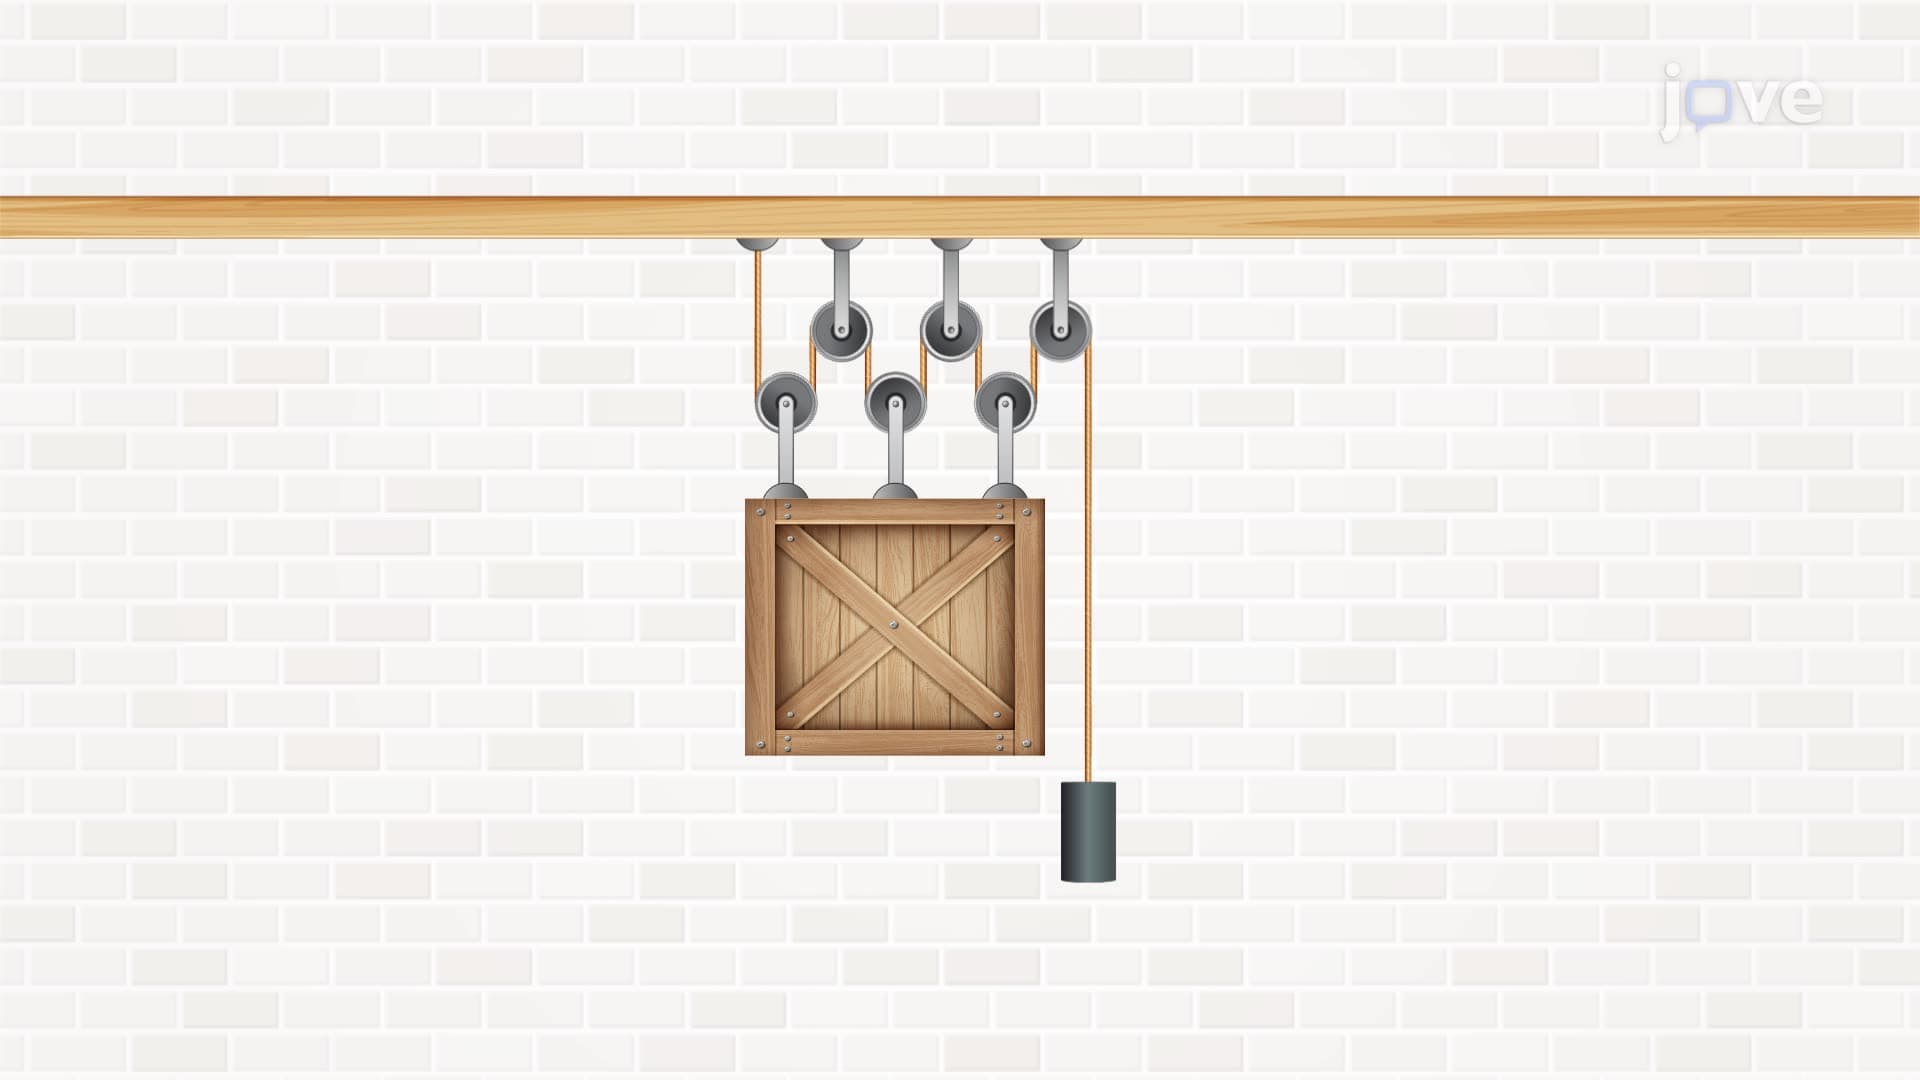
Consider a wooden box and a cylinder of known masses m1 and m2, respectively,  hanging from a ceiling with the help of a massless pulley system.
874
Introduction to Nonlinear Inequalities01:25

Introduction to Nonlinear Inequalities

Linear and nonlinear inequalities are fundamental for analyzing variable relationships and identifying ranges satisfying specific conditions. A linear inequality involves variables raised only to the first power, resulting in a straight-line graph. This line partitions the coordinate plane into two distinct regions: one that satisfies the inequality and one that does not. Each region represents a set of solutions where the linear relationship holds true under the specified constraint.Nonlinear...
102
Kinematic Equations: Problem Solving01:15

Kinematic Equations: Problem Solving
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
27.0K
Constraints and Statical Determinacy01:26

Constraints and Statical Determinacy

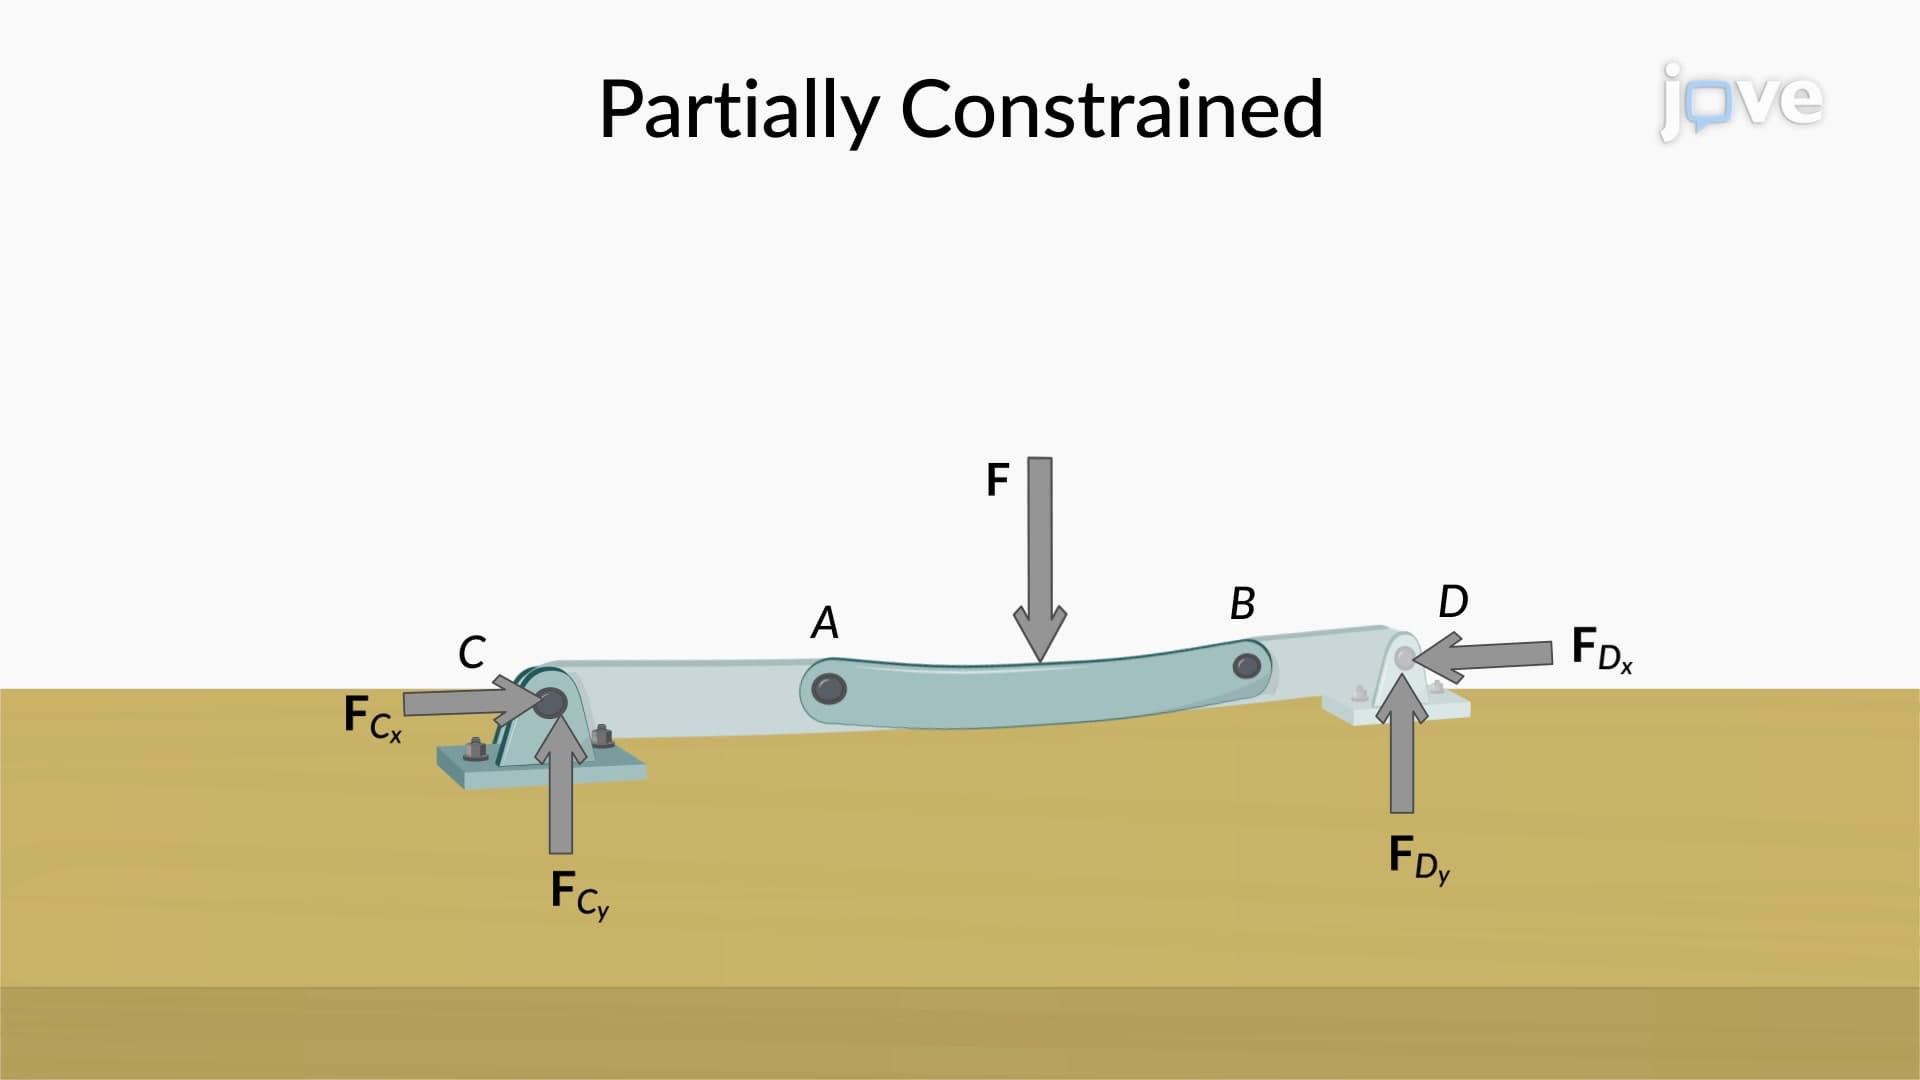
In structural engineering, the equilibrium of a system is not only determined by its equations of equilibrium but also with the help of constraints. Constraints refer to restrictions on the motion of a system. The proper combinations of constraints can minimize the total number of constraints needed to maintain a system in mechanical equilibrium. When this happens, the system is said to be statically determinate. For such systems, the unknown reaction supports can be estimated using equilibrium...
883