Related Experiment Video
Updated: Dec 11, 2025

Use of a Foot-Induced Digitally Controlled Resistance Device for Functional Magnetic Resonance Imaging Evaluation in Patients with Foot Paresis
Published on: July 7, 2023
Theoretical justification for distal foot power equation
1Associate Professor, School of Engineering Padnos College of Engineering and Computing, Grand Valley State University, 301 W Fulton Street, KEN 325, Grand Rapids, MI 49504, United States.

Abstract:
The distal foot power equation is a simple yet powerful tool for estimating the power dissipation or generation within the foot even while modeling it as a rigid body. It was introduced over two decades ago, but has seen a resurgence of use in recent years. Nevertheless, the theoretical justification for this formula has thus far been limited. It is difficult to properly use any equation and interpret the results from analyses using it without a solid understanding of how it is derived as well as its underlying assumptions. In this communication, a thorough derivation of the distal foot power equation is provided first for the case where the foot is interacting with a rigid ground without sliding and then second generalized for situations when the foot may slide relative to a deformable ground surface. For the first case, the derivation makes clear that distal foot power represents the power due to the deviation of the foot from a rigid body state for the portion of the foot between its mass center (or other point of reference) and the center of pressure. For the second case, distal foot power represents not only the internal deformation power of the foot, but also the power due to sliding of the foot on the ground and the power due to deformation of the ground near the point of contact.

Related Concept Videos
 00:57
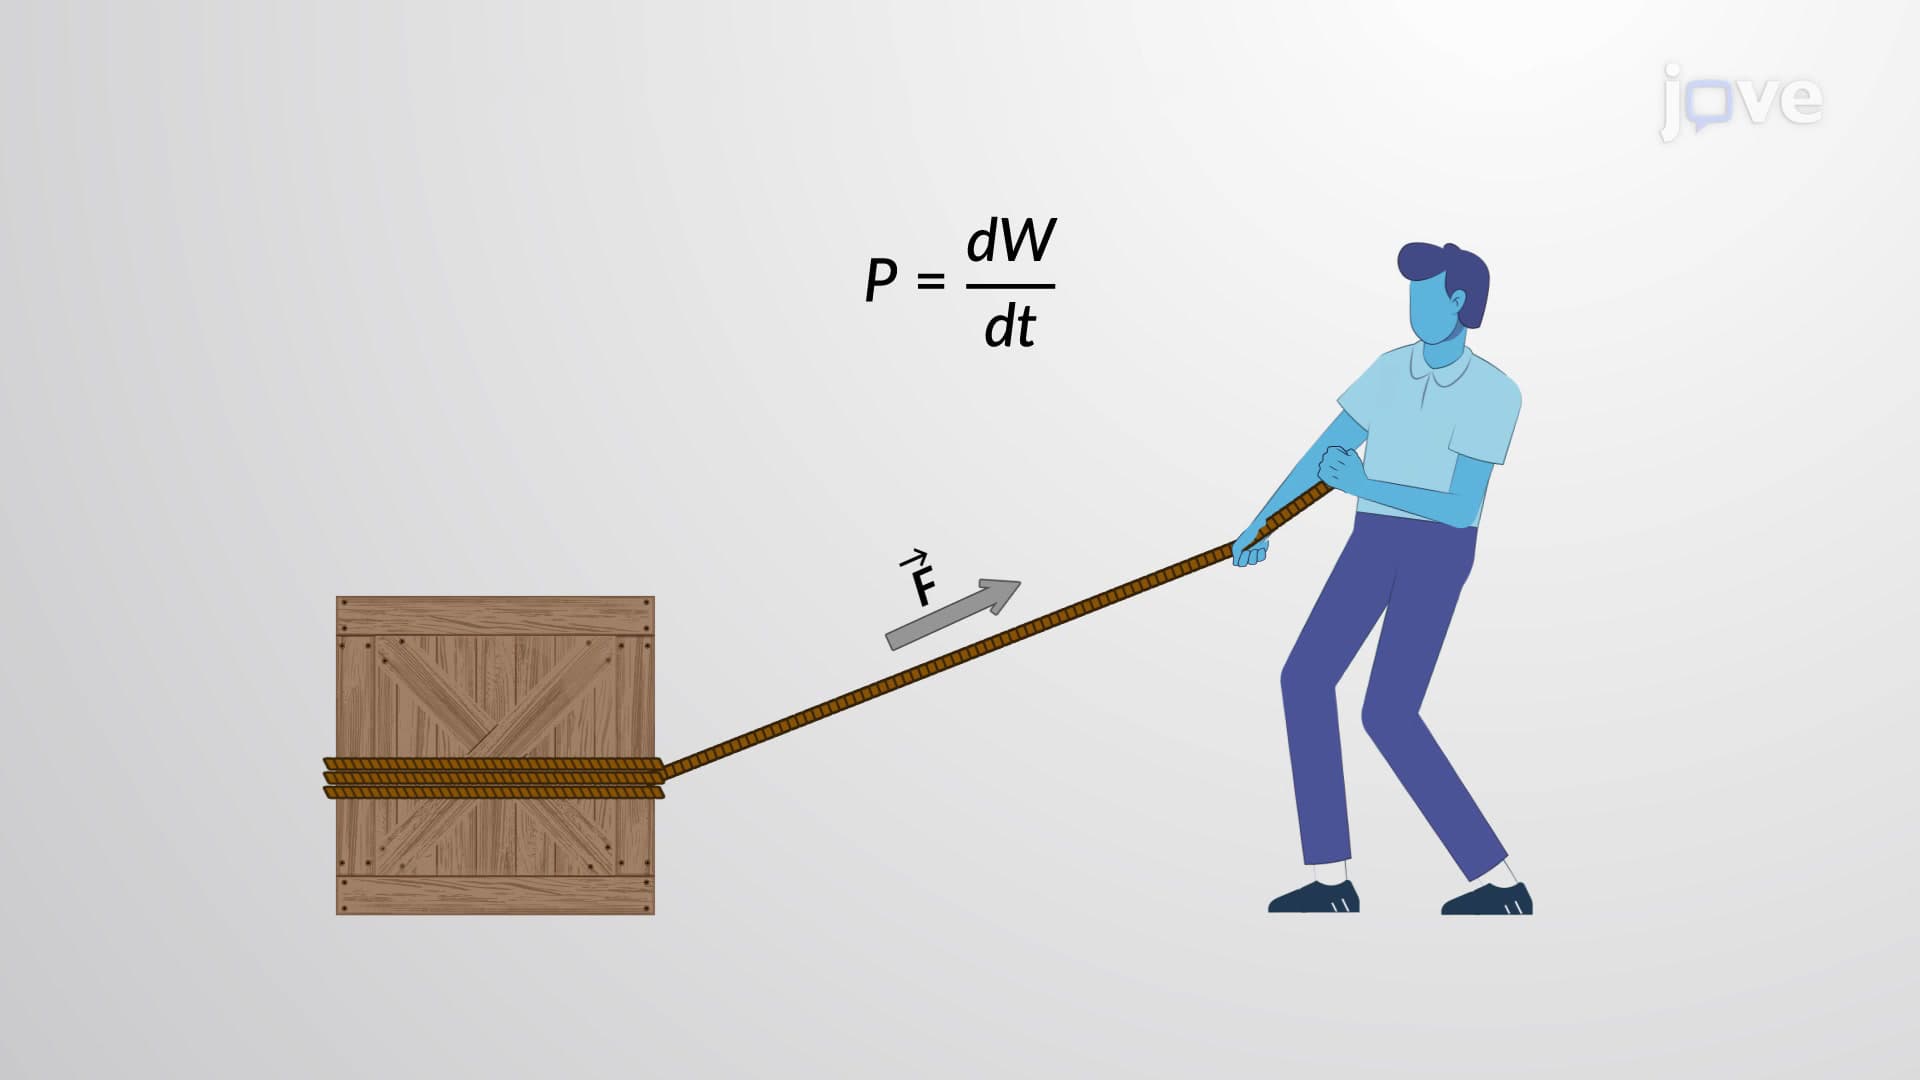
Power Expended by a Constant Force
 01:21
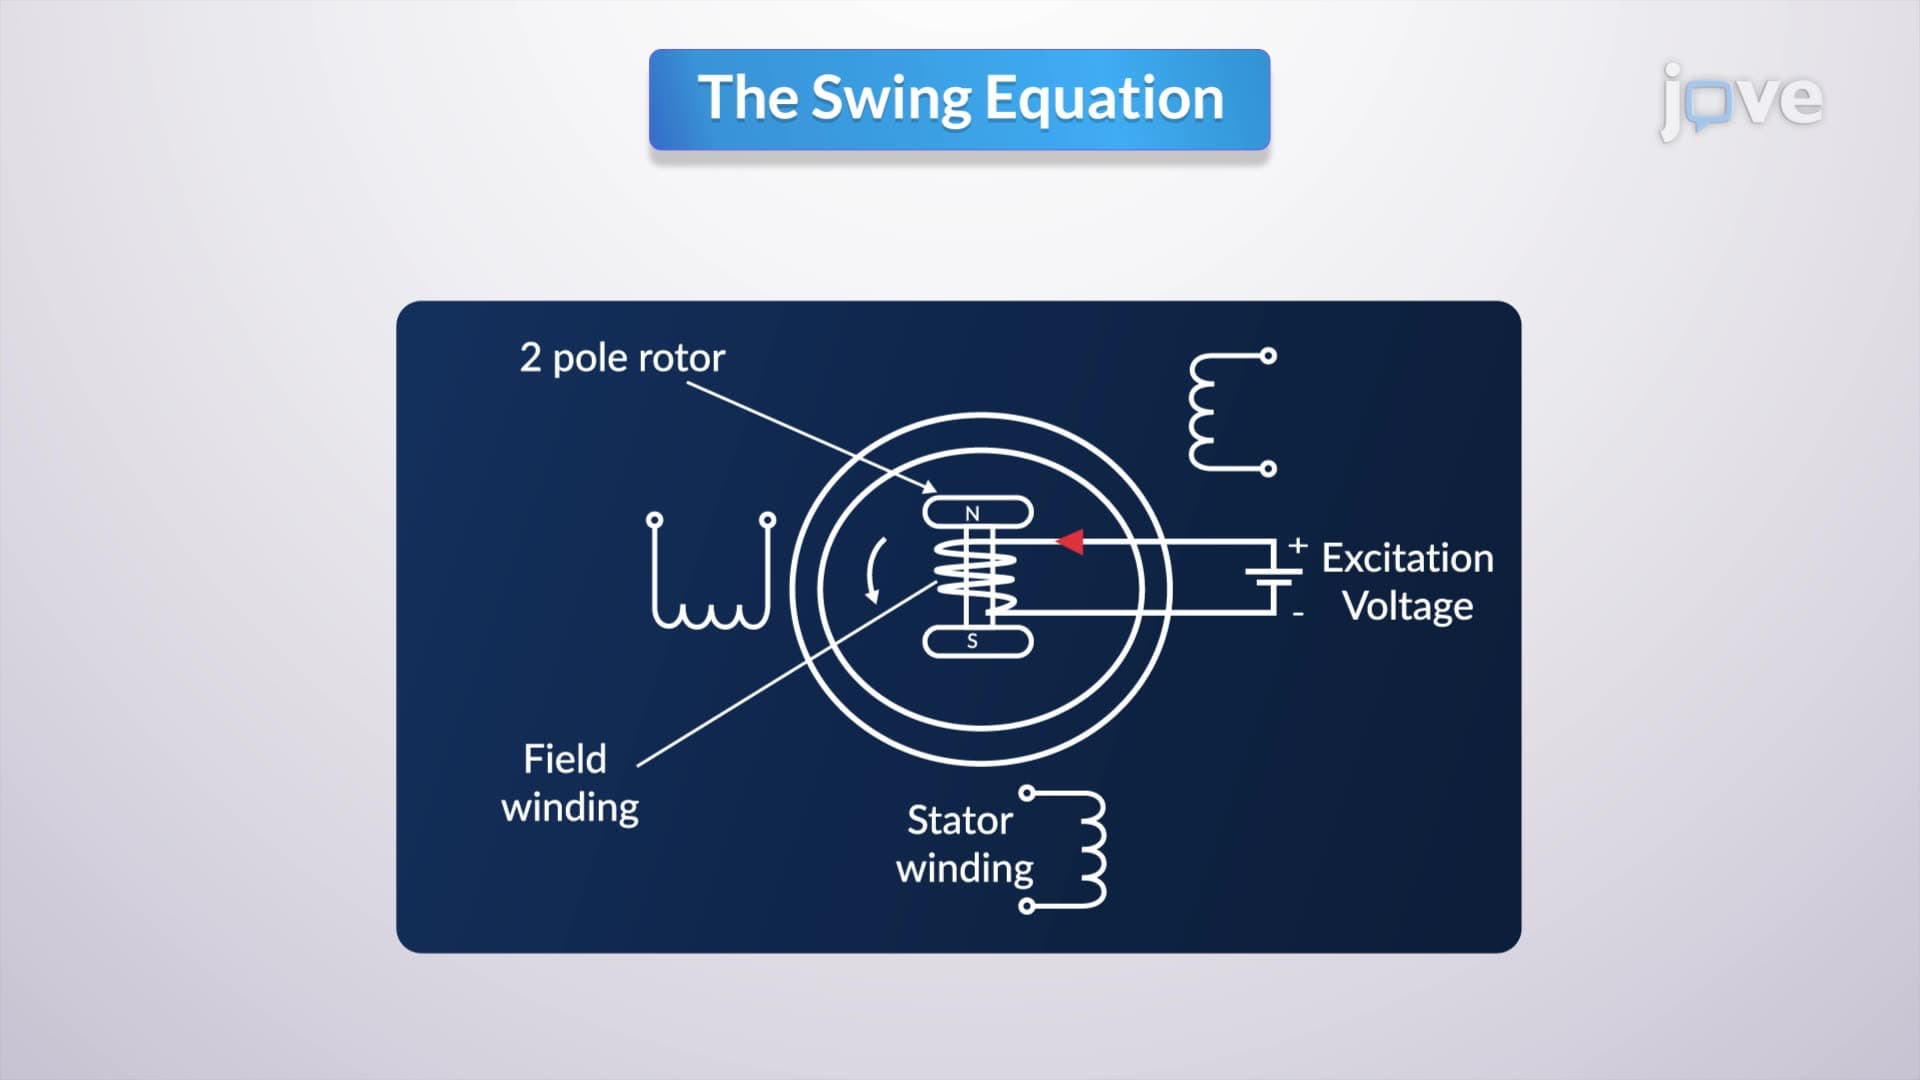
The Swing Equation
In a steady-state operation, the mechanical torque (Τm) supplied to the generator is balanced by the electrical torque (Τe)...
 01:26
The Power Flow Problem and Solution
 01:10
Energy Diagrams - II
The point in the energy diagram at which the system’s potential energy is the lowest is known as the local minima. The system tends to stay in this position indefinitely unless acted upon by a net force. The slope of the potential energy diagram at the local minima is zero, indicating that zero net force is acting on the system. The...
 01:24
Fast Decoupled and DC Powerflow
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...