Related Experiment Video
Updated: Dec 10, 2025
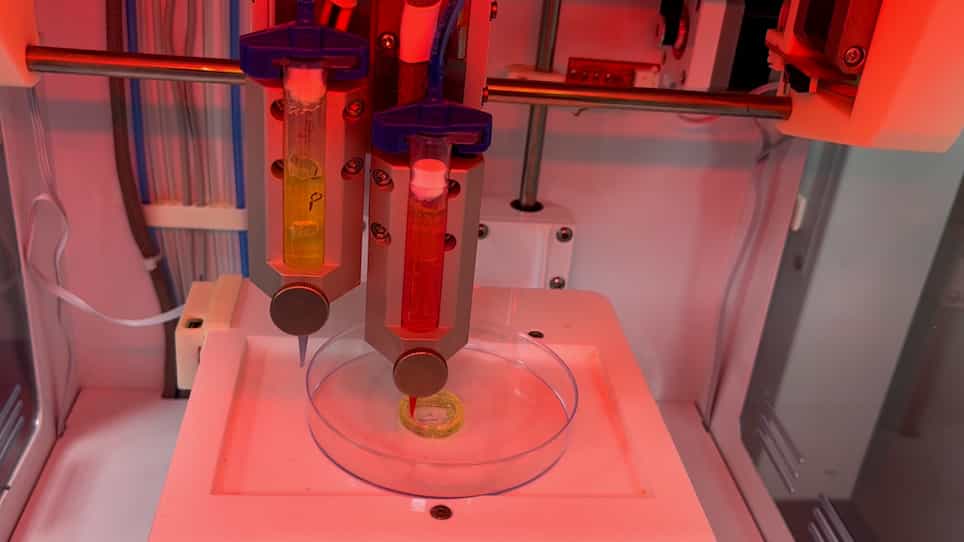
Four-Dimensional Printing of Stimuli-Responsive Hydrogel-Based Soft Robots
Published on: January 13, 2023
Beyond Human Hand: Shape-Adaptive and Reversible Magnetorheological Elastomer-Based Robot Gripper Skin
Dong-Soo Choi1, Tae-Hoon Kim2, Seok-Han Lee2
1School of Computer Science, College of Engineering and Information Technology, Semyung University, Jecheon, Chungcheongbuk-do 27136, Republic of Korea.

Abstract:
Developing a simple and universal solution for gripping fragile, multiscaled, and arbitrary-shaped objects using a robot gripper is challenging. Herein, we propose a universal, shape-adaptive/-retaining and reversible, hardness-variable gripper skin that serves as a resourceful solution for grasping such objects without damaging them. The proposed universal gripper skin based on a magnetorheological elastomer is attached to a robot gripper. The proposed skin takes the shape of a target object as soon as the gripper grasps the object. At this time, we solidify the gripper skin by applying a magnetic field, thereby allowing the gripper to grasp the target object easily. After releasing the objects, the magnetic field is removed and the deformed proposed gripper skin rapidly restores its original shape. The proposed adaptive gripper skin is made to grasp various target objects, such as cylinders, cuboids, and triangular prisms, based on which its grasping performance is evaluated.

