Related Experiment Video
Updated: Dec 10, 2025


An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
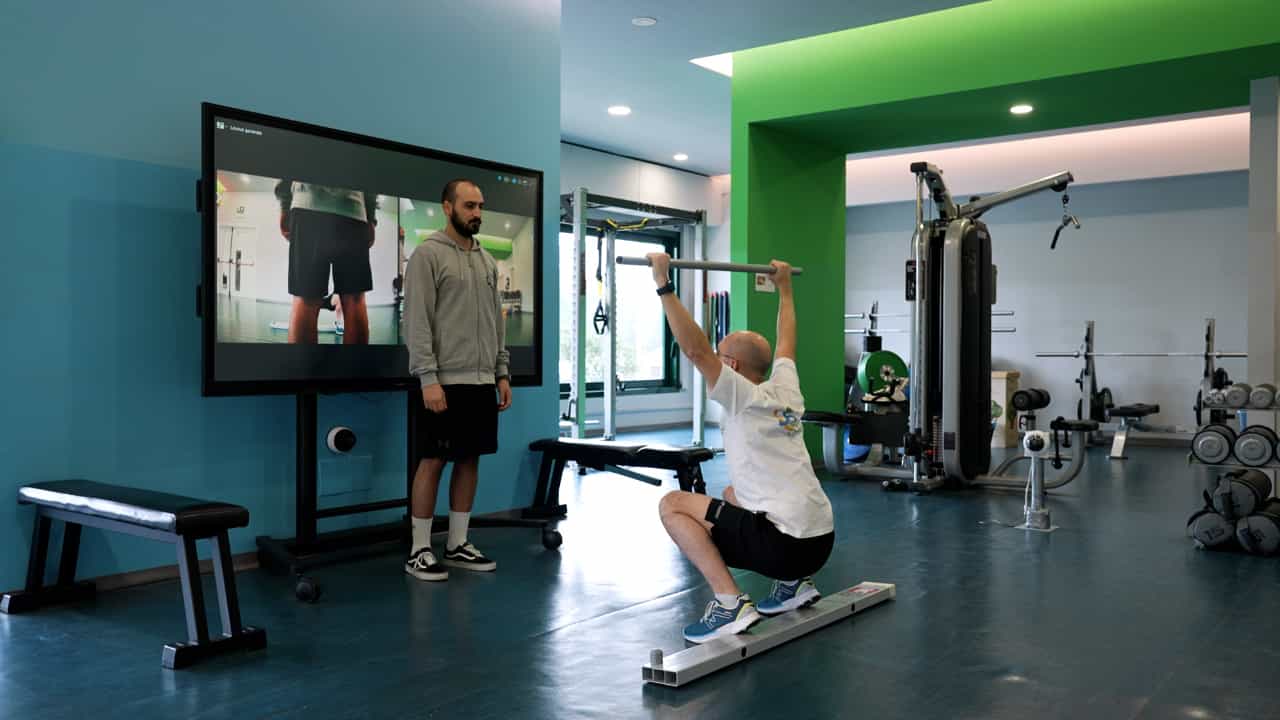
How Are Squat Timing and Kinematics in The Sagittal Plane Related to Squat Depth?
Magdalena Zawadka1, Jakub Smolka2, Maria Skublewska-Paszkowska2
1Department of Sports Medicine, Faculty of Health Sciences, Medical University of Lublin, Lublin, Poland.

Abstract:
The aim of this study was to analyze the relationship of range of motion (ROM) in the sagittal plane and timing parameters during a bodyweight squat to the depth of the squat. Sixty participants (20 females and 40 males) took part in this study. They were instructed to perform a bodyweight squat to the maximal depth position. Kinematic data were obtained using the optical motion capture system. The time for the descent phase of squatting was normalized from 0% (initial position, start of movement) to 100% (squat position-stop of movement). The ROM of ankle, knee, hip, pelvis and spine in the sagittal plane and the normalized time when the maximum joint angles occurred during the descent were analyzed to investigate the relationship between them and the squat depth in males and females. The knee ROM contributed most significantly, from all joints to squatting depth in both females and males (r = 0.92, p < 0.001). The squat depth was related to lumbar, hip and knee motion in females and to all kinematics parameters in males. Maximal ankle dorsiflexion and pelvis anterior tilt were reached earlier than the maximal angles of knee, hip and spine during squatting. Pelvis and ankle timing was negatively correlated with the squat depth (rs = -0.64, p < 0.001 and rs = -0.29, p = 0.02, respectively). This suggests that pelvis and ankle timing can be important to keeping balance during squatting and can lead to achieving the desired depth.
More Related Videos
Related Concept Videos
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:15
Kinematic Equations: Problem Solving
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:26
Kinematic Equations - I
 01:10
Relative Motion Analysis - Acceleration
 01:16
Bones of the Lower Limb: Femur and Patella