Related Experiment Video
Updated: Dec 9, 2025

Three-Dimensional Shape Modeling and Analysis of Brain Structures
Published on: November 14, 2019
LRF-Net: Learning Local Reference Frames for 3D Local Shape Description and Matching
Angfan Zhu1, Jiaqi Yang2, Weiyue Zhao1
1National Key Laboratory of Science and Technology on Multi-Spectral Information Processing, School of Artificial Intelligence and Automation, Huazhong University of Science and Technology, Wuhan 430074, China.

Abstract:
The local reference frame (LRF) acts as a critical role in 3D local shape description and matching. However, most existing LRFs are hand-crafted and suffer from limited repeatability and robustness. This paper presents the first attempt to learn an LRF via a Siamese network that needs weak supervision only. In particular, we argue that each neighboring point in the local surface gives a unique contribution to LRF construction and measure such contributions via learned weights. Extensive analysis and comparative experiments on three public datasets addressing different application scenarios have demonstrated that LRF-Net is more repeatable and robust than several state-of-the-art LRF methods (LRF-Net is only trained on one dataset). We show that LRFNet achieves 0.686 MeanCos performance on the UWA 3D modeling (UWA3M) dataset, outperforming the closest method by 0.18. In addition, LRF-Net can significantly boost the local shape description and 6-DoF pose estimation performance when matching 3D point clouds.
Related Concept Videos
 01:27
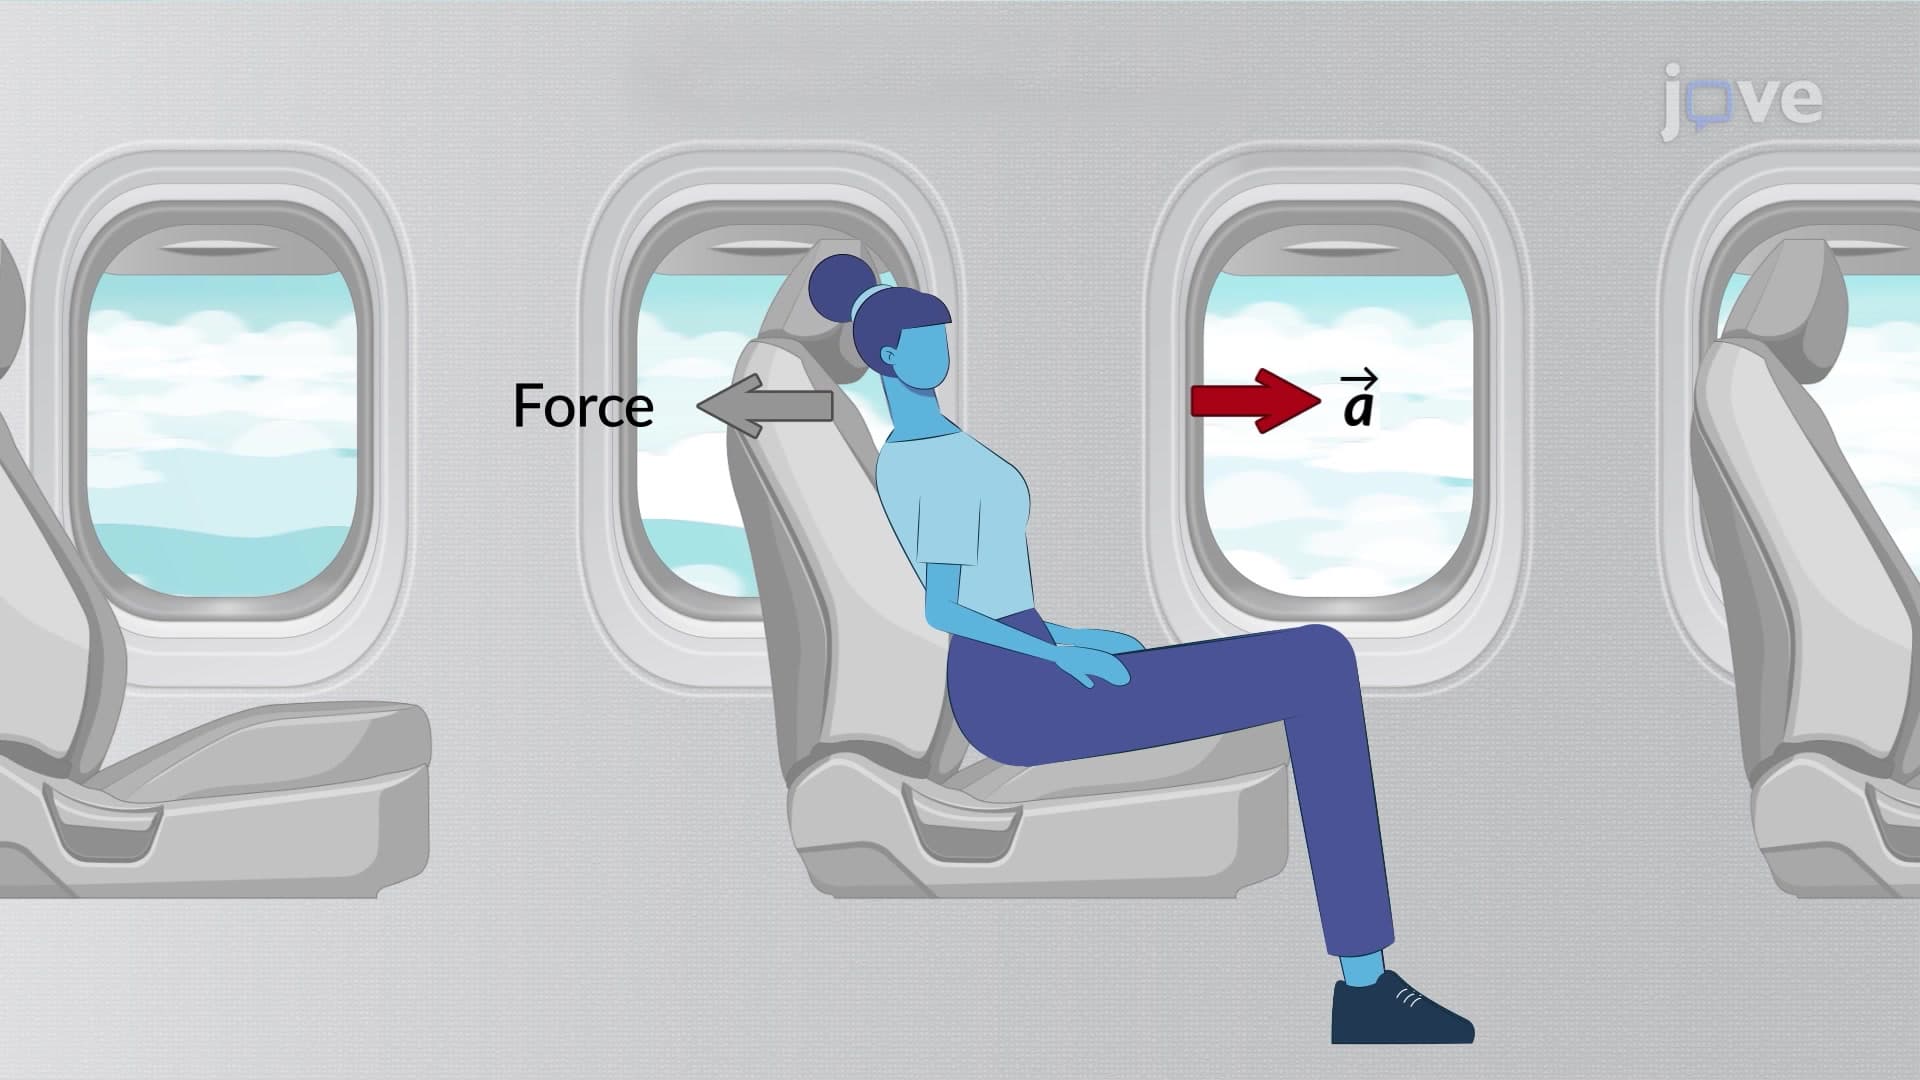
Non-inertial Frames of Reference
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:03
Inertial Frames of Reference
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...