Related Experiment Video
Updated: Dec 8, 2025

Clinical Assessment of Spatiotemporal Gait Parameters in Patients and Older Adults
Published on: November 7, 2014
Spatiotemporal Gait Measurement With a Side-View Depth Sensor Using Human Joint Proposals

Abstract:
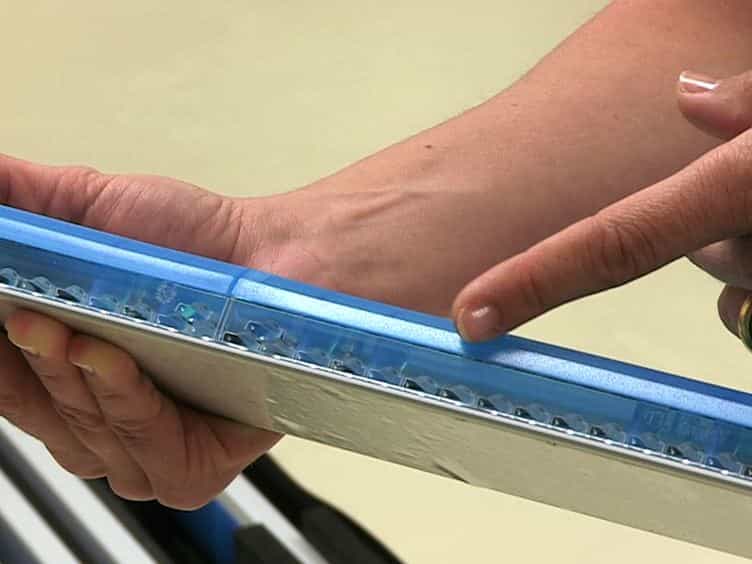
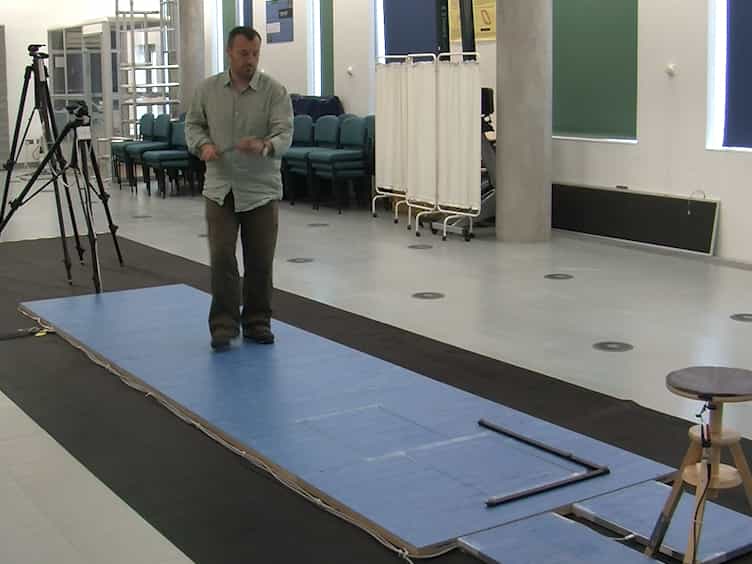
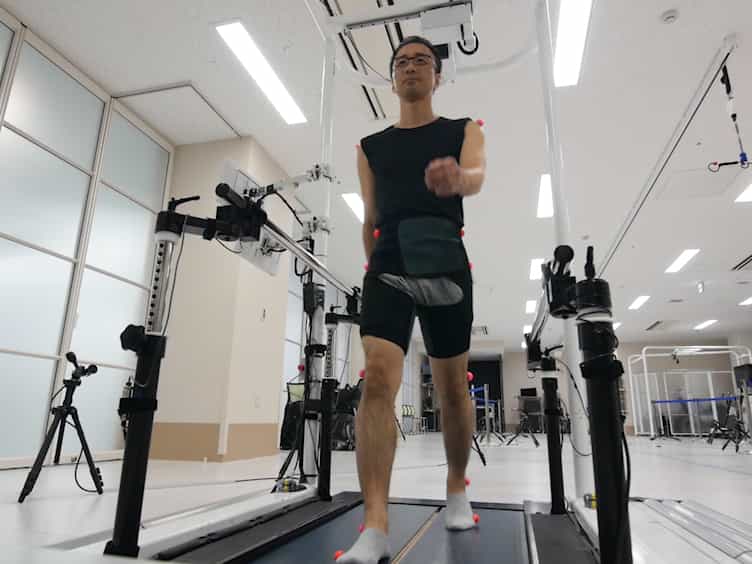
We propose a method for calculating standard spatiotemporal gait parameters from individual human joints with a side-view depth sensor. Clinical walking trials were measured concurrently by a side-view Kinect and a pressure-sensitive walkway, the Zeno Walkway. Multiple joint proposals were generated from depth images by a stochastic predictor based on the Kinect algorithm. The proposals are represented as vertices in a weighted graph, where the weights depend on the expected and measured lengths between body parts. A shortest path through the graph is a set of joints from head to foot. Accurate foot positions are selected by comparing pairs of shortest paths. Stance phases of the feet are detected by examining the motion of the feet over time. The stance phases are used to calculate four gait parameters: stride length, step length, stride width, and stance percentage. A constant frame rate was assumed for the calculation of stance percentage because time stamps were not captured during the experiment. Gait parameters from 52 trials were compared to the ground truth walkway using Bland-Altman analysis and intraclass correlation coefficients. The large spatial parameters had the strongest agreements with the walkway (ICC(2, 1) = 1.00 and 0.98 for stride and step length with normal pace, respectively). The presented system directly calculates gait parameters from individual foot positions while previous side-view systems relied on indirect measures. Using a side-view system allows for tracking walking in both directions with one camera, extending the range in which the subject is in the field of view.
More Related Videos
Related Concept Videos
 01:18
Distance Measurements by Taping
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:15
Depth Perception and Spatial Vision