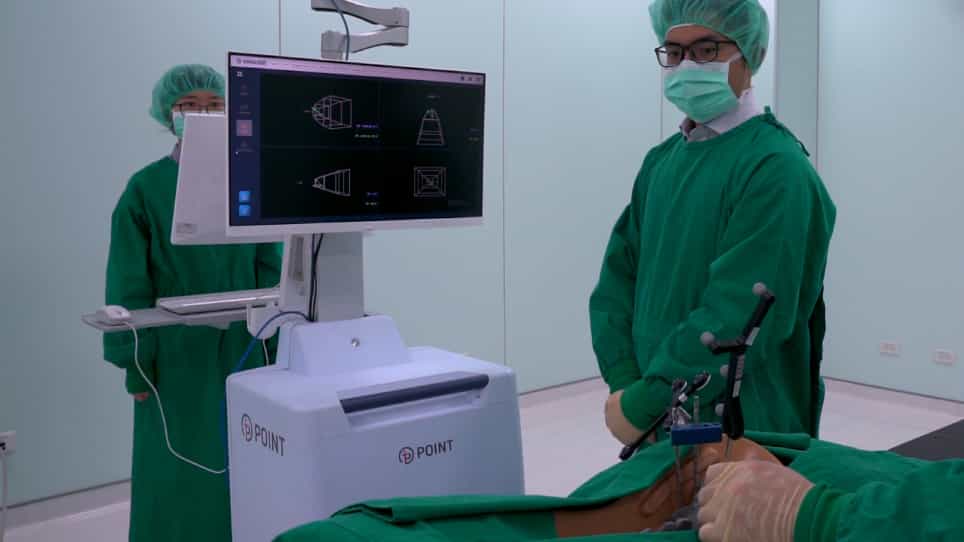
Related Experiment Video
Updated: Dec 7, 2025

A Teleoperated Robotic System-Assisted Percutaneous Transiliac-Transsacral Screw Fixation Technique
Published on: January 6, 2023
Robotic-assisted cortical bone trajectory (CBT) screws using the Mazor X Stealth Edition (MXSE) system: workflow and
John A Buza1, Christopher R Good2, Ronald A Lehman3
1Department of Spine Surgery, Norton Leatherman Spine Center, 210 E. Gray St. Suite 900, Louisville, KY, 40202, USA.

Abstract:
Robotic-assisted spine surgery has a number of potential advantages, including more precise pre-operative planning, a high degree of accuracy in screw placement, and significantly reduced radiation exposure to the surgical team. While the current primary goal of these systems is to improve the safety of spine surgery by increasing screw accuracy, there are a number of technical errors that may increase the risk of screw malposition. Given the learning curve associated with this technology, it is important for the surgeon to have a thorough understanding of all required steps. In this article, we will demonstrate the setup and workflow of a combined navigation and robotic spine surgery platform using the Mazor X Stealth Edition (MXSE) system to place cortical-based trajectory (CBT) screws, including a review of all technical tips and pearls to efficiently perform this procedure with minimal risk of screw malposition. In this article, we will review surgical planning, operating room setup, robotic arm mounting, registration, and CBT screw placement using the MXSE system.