Related Experiment Video
Updated: Jun 28, 2026
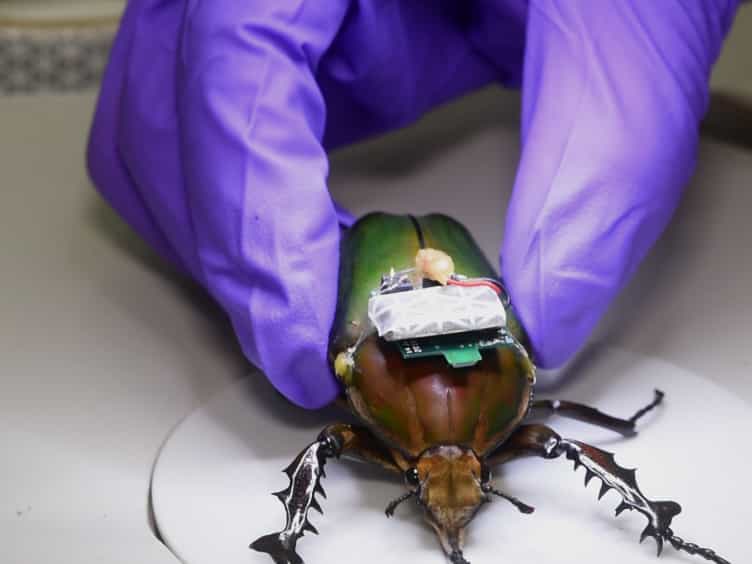

Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle Mercynorrhina torquata
Published on: September 2, 2016
Automatic tracking of free-flying insects using a cable-driven robot
Rémi Pannequin1, Mélanie Jouaiti2, Mohamed Boutayeb1
1Université de Lorraine, CNRS, CRAN, 54000 Nancy, France.

Abstract:
Flying insects have evolved to develop efficient strategies to navigate in natural environments. Yet, studying them experimentally is difficult because of their small size and high speed of motion. Consequently, previous studies were limited to tethered flights, hovering flights, or restricted flights within confined laboratory chambers. Here, we report the development of a cable-driven parallel robot, named lab-on-cables, for tracking and interacting with a free-flying insect. In this approach, cameras are mounted on cables, so as to move automatically with the insect. We designed a reactive controller that minimizes the online tracking error between the position of the flying insect, provided by an embedded stereo-vision system, and the position of the moving lab, computed from the cable lengths. We validated the lab-on-cables with Agrotis ipsilon moths (ca. 2 centimeters long) flying freely up to 3 meters per second. We further demonstrated, using prerecorded trajectories, the possibility to track other insects such as fruit flies or mosquitoes. The lab-on-cables is relevant to free-flight studies and may be used in combination with stimulus delivery to assess sensory modulation of flight behavior (e.g., pheromone-controlled anemotaxis in moths).
More Related Videos
 09:00
Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect
Published on: December 19, 2016
 08:13
SwarmSight: Real-time Tracking of Insect Antenna Movements and Proboscis Extension Reflex Using a Common Preparation and Conventional Hardware
Published on: December 25, 2017
