Related Experiment Video
Updated: Dec 6, 2025

Measurements of Waves in a Wind-wave Tank Under Steady and Time-varying Wind Forcing
Published on: February 13, 2018
Two Supervised Machine Learning Approaches for Wind Velocity Estimation Using Multi-Rotor Copter Attitude
David Crowe1, Raghava Pamula1, Hing Yuet Cheung1
1Department of Environmental Sciences, University of Virginia, Charlottesville, VA 22903, USA.

Abstract:
In this work we address the adequacy of two machine learning methods to tackle the problem of wind velocity estimation in the lowermost region of the atmosphere using on-board inertial drone data within an outdoor setting. We fed these data, and accompanying wind tower measurements, into a K-nearest neighbor (KNN) algorithm and a long short-term memory (LSTM) neural network to predict future windspeeds, by exploiting the stabilization response of two hovering drones in a wind field. Of the two approaches, we found that LSTM proved to be the most capable supervised learning model during more capricious wind conditions, and made competent windspeed predictions with an average root mean square error of 0.61 m·s-1 averaged across two drones, when trained on at least 20 min of flight data. During calmer conditions, a linear regression model demonstrated acceptable performance, but under more variable wind regimes the LSTM performed considerably better than the linear model, and generally comparable to more sophisticated methods. Our approach departs from other multi-rotor-based windspeed estimation schemes by circumventing the use of complex and specific dynamic models, to instead directly learn the relationship between drone attitude and fluctuating windspeeds. This exhibits utility in a range of otherwise prohibitive environments, like mountainous terrain or off-shore sites.
More Related Videos

Related Concept Videos
 01:24
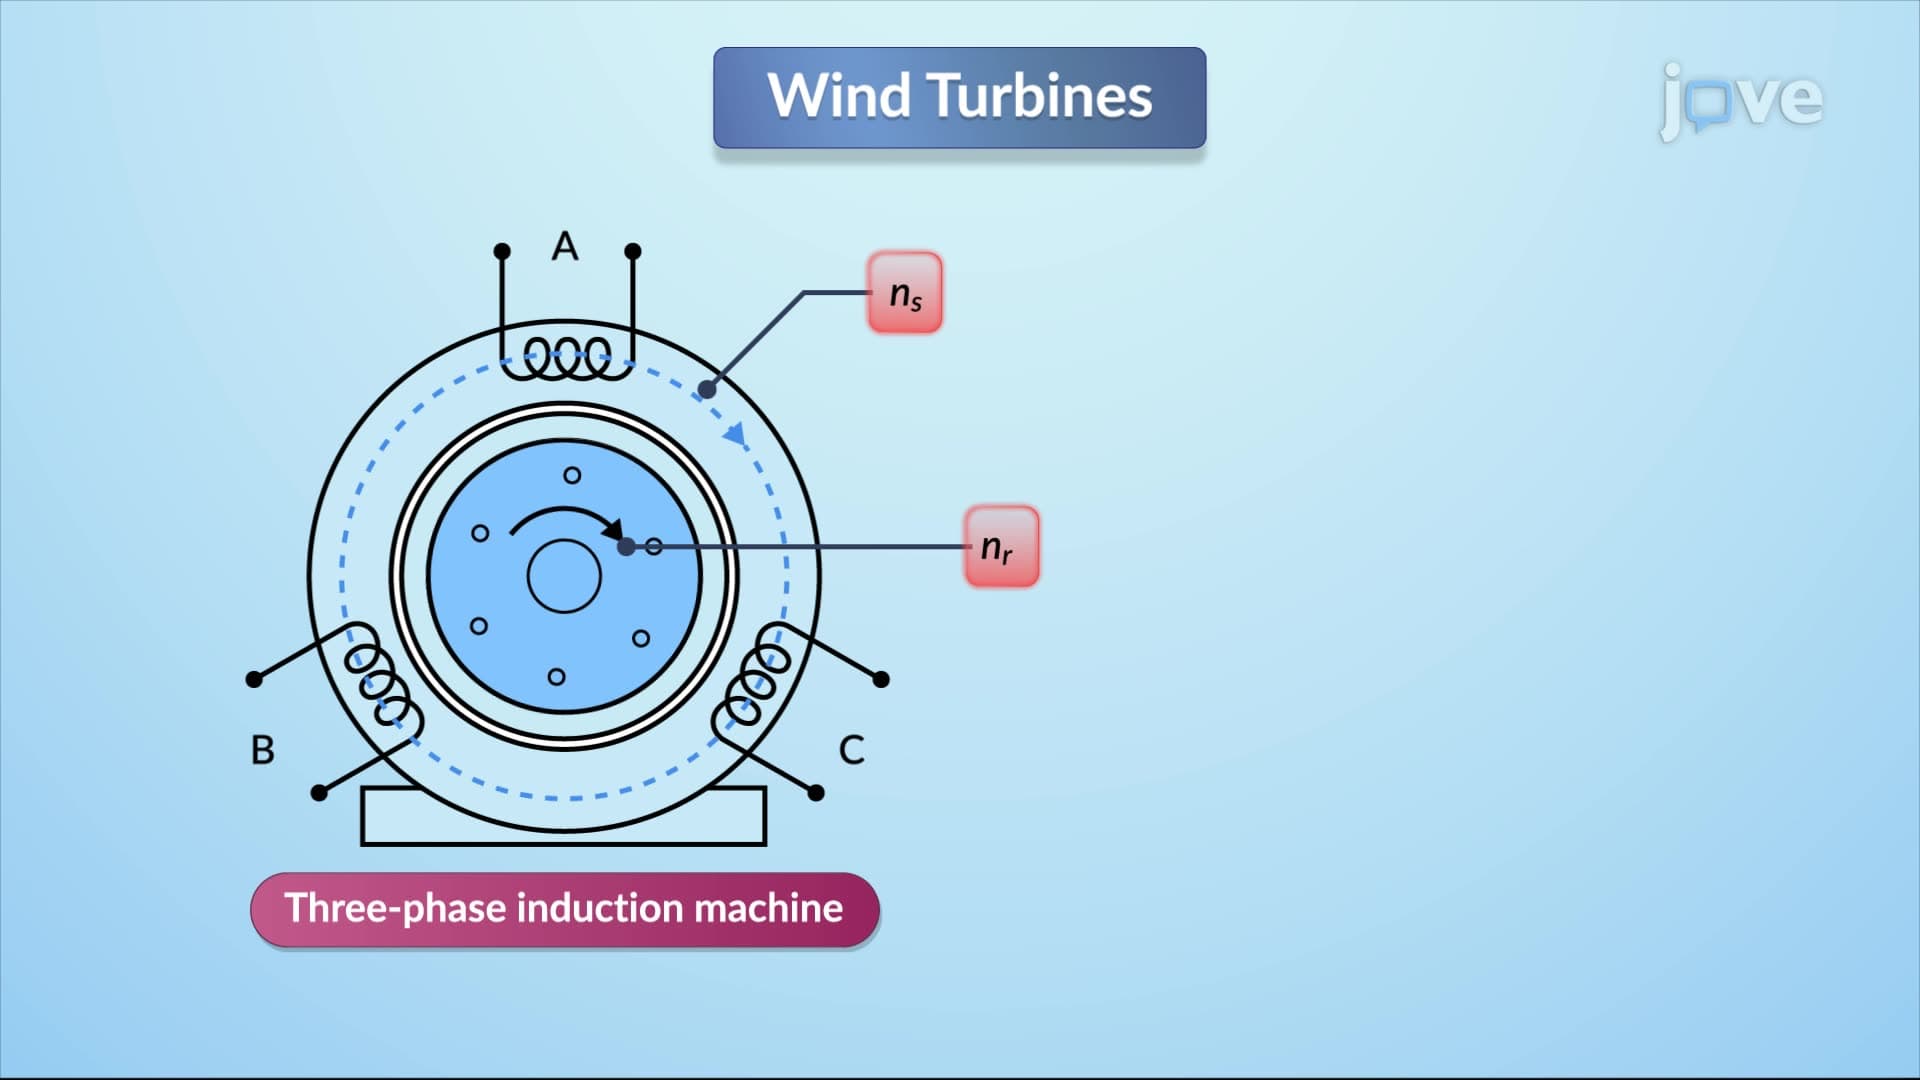
Wind Turbine Machine Models
Induction machines interact through the rotating magnetic field generated by the stator and the rotor. The key parameter is slip, which is the difference between synchronous speed and rotor speed relative to synchronous speed. Slip is...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...