Related Experiment Video
Updated: Dec 3, 2025

Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
Design and Analysis of a Variable Inertia Spatial Robotic Tail for Dynamic Stabilization
Xinran Wang1, Hailin Ren1, Anil Kumar1
1Mechanical Engineering, Robotics and Mechatronics Lab, Virginia Tech, Blacksburg, VA 24060, USA.

Abstract:
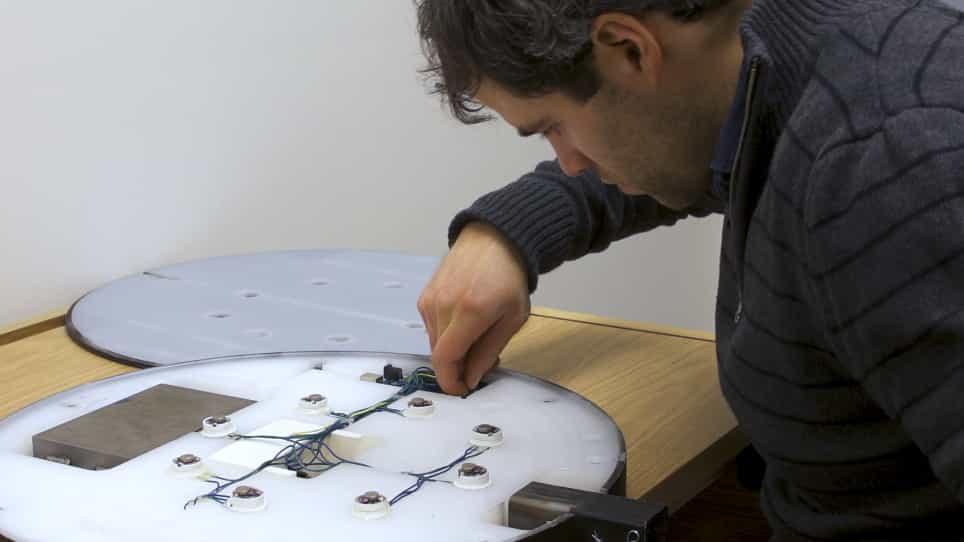
This paper presents the design of a four degree-of-freedom (DoF) spatial tail and demonstrates the dynamic stabilization of a bipedal robotic platform through a hardware-in-loop simulation. The proposed tail design features three active revolute joints with an active prismatic joint, the latter of which provides a variable moment of inertia. Real-time experimental results validate the derived mathematical model when compared to simulated reactive moment results, both obtained while executing a pre-determined trajectory. A 4-DoF tail prototype was constructed and the tail dynamics, in terms of reactive force and moments, were validated using a 6-axis load cell. The paper also presents a case study where a zero moment point (ZMP) placement-based trajectory planner, along with a model-based controller, was developed in order for the tail to stabilize a simulated unstable biped robot. The case study also demonstrates the capability of the motion planner and controller in reducing the system's kinetic energy during periods of instability by maintaining ZMP within the support polygon of the host biped robot. Both experimental and simulation results show an improvement in the tail-generated reactive moments for robot stabilization through the inclusion of prismatic motion while executing complex trajectories.

Related Concept Videos
 01:14
Stability of structures
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 00:49
Rigid Body Equilibrium Problems - I