

Active Disturbance Rejection Position Synchronous Control of Dual-Hydraulic Actuators with Unknown Dead-Zones
Lixin Wang1,2, Dingxuan Zhao1,2, Fucai Liu3
1School of Mechanical Engineering, Yanshan University, Qinhuangdao 066004, China.

Abstract:
In this paper, an integrated control strategy of position synchronization control for dual-electro-hydraulic actuators with unknown dead-zones is proposed. The unified control scheme consists of two parts: One is adaptive dead-zone inverse controllers of each hydraulic actuator to offset the unknown dead-zones. The other is the linear active disturbance rejection controller (LADRC) for position synchronization error. First, the model of the electro-hydraulic proportional position control system (EPPS) was identified by the forgetting factor recursive least square (FFRLS) algorithm. Next, the model reference dead-zone inverse adaptive controller (MRDIAC) was developed to compensate for the delay of actuator response caused by unknown proportional valve dead-zones. Meanwhile, the validity of the adaptive law was proven by the Lyapunov theory. Therefore, the position control accuracy of each hydraulic actuator is guaranteed. Besides, to improve the precision of position synchronization control of dual-hydraulic actuators, a simple and elegant synchronous error-based LADRC was adopted, which applies the total disturbances design concept to eliminate and compensate for motion coupling rather than cross-coupling technology. The performance of the proposed control solution was investigated through extensive comparative experiments based on a hydraulic test platform. The experimental results successfully demonstrate the effectiveness and practicality of the proposed method.

Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:03
Application of Pascal's Law
Hydraulic systems are used to operate automotive brakes, hydraulic jacks, and numerous other mechanical systems. We can derive a relationship between the forces in a simple hydraulic system...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:16
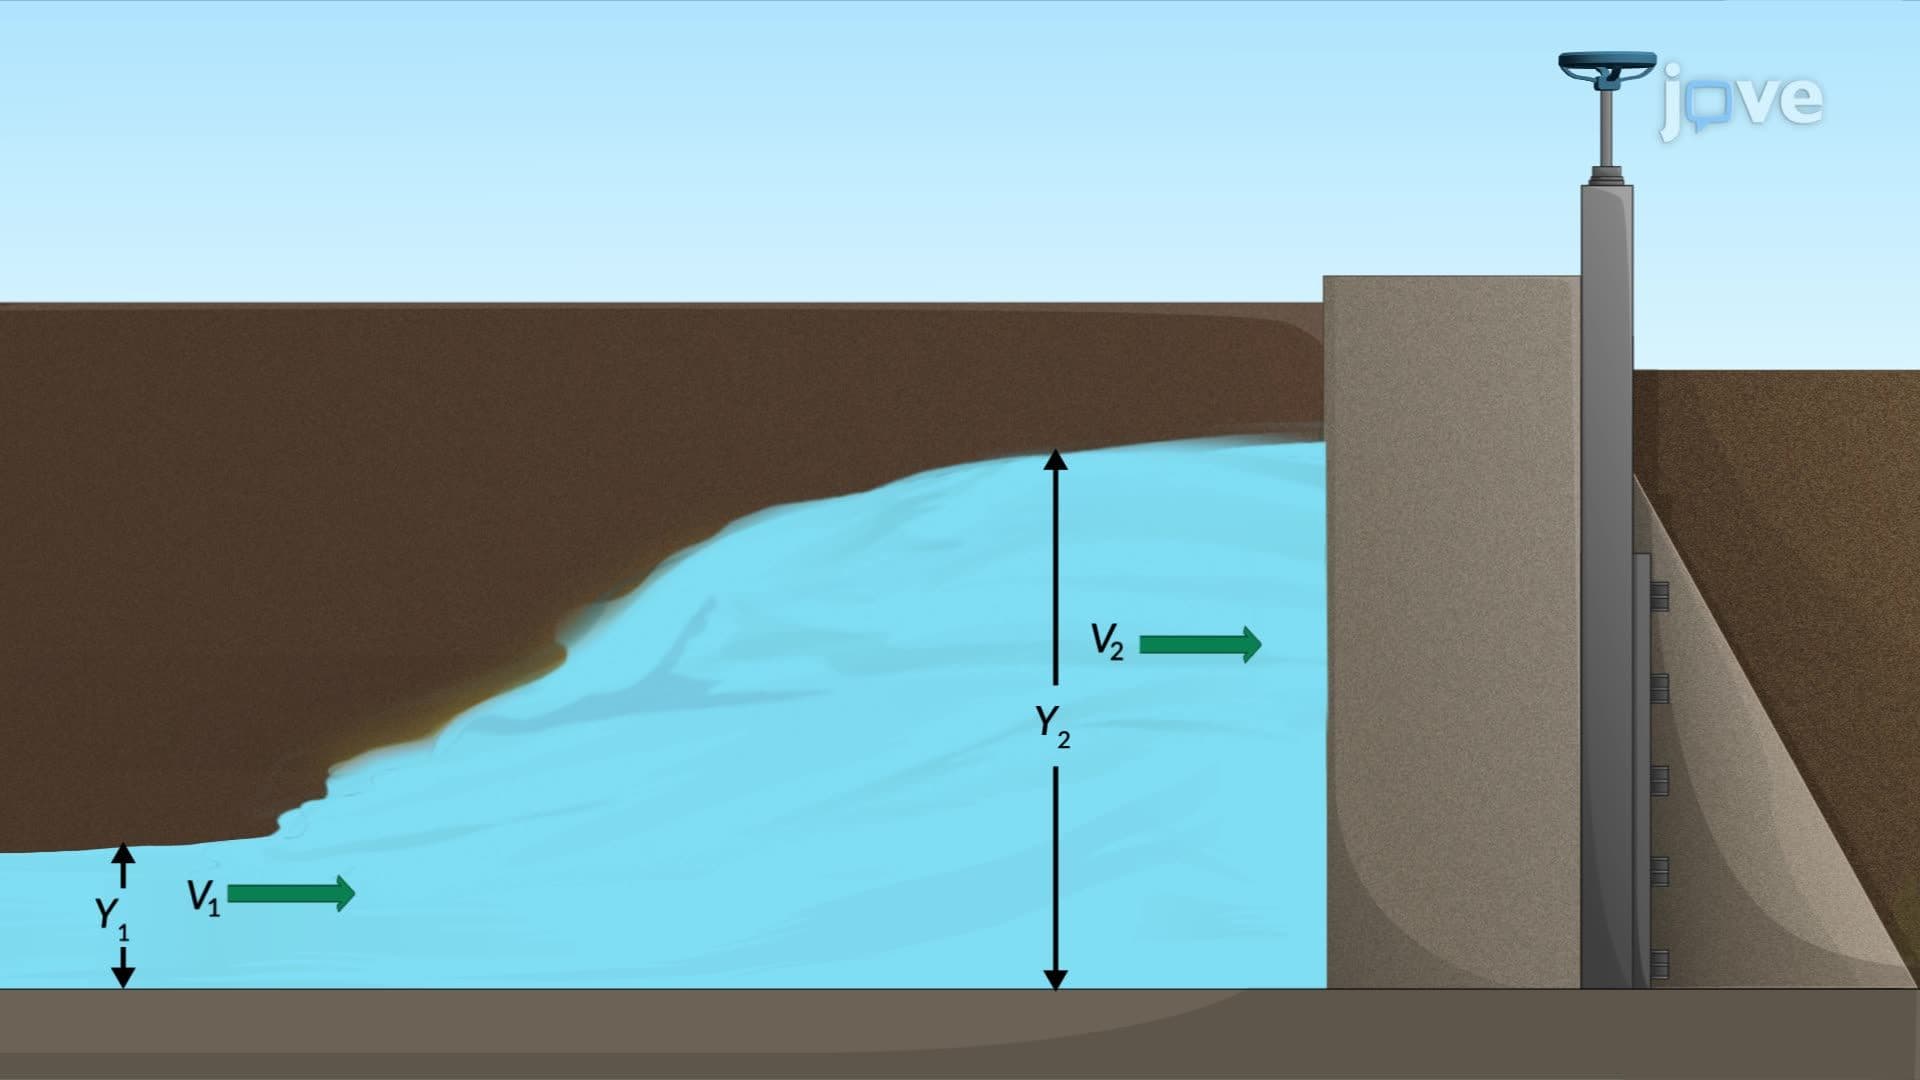
Hydraulic Jump: Problem Solving
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...