
Observer-based deadbeat predictive speed controller for surface-mounted PM synchronous motor
Anh Tuan Nguyen1, Muhammad Saad Rafaq1, Han Ho Choi1
1Division of Electronics and Electrical Engineering, Dongguk University, Seoul 04620, South Korea.

Abstract:
This paper investigates an observer-based deadbeat predictive speed controller (DBPSC) for a prototype surface-mounted permanent magnet synchronous motor (SPMSM) drive system. Unlike the conventional deadbeat controllers which are mainly used for deadbeat current control in the inner loop in a cascaded control structure, the proposed deadbeat controller is designed by incorporating a speed controller with a load torque disturbance observer. Specifically the proposed deadbeat speed control law consists of a deadbeat stabilizing feedback control term and a compensation control term. The stability of the proposed closed-loop system is assured based on the former term by forcing all poles of the dynamic error vector toward the origin within a short transient time, which guarantees a fast transient response of the control system by using the solution of an optimal control problem. The latter term is proposed based on the predicted q-axis current to compensate for the model nonlinearities and parameter uncertainties. Next, the deadbeat load torque observer (DBLTO) is proposed to provide a precisely estimated load torque with a high estimation rate for the predicted q-axis current in the latter term, which helps the proposed scheme in obtaining a small steady-state error (SSE), a low total harmonic distortion (THD), and robustness against the parameter variations. In addition, the proposed scheme possesses a simple structure, so it reduces the computational burden for digital implementation. The Lyapunov theory is utilized in the stability proof process of the proposed observer-based method. Finally, the comparative studies between the proposed DBPSC and a conventional deadbeat speed controller (DBSC) are performed under the sudden changes of speed and load torque through simulations on MATLAB/Simulink and experiments on a prototype SPMSM drive using a TI TMS320F28335 DSP platform.


Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
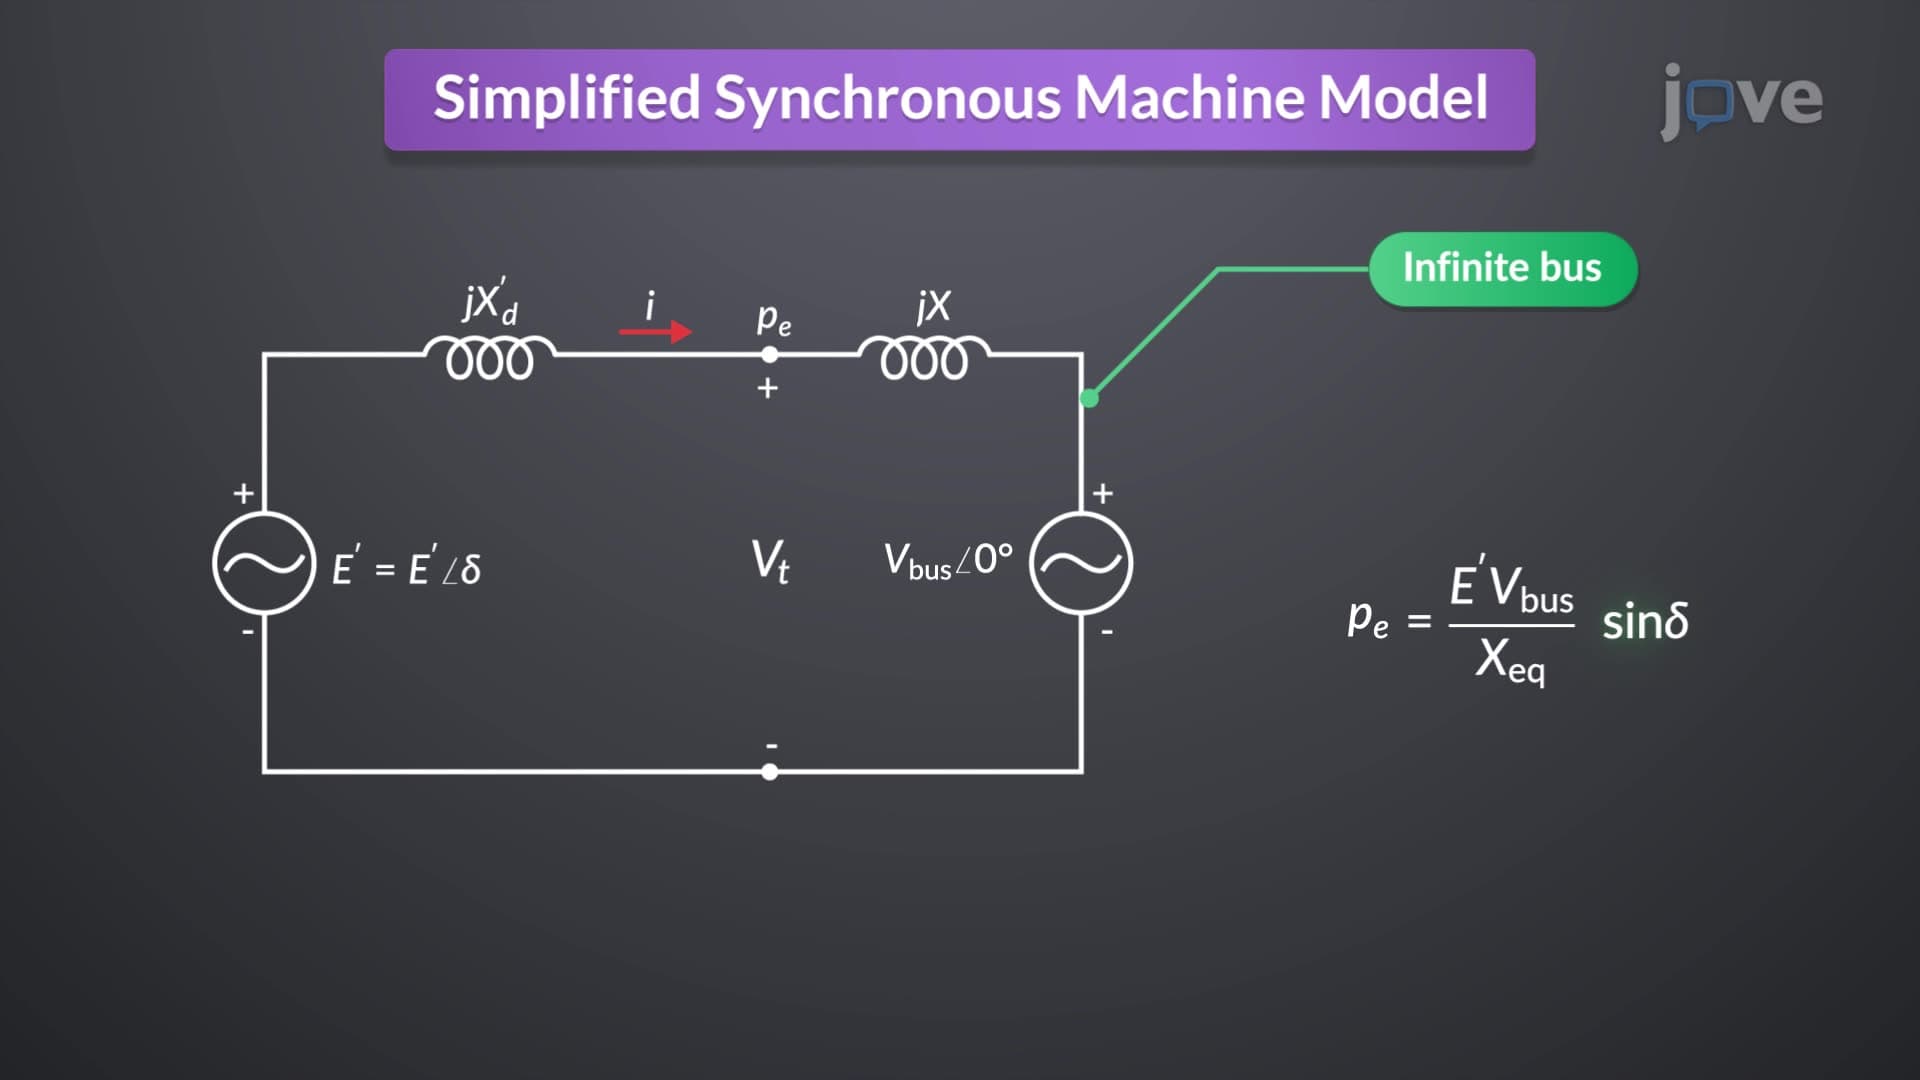 01:30
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
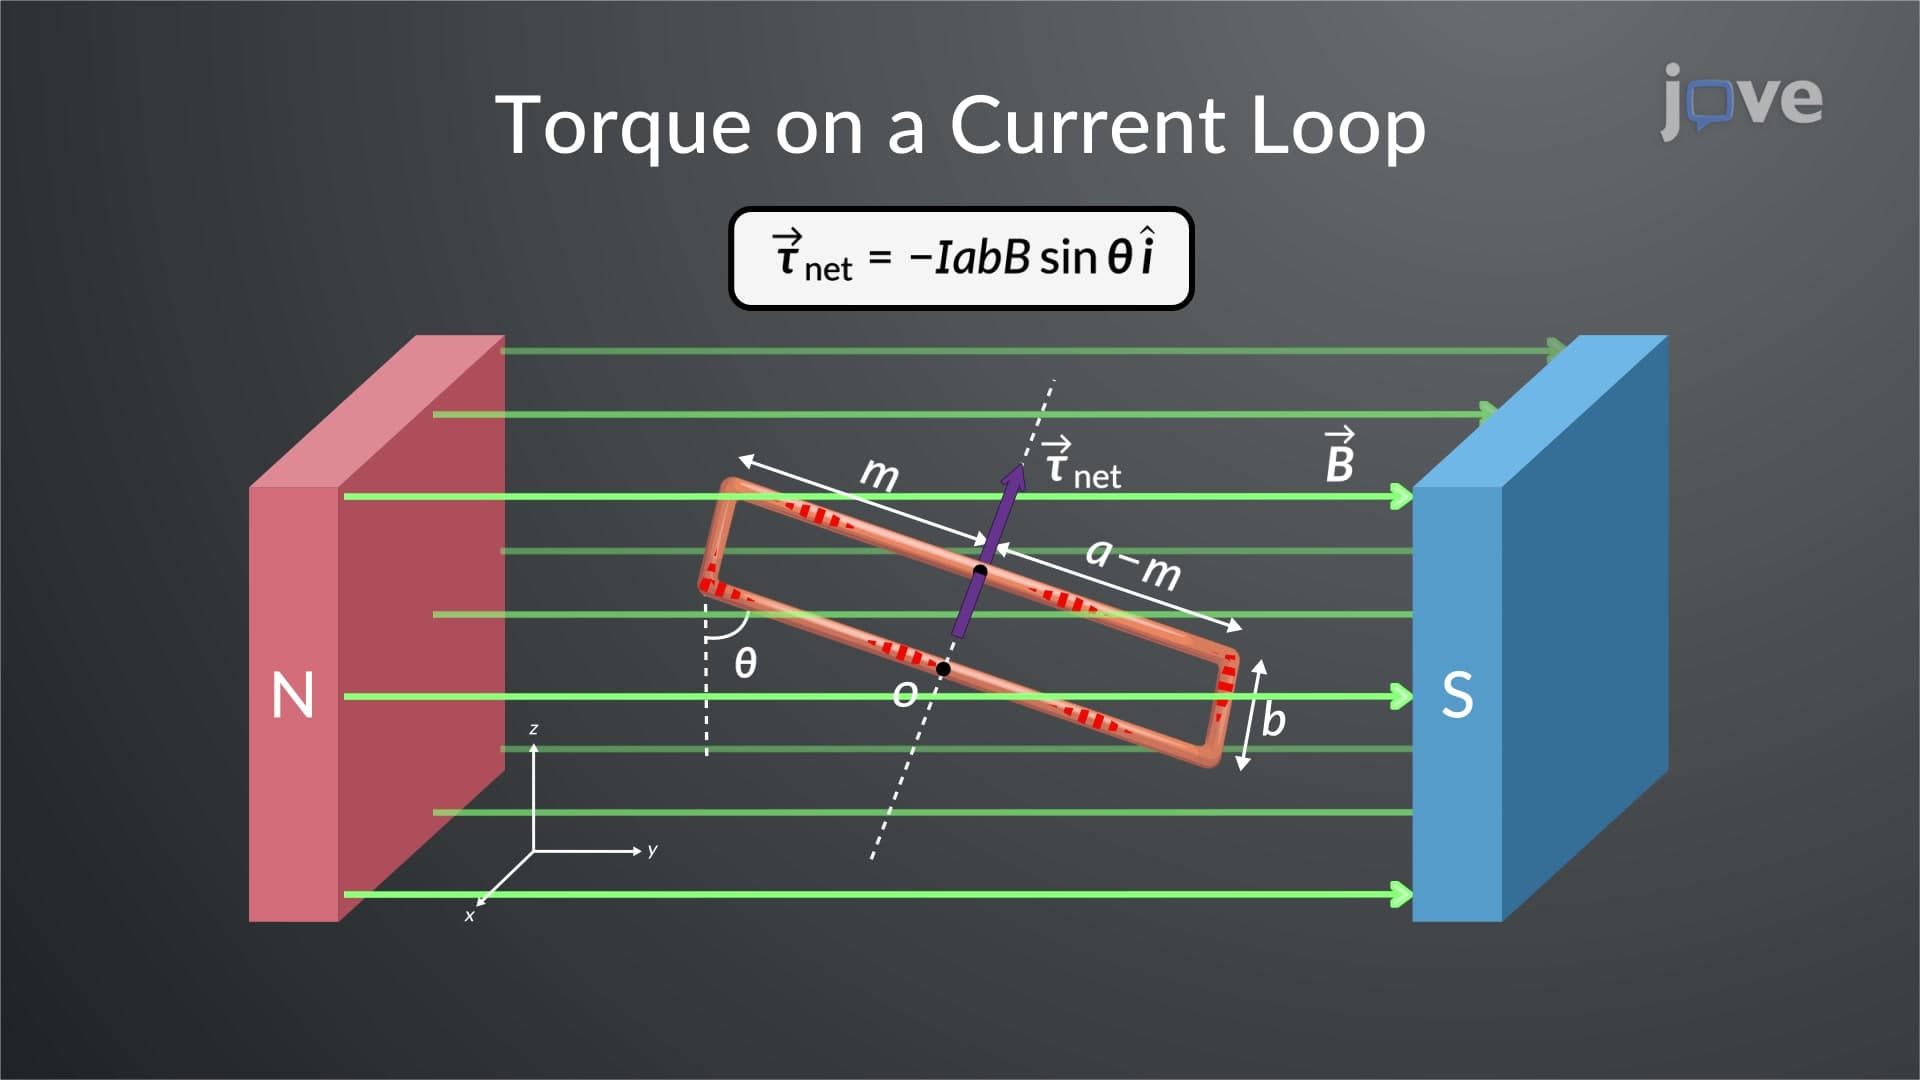 01:13
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
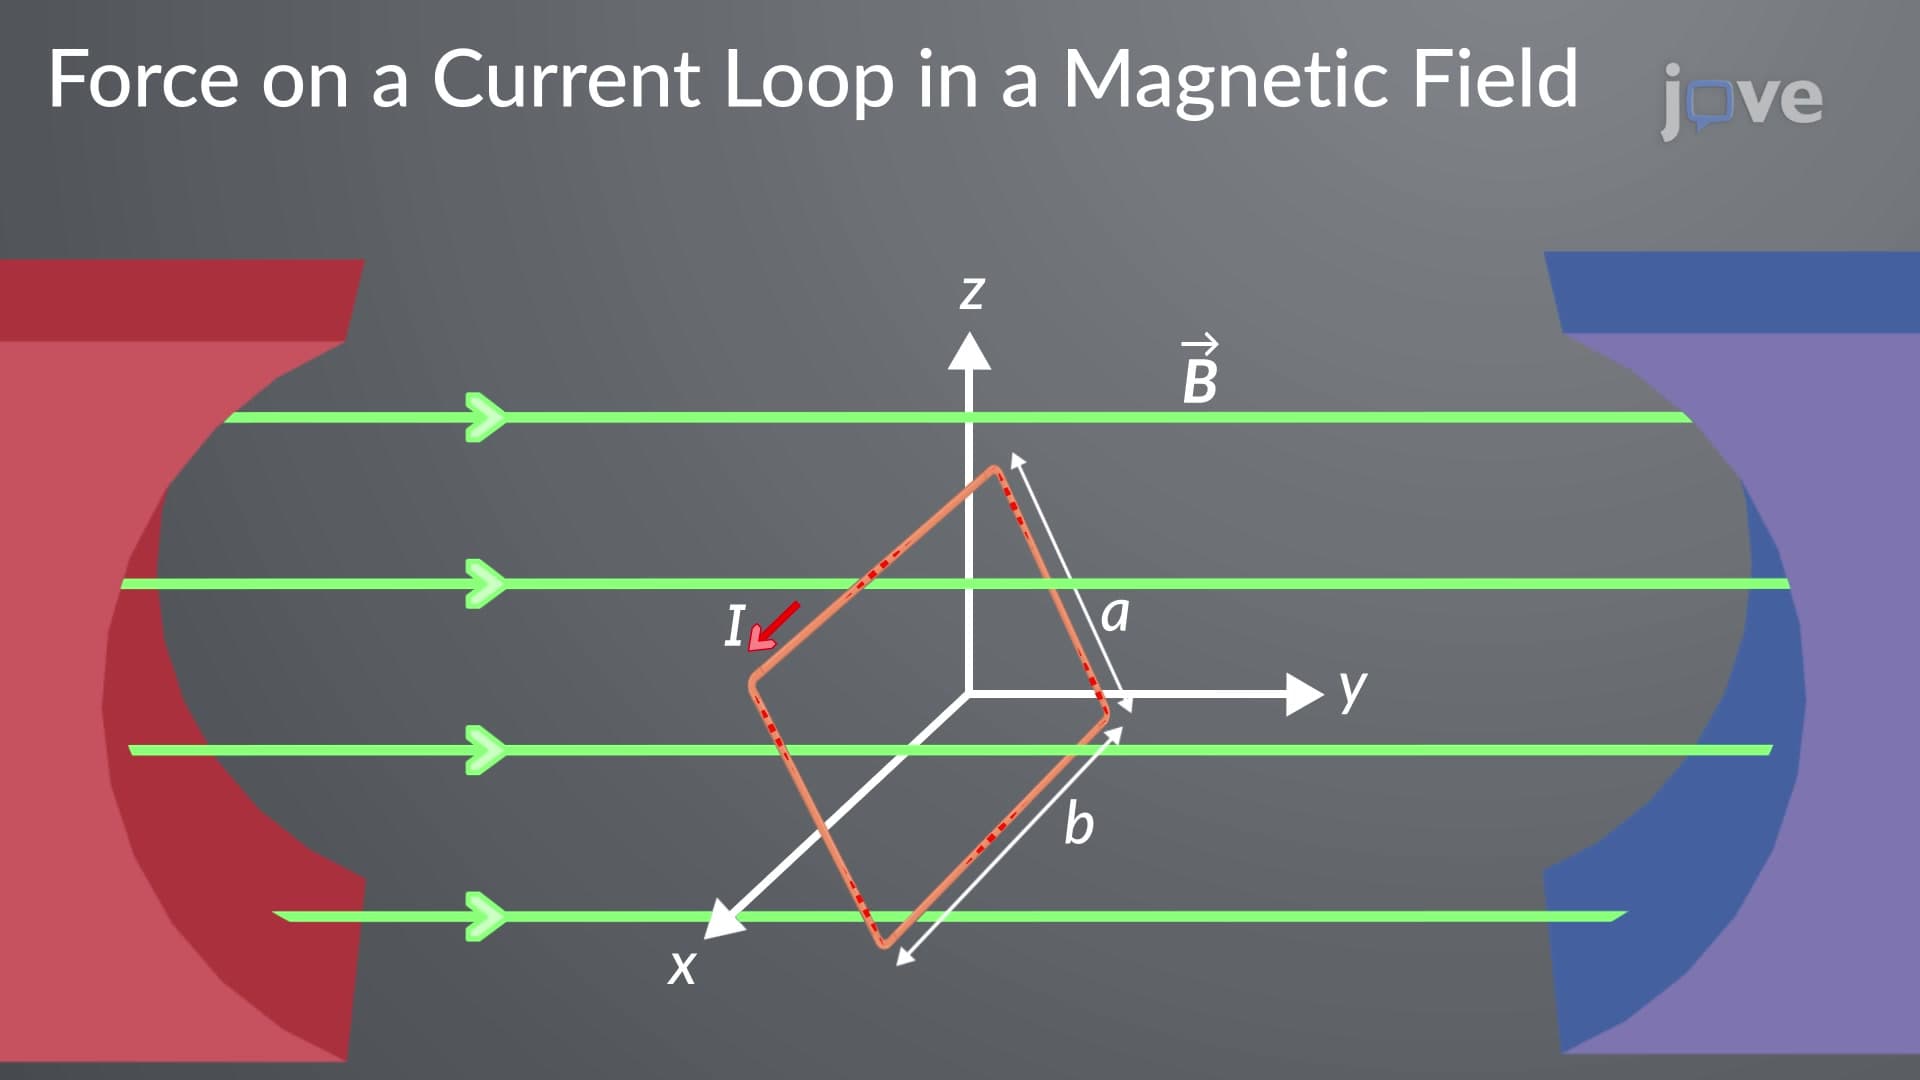 01:17
Force On A Current Loop In A Magnetic Field